MARSAD / CONSOLIDATED CATALOG / #004
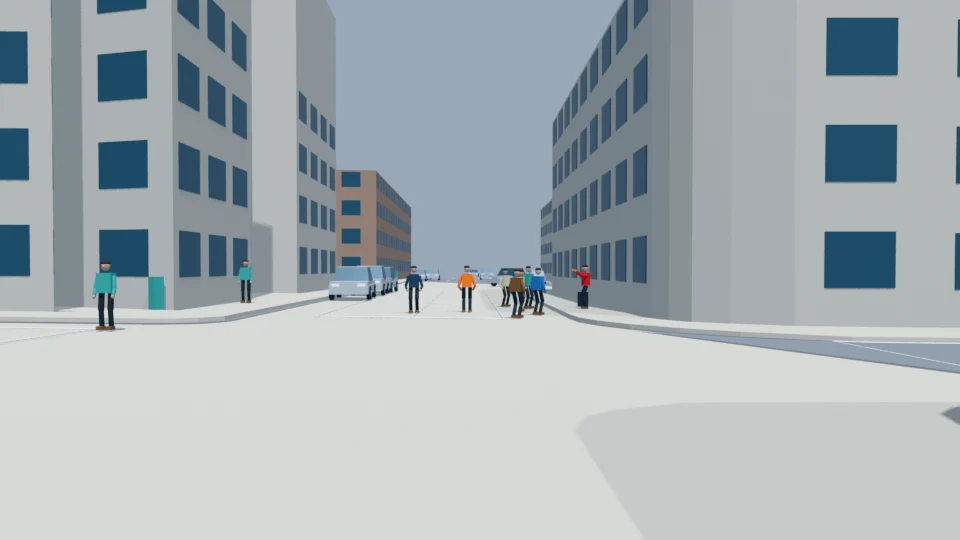
Roadside performer with standing and pacing spectators
Awaiting your 3D scene approvalCounterfactual proposal: a street performer attracts seven spectators beside the south sidewalk. Four spectators remain in place, two pace back and forth in the road, and one approaches from the sidewalk. The gathering continues to obstruct ego's corridor after the performance pauses.
Original description: 前方有街头艺人在路边表演聚集人群,部分行人站立或来回走动
Loading the full animated scene…
Critical moments
What to verify
- Require human approval of the initial review state and complete rehearsal before image generation.
- Verify one performer, seven distinct spectators and one persistent speaker.
- Play the finite -7 to 40 second timeline at 20 Hz with 941 inclusive frames.
- Verify the performer and speaker lie within the mapped south sidewalk polygon; road-side spectators and pacing paths must lie inside the windblown road polygon.
- Preserve at least 0.6 m body clearance between ordinary spectators, including when the two pacing paths pass one another.
- Verify approximately 0.7-0.8 m/s walking, stationary heading reversals and no instantaneous turnarounds.
- Keep the performance recognizably distinct from a generic crossing: spectators orient toward the performer and pace parallel to the curb.
- Keep ego stopped through 40 seconds because c004_p1 remains directly in its corridor.
Review notes
Reviewed performer, gathered audience and moving passersby through all event stills. Audience gestures and the roadside performance remain readable. Background vehicles no longer cross the critical pedestrian work area.
Check action, relative position, facing, posture and visibility. Approximate offsets are acceptable. Sampled visual checks do not prove every contact or continuous collision clearance.
Rendered inspection views
Event, approach and final views rendered from the exact committed Higgsfield Blender source. These are procedural 3D previews, not generated training photographs.
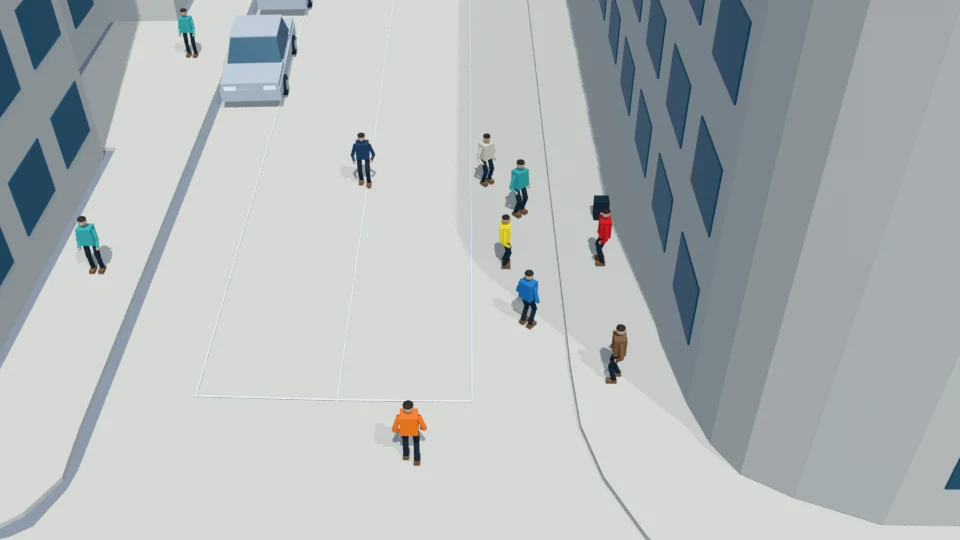
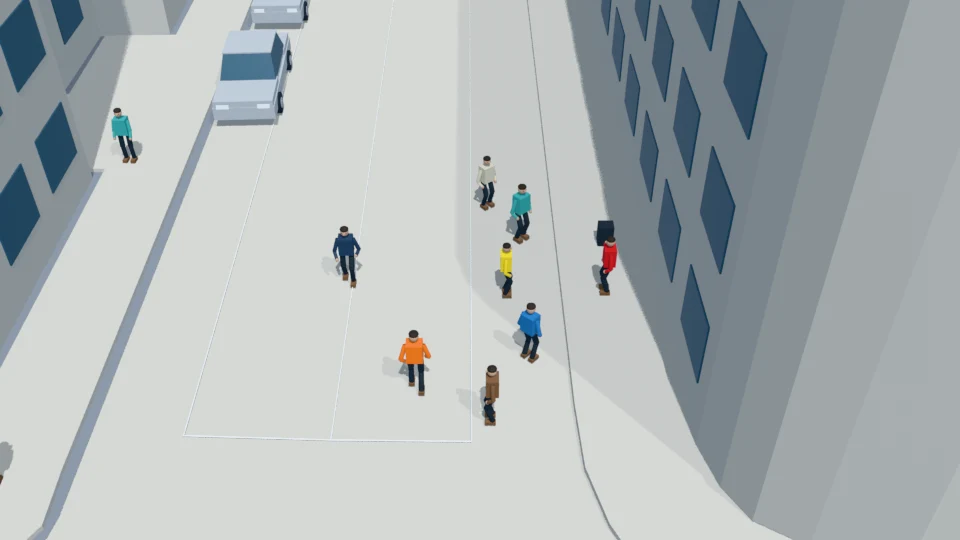
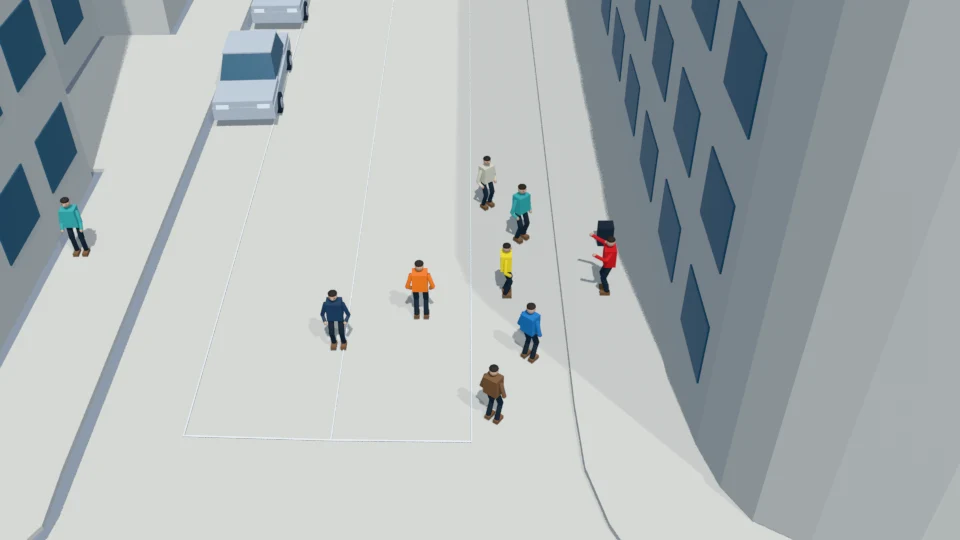
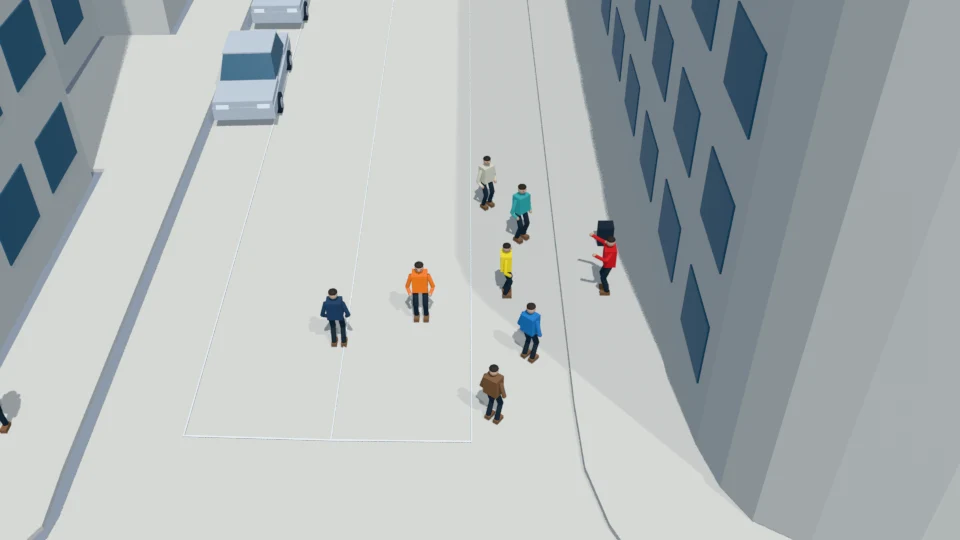
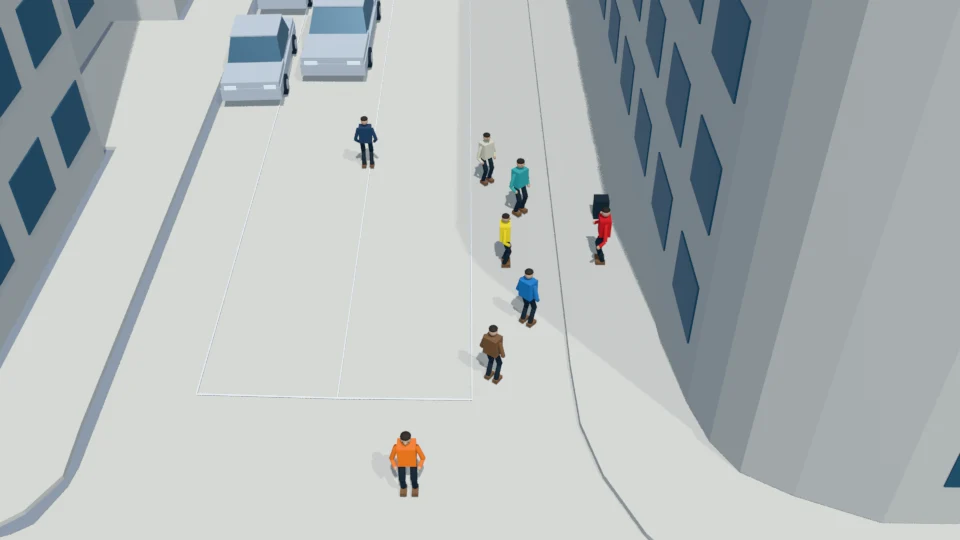
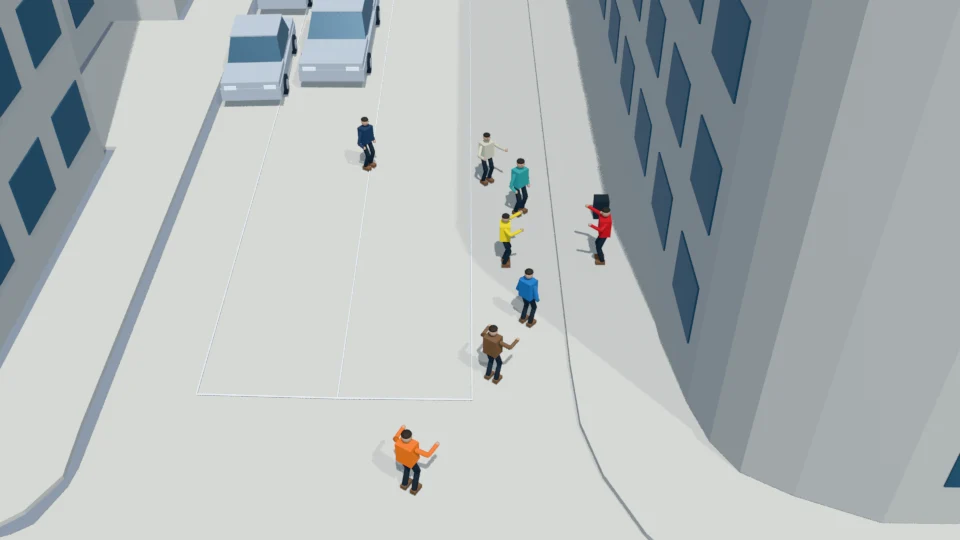
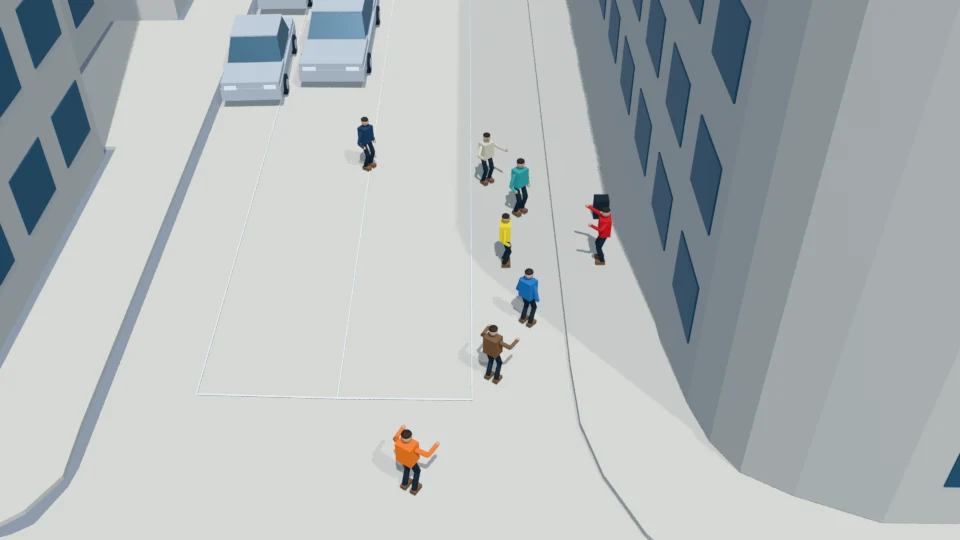
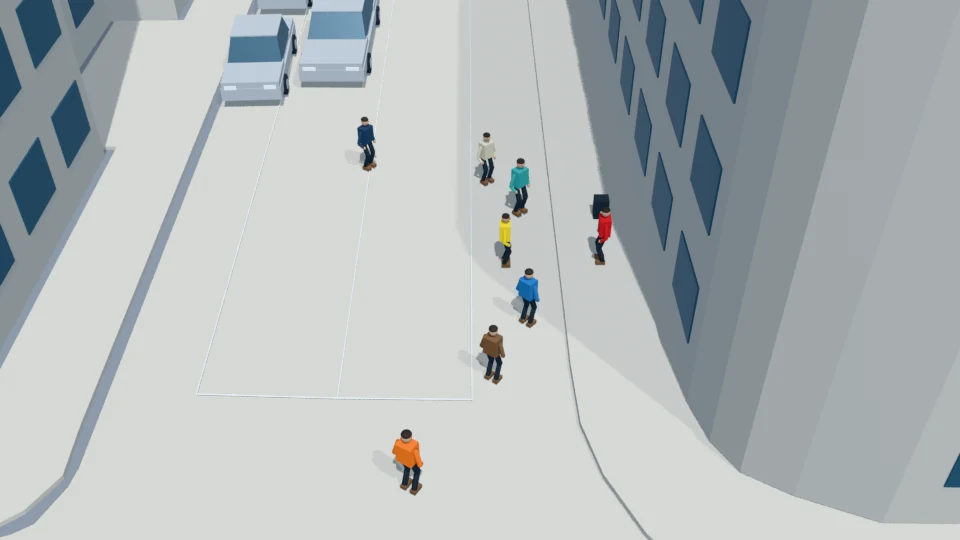
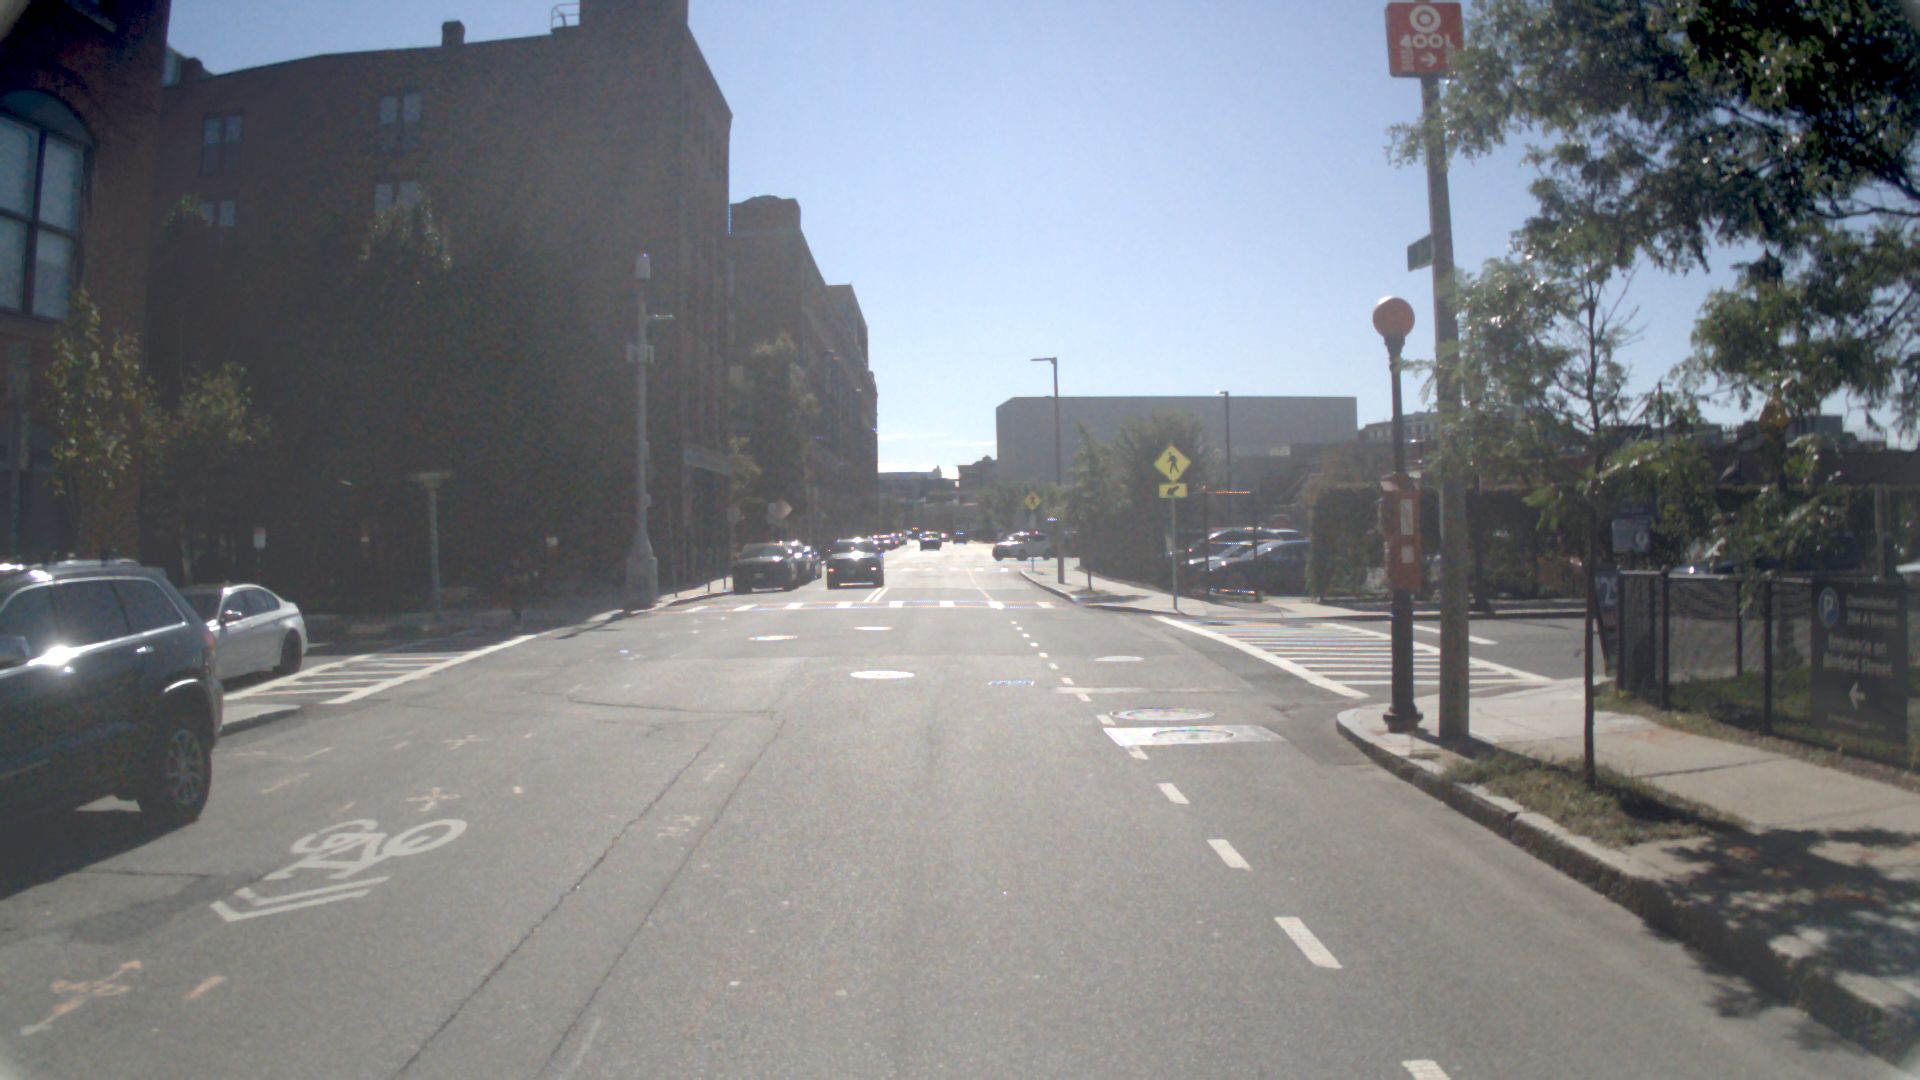
Original NAVSIM camera context
4 conflicting background vehicles were moved to clear holding positions for this counterfactual rehearsal. Original photos remain unchanged. Before later inpainting, any overlap with original-photo traffic must be resolved. Background positions in this 3D rehearsal are not an exact replay of the photographs.
After scene approval
The working pipeline will edit each original NAVSIM camera photograph with Image 2.5. Its same-time Higgsfield view will provide position and posture, annotated with facing direction and current speed. Temporal image requests will cover the full event with a 1 Hz base plus critical moments.
Assumptions and source provenance
- Image 4 supplies the intersection, roadside buildings and sidewalk context. No street performance or crowd is claimed to be observed.
- The unspecified gathering is instantiated as one adult performer and seven adult spectators. A single battery speaker supplies a modest performance prop.
- The south sidewalk near x=39..46 occupies approximately y=-5.3..-3.1. The approach includes a normal curb step; detailed curb geometry requires human review.
- Ego is implicit: it starts at x=0, y=0 at -7 seconds at 6 m/s, decelerates at 1.5 m/s squared to x=12 at -3 seconds, and stays stopped.
- All standing and walking roots use z=0 above the mapped surface. In-place gestures do not translate body roots or create a repeating animation cycle.
- Any later Image 2.5 edit must use original Image 4 after human approval, preserving its architecture and using the rehearsal only for actor positions and postures. Retained background traffic requires an overlap review.
Fresh GPT-6 motion plans use semantic descriptions from the pinned consolidated catalog and NAVSIM environments. No upstream nuPlan vectors, trajectories or images are used. The four source environments are reused; 82 scenario descriptions do not mean 82 independent locations.
Higgsfield revision 2. The portable GLB combines export clips without changing geometry or animation samples.
This review uses Higgsfield revision 2 and the exact exported scene snapshot.
Higgsfield workspace (latest revision) · Download animated GLB · GPT-6 scene plan · Visual review evidence · Motion checks · Approval status