MARSAD / CONSOLIDATED CATALOG / #007
Officer alternates pedestrian and vehicle passage
Awaiting your 3D scene approvalCounterfactual traffic control at the mapped intersection: one officer admits two pedestrians, releases four cars, then admits a second pedestrian pair. Ego remains stopped until both pedestrian phases finish and its corridor is clear.
Original description: 前方有警察站在路口中央,通过手势组织行人通行并指挥交通,行人与车辆在指挥下交替通过
Loading the full animated scene…
Critical moments
What to verify
- Require exactly one officer, four pedestrian actors and four non-ego cars, with persistent identities throughout all 941 inclusive playback samples.
- Verify the officer stands inside the mapped intersection and pedestrian endpoints lie inside the windblown sidewalk polygons.
- Verify all four cars remain stopped from -4 through 6 seconds, and every car footprint clears the pedestrian crossing before 16 seconds.
- Require non-overlapping vehicle footprints and at least 0.6 metres of ordinary pedestrian body clearance.
- Verify ego is stopped at x=12 by -5 seconds and ignores the intermediate vehicle release; its release is not earlier than 28 seconds.
- At ego release, require the swept corridor x=12..55 and |y|<=1.25 to be clear of pedestrians, officer and obstructing vehicles.
- Human approval of the full rehearsal, including -2, 6, 23, 28 and 40 seconds, is required before image generation.
Review notes
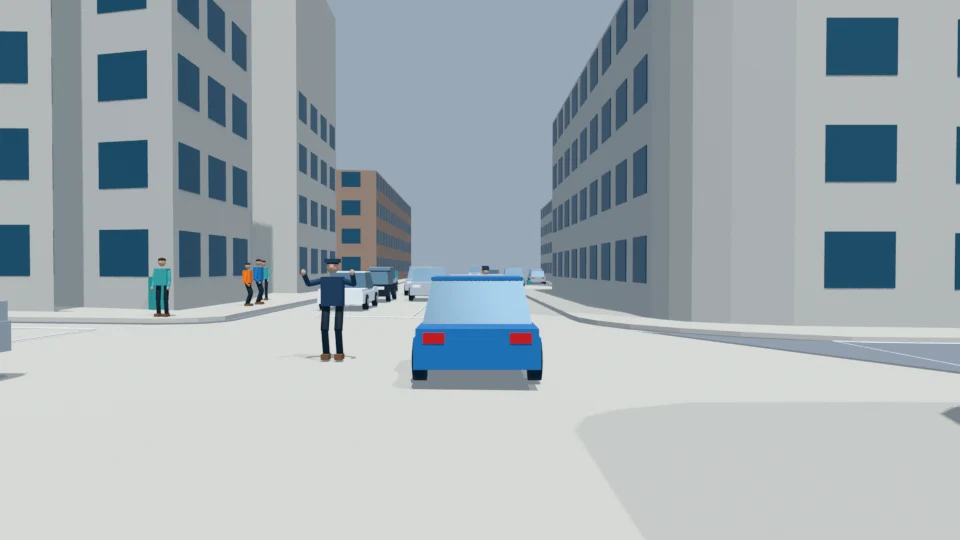
Reviewed officer-controlled intersection and traffic movement across the full episode. Officer, stopped queue, released vehicles and waiting pedestrians remain distinguishable. Wide framing is needed for later traffic movement; native front view shows the officer and first queue.
Check action, relative position, facing, posture and visibility. Approximate offsets are acceptable. Sampled visual checks do not prove every contact or continuous collision clearance.
Rendered inspection views
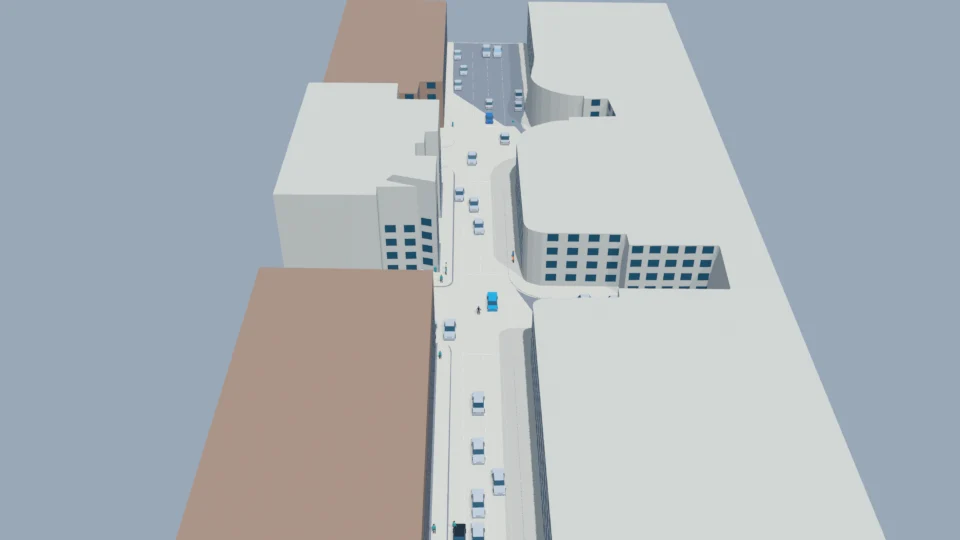
Event, approach and final views rendered from the exact committed Higgsfield Blender source. These are procedural 3D previews, not generated training photographs.
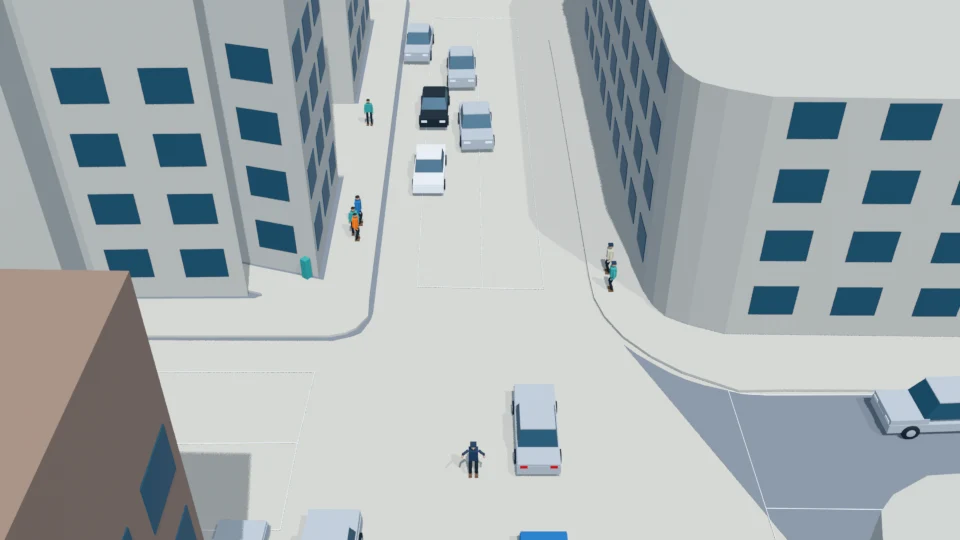
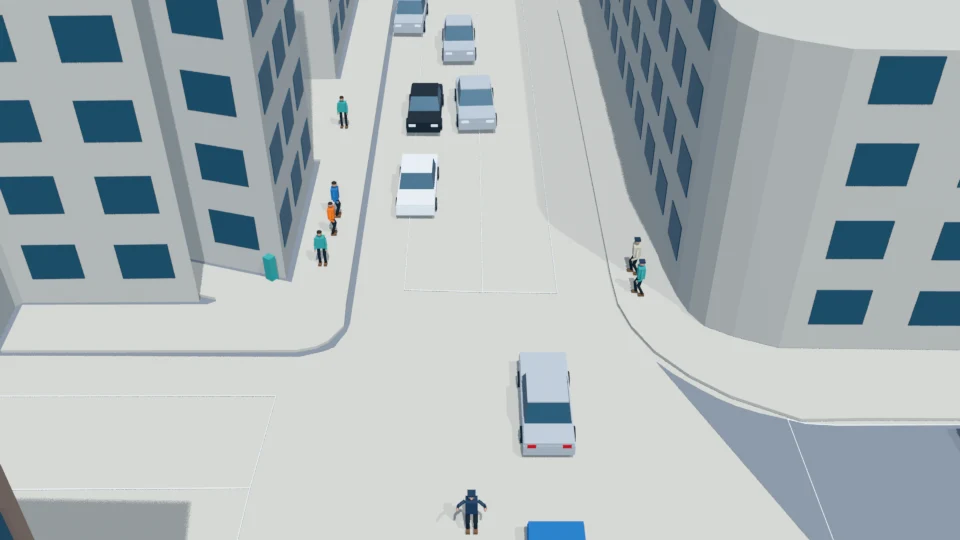
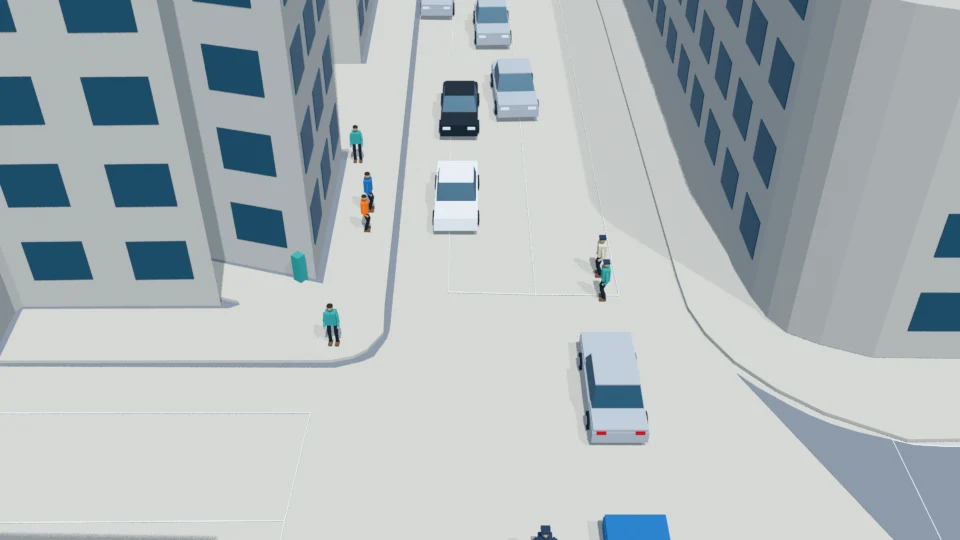
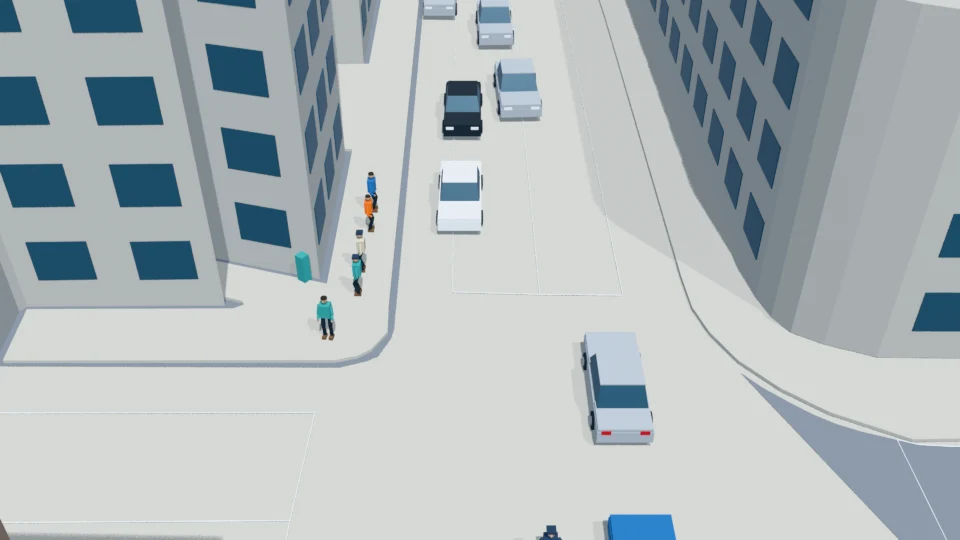
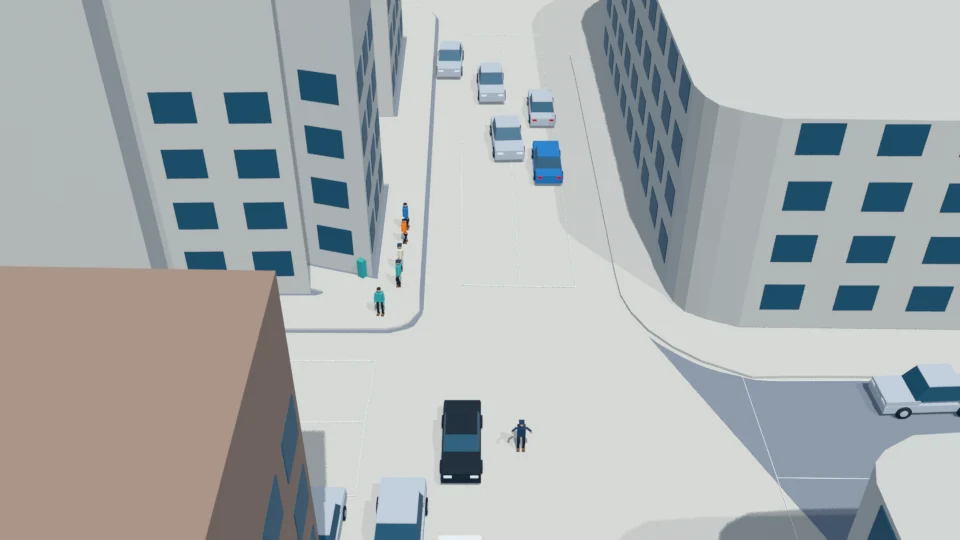
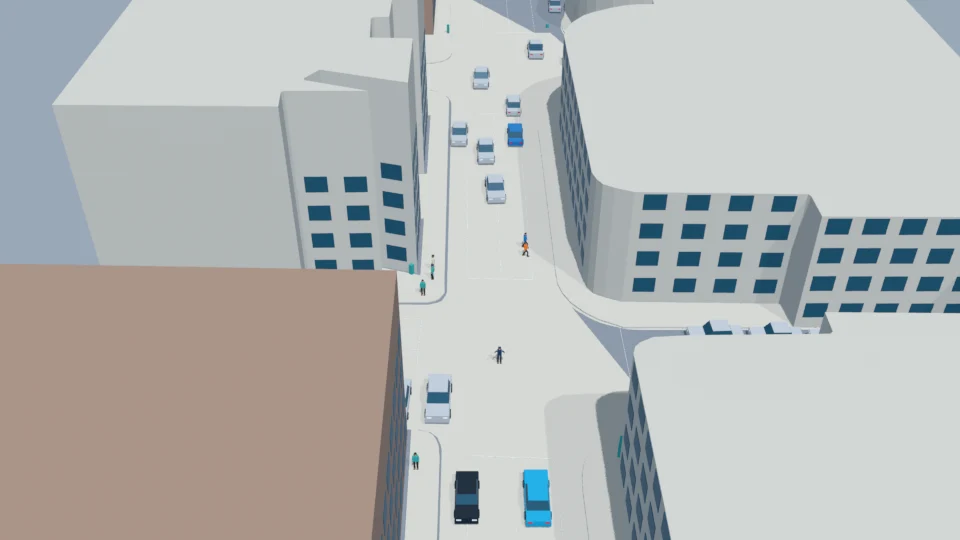
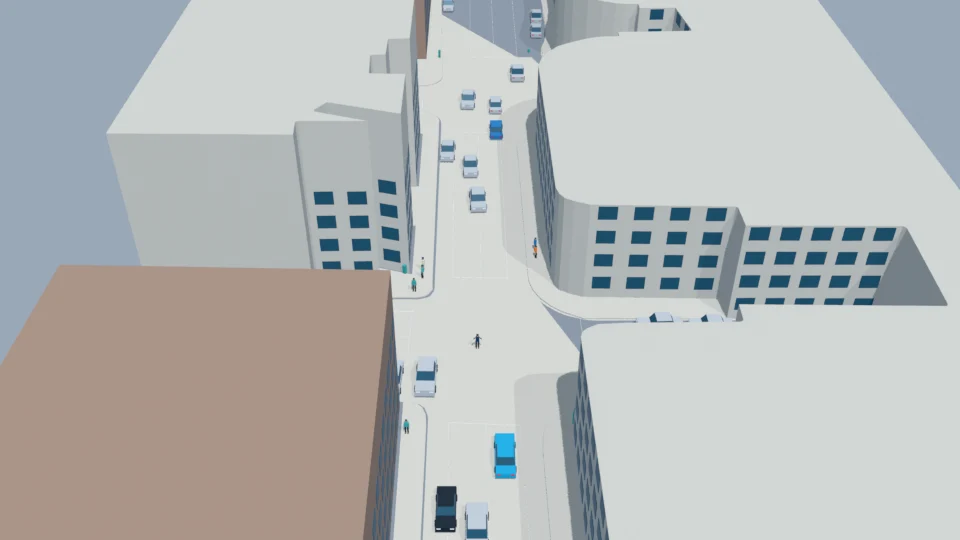
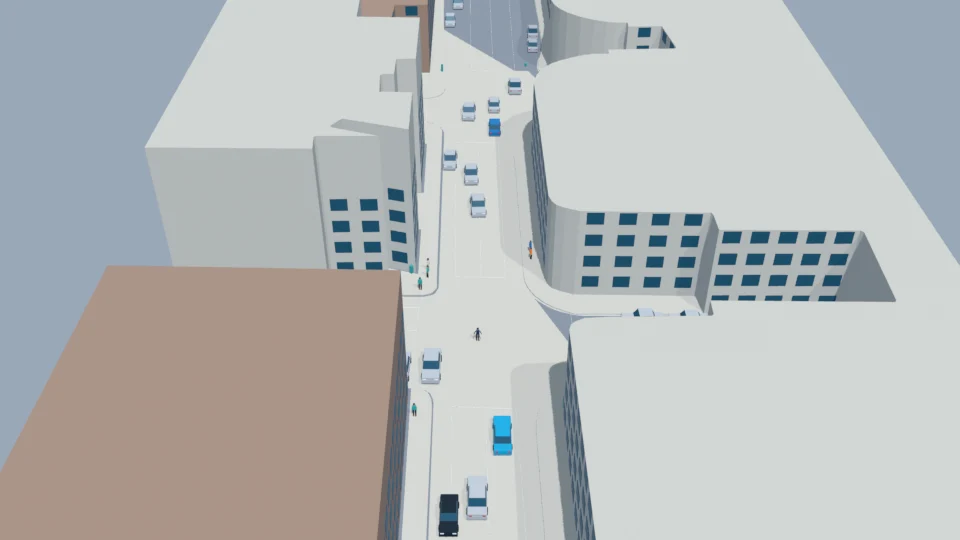
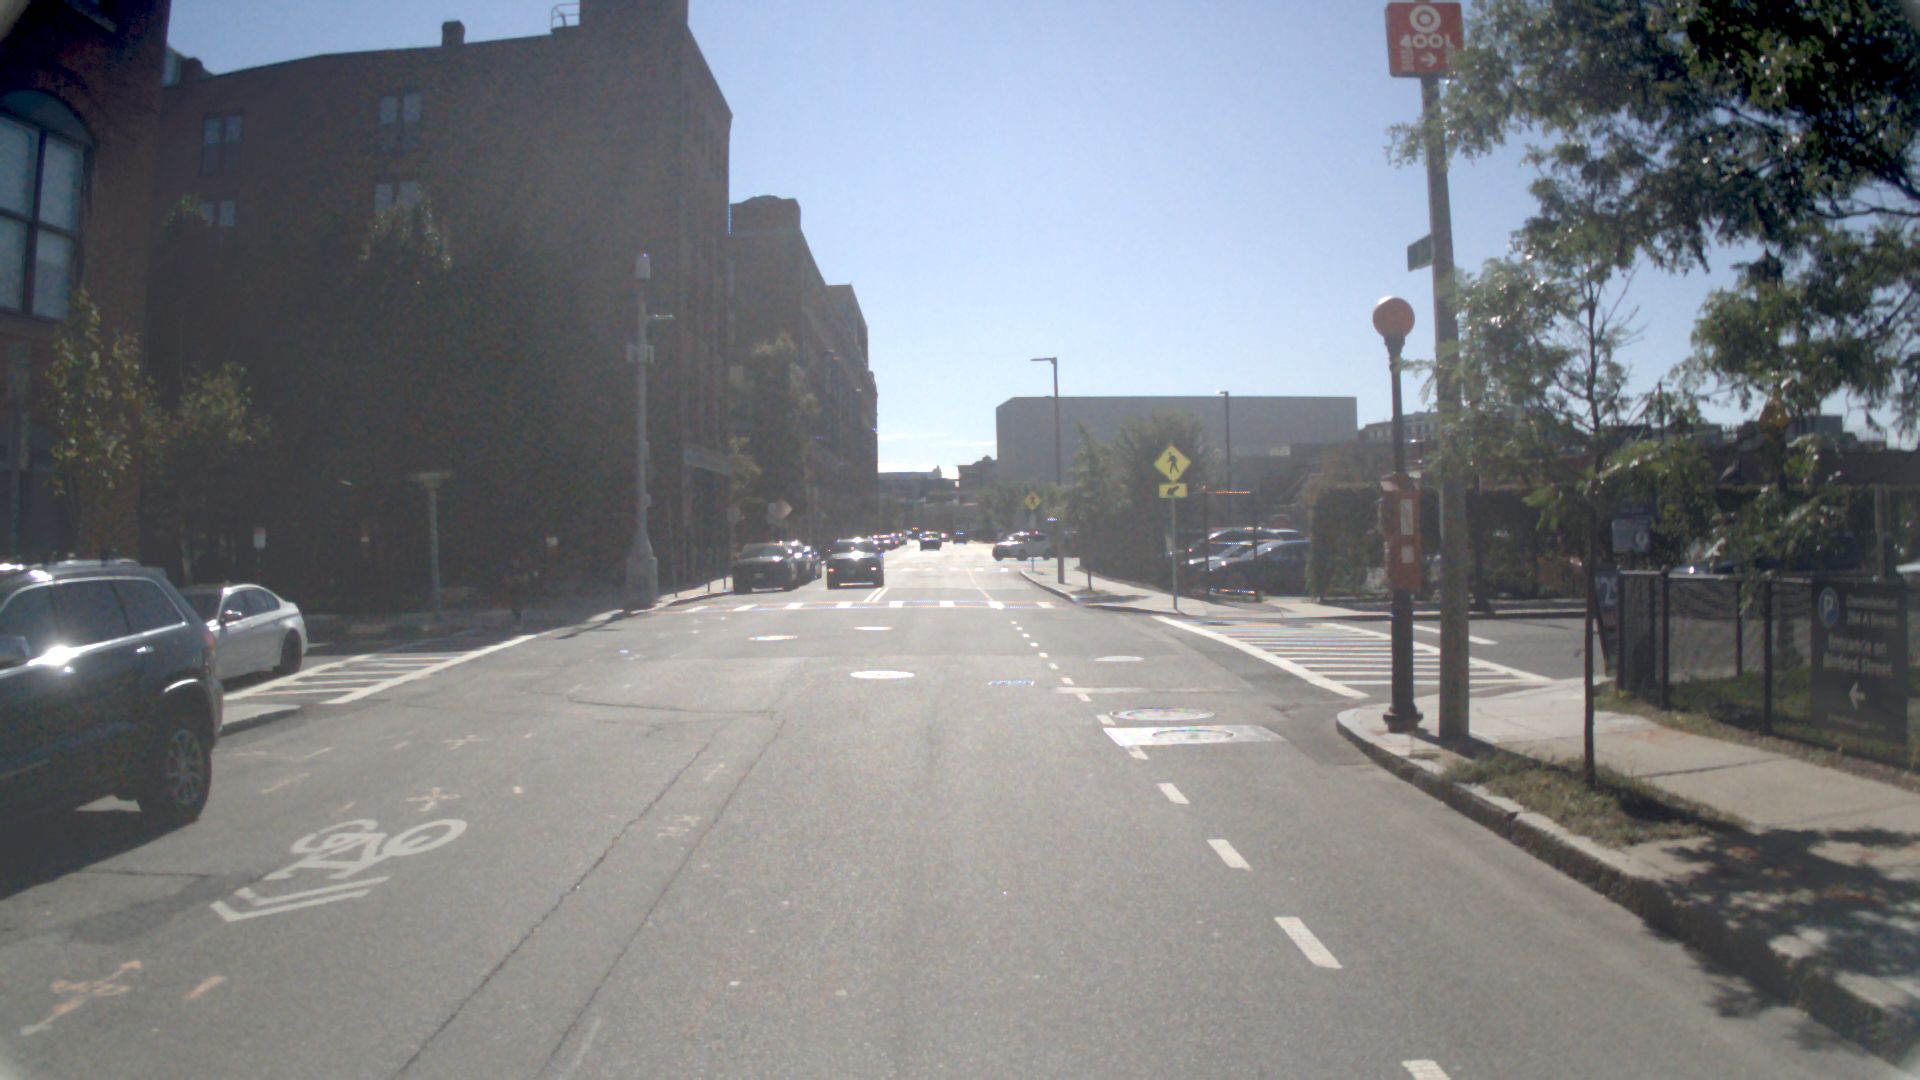
Original NAVSIM camera context
15 conflicting background vehicles were moved to clear holding positions for this counterfactual rehearsal. Original photos remain unchanged. Before later inpainting, any overlap with original-photo traffic must be resolved. Background positions in this 3D rehearsal are not an exact replay of the photographs.
After scene approval
The working pipeline will edit each original NAVSIM camera photograph with Image 2.5. Its same-time Higgsfield view will provide position and posture, annotated with facing direction and current speed. Temporal image requests will cover the full event with a 1 Hz base plus critical moments.
Assumptions and source provenance
- The supplied windblown map provides the intersection near x=27 and its east-arm sidewalks. Image 4 supplies architectural context; the officer, traffic phases and all listed actors are counterfactual proposals, not observed events.
- World time is -7..40 seconds at 20 Hz, yielding 941 inclusive samples. Playback is finite and non-looping; z=0 means support on the mapped ground surface.
- The unspecified traffic is instantiated as exactly four modest cars, excluding separately controlled ego. Pedestrian traffic is instantiated as two distinct pairs.
- Cars decelerate from approximately 3 m/s to rest during -7..-4, accelerate from rest to 3 m/s during 6..9, then ease to 2 m/s during 15..18 and continue at that speed. Interpolation must respect these profiles without overshoot.
- Pedestrian travel averages 1.27 m/s, with short eased starts and stops bounded by 1.7 m/s. The stop signal at 15 seconds prevents new entrants; vehicles already through the crossing continue away.
- Signal arm direction and rendered role labels distinguish the four-car release from ego's later release. Ego's post-release speed is limited to 3 m/s.
- Human review is pending. After approval, Image 2.5 must edit original Image 4, preserving its architecture and using this rehearsal only for placement and posture; the review cursor is not an approval.
Fresh GPT-6 motion plans use semantic descriptions from the pinned consolidated catalog and NAVSIM environments. No upstream nuPlan vectors, trajectories or images are used. The four source environments are reused; 82 scenario descriptions do not mean 82 independent locations.
Higgsfield revision 2. The portable GLB combines export clips without changing geometry or animation samples.
This review uses Higgsfield revision 2 and the exact exported scene snapshot.
Higgsfield workspace (latest revision) · Download animated GLB · GPT-6 scene plan · Visual review evidence · Motion checks · Approval status