MARSAD / CONSOLIDATED CATALOG / #008
Low-speed two-car collision with resident onlookers
Awaiting your 3D scene approvalCounterfactual low-speed rear-end contact occurs at time zero. Two cars settle in the ego corridor while six residents approach from both sidewalks and gather around them. The obstruction remains through 40 seconds.
Original description: 前方两辆车发碰撞,周围有多个居民围观,堵塞道路
Loading the full animated scene…
Critical moments
What to verify
- Require exactly two collision cars and six resident onlookers; retain every actor from -7 through 40 seconds.
- At t=0 require tangent front-to-rear bumper contact at x=36.3, with no footprint overlap before or after contact.
- Require pre-contact closing speed near 0.4 m/s, a shared forward displacement of 0.25 metres, and no motion after 1.5 seconds.
- Verify residents do not leave their starting sidewalks until 2 seconds and never cross a car footprint.
- At 20 Hz verify ordinary people remain at least 0.6 metres apart and that all approach paths remain on mapped road or sidewalk surfaces.
- Require the cars to continue blocking |y|<=1.25 through 40 seconds; ego stays at x=12 with no release or invented recovery.
- Human review must approve the contact frame, shared settling motion and final crowd arrangement before any image generation.
Review notes
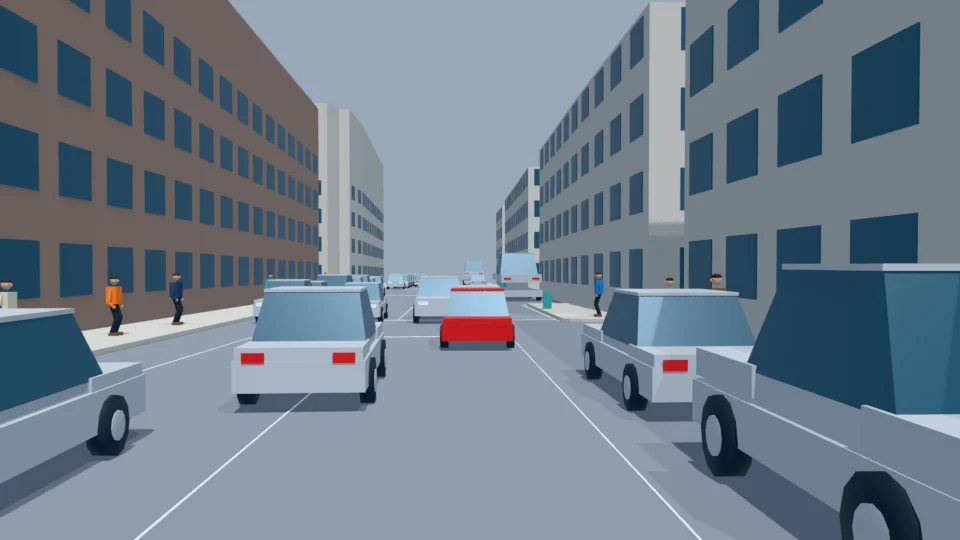
Reviewed rear-end collision sequence and onlookers. Red trailing car approaches the stopped vehicle and remains at the intended collision point. Bystanders approach and gesture after the collision; the contact is intentional and ego remains stopped.
Check action, relative position, facing, posture and visibility. Approximate offsets are acceptable. Sampled visual checks do not prove every contact or continuous collision clearance.
Rendered inspection views
Event, approach and final views rendered from the exact committed Higgsfield Blender source. These are procedural 3D previews, not generated training photographs.
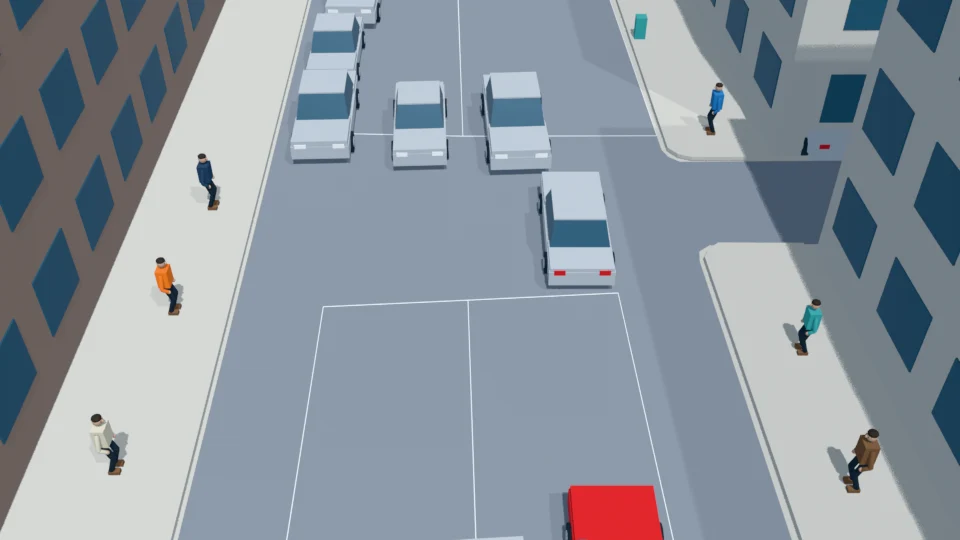
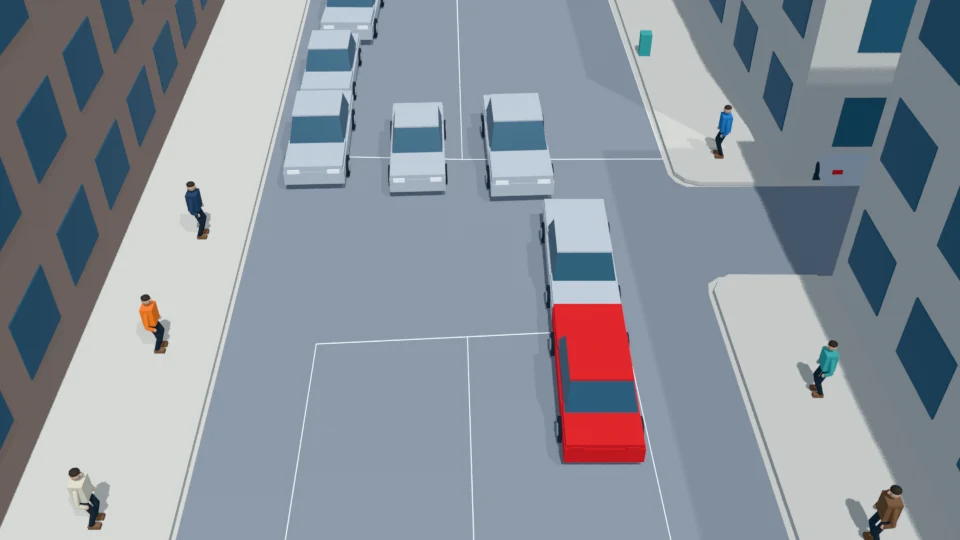
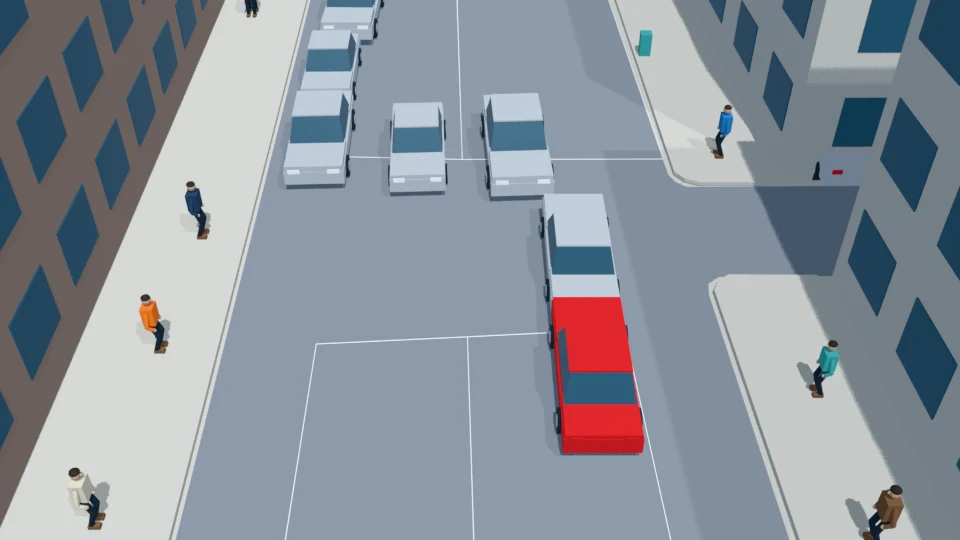
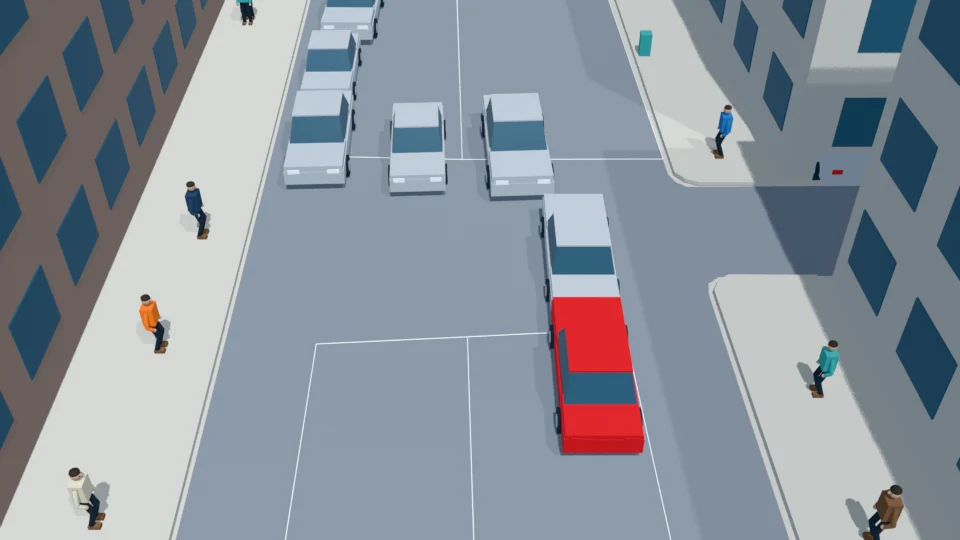
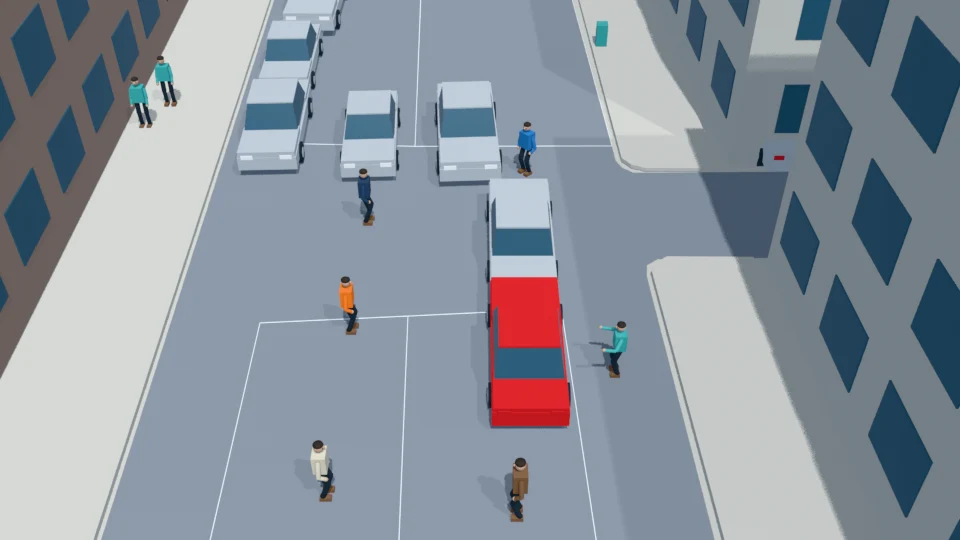
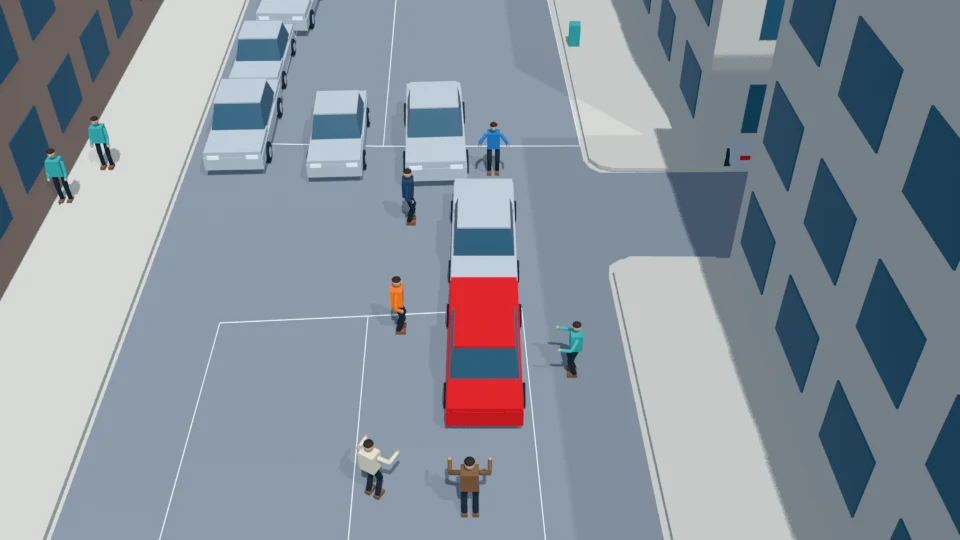
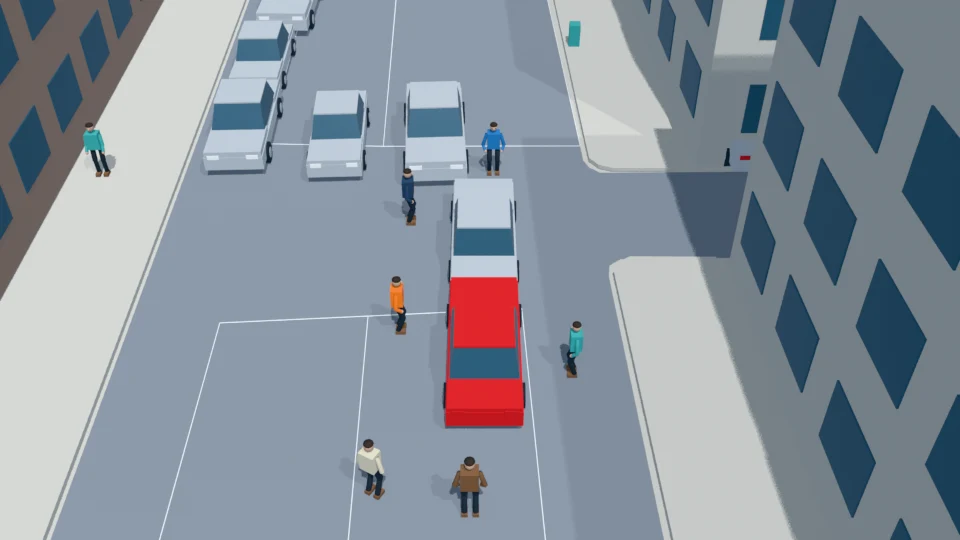
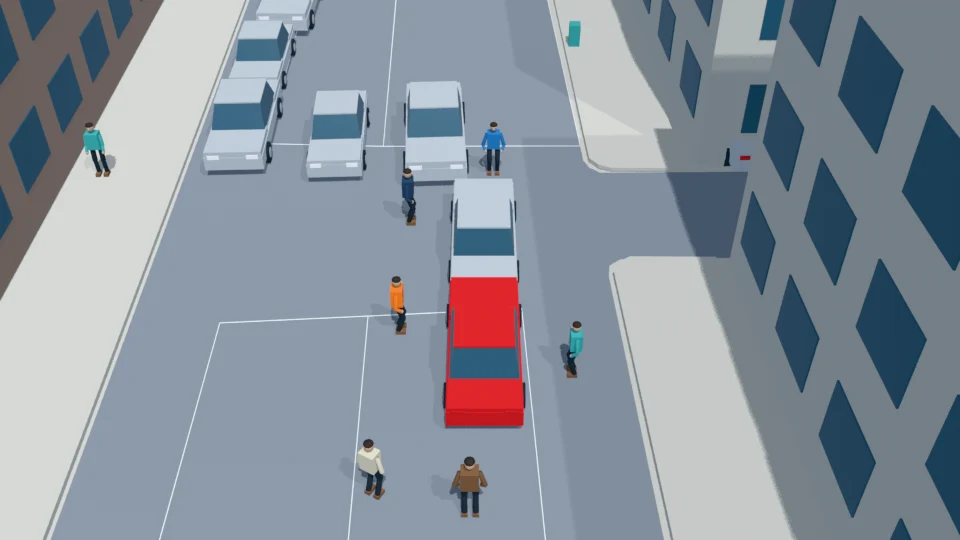
Original NAVSIM camera context
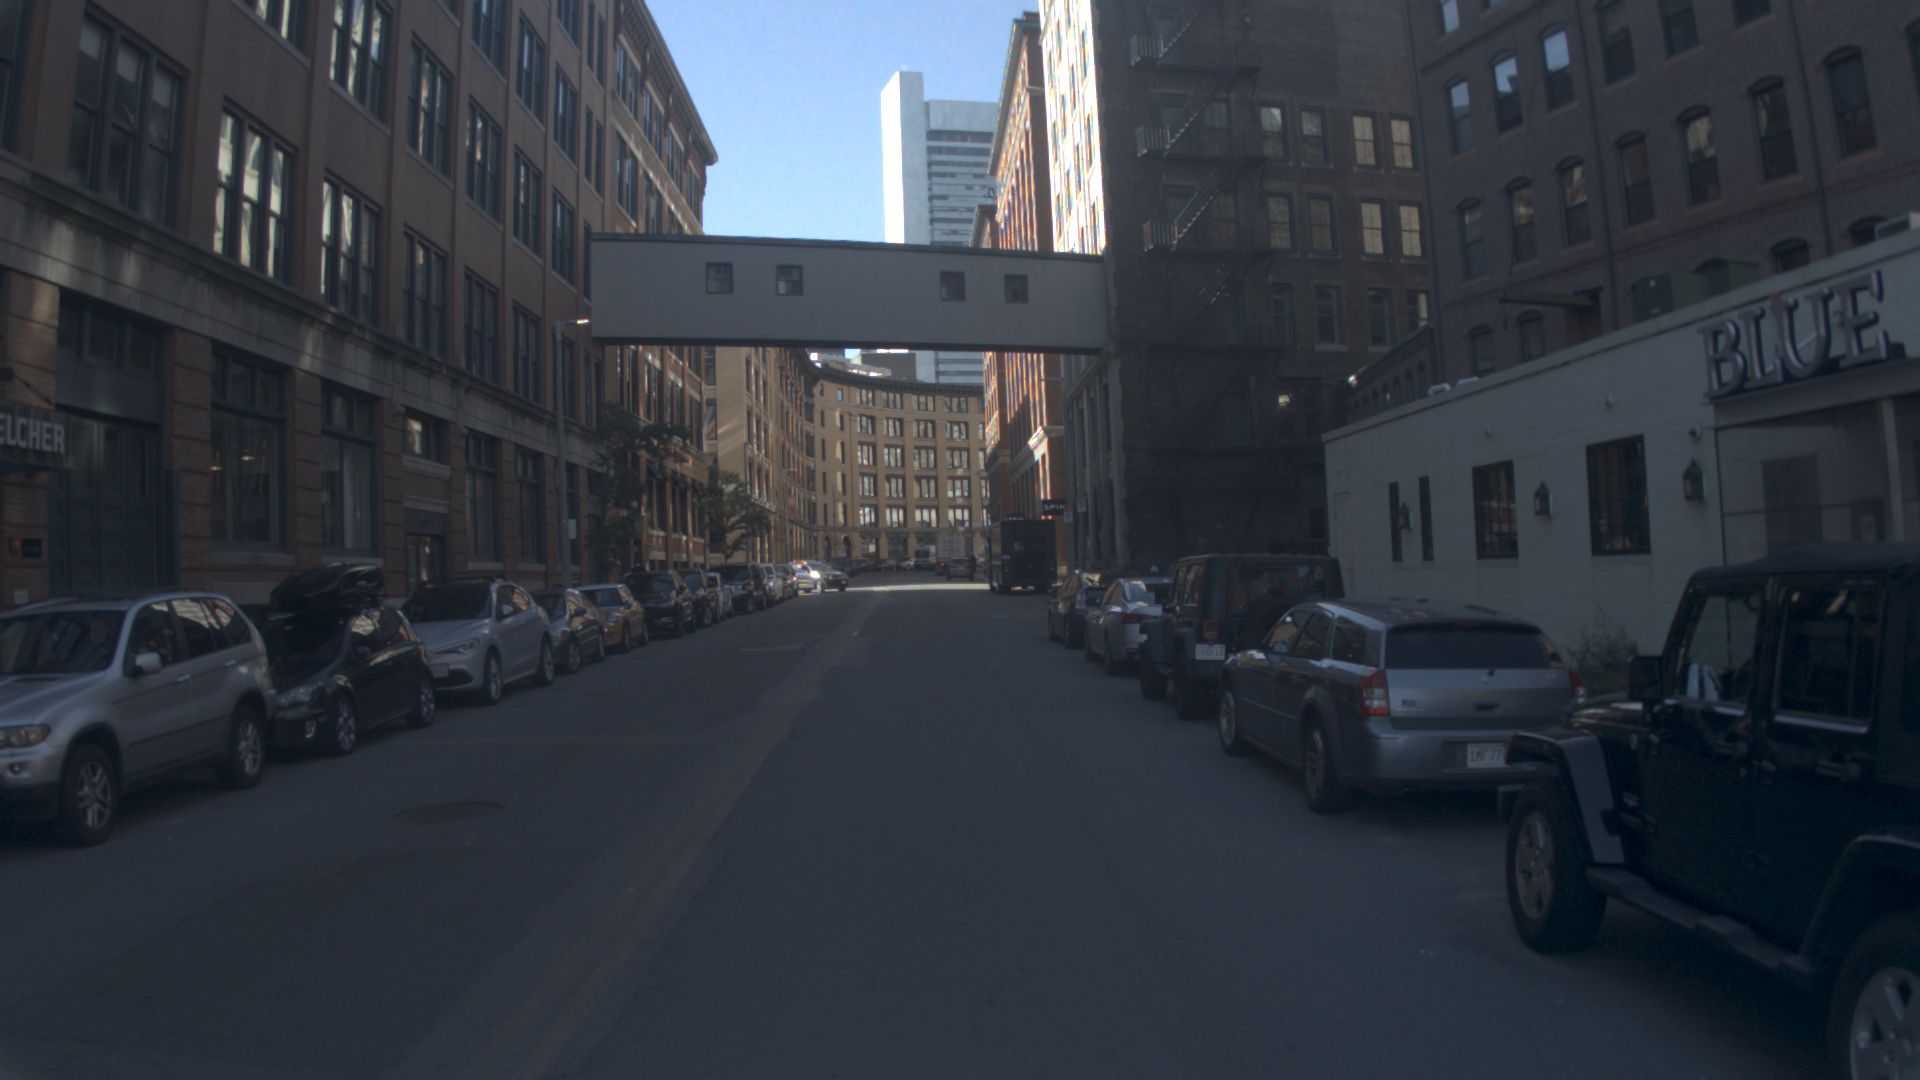
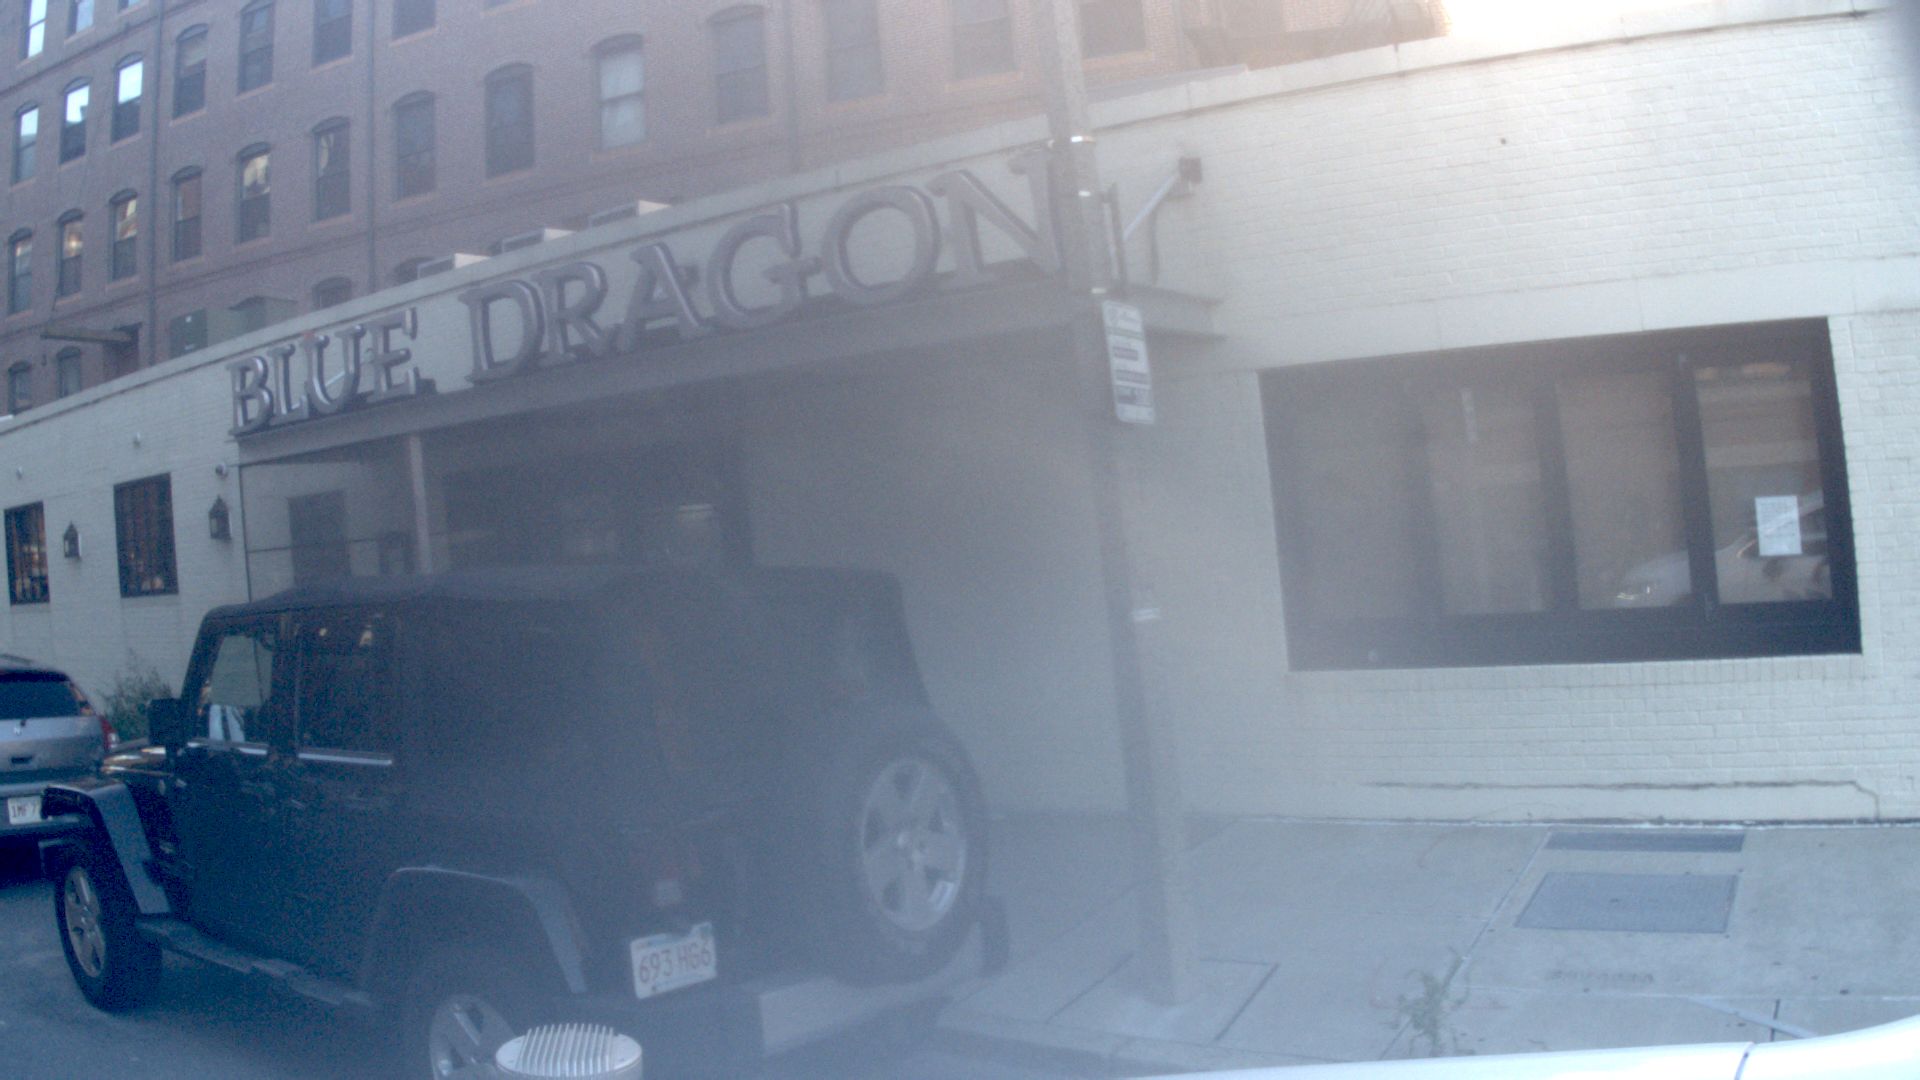
5 conflicting background vehicles were moved to clear holding positions for this counterfactual rehearsal. Original photos remain unchanged. Before later inpainting, any overlap with original-photo traffic must be resolved. Background positions in this 3D rehearsal are not an exact replay of the photographs.
After scene approval
The working pipeline will edit each original NAVSIM camera photograph with Image 2.5. Its same-time Higgsfield view will provide position and posture, annotated with facing direction and current speed. Temporal image requests will cover the full event with a 1 Hz base plus critical moments.
Assumptions and source provenance
- The police map and Image 2 establish road, sidewalk and building context only. The collision and resident crowd are newly authored counterfactual proposals.
- World time is -7..40 seconds at 20 Hz, with 941 inclusive samples and no loop. All support roots use z=0 relative to mapped ground.
- The request fixes two colliding cars. Six residents instantiate the unspecified multiple onlookers; no additional traffic vehicles are added.
- The lead car is initially stationary. The rear car slows from approximately 1.5 m/s to 0.4 m/s before contact. A modest contact impulse starts a shared 0.2 m/s roll, followed by braking to rest.
- Resident walking segments use approximately 0.9..1.1 m/s with eased starts and stops. Turns occur at stationary keys; pointing does not imply touching or aggression.
- No injuries, debris, emergency response or vehicle removal are proposed. Ego is separately controlled and stopped upstream before contact.
- Precise background-object footprints are not supplied and require human clearance review. After approval, Image 2.5 must edit original Image 2 rather than reconstruct its architecture; no approval or image generation has yet occurred.
Fresh GPT-6 motion plans use semantic descriptions from the pinned consolidated catalog and NAVSIM environments. No upstream nuPlan vectors, trajectories or images are used. The four source environments are reused; 82 scenario descriptions do not mean 82 independent locations.
Higgsfield revision 2. The portable GLB combines export clips without changing geometry or animation samples.
This review uses Higgsfield revision 2 and the exact exported scene snapshot.
Higgsfield workspace (latest revision) · Download animated GLB · GPT-6 scene plan · Visual review evidence · Motion checks · Approval status