MARSAD / CONSOLIDATED CATALOG / #009
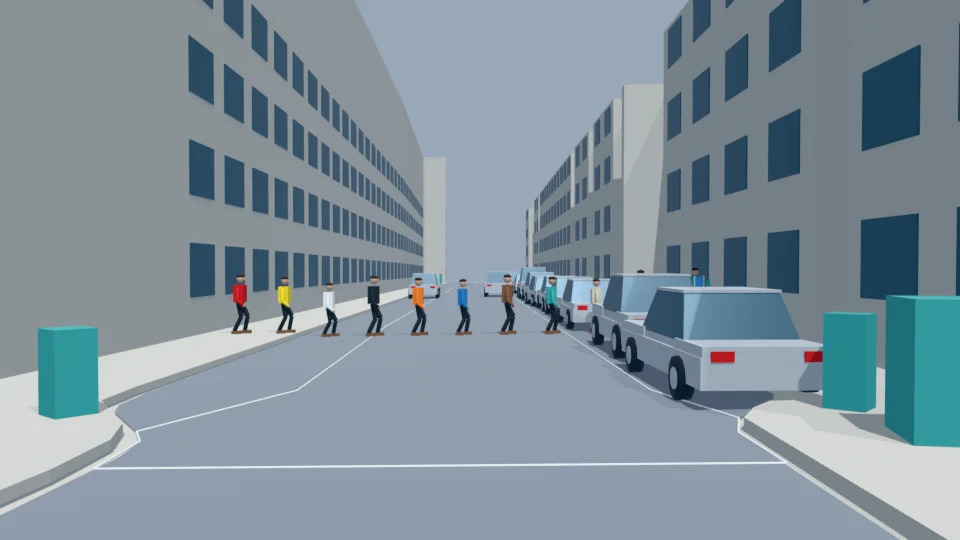
Ten spectators slowly queue toward a southern venue entrance
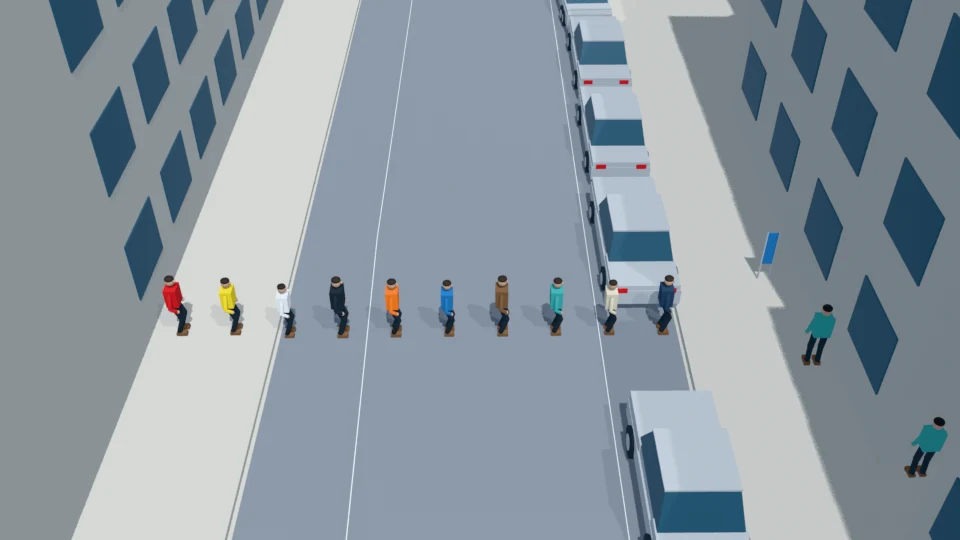
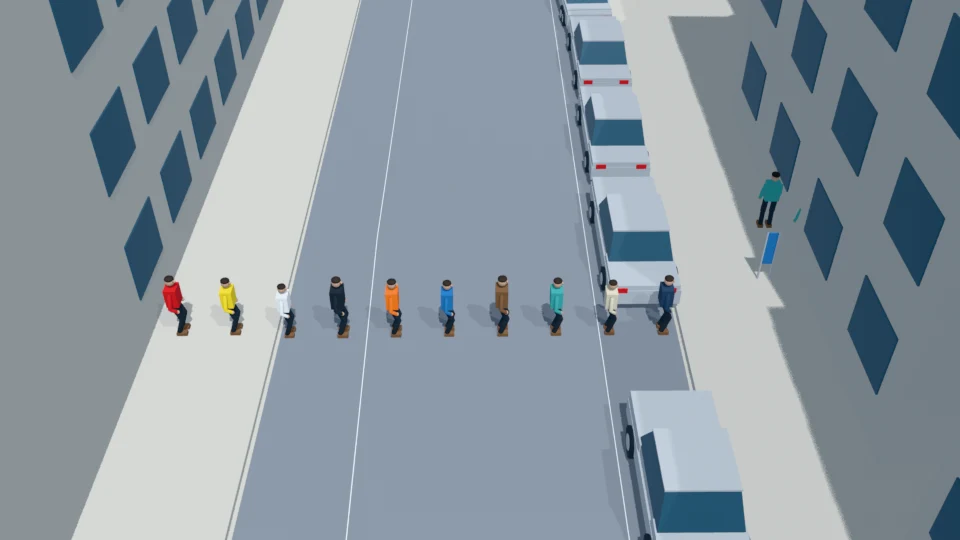
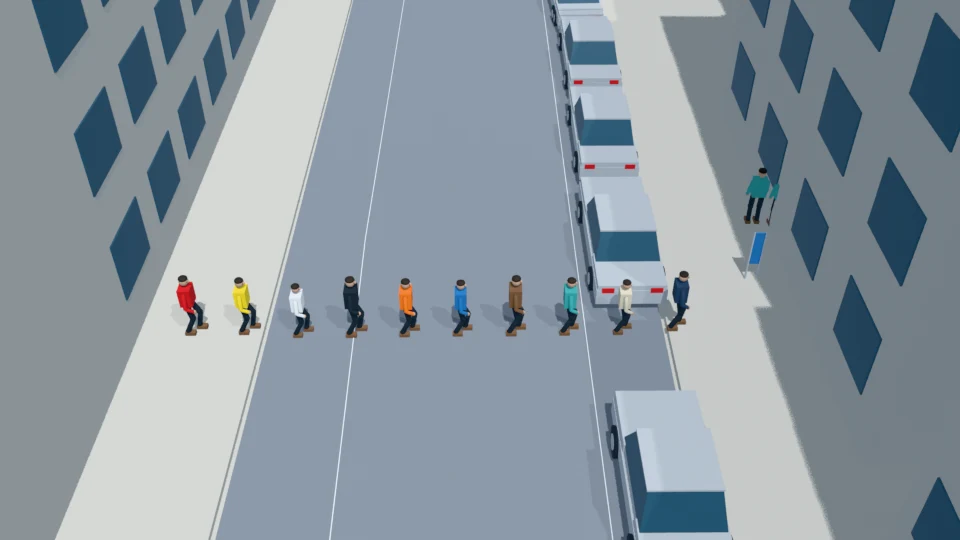
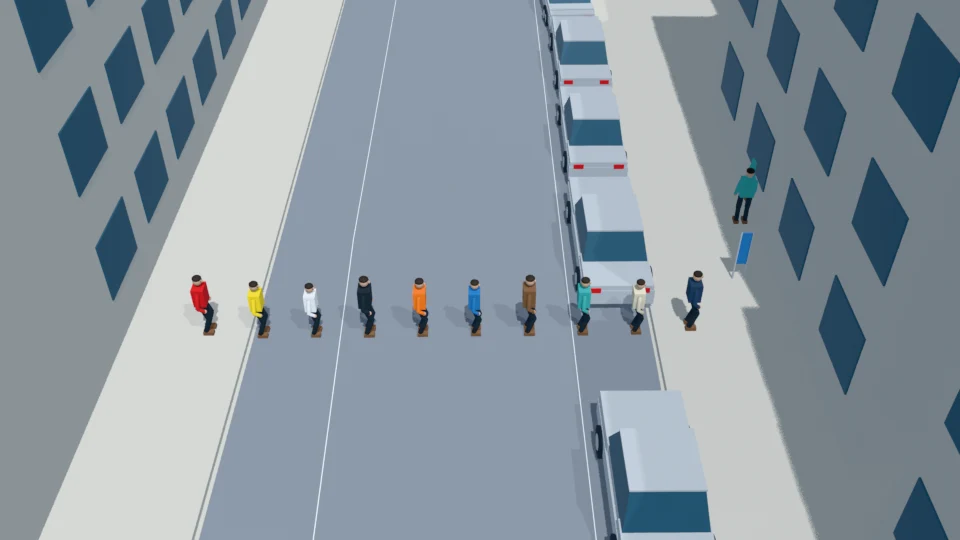
Awaiting your 3D scene approvalCounterfactual single-file queue of exactly ten spectators extends north-south across the road. Two brief southward shuffles produce very slow overall progress toward a proposed southern admission point. The queue still blocks ego at the final state.
Original description: 前方有十个左右的观众在道路上排队等候进场,观众从南到北延伸排成一排,以非常缓慢的速度向南边的场馆入口移动
Loading the full animated scene…
Critical moments
What to verify
- Require exactly ten individually identified spectators and one persistent entrance sign, with no additional queue members.
- At every sample require all spectators to share x=36.2, face south, preserve their order and retain 1.3-metre adjacent center spacing.
- Require total southward displacement of exactly 2.6 metres per spectator; movement occurs only during the two finite advance intervals.
- Verify at least 0.6 metres of body clearance between spectators and no intersection with the sign.
- Verify the queue uses the wheelchair road and adjoining sidewalks rather than treating sidewalk space as roadway.
- Require a spectator footprint to obstruct the ego corridor throughout the rehearsal, including after 22 seconds; ego_release_s remains -1.
- Human review must approve the ten-person count, slow queue behavior, southern admission interpretation and final obstruction before image generation.
Review notes
Reviewed the persistent ten-person queue, its slow progress toward the southern venue entrance, and the native front camera. People remain ordered across the road; parked traffic remains clear of their path. The queue continues to obstruct ego.
Check action, relative position, facing, posture and visibility. Approximate offsets are acceptable. Sampled visual checks do not prove every contact or continuous collision clearance.
Rendered inspection views
Event, approach and final views rendered from the exact committed Higgsfield Blender source. These are procedural 3D previews, not generated training photographs.
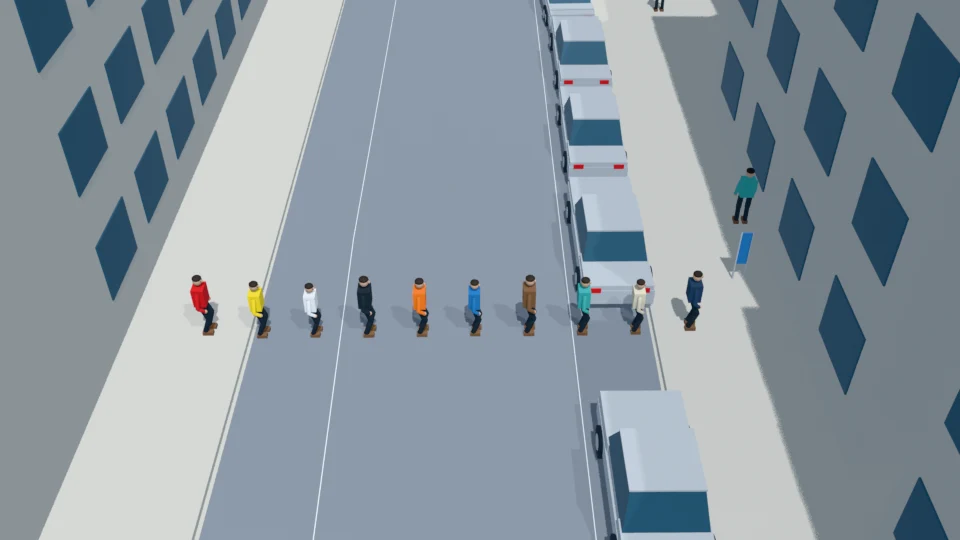
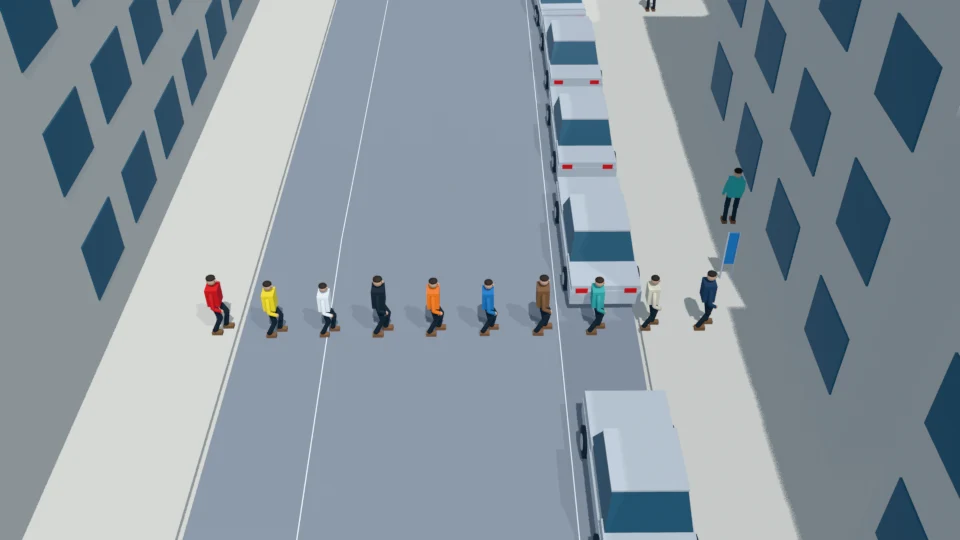
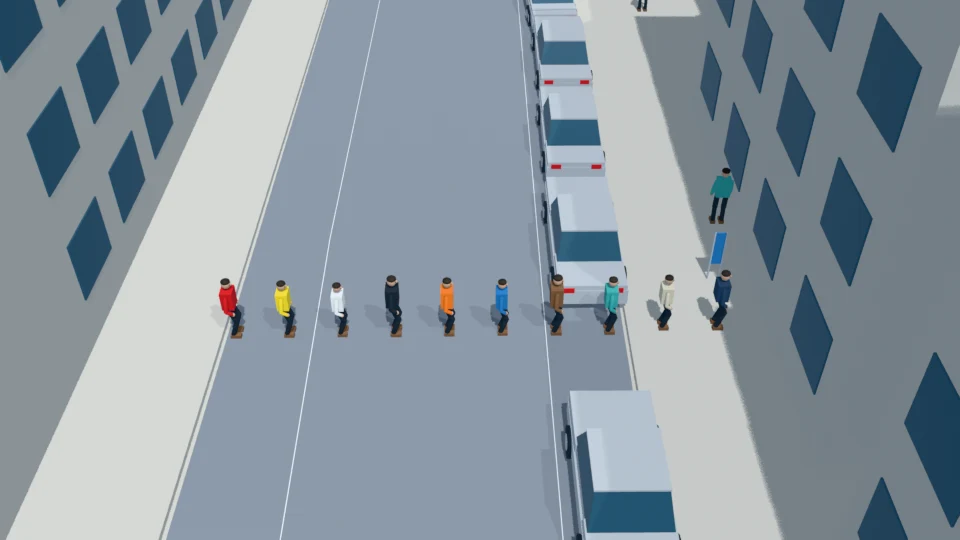
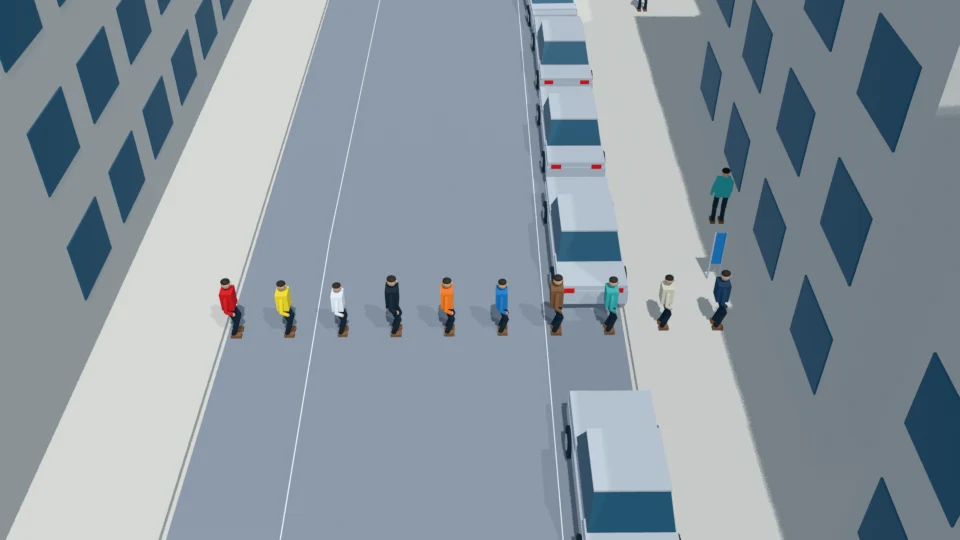
Original NAVSIM camera context
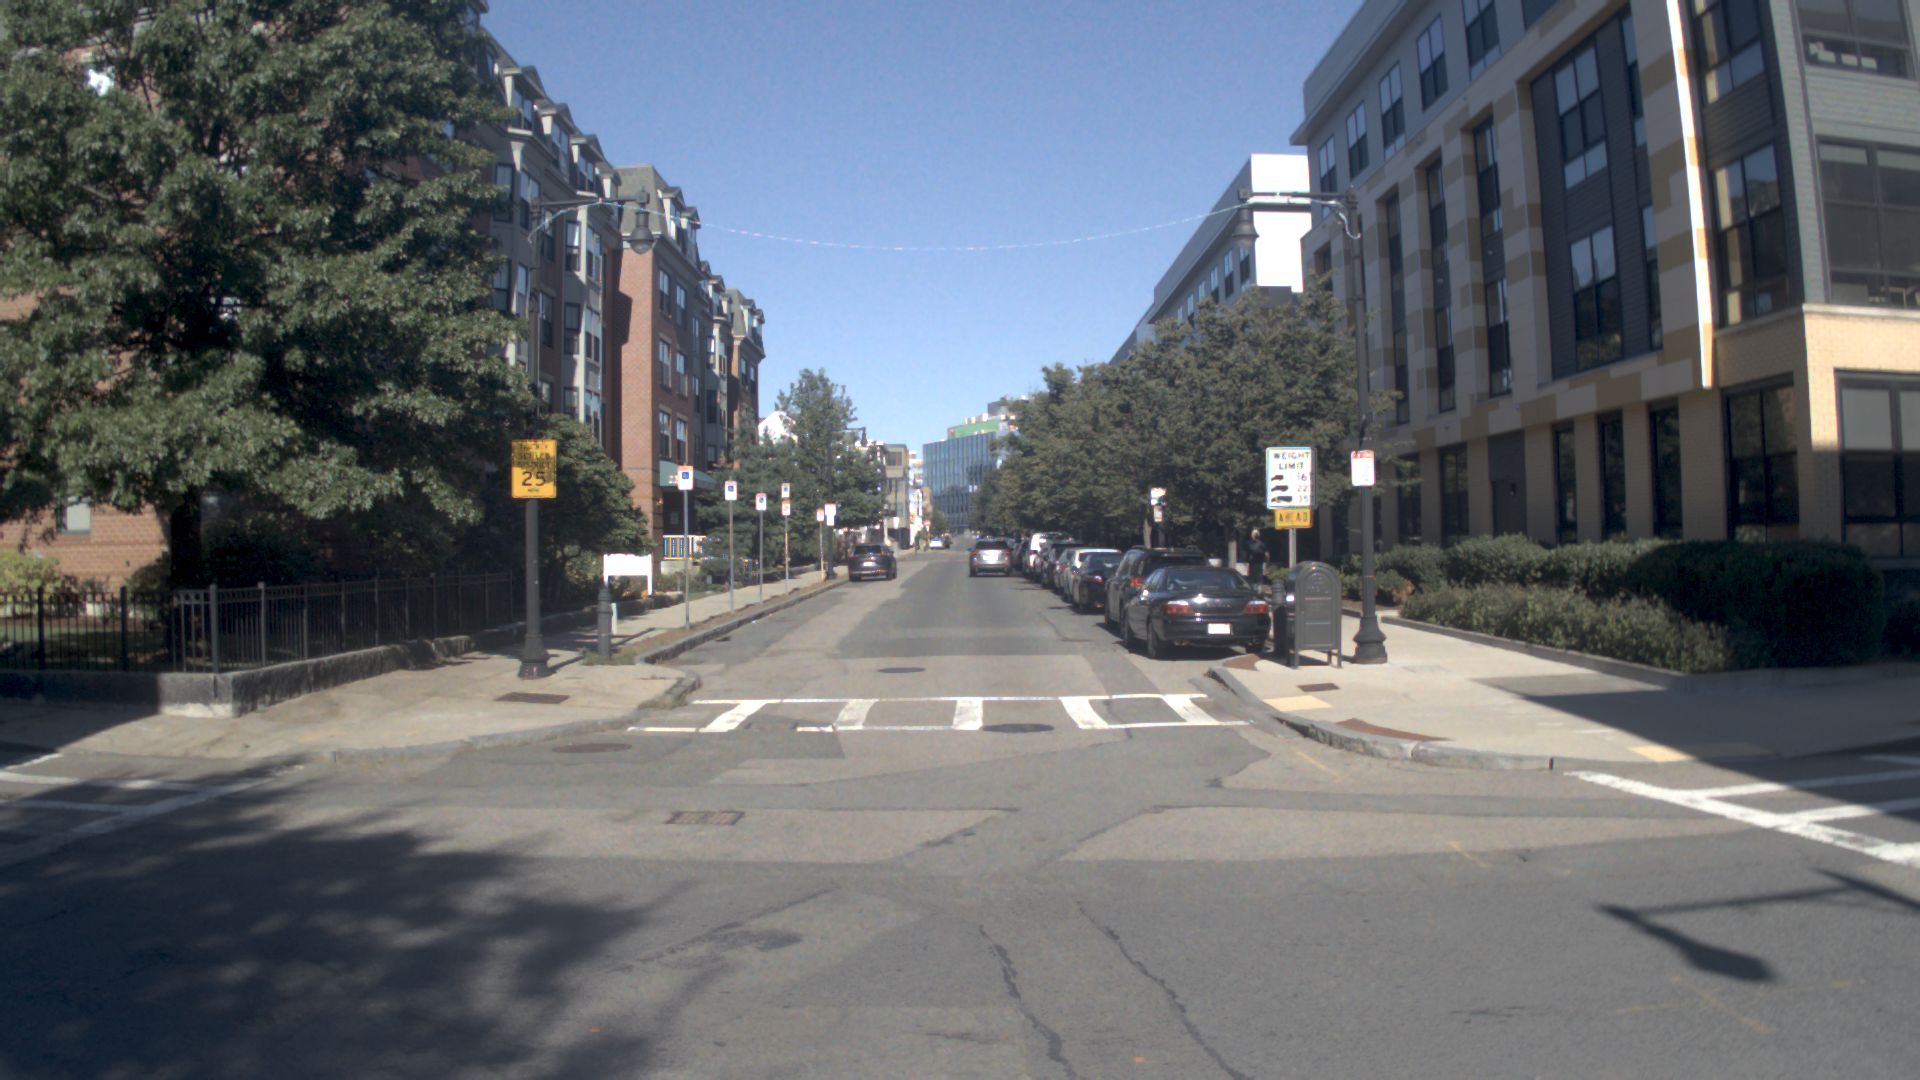
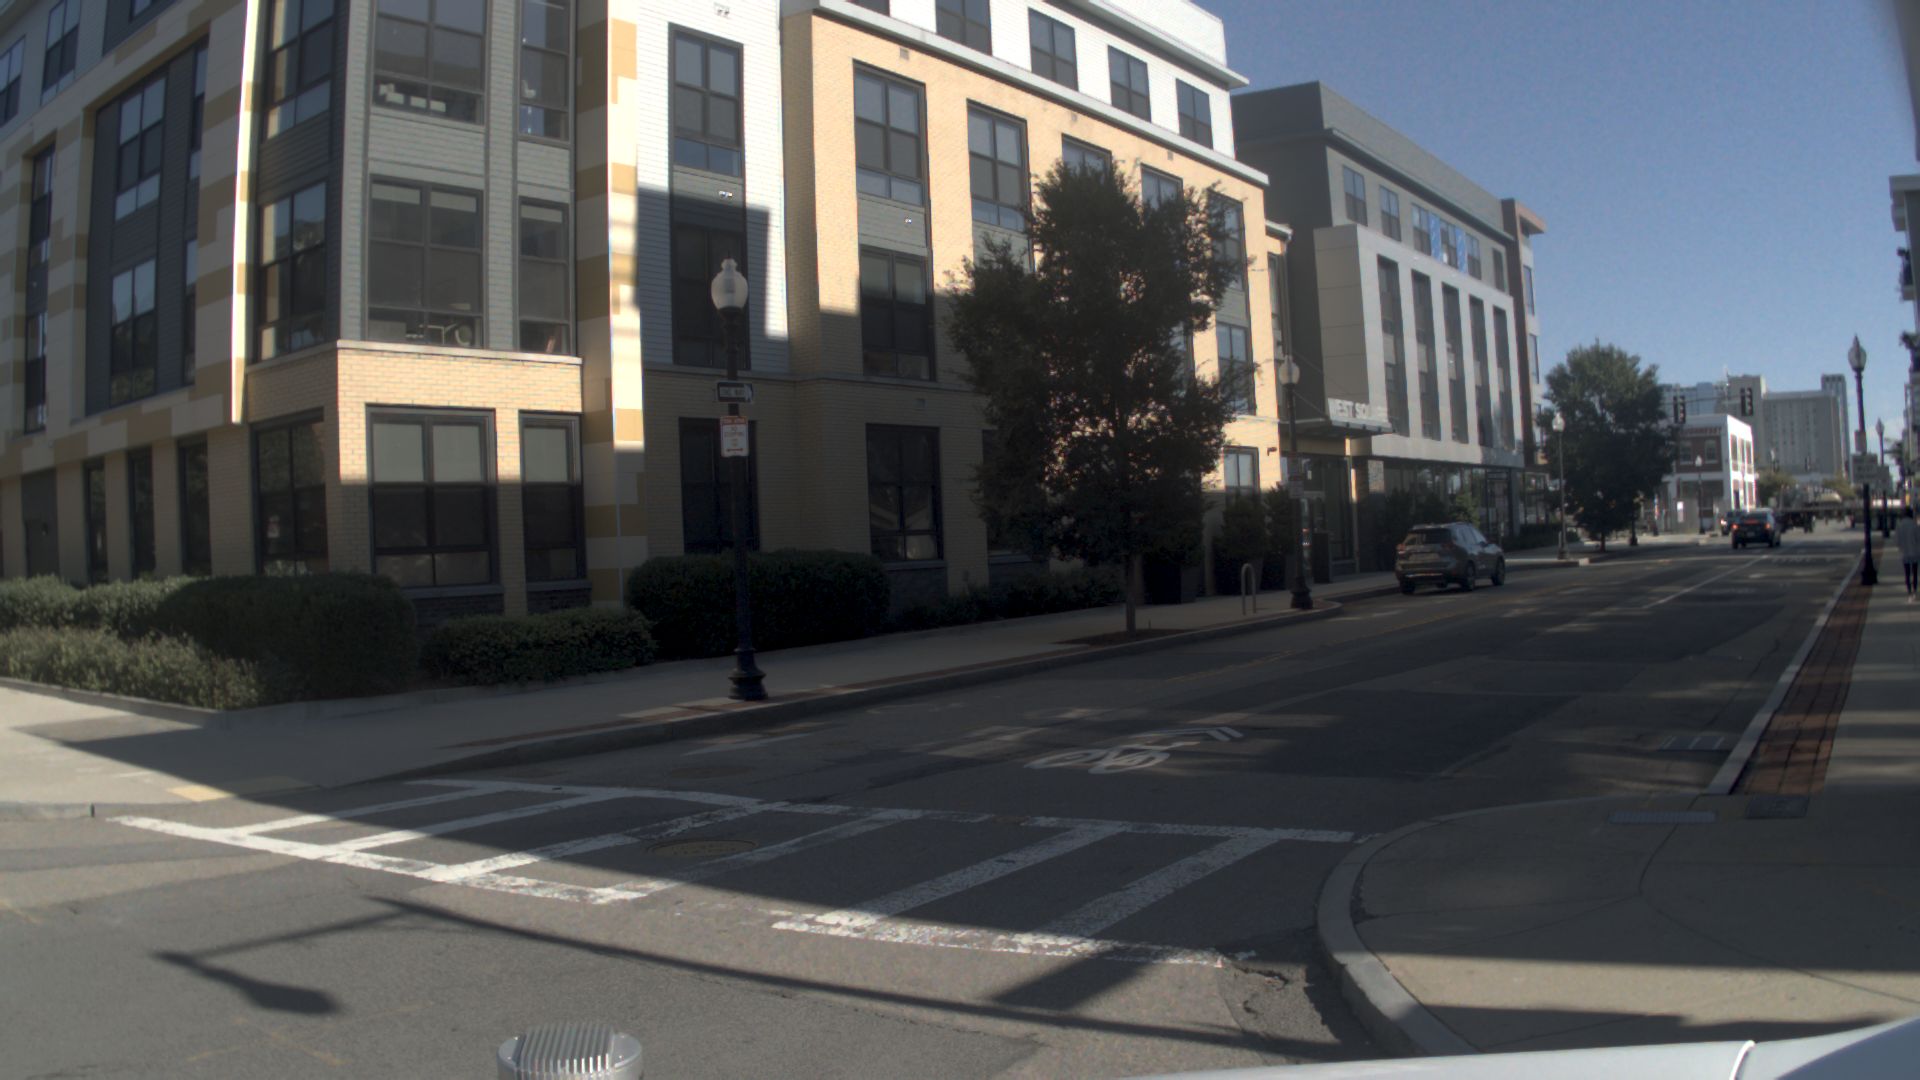
No additional background-vehicle holding corrections were needed. Original photos remain unchanged. Before later inpainting, any overlap with original-photo traffic must be resolved. Background positions in this 3D rehearsal are not an exact replay of the photographs.
After scene approval
The working pipeline will edit each original NAVSIM camera photograph with Image 2.5. Its same-time Higgsfield view will provide position and posture, annotated with facing direction and current speed. Temporal image requests will cover the full event with a 1 Hz base plus critical moments.
Assumptions and source provenance
- The wheelchair map and Image 1 provide road, sidewalk and building context. No venue or audience queue is established by the evidence; both are counterfactual additions.
- World time is -7..40 seconds at 20 Hz, with 941 inclusive samples. All actors persist and playback does not loop; z=0 follows the mapped support surface.
- About ten spectators is instantiated as exactly ten adults. The line extends north-south and advances only south toward a proposed admission approach near [36.2,-7.4].
- Very slow progress is represented by waiting punctuated by two 1.3-metre shuffles, not by continuous sliding below walking speed. Overall progress averages about 0.055 m/s.
- Each two-second shuffle is synchronized and smoothly starts and stops; a rest-to-rest profile with approximately 0.975 m/s peak speed matches the midpoint keys. The long intervals between advances are stationary holds.
- All spectators remain outside the venue through 40 seconds. Admission is not completed, the queue is not removed, and ego stays stopped at x=12.
- Human review is pending. After approval, Image 2.5 must edit original Image 1, preserving its source architecture and transferring only the approved actor positions, postures and modest entrance sign.
Fresh GPT-6 motion plans use semantic descriptions from the pinned consolidated catalog and NAVSIM environments. No upstream nuPlan vectors, trajectories or images are used. The four source environments are reused; 82 scenario descriptions do not mean 82 independent locations.
Higgsfield revision 2. The portable GLB combines export clips without changing geometry or animation samples.
This review uses Higgsfield revision 2 and the exact exported scene snapshot.
Higgsfield workspace (latest revision) · Download animated GLB · GPT-6 scene plan · Visual review evidence · Motion checks · Approval status