MARSAD / CONSOLIDATED CATALOG / #010
Municipal crew moves among access covers and cable runs
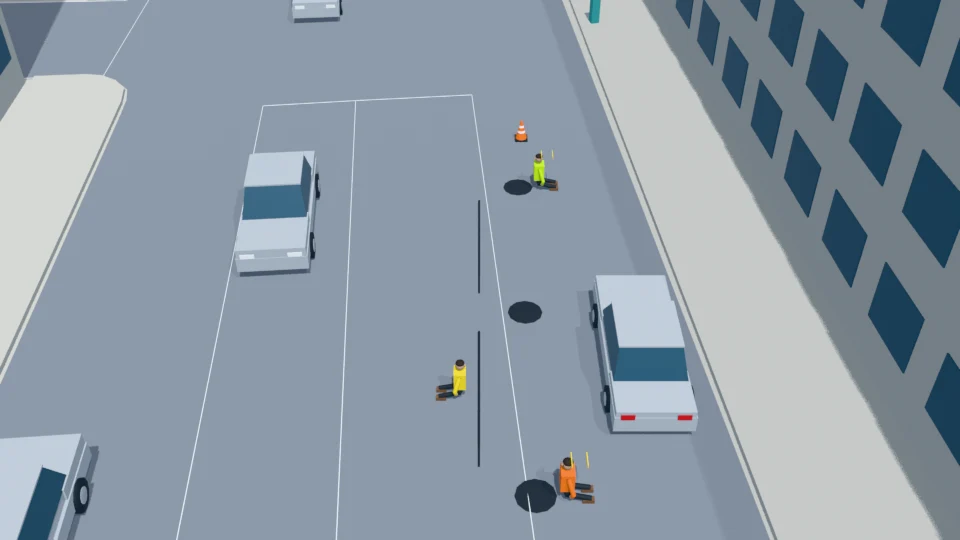
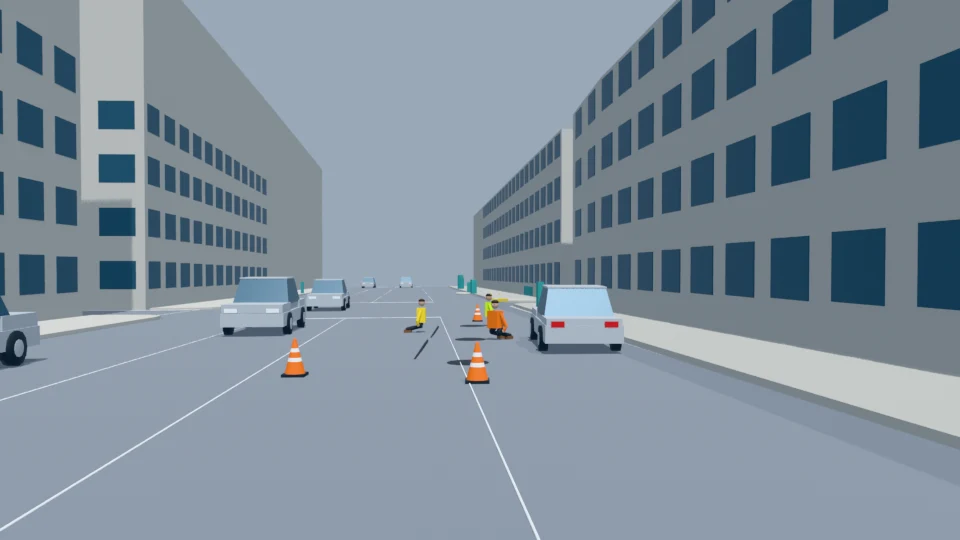
Awaiting your 3D scene approvalCounterfactual municipal maintenance zone contains three workers, three closed access covers, two surface cable runs and three cones. Workers inspect, relocate between stations and revisit earlier stations. Maintenance and the lane obstruction continue through 40 seconds.
Original description: 前方有市政人员正在道路上检修多个井盖和电缆,在不同的井盖和线缆之间来回移动,周围摆放少量锥桶
Loading the full animated scene…
Critical moments
What to verify
- Require exactly three municipal workers, three access covers, two distinct cable runs and three cones, all persistent.
- Verify all work props lie inside the cargo road polygon and workers start on the corresponding mapped sidewalks.
- Require visible kneeling inspections at all three covers and both cables, plus the specified finite return visits rather than a generic crossing.
- Verify at least 0.6 metres of worker body clearance; the two westbound cover workers retain six metres of center separation during 20..26 seconds.
- Require worker footpaths to avoid cable footprints and cone bases; reaching hands must face and meet the intended near rim or cable before withdrawing.
- At 20 Hz verify grounded props, continuous bounded-speed paths, in-place turns and no duplicated, floating or disappearing equipment.
- Require the upstream cone and ongoing work to preserve the ego obstruction through 40 seconds; ego remains at x=12 with no release.
- Human review of approach, distributed work at 16 seconds, station changes and final state must precede image generation.
Review notes
Reviewed worker relocations, crouching inspections, three covers, two cable runs and cones through the full episode. Revision 3 repairs portable object names without changing geometry or motion. Maintenance remains an ongoing obstruction.
Check action, relative position, facing, posture and visibility. Approximate offsets are acceptable. Sampled visual checks do not prove every contact or continuous collision clearance.
Rendered inspection views
Event, approach and final views rendered from the exact committed Higgsfield Blender source. These are procedural 3D previews, not generated training photographs.
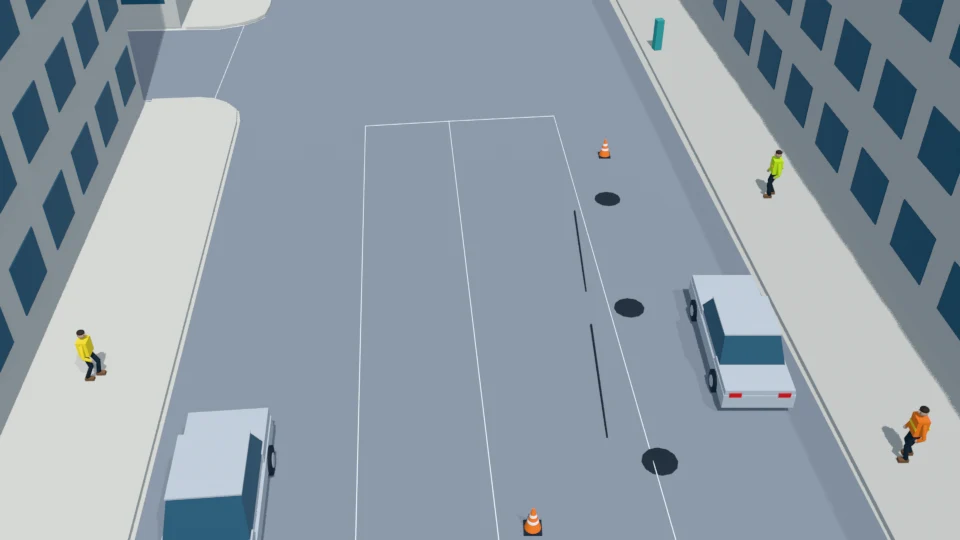
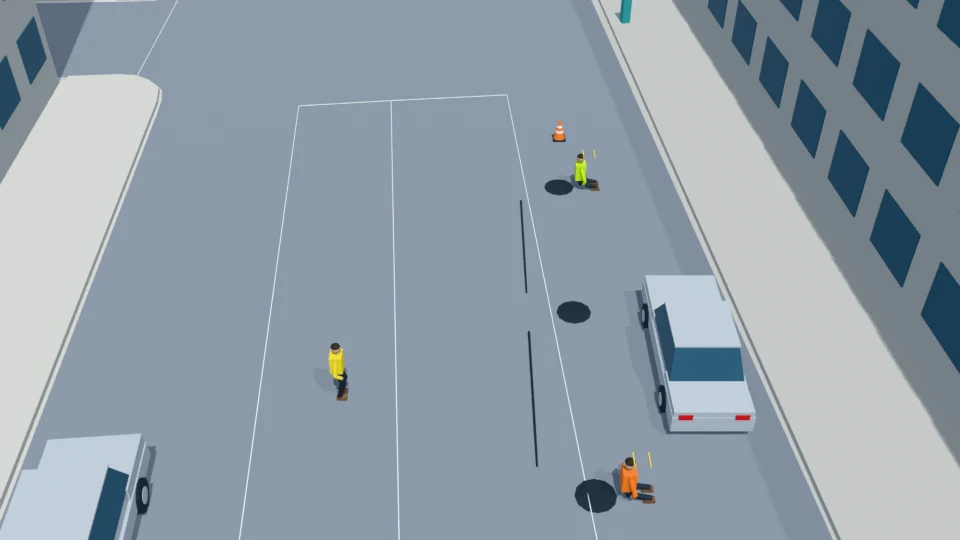
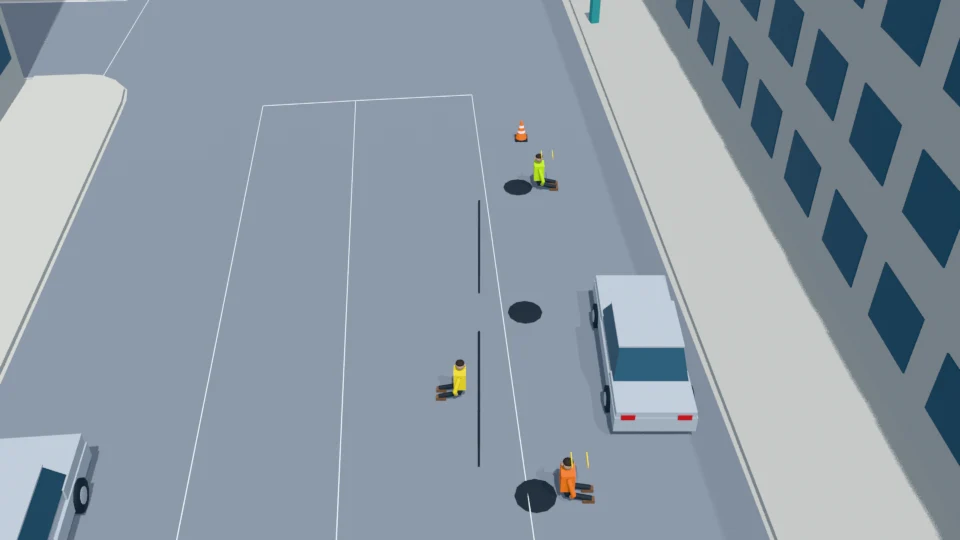
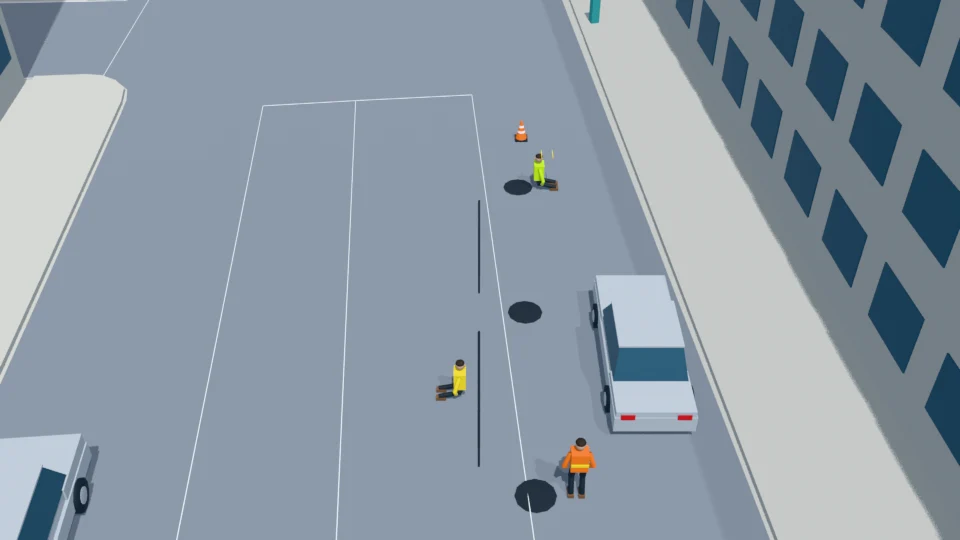
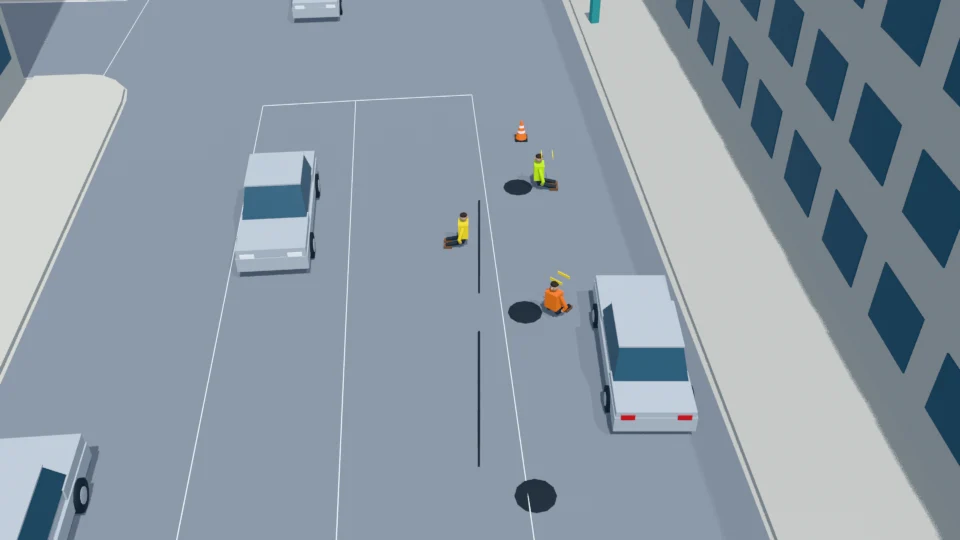
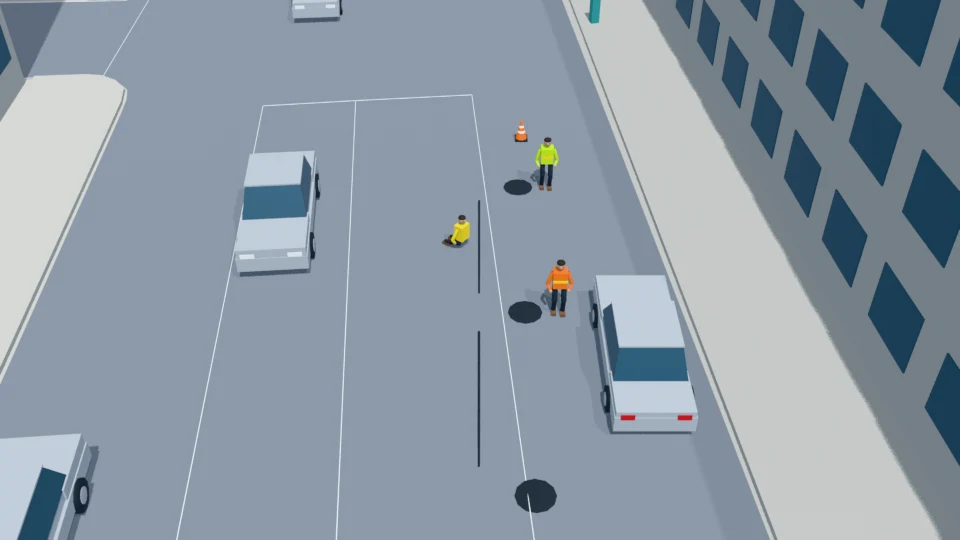
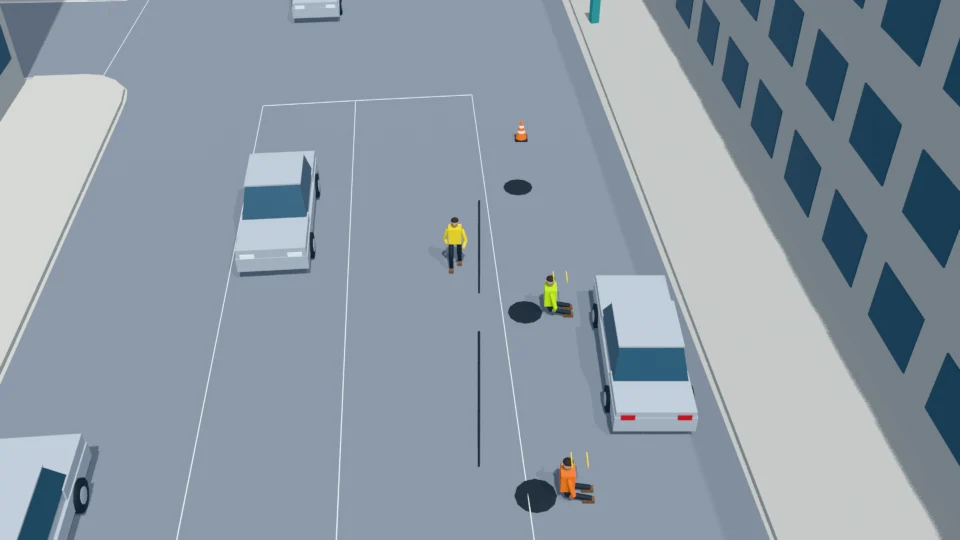
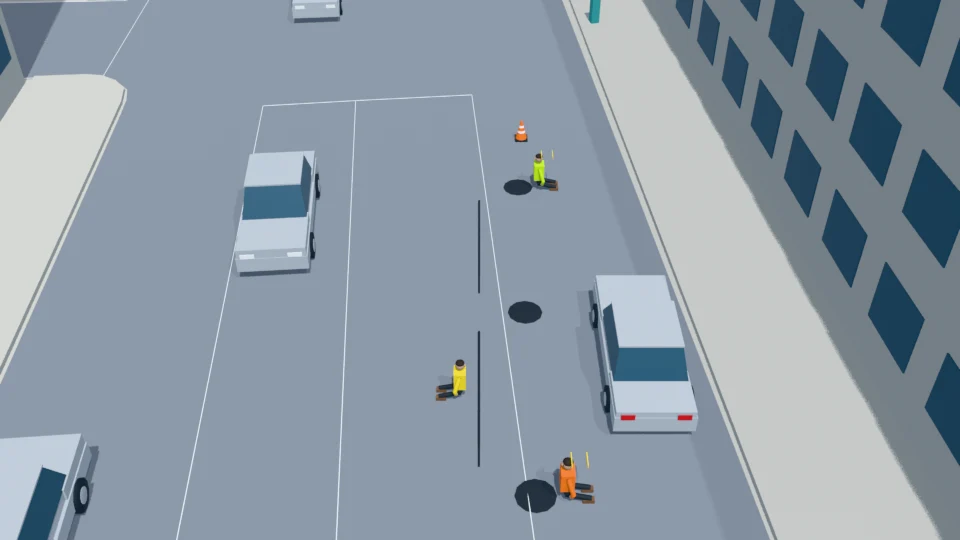
Original NAVSIM camera context
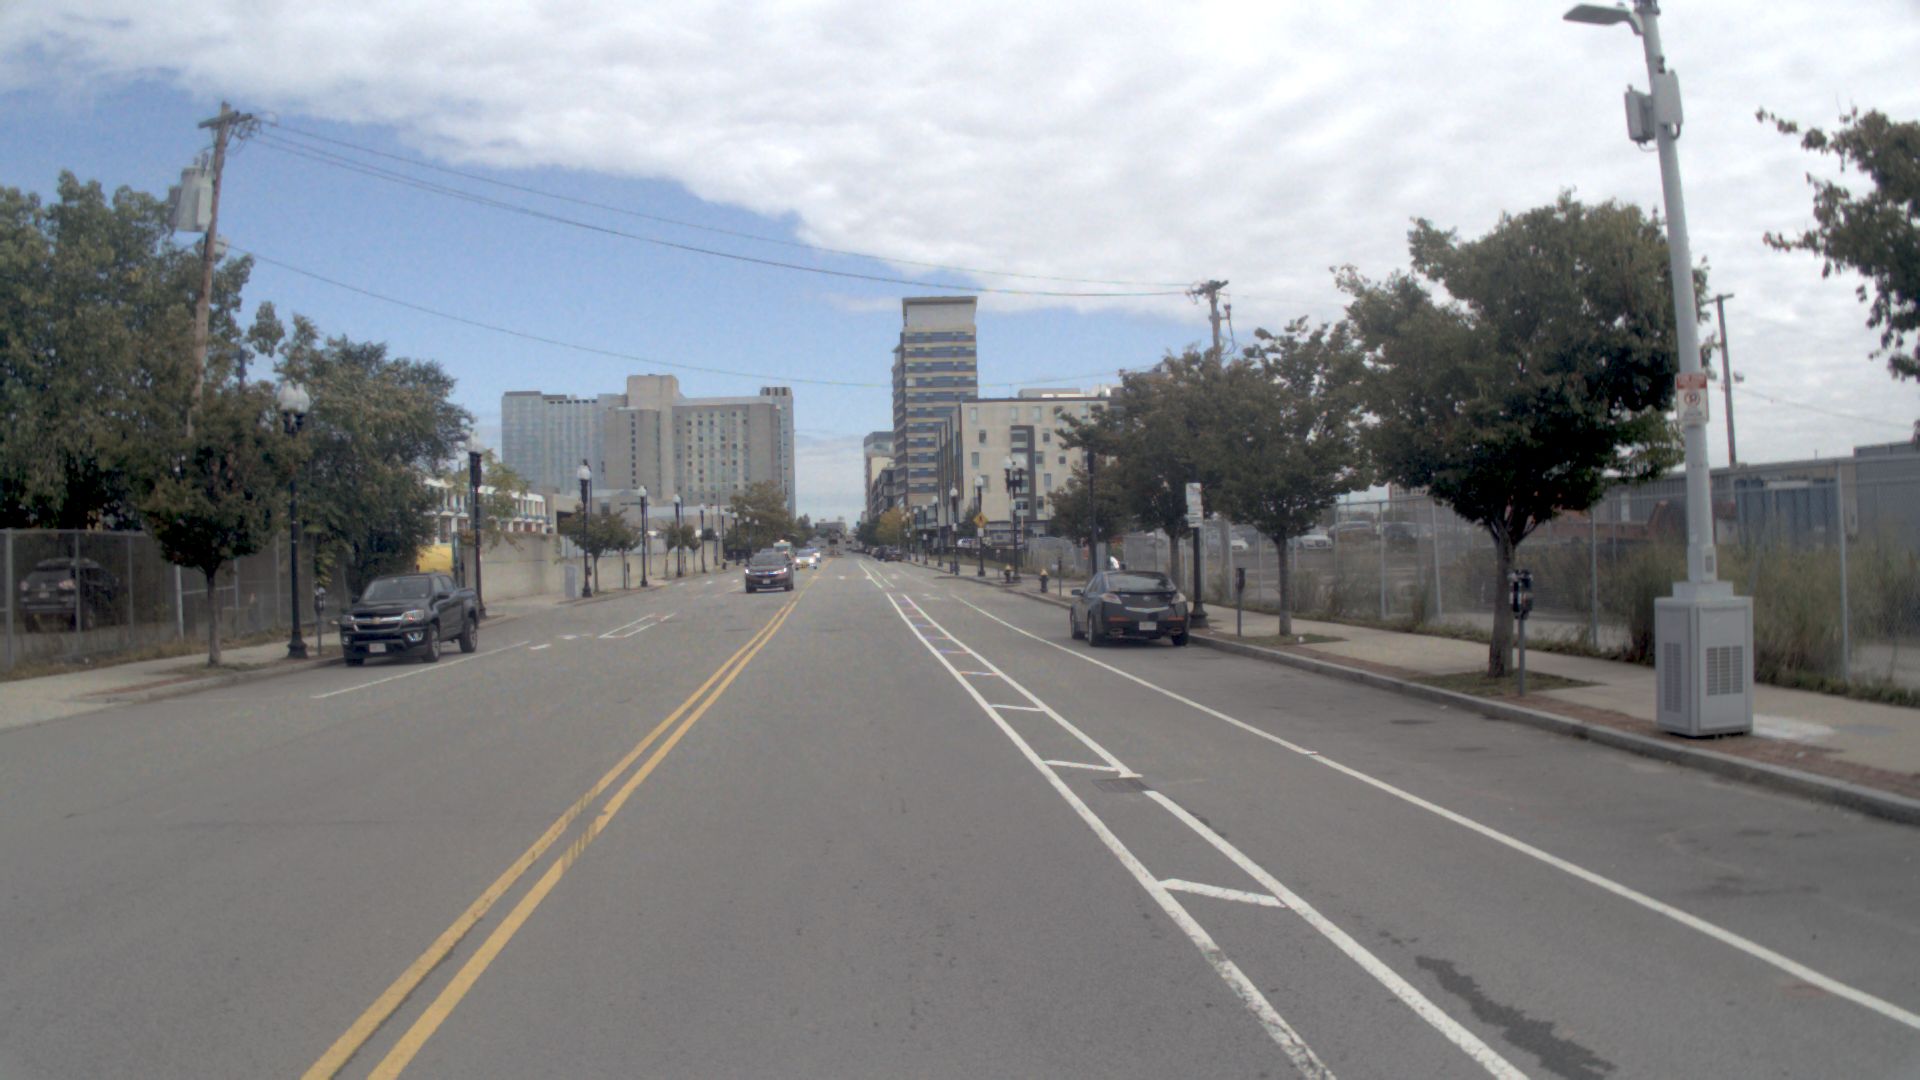
5 conflicting background vehicles were moved to clear holding positions for this counterfactual rehearsal. Original photos remain unchanged. Before later inpainting, any overlap with original-photo traffic must be resolved. Background positions in this 3D rehearsal are not an exact replay of the photographs.
After scene approval
The working pipeline will edit each original NAVSIM camera photograph with Image 2.5. Its same-time Higgsfield view will provide position and posture, annotated with facing direction and current speed. Temporal image requests will cover the full event with a 1 Hz base plus critical moments.
Assumptions and source provenance
- The cargo map and Image 3 provide street and sidewalk geometry. The municipal work zone, access covers and cable placement are counterfactual proposals, not verified source infrastructure.
- World time is -7..40 seconds at 20 Hz, with 941 inclusive samples and no looping. Every z value is a support offset above the mapped surface, not absolute elevation.
- Multiple covers and cables are instantiated as three closed, nearly flush covers and two isolated surface cable runs. A few cones is instantiated as exactly three.
- No open shafts, energized-cable effects, detached tools or unmodeled moving machinery are proposed. The two cable runs remain intact and ground-supported.
- Workers walk approximately 0.95..1.30 m/s between stations, with bounded easing and short in-place turns. Stationary inspection intervals include withdrawing hands before orientation changes.
- The north and south work aisles are separated by 2.7 metres. Cover B is used sequentially; the later worker never passes through the earlier worker.
- Maintenance is still underway at the finite horizon. No prop collection or artificial lane clearance is introduced.
- Human review is pending. After approval, Image 2.5 must edit original Image 3, preserving its architecture and transferring only approved rehearsal placements and postures.
Fresh GPT-6 motion plans use semantic descriptions from the pinned consolidated catalog and NAVSIM environments. No upstream nuPlan vectors, trajectories or images are used. The four source environments are reused; 82 scenario descriptions do not mean 82 independent locations.
Higgsfield revision 3. The portable GLB combines export clips without changing geometry or animation samples.
This review uses Higgsfield revision 3 and the exact exported scene snapshot.
Higgsfield workspace (latest revision) · Download animated GLB · GPT-6 scene plan · Visual review evidence · Motion checks · Approval status