MARSAD / CONSOLIDATED CATALOG / #011
Scattered roadside dance
Awaiting your 3D scene approvalResidents dance in a loose roadside formation; broad movements maintain a lane obstruction.
Original description: 前方有多名居民在道路边跳广场舞,队形分散,部分动作幅度较大(prompt要尽量简短)
Loading the full animated scene…
Critical moments
What to verify
- Verify exactly six persistent adult residents, with no duplicated dancers or disappearing actors.
- Evaluate all 941 samples at 20 Hz over -7..40 s; check grounded feet, bounded interpolation, sidewalk and roadway footprints, and at least 0.6 m ordinary walking separation.
- Check full articulated arm envelopes, not only torso dimensions; broad gestures must not intersect neighboring bodies.
- Confirm a scattered roadside dance rather than a generic crossing, with visible broad movements at 6 and 22 s and continuing obstruction at 40 s.
- Keep ego stopped at x=12, y=0; do not release merely because the rear residents rest.
- Require human approval of the full rehearsal and source-photo occlusions before Image 2.5 edits original Image 3.
Review notes
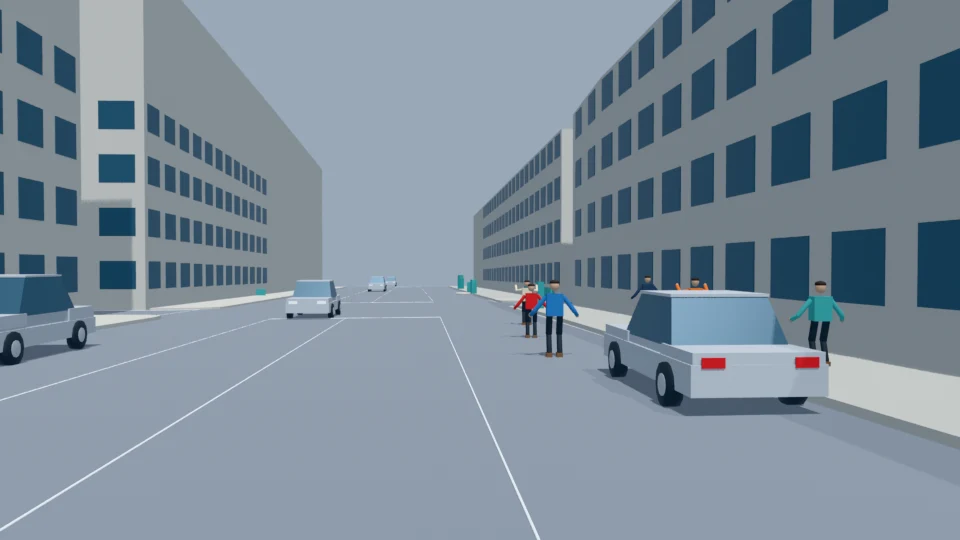
Reviewed the enlarged inspection framing and full dance sequence. Six residents remain identifiable in a scattered formation; three move to the road edge and their arm gestures continue. The actor group stays present through the final frame.
Check action, relative position, facing, posture and visibility. Approximate offsets are acceptable. Sampled visual checks do not prove every contact or continuous collision clearance.
Rendered inspection views
Event, approach and final views rendered from the exact committed Higgsfield Blender source. These are procedural 3D previews, not generated training photographs.
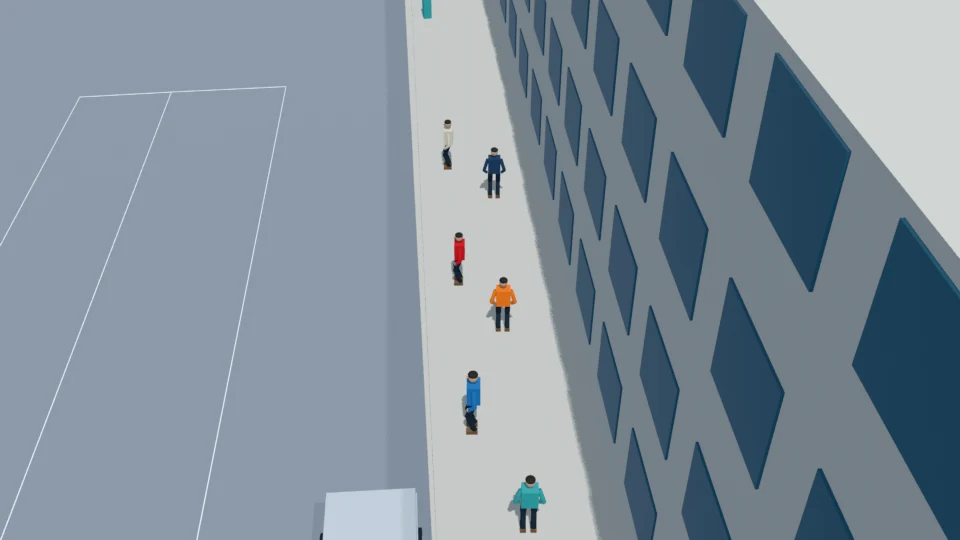
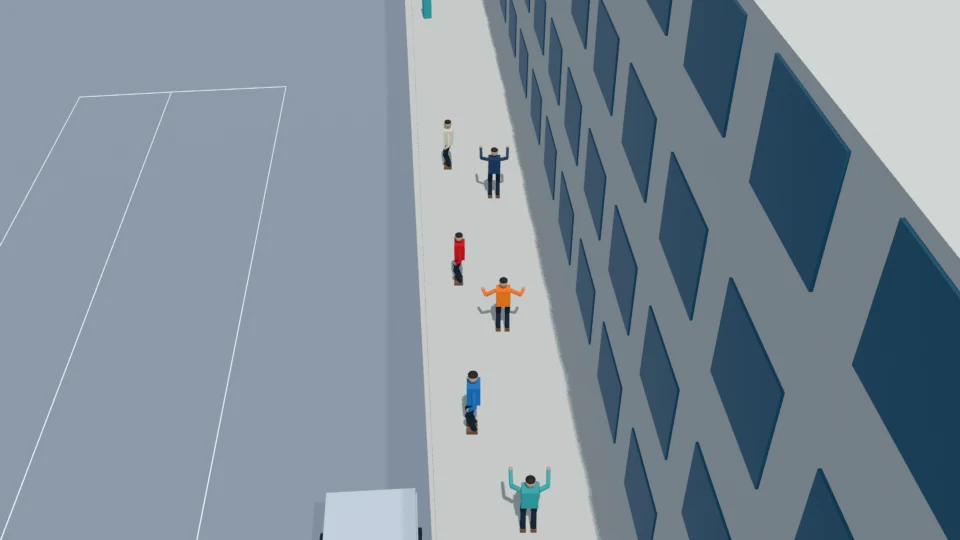
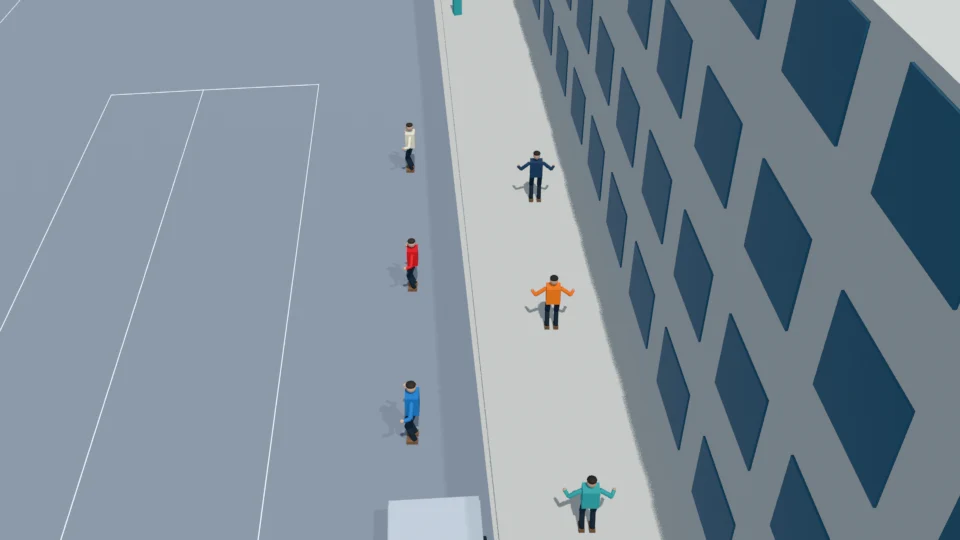
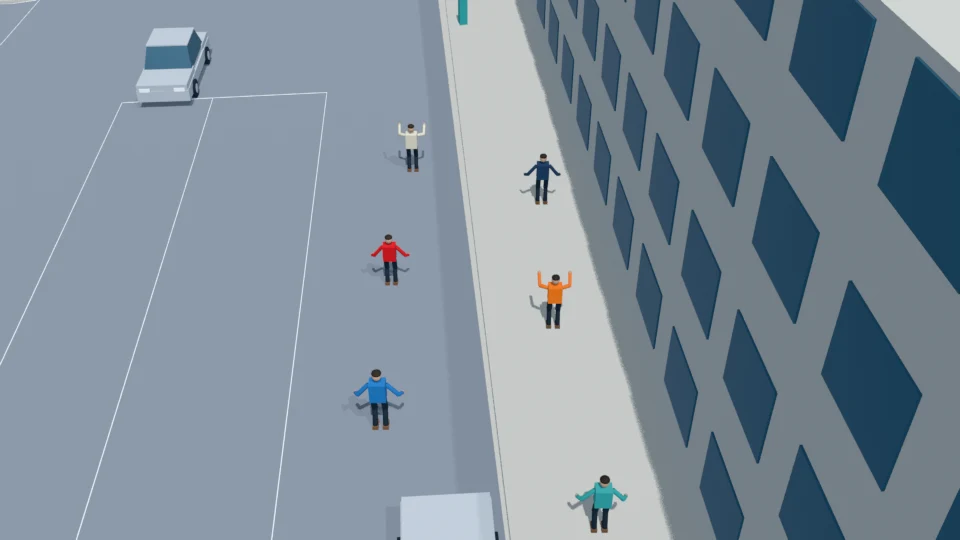
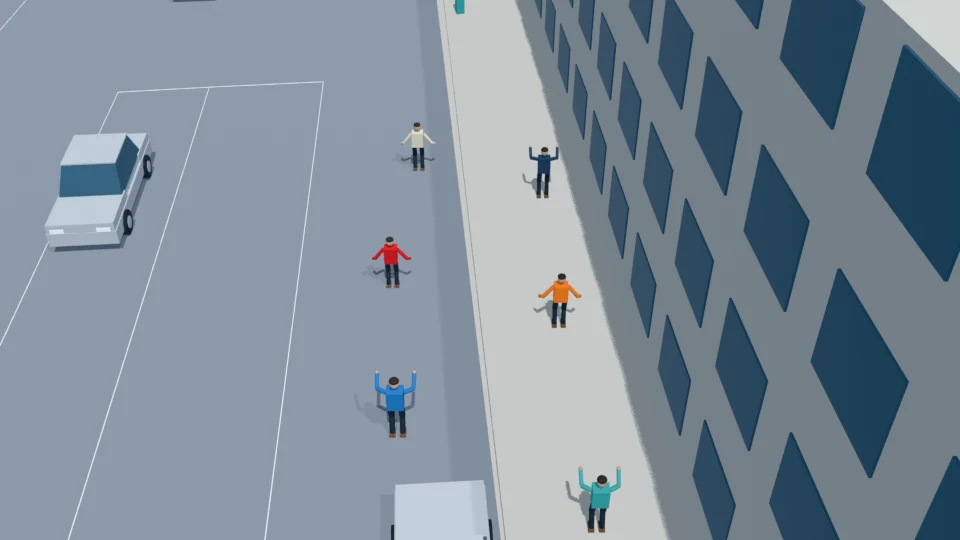
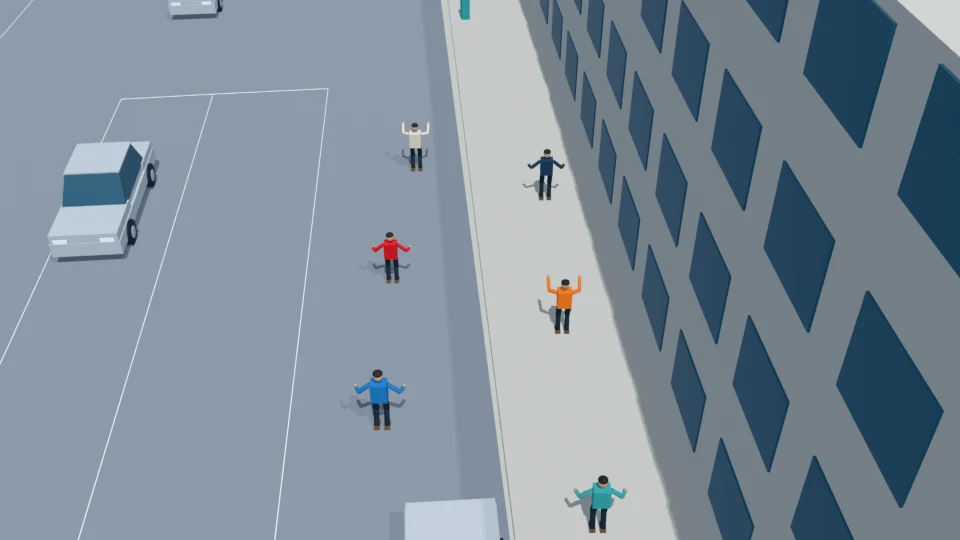
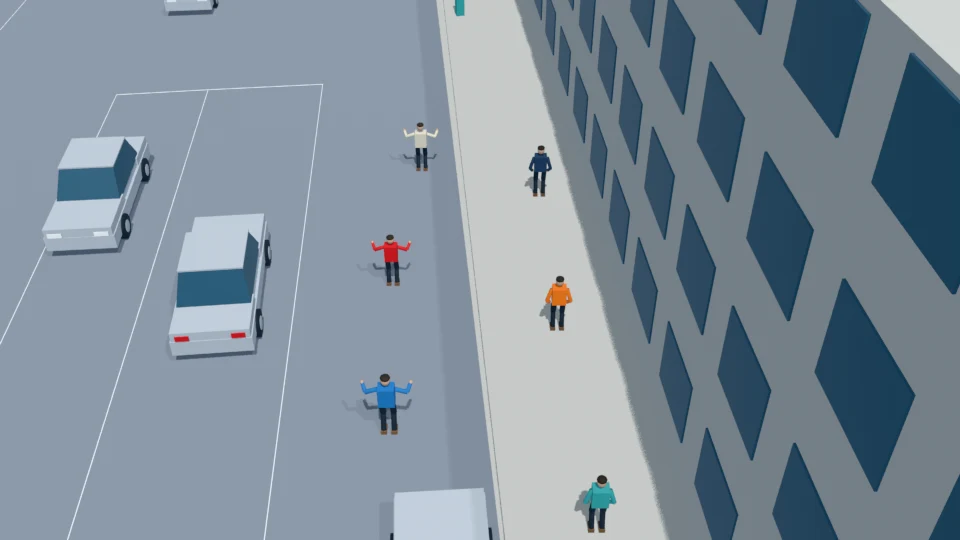
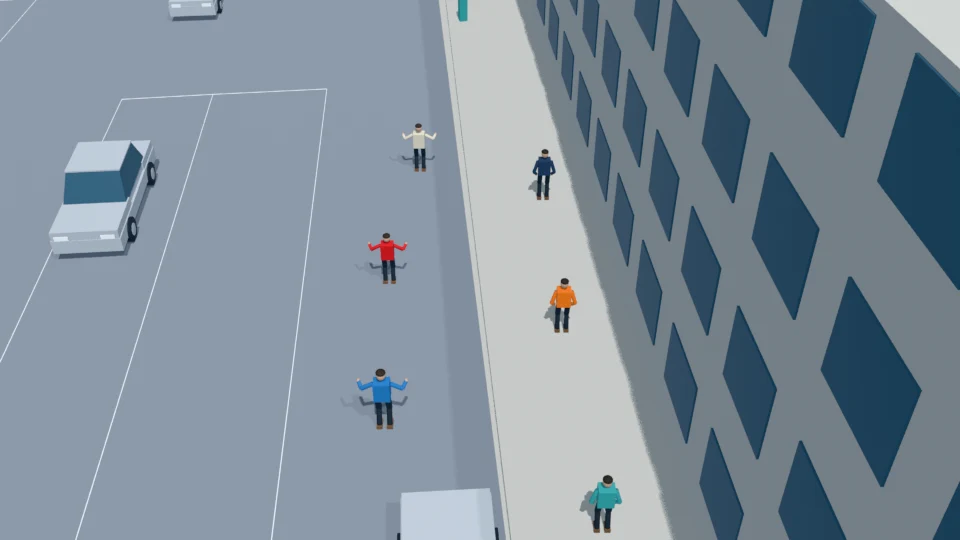
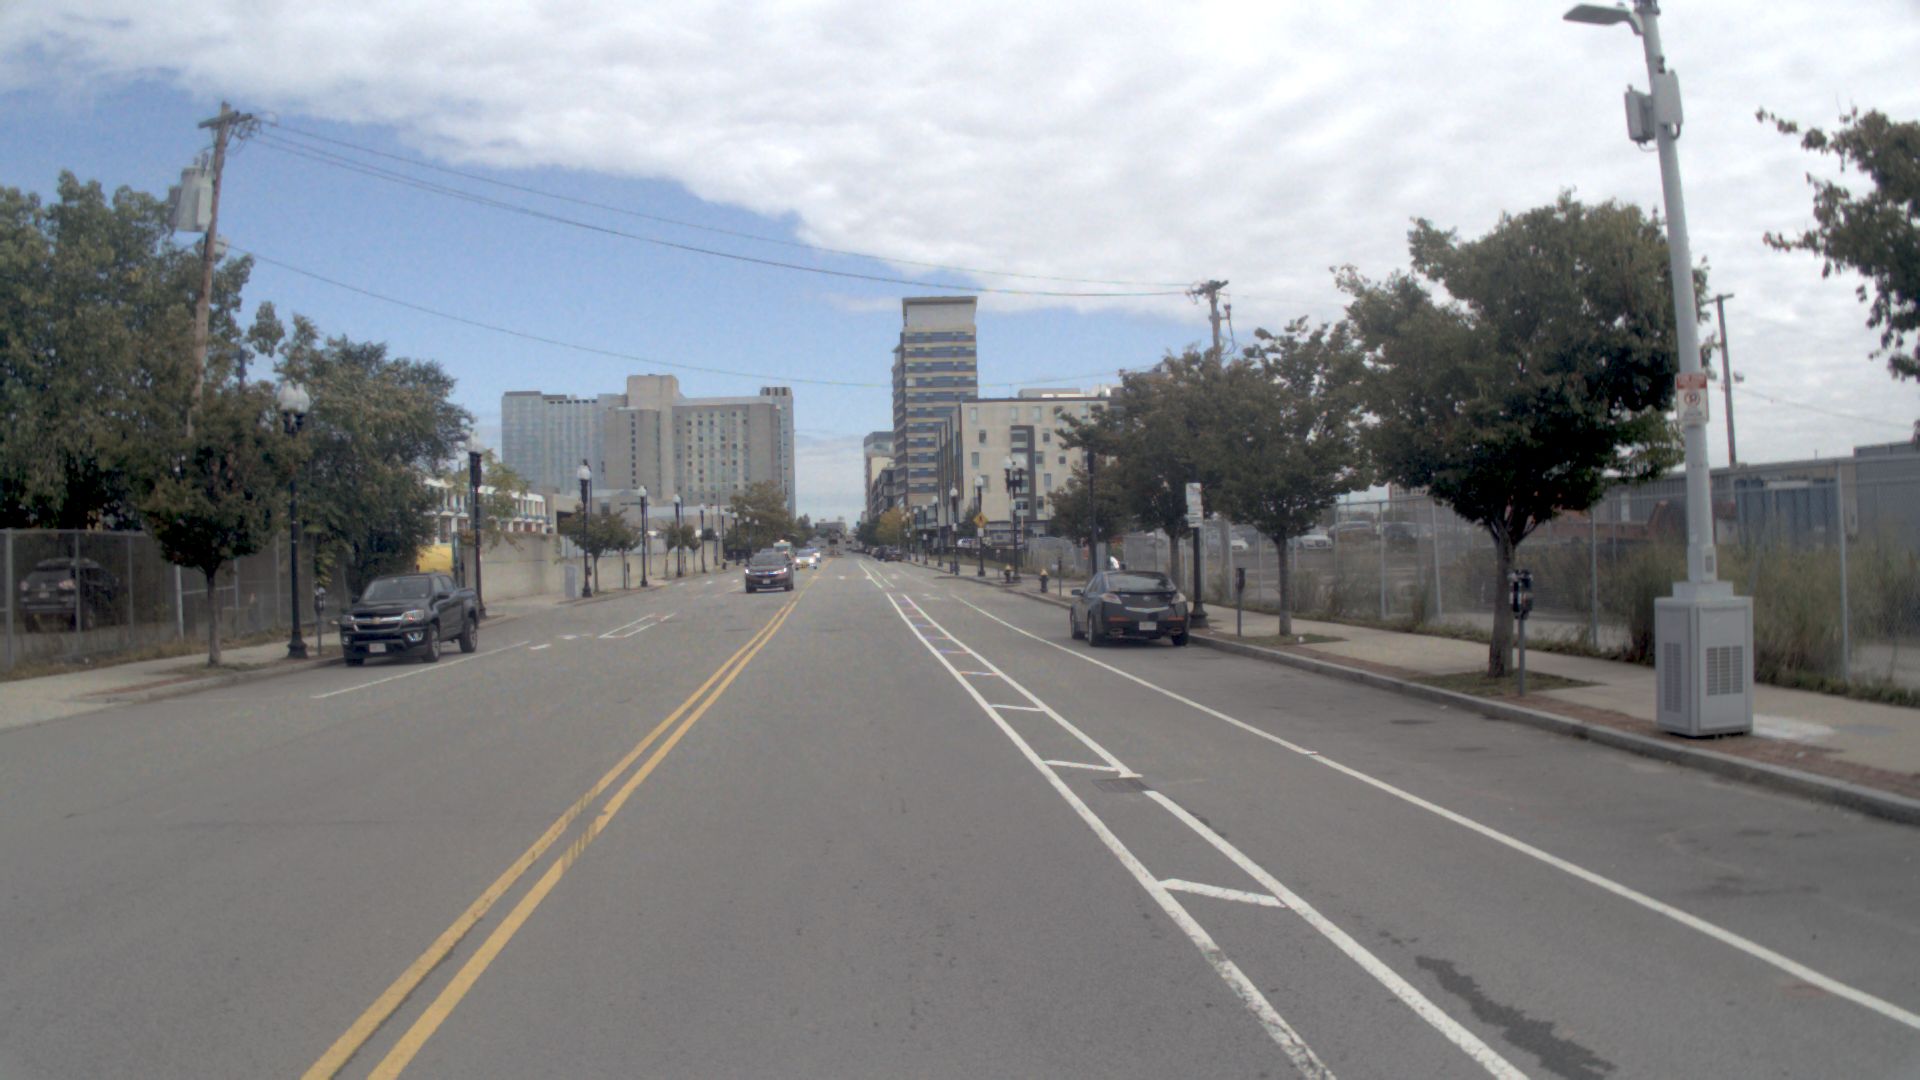
Original NAVSIM camera context
1 conflicting background vehicles were moved to clear holding positions for this counterfactual rehearsal. Original photos remain unchanged. Before later inpainting, any overlap with original-photo traffic must be resolved. Background positions in this 3D rehearsal are not an exact replay of the photographs.
After scene approval
The working pipeline will edit each original NAVSIM camera photograph with Image 2.5. Its same-time Higgsfield view will provide position and posture, annotated with facing direction and current speed. Temporal image requests will cover the full event with a 1 Hz base plus critical moments.
Assumptions and source provenance
- This is a counterfactual proposal. Original Image 3 supports the broad road, fencing, trees and buildings, not the proposed dancers; all actor coordinates are newly authored on the cargo map.
- Rear residents occupy the mapped south sidewalk; front residents approach the adjacent roadway. The template name contributes geometry, not cargo-related behavior.
- Playback is finite and non-looping from -7 to 40 s at 20 Hz. Use velocity-limited C1 interpolation and finite articulated dance phrases; small dance weight shifts are not ordinary walking.
- Ego is the simulator vehicle, approximately 4.6 by 1.85 m, not an additional cast actor. It stops with its center at x=12, y=0 by -3 s. Its buffered corridor is approximately |y|<=1.55, including checks against moving limbs.
- Ground support follows the supplied ground plane; human z values are zero offsets. Exact curb profiles, parked-vehicle depths and facade clearances remain unverified from the single photograph.
- The initial review time is a suggested seek point, not approval. No image generation is authorized before human review; acceptance checks are requirements, not executed test results.
Fresh GPT-6 motion plans use semantic descriptions from the pinned consolidated catalog and NAVSIM environments. No upstream nuPlan vectors, trajectories or images are used. The four source environments are reused; 82 scenario descriptions do not mean 82 independent locations.
Higgsfield revision 1. The portable GLB combines export clips without changing geometry or animation samples.
This review uses Higgsfield revision 1 and the exact exported scene snapshot.
Higgsfield workspace (latest revision) · Download animated GLB · GPT-6 scene plan · Visual review evidence · Motion checks · Approval status