MARSAD / CONSOLIDATED CATALOG / #013
Phone distraction and an unexpected stop
Awaiting your 3D scene approvalA phone-distracted pedestrian drifts into the lane, stops, changes direction and eventually returns to the sidewalk.
Original description: 前方有行人低头专注于手机,对周围环境感知不足,可能会突然变向或停步。
Loading the full animated scene…
Critical moments
What to verify
- Verify one persistent adult and one persistent phone, with no second pedestrian or replacement phone.
- Evaluate 941 samples at 20 Hz; use a tangent-aligned curved approach, planted turns and walking speeds of 0.6..1.7 m/s apart from bounded starting and stopping transitions.
- Make the lowered gaze, first lane stop, westward direction change and second stop clearly distinguishable from an ordinary crossing.
- Check the phone remains gripped, its attachment transforms agree with its keys, and neither phone nor hands intersect the torso.
- Keep ego at x=12, y=0 until the pedestrian and phone are on the south sidewalk at 13 s and clearance remains confirmed through 15 s.
- Require human review of the full timeline and original parked-vehicle occlusions before Image 2.5 edits original Image 2.
Review notes
Reviewed distracted walking, unplanned stop, direction change and return to the sidewalk. The phone remains in the hands. Contact inspection was reframed from the road side to avoid looking through a building.
Check action, relative position, facing, posture and visibility. Approximate offsets are acceptable. Sampled visual checks do not prove every contact or continuous collision clearance.
Rendered inspection views
Event, approach and final views rendered from the exact committed Higgsfield Blender source. These are procedural 3D previews, not generated training photographs.
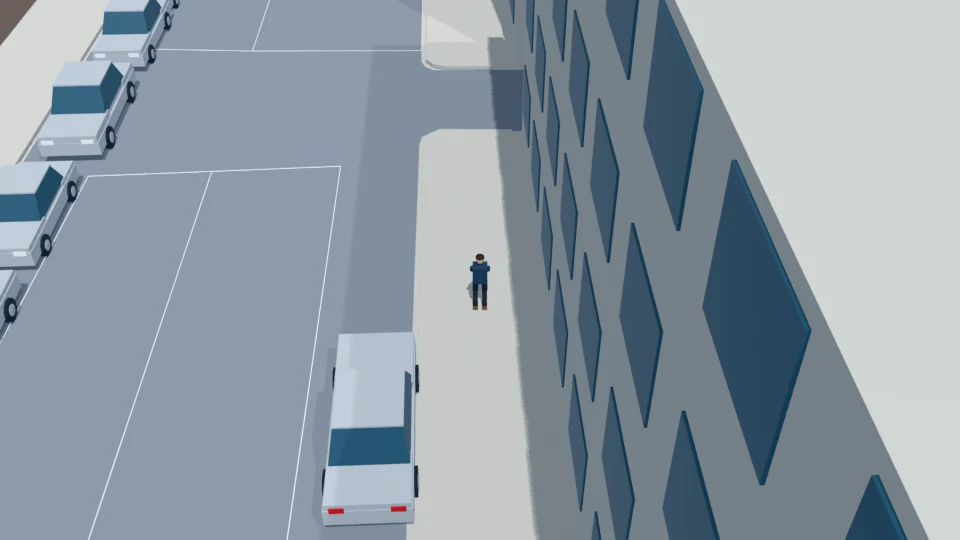
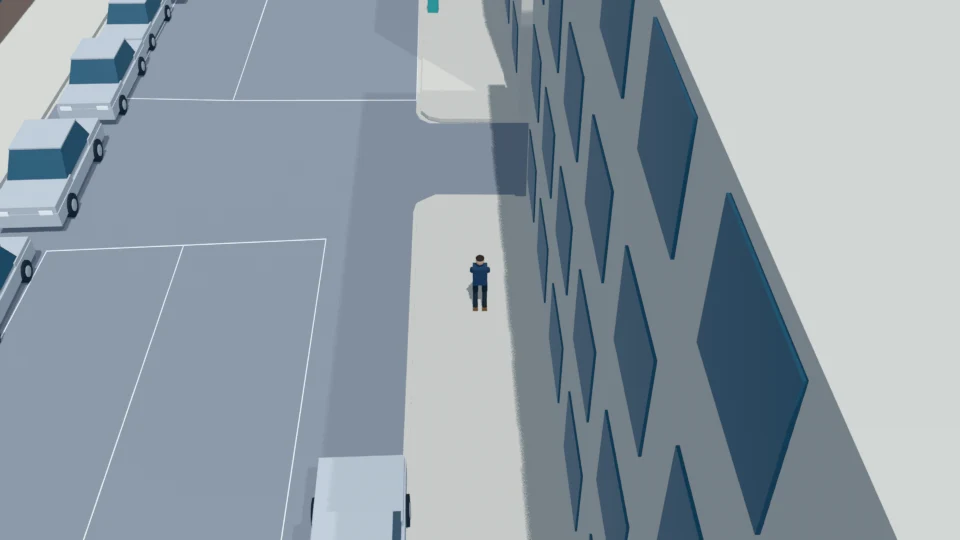
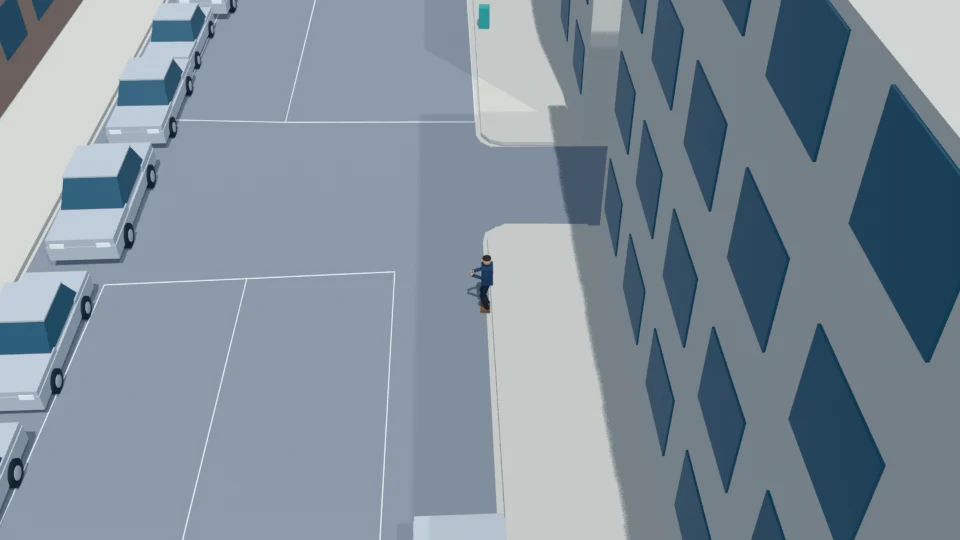
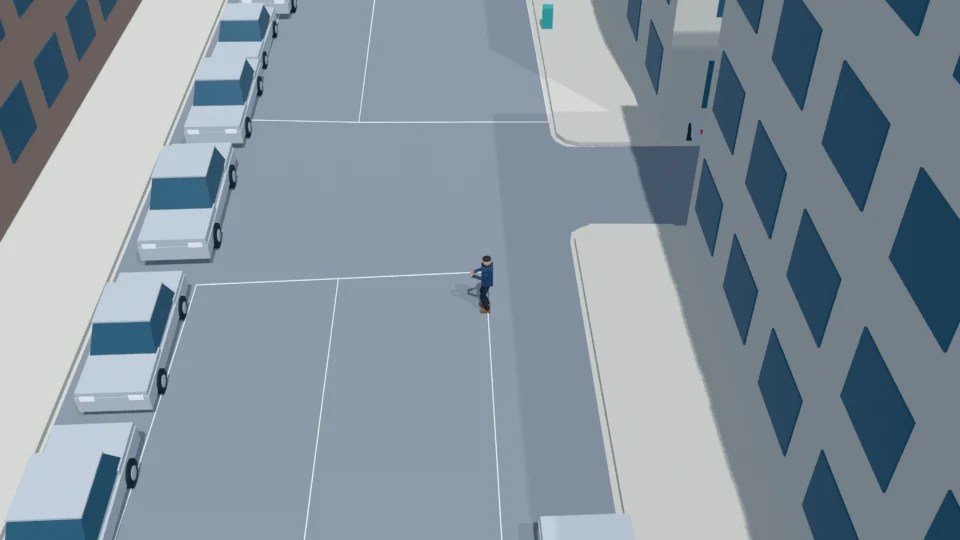
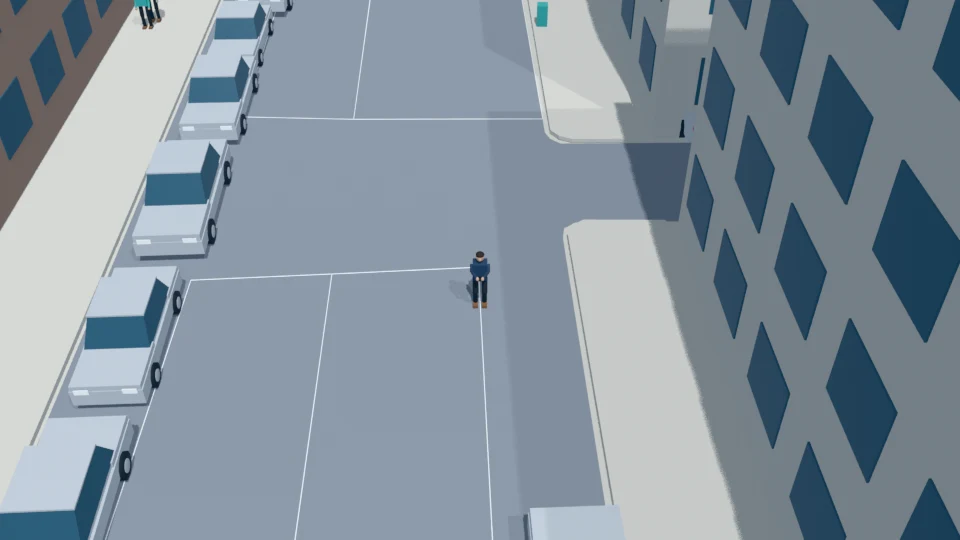
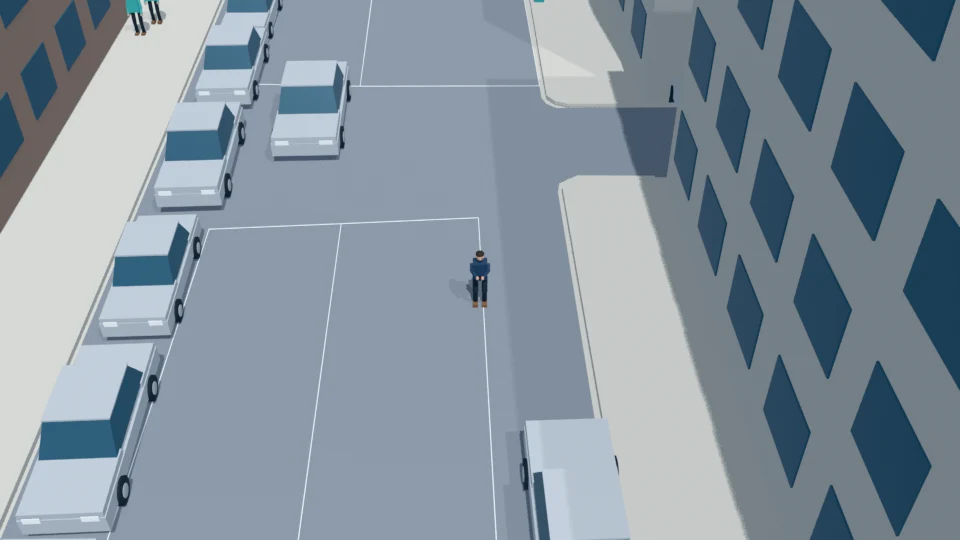
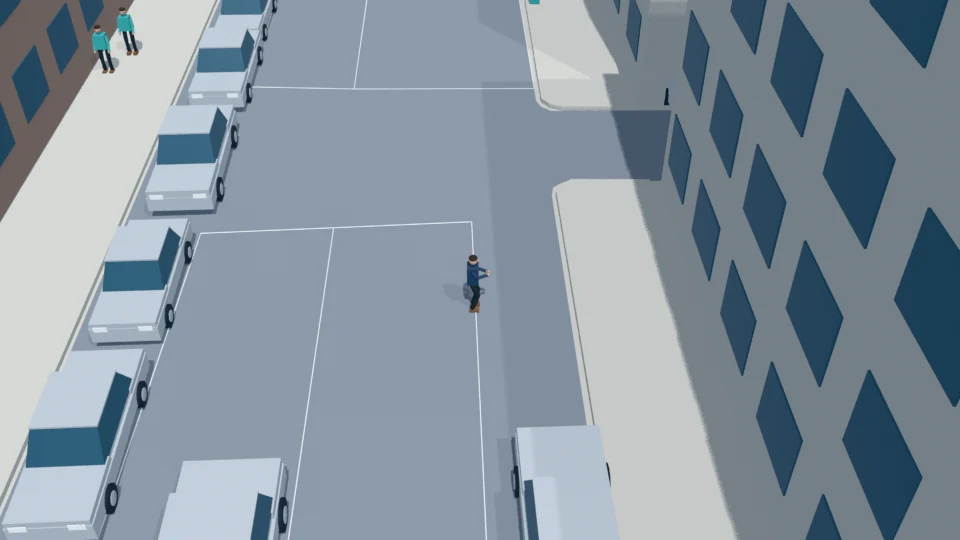
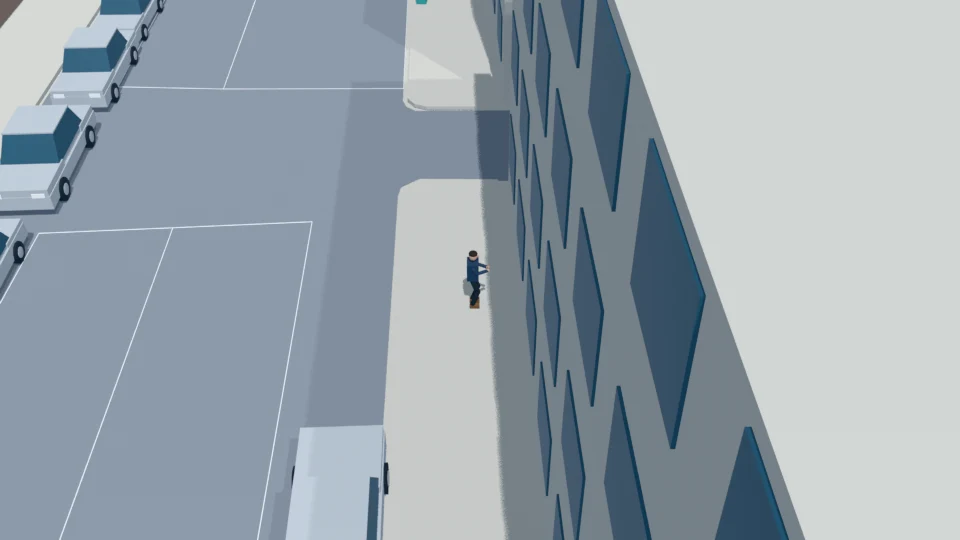
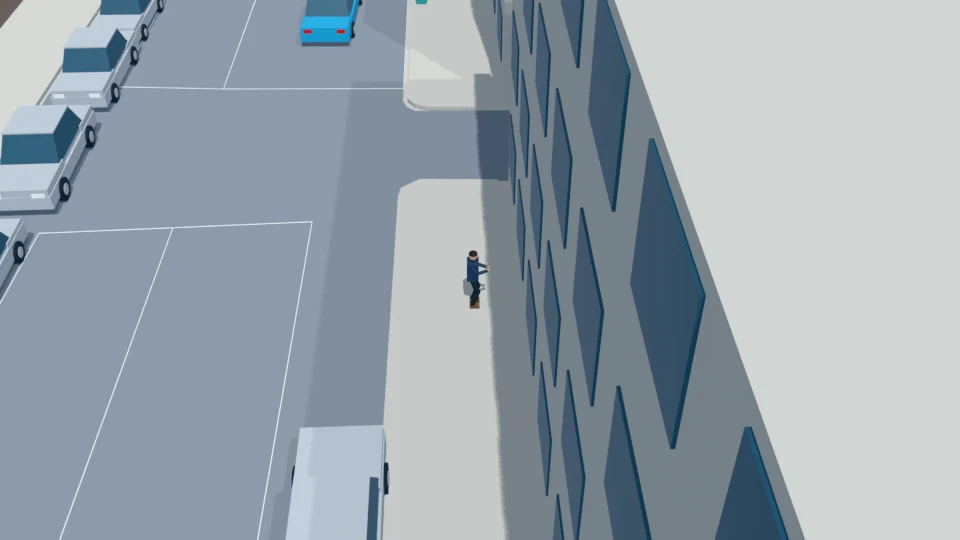
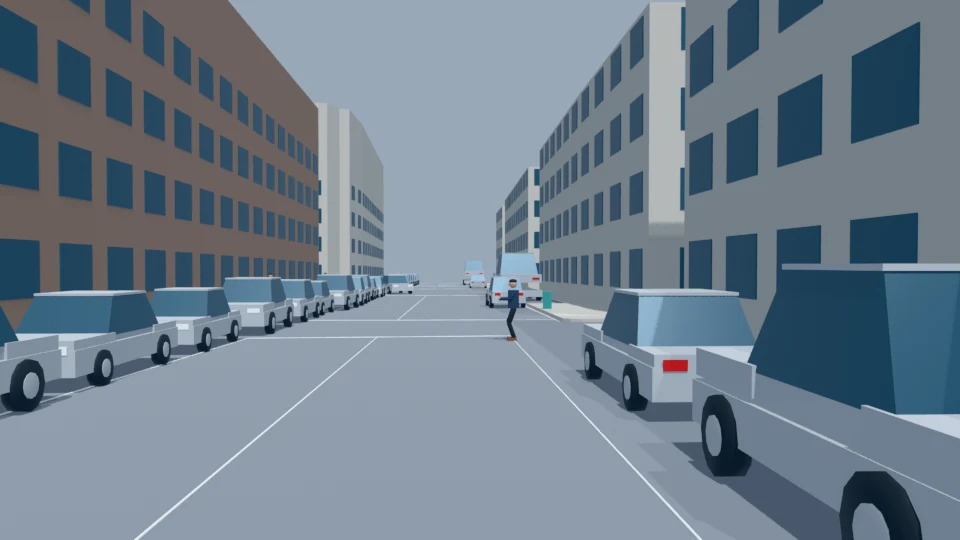
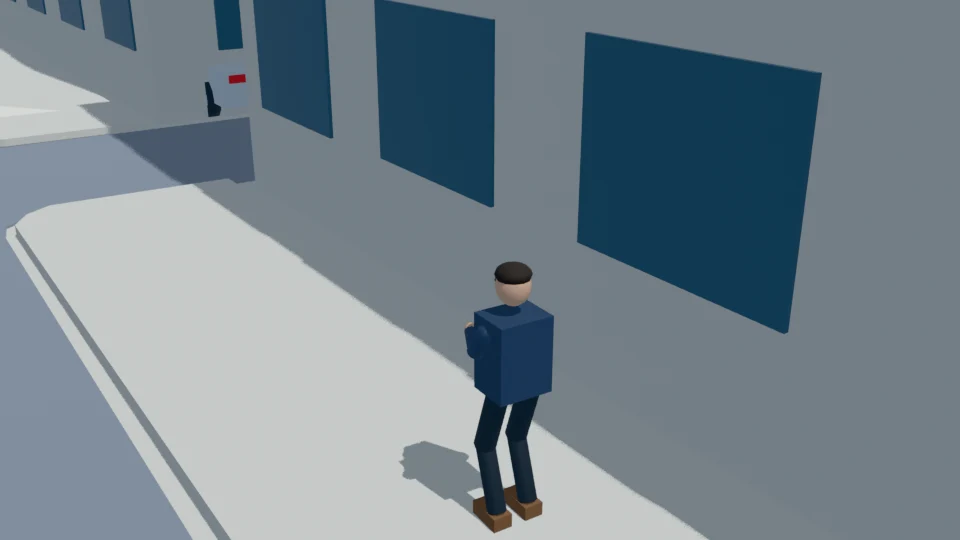
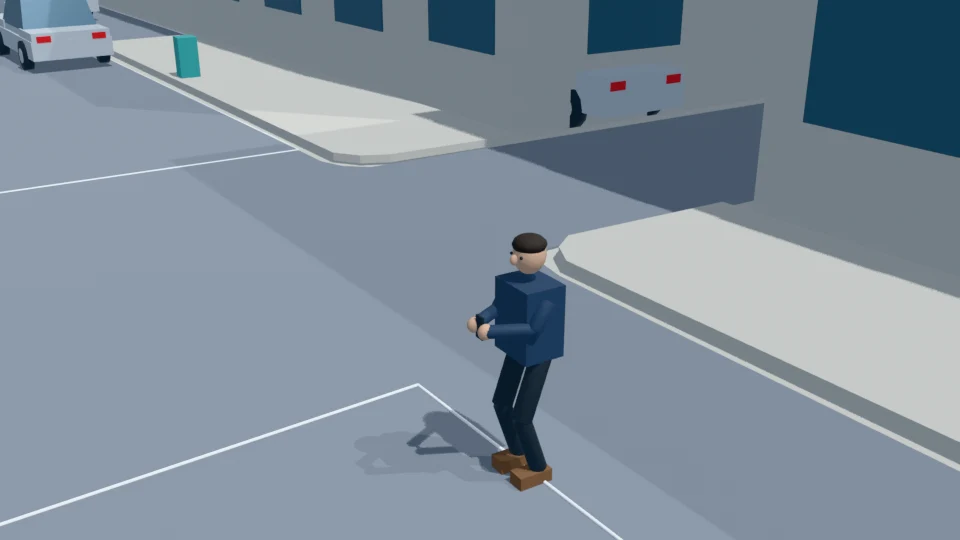
Original NAVSIM camera context
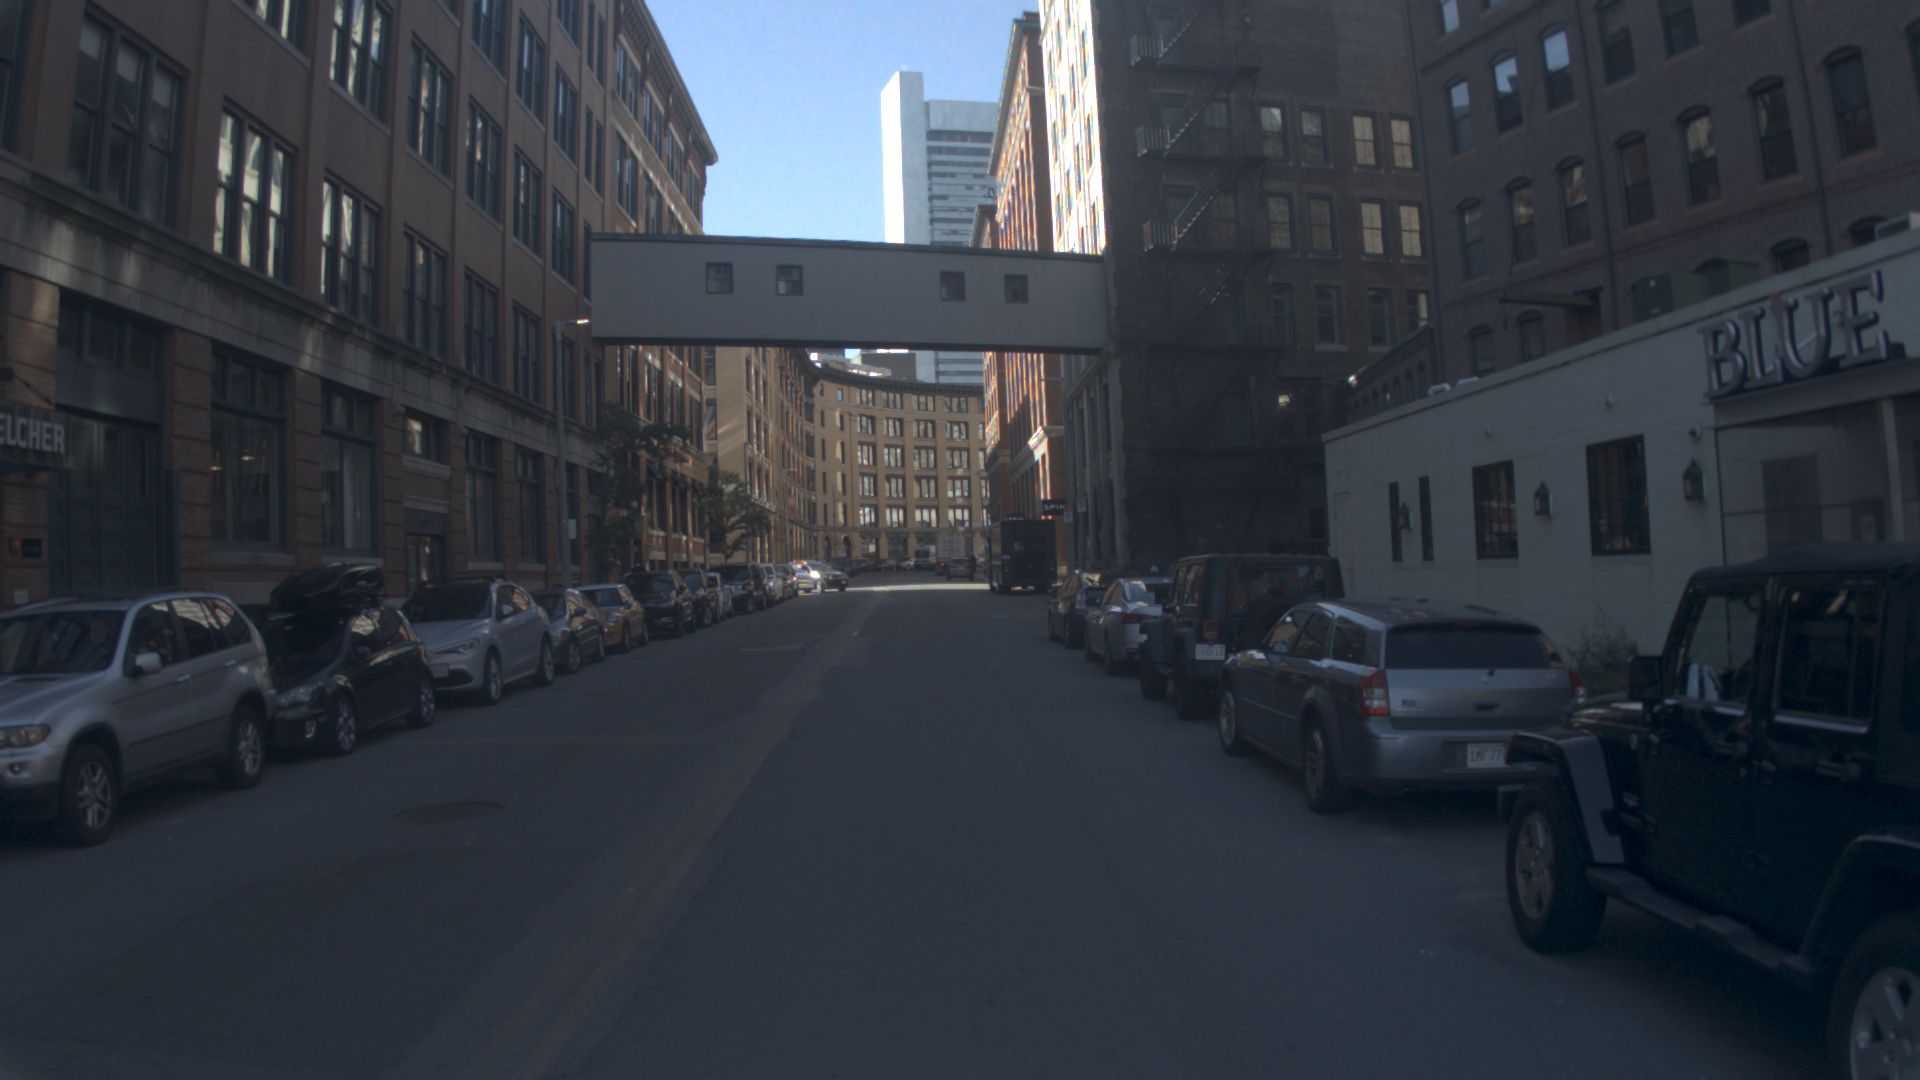
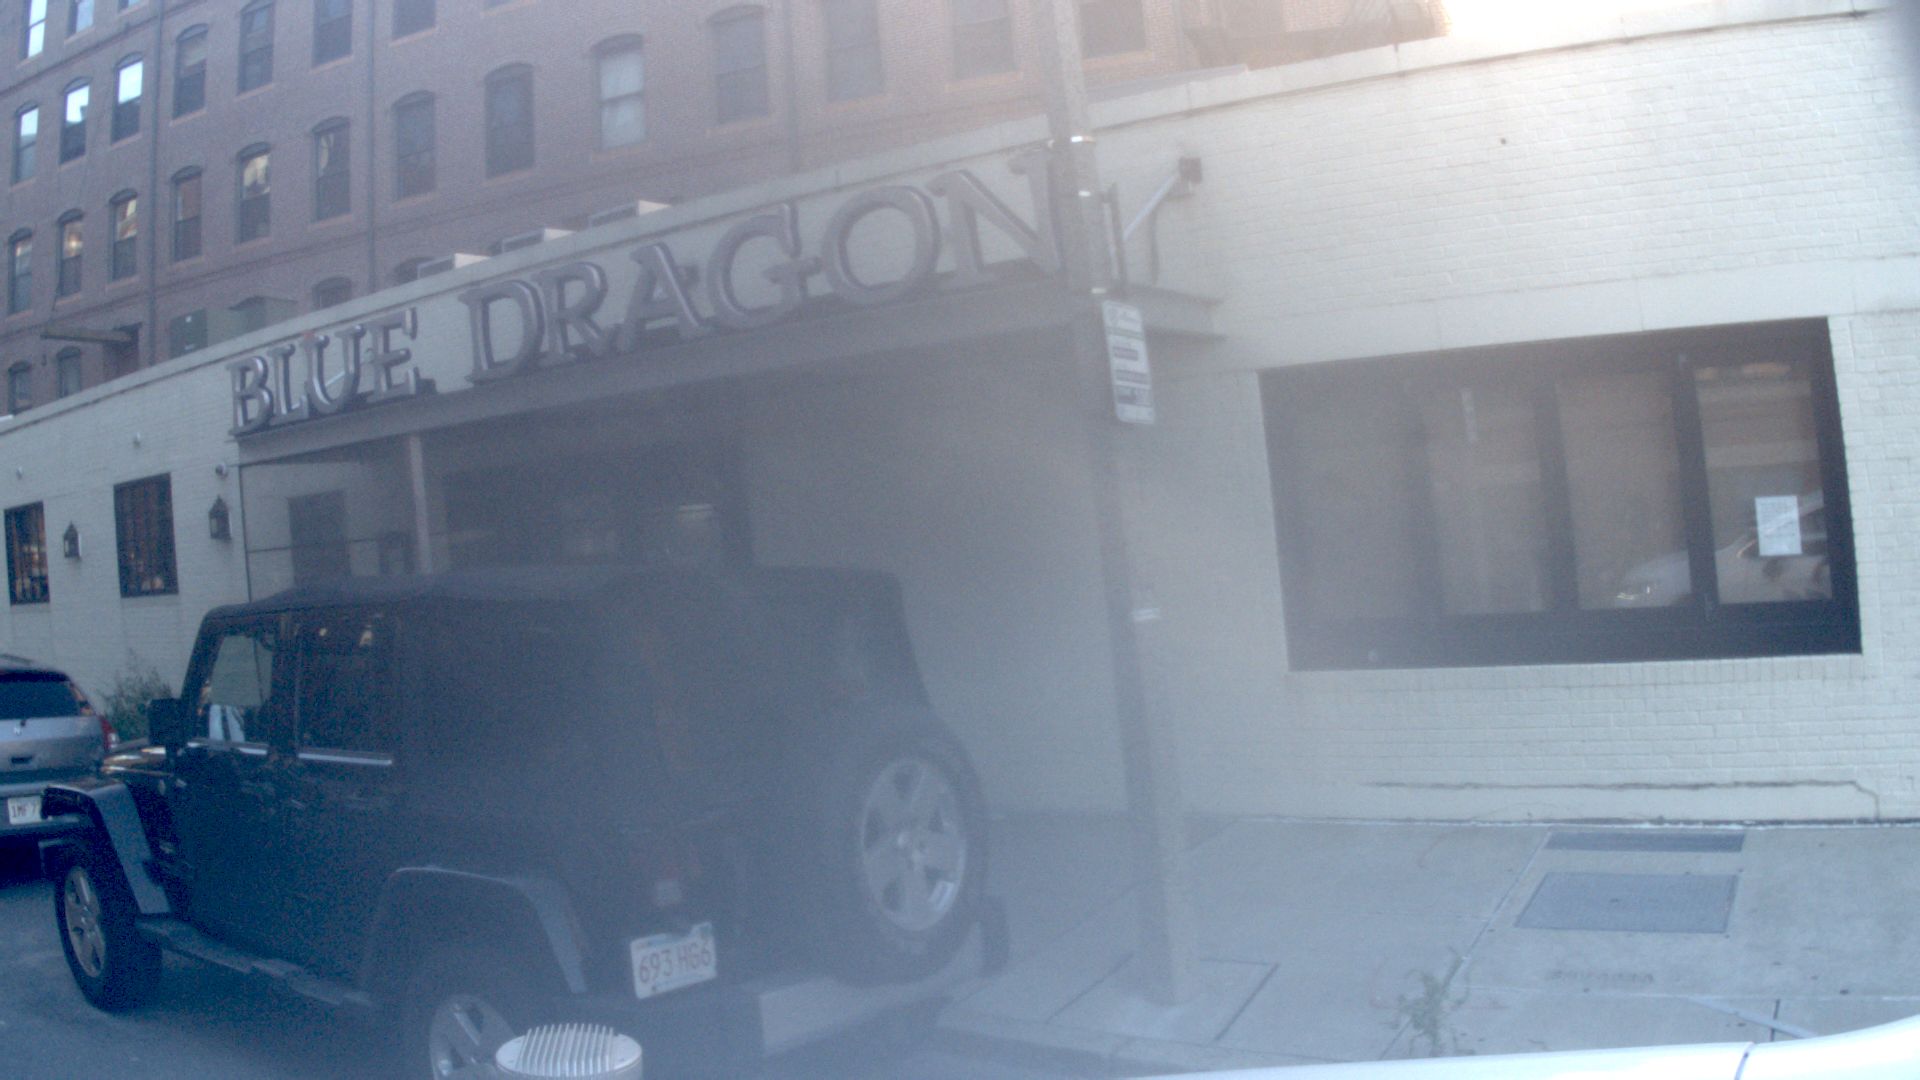
1 conflicting background vehicles were moved to clear holding positions for this counterfactual rehearsal. Original photos remain unchanged. Before later inpainting, any overlap with original-photo traffic must be resolved. Background positions in this 3D rehearsal are not an exact replay of the photographs.
After scene approval
The working pipeline will edit each original NAVSIM camera photograph with Image 2.5. Its same-time Higgsfield view will provide position and posture, annotated with facing direction and current speed. Temporal image requests will cover the full event with a 1 Hz base plus critical moments.
Assumptions and source provenance
- The pedestrian, distraction and motion are newly authored counterfactuals. Original Image 2 supports the brick streetscape, overhead connection and parked vehicles, not the proposed behavior.
- The police template is used only for its map and source photograph. No police encounter is imported into this scene.
- The south sidewalk path stays near y=-5.2; the lane pauses occur at y=-1. The return ends within the mapped south sidewalk at x=32.6, y=-5.5.
- Playback is finite and non-looping at 20 Hz from -7 through 40 s. Unexpected stopping means bounded deceleration, not a velocity discontinuity; use C1 interpolation with explicit stationary intervals.
- The supplied ground plane supports the human at z=0. Phone key heights compensate the plane gradient for the permanent local attachment offset.
- Ego is the simulator vehicle, approximately 4.6 by 1.85 m, stopped with its center at x=12, y=0 by -3 s. The nominal 15 s release is conditional on full buffered-corridor clearance.
- Exact curb geometry, photographed vehicle depths and pedestrian mental state are not established by the image. The proposal awaits human approval; its acceptance checks have not been executed.
Fresh GPT-6 motion plans use semantic descriptions from the pinned consolidated catalog and NAVSIM environments. No upstream nuPlan vectors, trajectories or images are used. The four source environments are reused; 82 scenario descriptions do not mean 82 independent locations.
Higgsfield revision 1. The portable GLB combines export clips without changing geometry or animation samples.
This review uses Higgsfield revision 1 and the exact exported scene snapshot.
Higgsfield workspace (latest revision) · Download animated GLB · GPT-6 scene plan · Visual review evidence · Motion checks · Approval status