MARSAD / CONSOLIDATED CATALOG / #017
Unleashed dog chases a startled cat into the lane
Awaiting your 3D scene approvalCounterfactual proposal: an unleashed dog walking ahead of its handler notices a cat. The startled cat crosses the road and the dog follows into ego's corridor. The handler follows, recalls the dog, and steadies it on the opposite sidewalk while the cat escapes farther east.
Original description: 前方有人在路边遛狗,狗未拴绳或绳子过长,突然追逐其他动物或行人而窜入车道。
Loading the full animated scene…
Critical moments
What to verify
- Verify exactly one handler, one dog, and one cat persist for all 941 samples; no leash, replacement animal, or off-screen disappearance is introduced.
- Verify the cat visibly initiates its escape before the dog begins pursuit and remains separated from the dog throughout.
- Verify the dog's curved departure and the cat's south-side turn remain continuous, grounded, and free of instantaneous heading changes.
- Verify the handler walks at 0.6–1.7 m/s apart from start and stop transitions and reaches the dog through the road rather than jumping between sidewalks.
- Verify the final handler and animal footprints fit the mapped south sidewalk, and the handler's hands meet the dog's shoulders without torso penetration.
- Verify ego holds at x=13 through 12 s; release requires the handler's established hold and clearance of the complete buffered corridor.
- Require human approval of the full chase, source-background conflicts, and the proposed 1 s review view before image generation.
Review notes
Reviewed dog and cat crossing trajectories and the handler following, recalling and crouching beside the dog. Both animals are persistent and distinct, with the cat in front of the pursuing dog. Procedural animal silhouettes are coarse.
Check action, relative position, facing, posture and visibility. Approximate offsets are acceptable. Sampled visual checks do not prove every contact or continuous collision clearance.
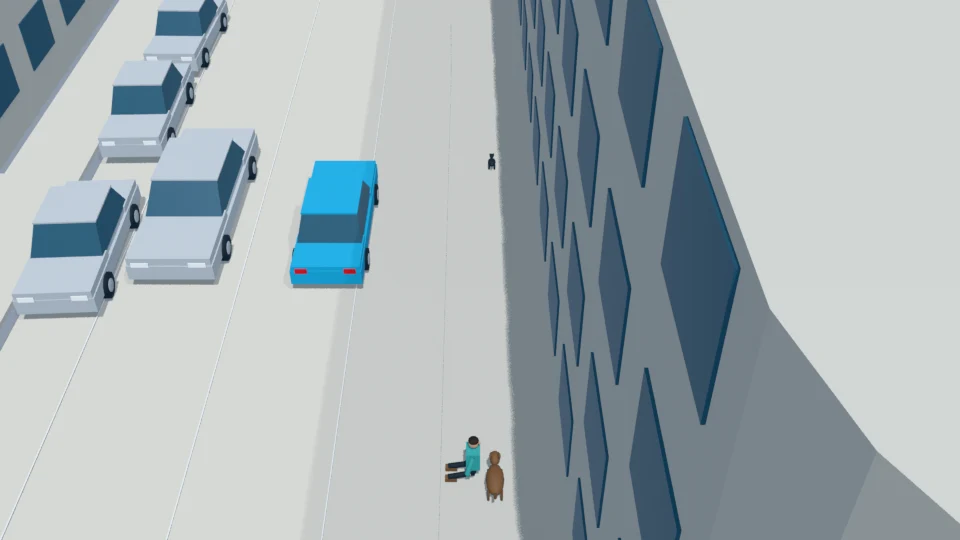
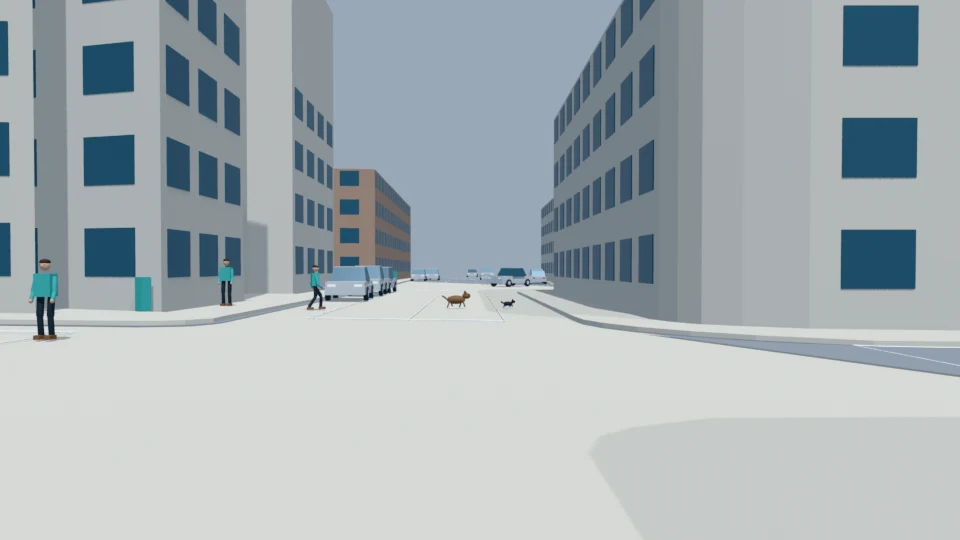
Rendered inspection views
Event, approach and final views rendered from the exact committed Higgsfield Blender source. These are procedural 3D previews, not generated training photographs.
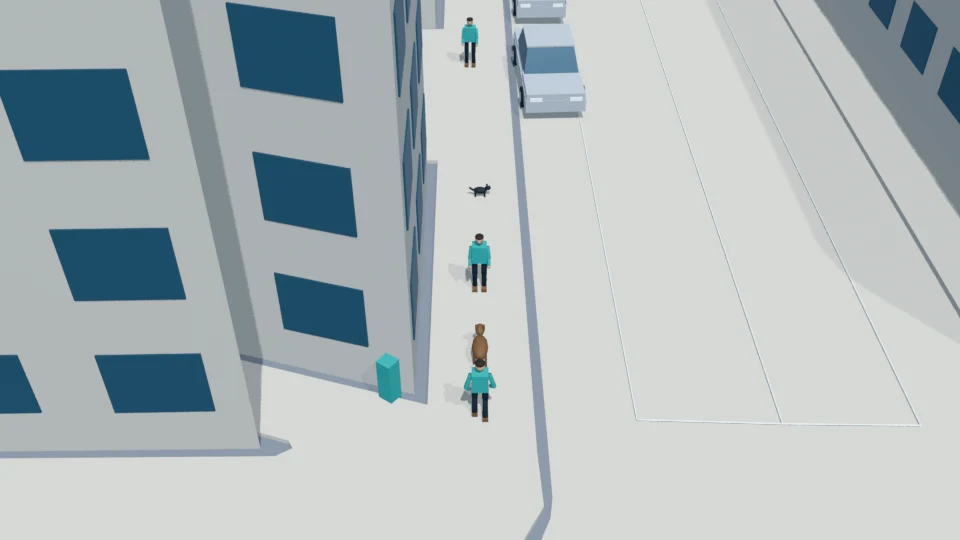
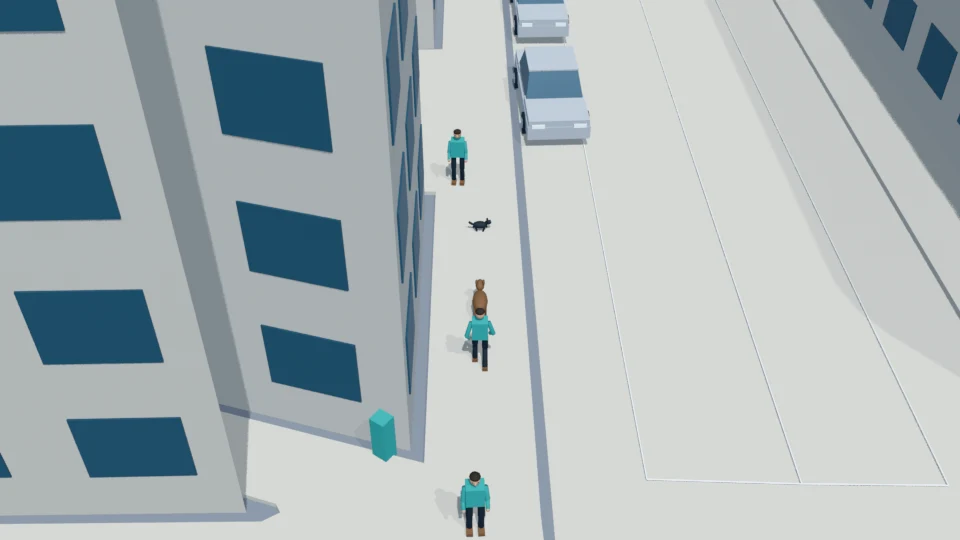
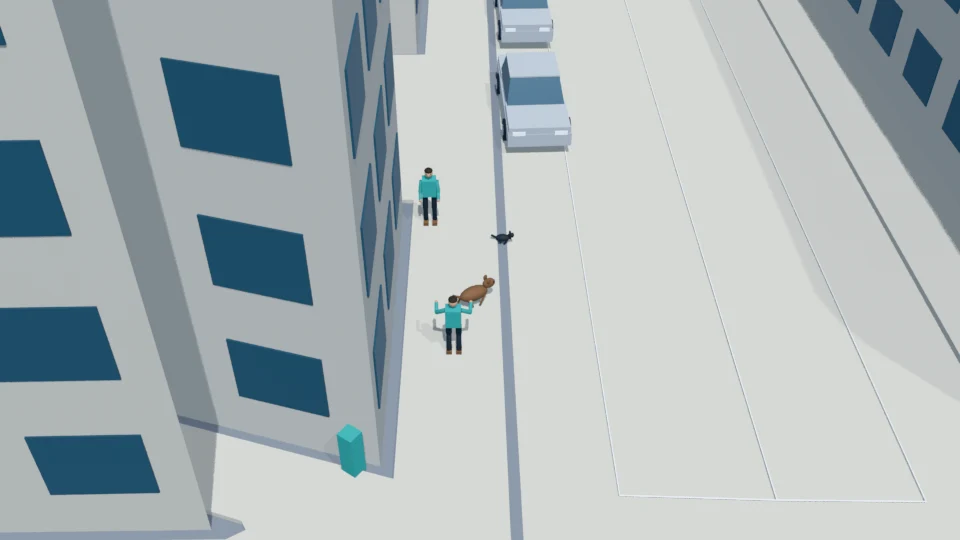
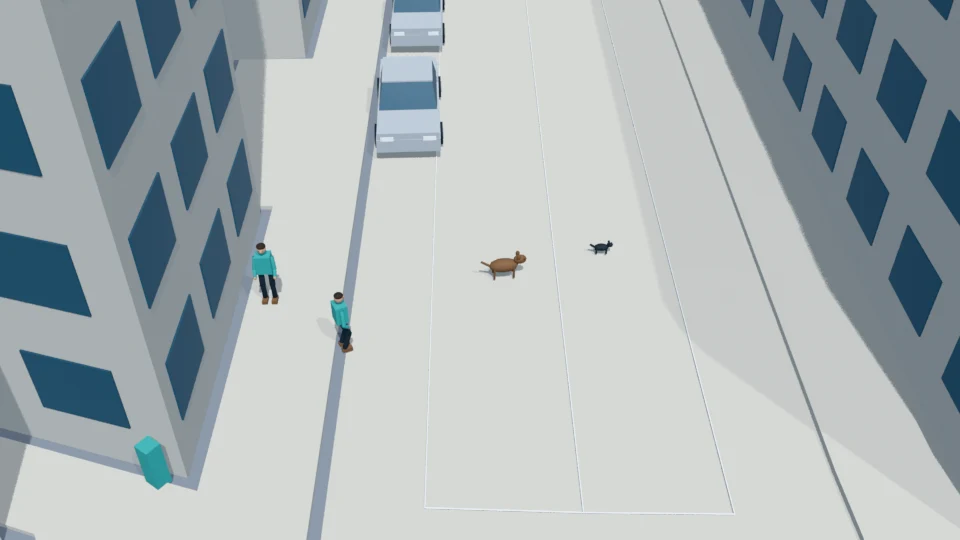
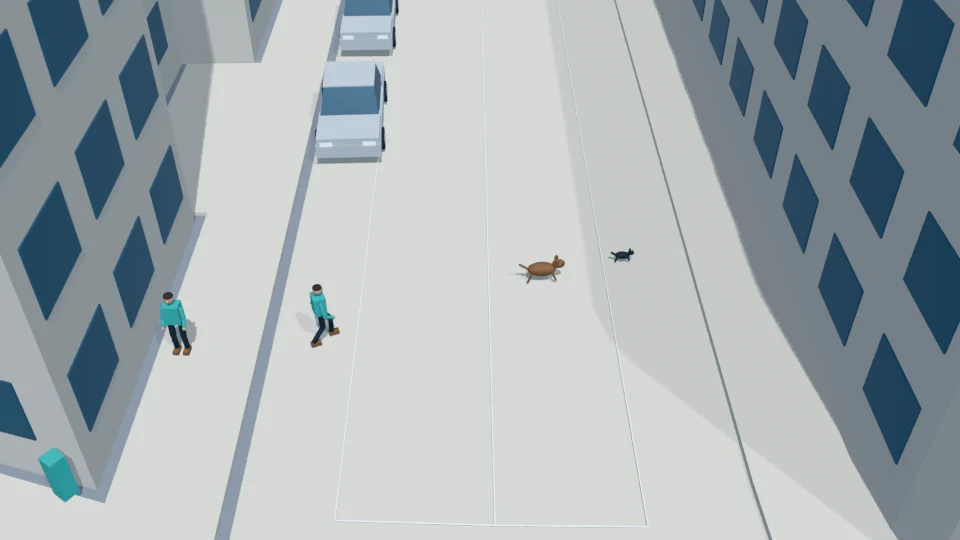
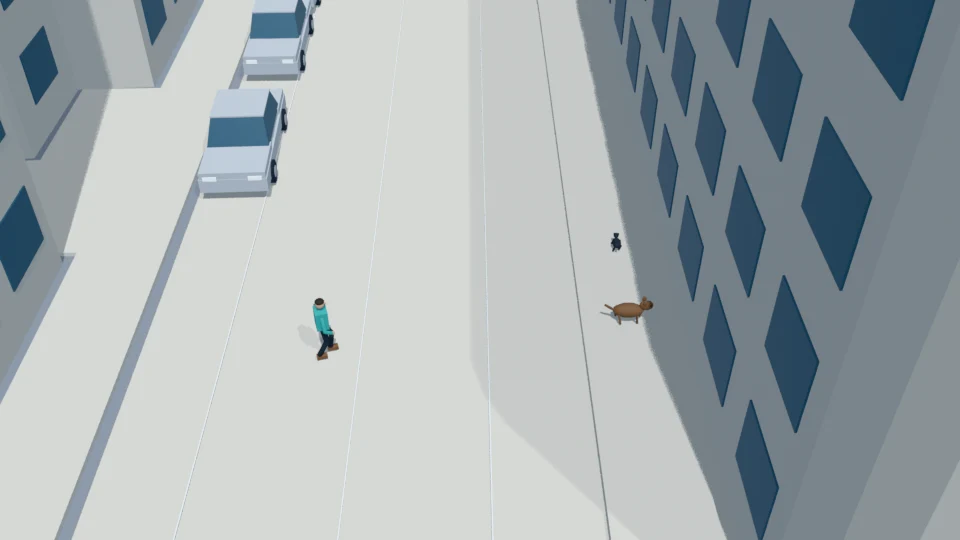
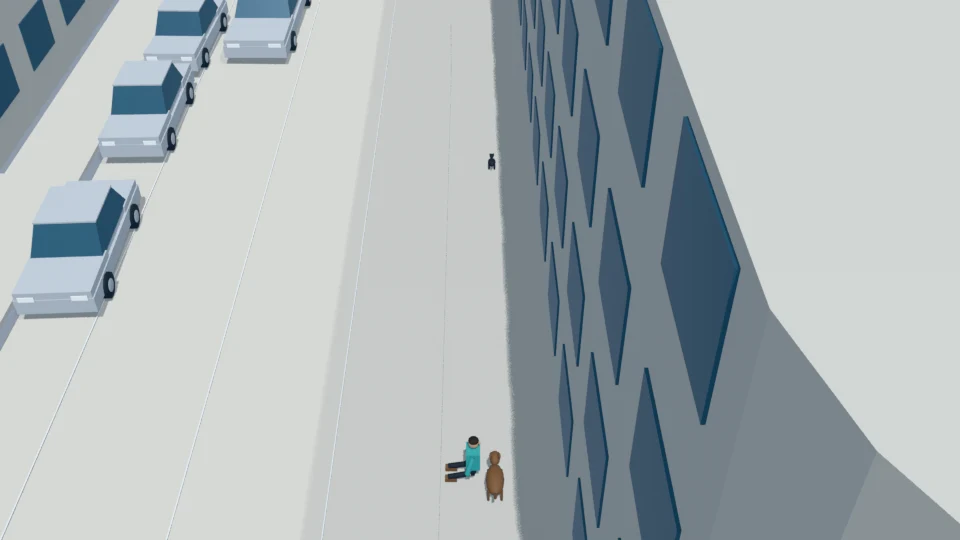
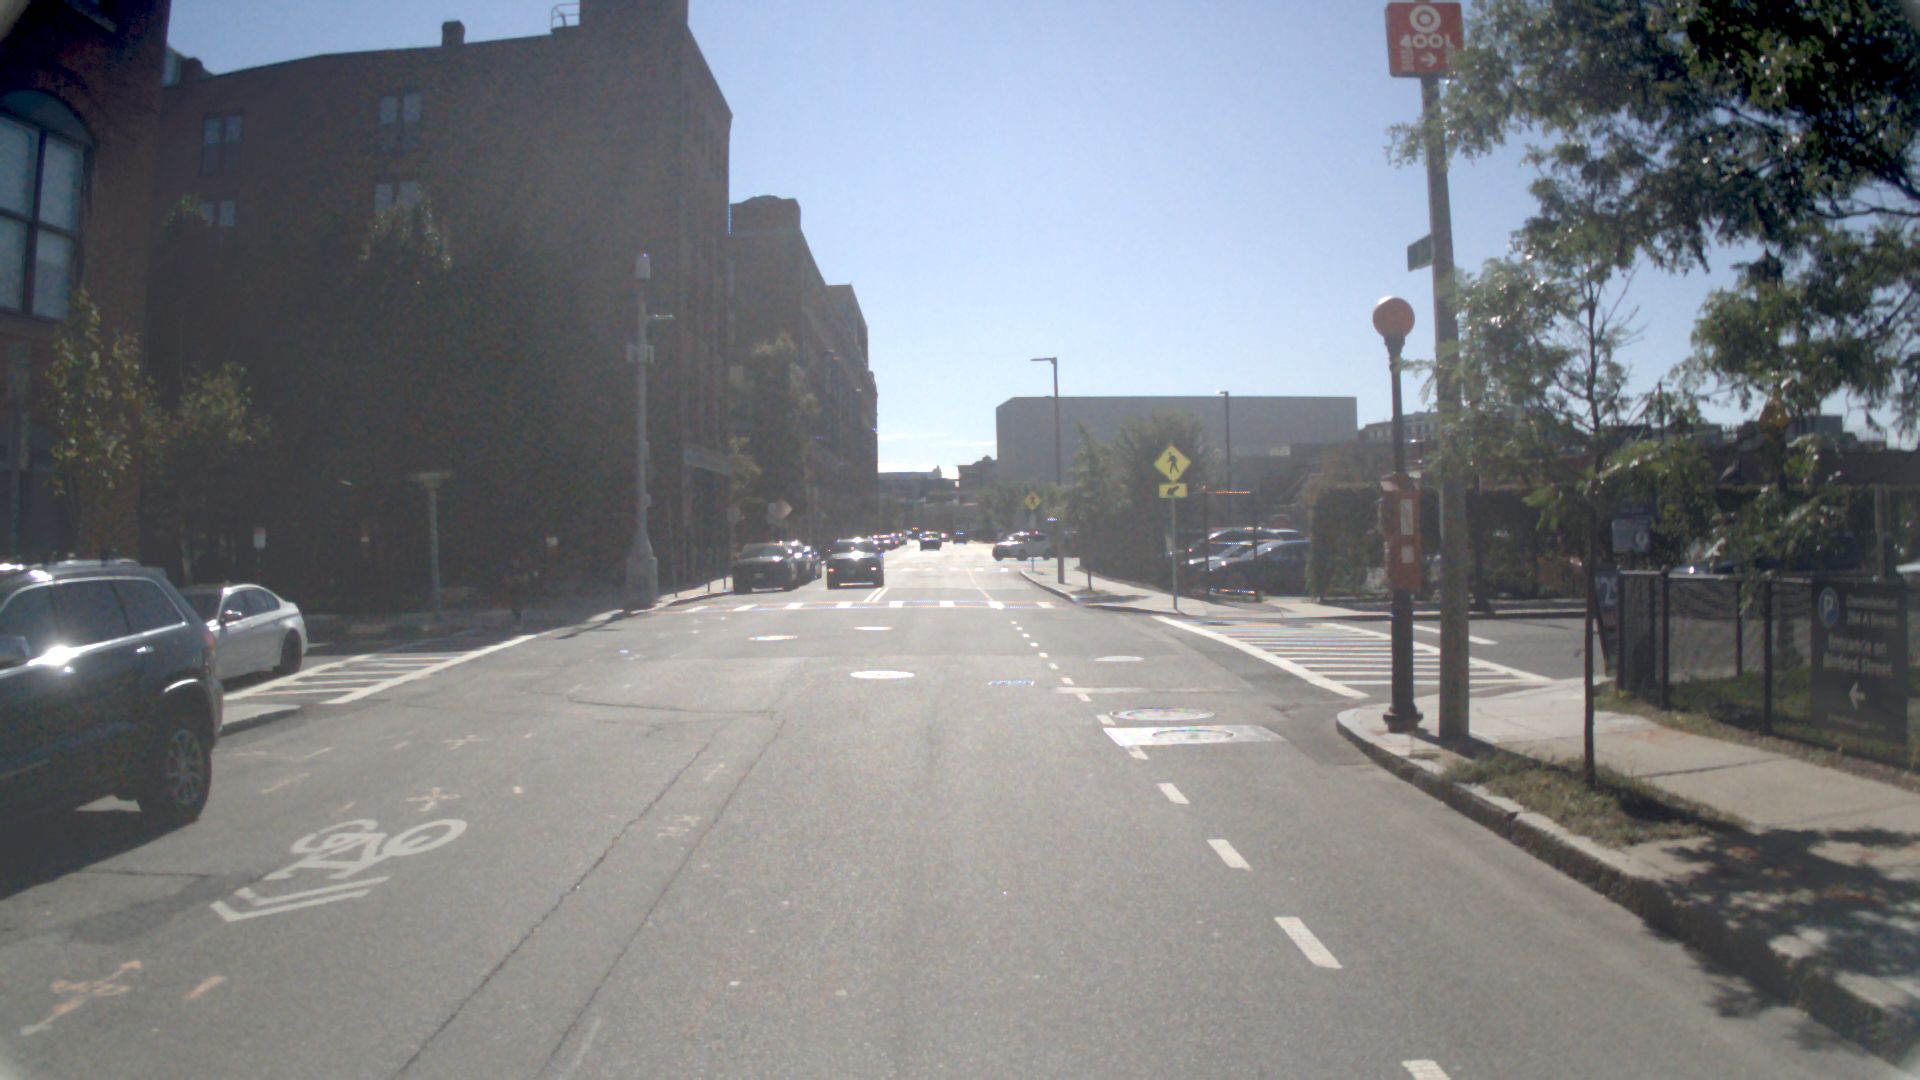
Original NAVSIM camera context
4 conflicting background vehicles were moved to clear holding positions for this counterfactual rehearsal. Original photos remain unchanged. Before later inpainting, any overlap with original-photo traffic must be resolved. Background positions in this 3D rehearsal are not an exact replay of the photographs.
After scene approval
The working pipeline will edit each original NAVSIM camera photograph with Image 2.5. Its same-time Higgsfield view will provide position and posture, annotated with facing direction and current speed. Temporal image requests will cover the full event with a 1 Hz base plus critical moments.
Assumptions and source provenance
- Image #4 supplies intersection architecture, roadway, and sidewalk context. The handler, dog, cat, and chase are counterfactual additions, not observed animals or behavior.
- Playback spans -7 through 40 s inclusive at 20 Hz, producing 941 samples without looping. Use bounded C1 motion, rounded tangent-aligned turns, smooth acceleration and braking, and exact final holds. All support roots remain at z=0.
- The north sidewalk near x=39 to 47 lies around y=7.5 to 9.9; the south sidewalk near x=46 to 59 lies around y=-5.2 to -3.1. The cat's escape extends beyond the usual work area while remaining on this supplied map.
- This explicitly selects the unleashed variant of the request. The final two-handed hold is proposed physical control, not an unexplained new tether.
- Ego is supplied by a separate controller: 4.5 m long, 1.9 m wide, y=0, starting at x=5 at -7 s with speed 4 m/s and stopping smoothly at x=13 by -3 s. Its buffered corridor is y=-1.5 to 1.5; after release it may accelerate smoothly to 2 m/s.
- Background vehicle footprints and precise curb geometry require human confirmation. Approval is pending; later Image 2.5 must edit original Image #4 using this rehearsal only for position and posture.
Fresh GPT-6 motion plans use semantic descriptions from the pinned consolidated catalog and NAVSIM environments. No upstream nuPlan vectors, trajectories or images are used. The four source environments are reused; 82 scenario descriptions do not mean 82 independent locations.
Higgsfield revision 1. The portable GLB combines export clips without changing geometry or animation samples.
This review uses Higgsfield revision 1 and the exact exported scene snapshot.
Higgsfield workspace (latest revision) · Download animated GLB · GPT-6 scene plan · Visual review evidence · Motion checks · Approval status