MARSAD / CONSOLIDATED CATALOG / #019
Recently alighted pupils dart around a stopped school bus
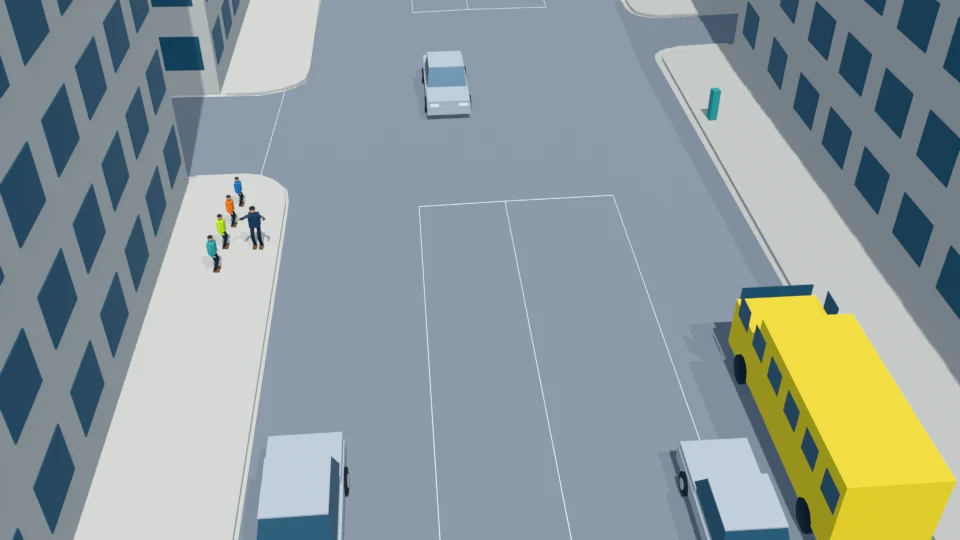
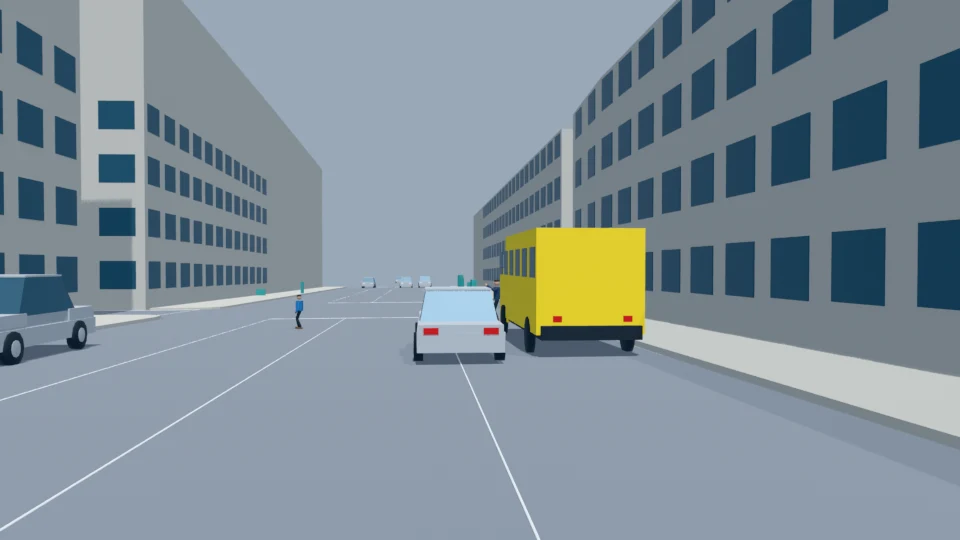
Awaiting your 3D scene approvalCounterfactual proposal: four recently alighted pupils walk along the curb side of a stopped school bus. The leader abruptly runs around its front, and the others follow in a staggered burst across ego's path. A supervisor follows and regroups them on the north sidewalk. The bus remains partly in ego's corridor with warning lamps active, so ego does not resume.
Original description: 前方校车停靠在路边,一群学童从车上下来后,在车前或车后突然窜出。
Loading the full animated scene…
Critical moments
What to verify
- Verify exactly one school bus, four individually identified pupils, and one supervisor persist through all 941 samples.
- Verify all four pupils are visibly present outside the bus at -7 s; none spawns at the door, traverses the bus body, disappears, or duplicates.
- Verify the bus footprint remains wholly on the cargo road polygon and every pupil rounds its front with positive body clearance.
- Verify the walking queue maintains at least 0.6 m body separation, the two-second stagger persists through the dash, and the final waiting positions do not overlap.
- Verify walking phases remain within 0.6–1.7 m/s and running phases within 2–4 m/s apart from smooth gait transitions; rounded turns must not create instantaneous heading flips.
- Verify the bus creates real front-corner occlusion from ego's viewpoint while allowing continuous emergence; human review must confirm this against the original camera.
- Verify all final pedestrian footprints fit the north sidewalk, but do not infer ego clearance: the bus still intersects the buffered corridor and remains stopped with warning lamps active.
- Verify ego stays at x=12 through 40 s with ego_release_s=-1, and require human approval before image generation.
Review notes
Inspected the full event sequence. Four pupils emerge around the parked bus front, cross with staggered timing, and regroup with the supervisor on the far sidewalk. The parked bus remains and the early camera occlusion is intentional.
Check action, relative position, facing, posture and visibility. Approximate offsets are acceptable. Sampled visual checks do not prove every contact or continuous collision clearance.
Rendered inspection views
Event, approach and final views rendered from the exact committed Higgsfield Blender source. These are procedural 3D previews, not generated training photographs.
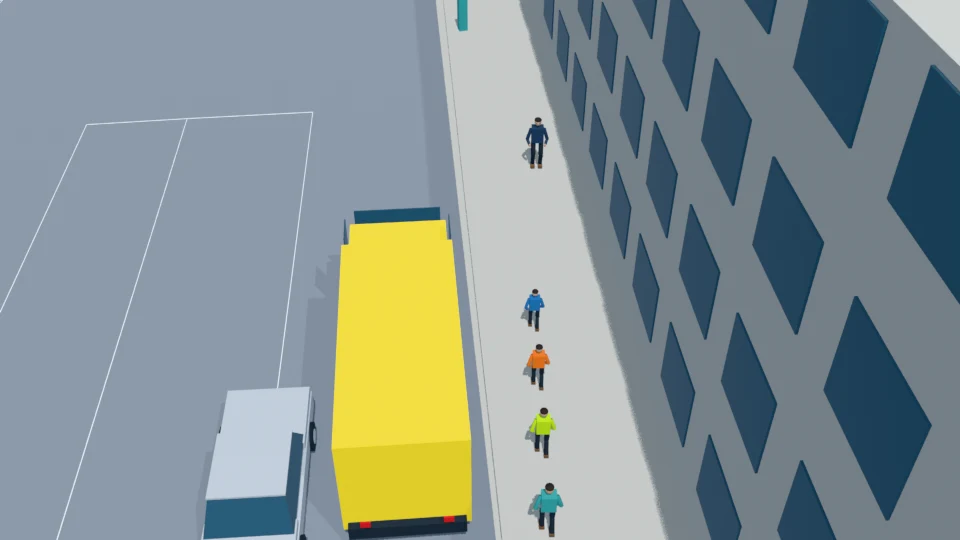
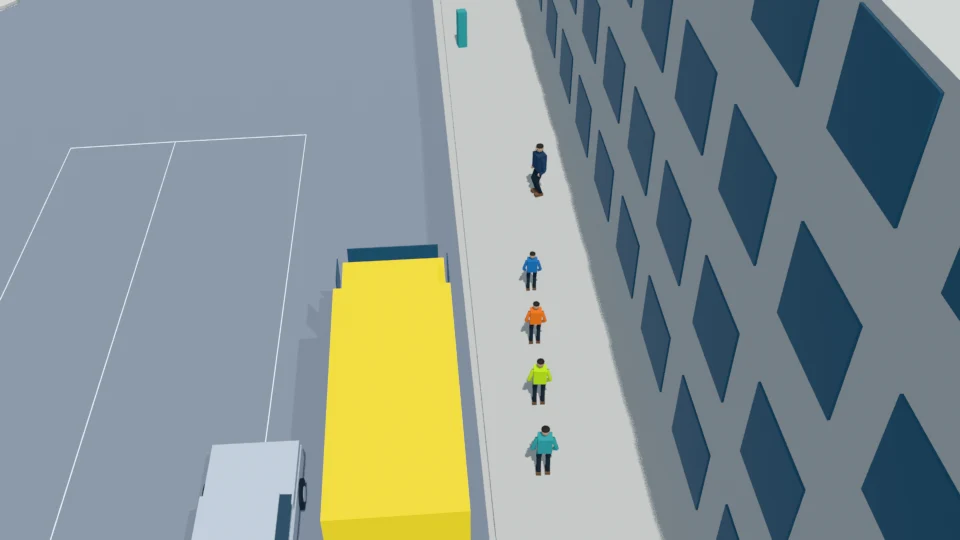
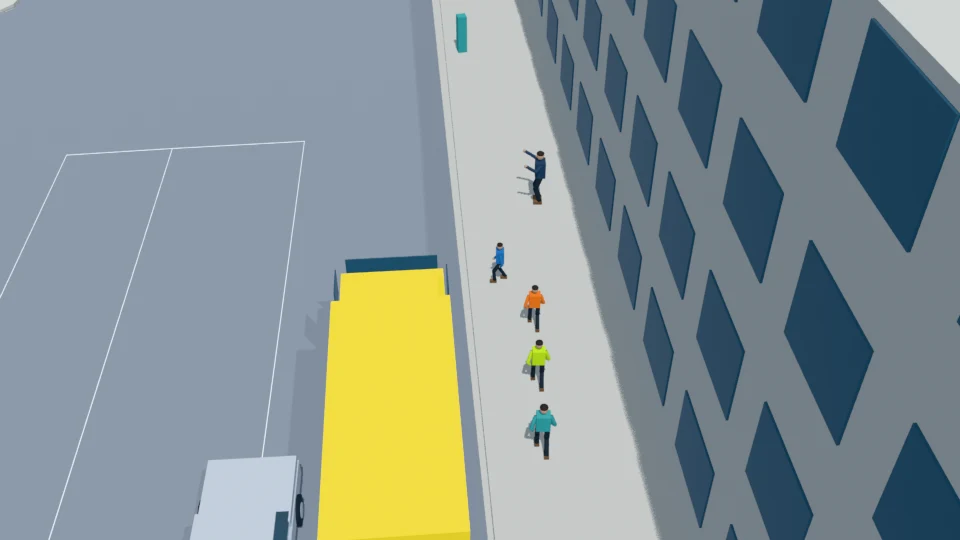
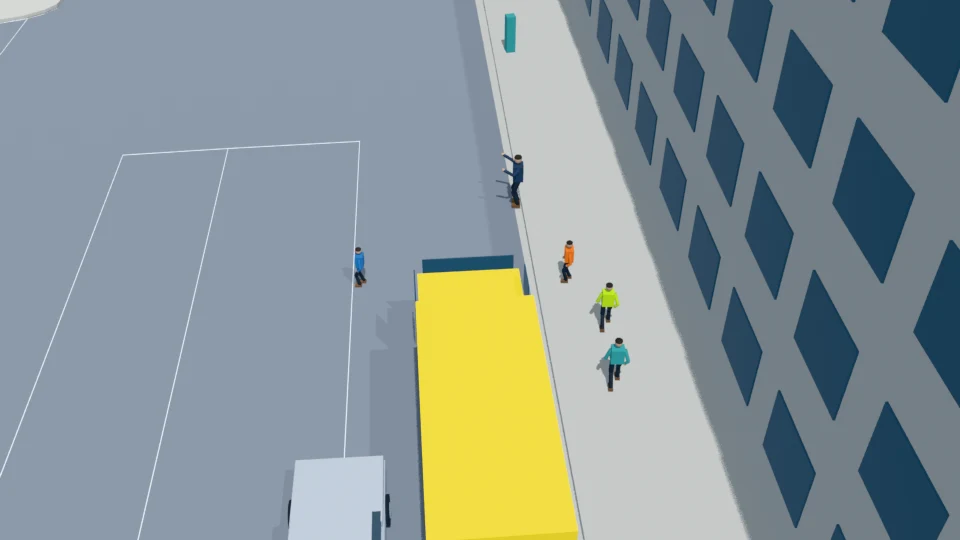
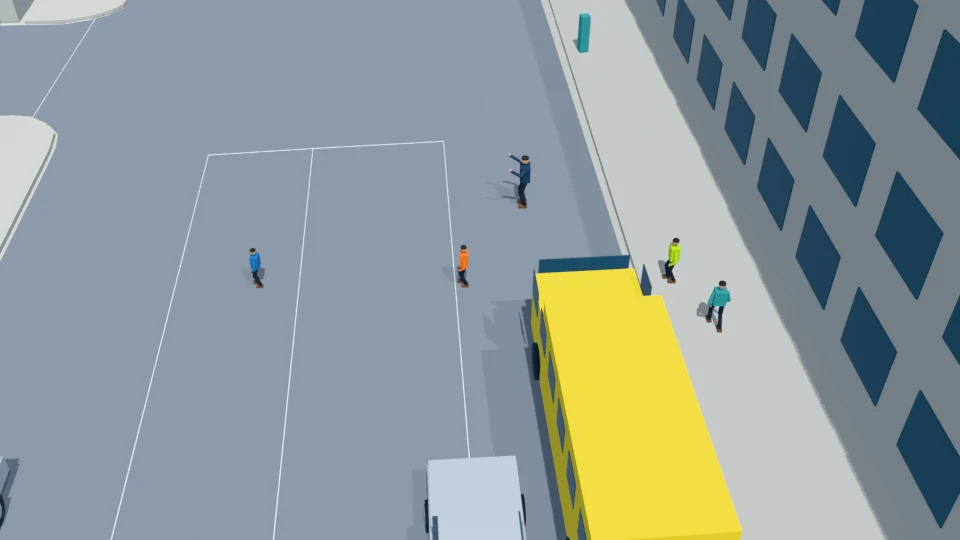
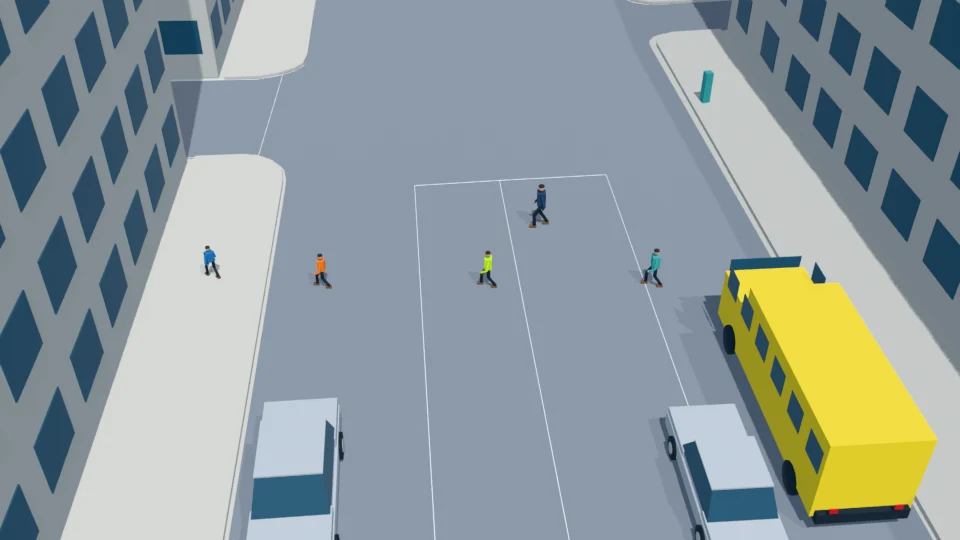
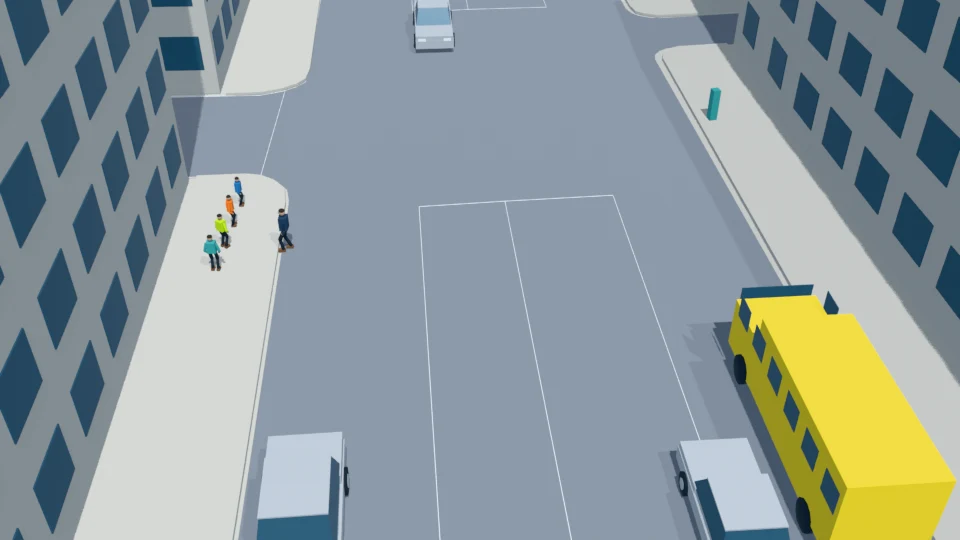
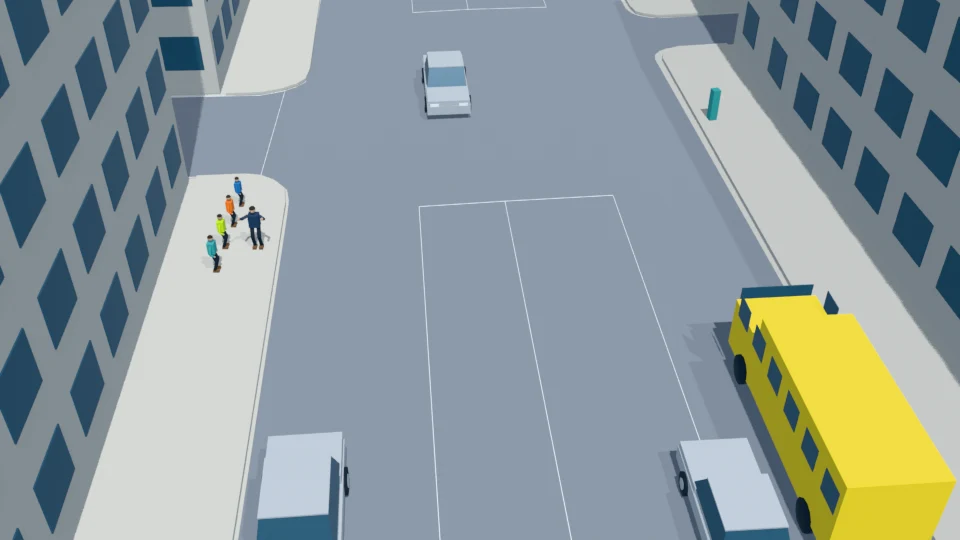
Original NAVSIM camera context
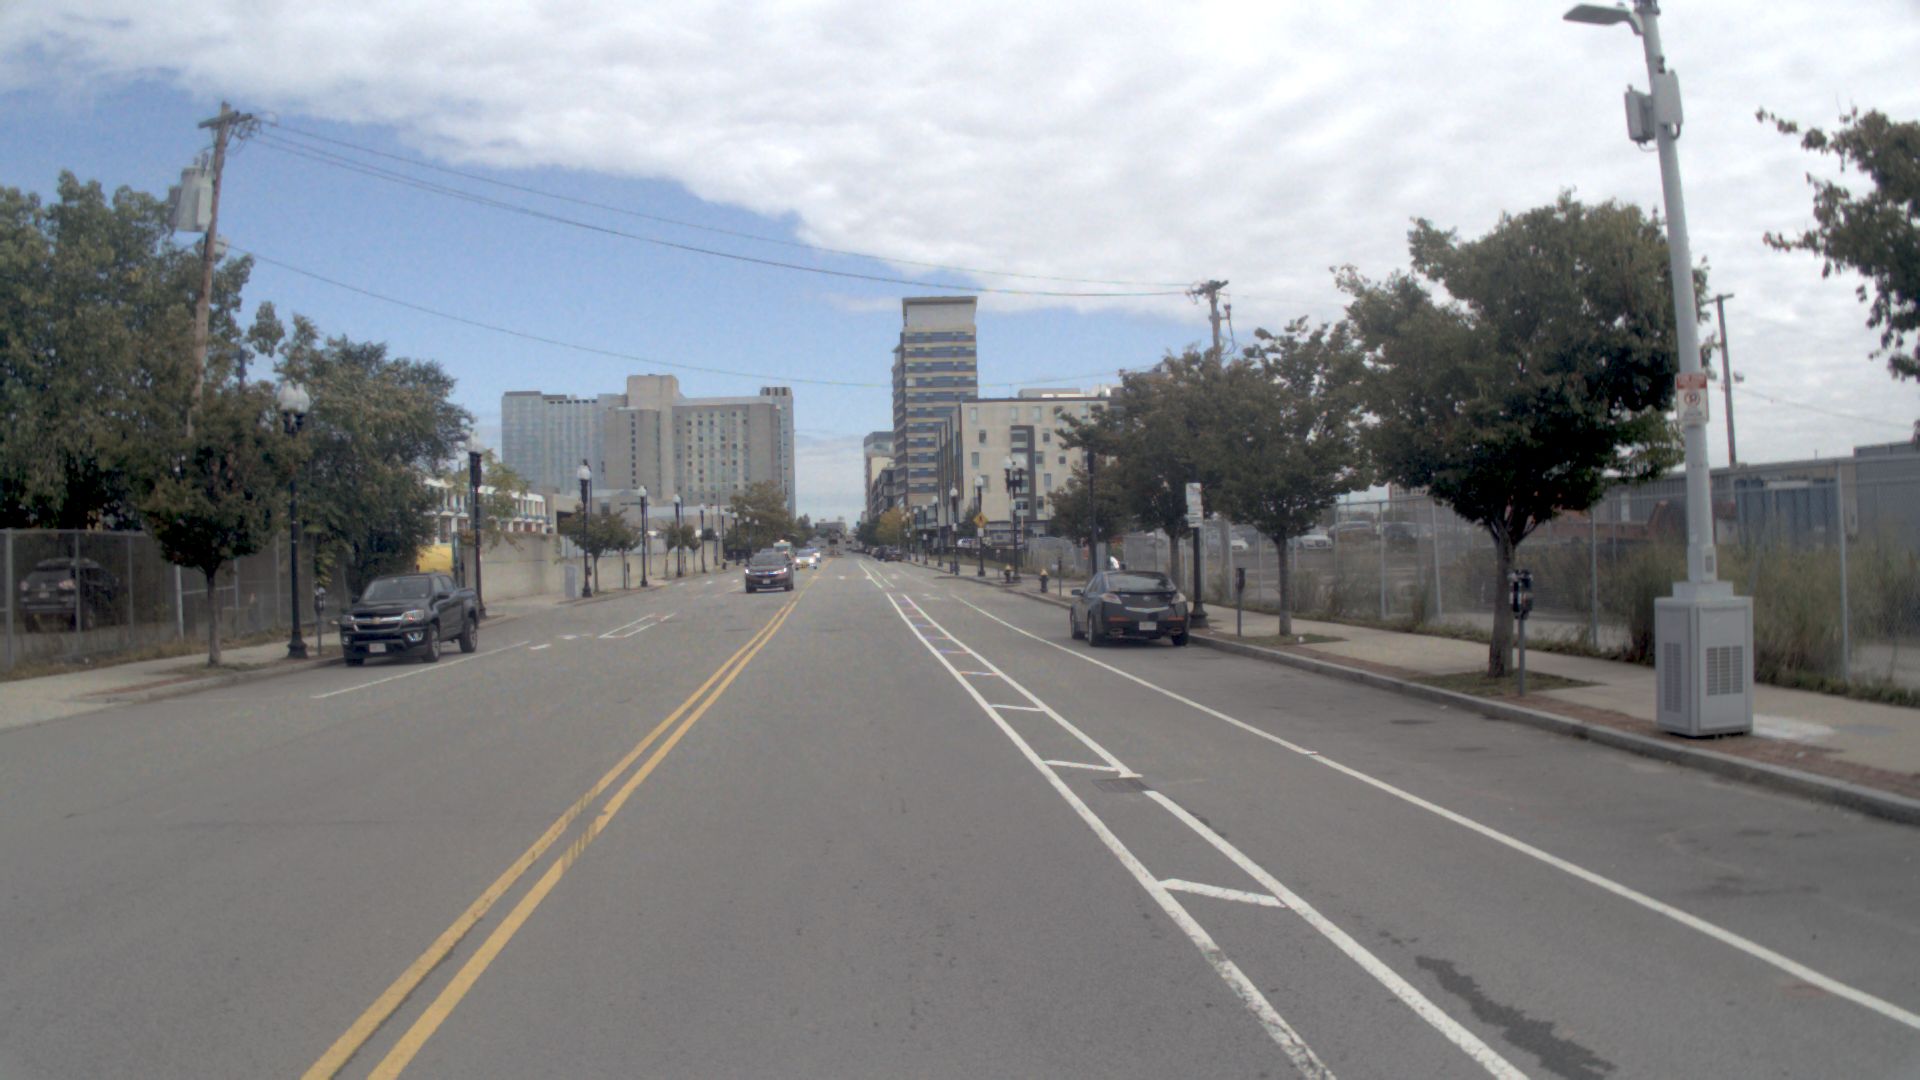
5 conflicting background vehicles were moved to clear holding positions for this counterfactual rehearsal. Original photos remain unchanged. Before later inpainting, any overlap with original-photo traffic must be resolved. Background positions in this 3D rehearsal are not an exact replay of the photographs.
After scene approval
The working pipeline will edit each original NAVSIM camera photograph with Image 2.5. Its same-time Higgsfield view will provide position and posture, annotated with facing direction and current speed. Temporal image requests will cover the full event with a 1 Hz base plus critical moments.
Assumptions and source provenance
- Image #3 supplies the broad street, marked roadway strips, fences, trees, and parked-car context. The school bus, pupils, supervisor, and all motion are counterfactual additions rather than observed events.
- The unspecified group is instantiated as exactly four pupils and one supervisor. All four completed disembarkation before -7 s and begin already outside the bus, lining up beside its curb side; this avoids invented interior geometry, stair-height jumps, or concealed spawning.
- Playback covers -7 through 40 s inclusive at 20 Hz: 941 samples, finite and non-looping. Use bounded C1 trajectories, approximately rounded 0.8 m corner turns, smooth gait transitions, and exact stationary final holds.
- The bus follows the supplied cargo map's sloping south curb at heading 4.65 degrees. The pupils approach along y=-5.3, cross at x=41 beyond the bus nose, and regroup at y=15.8 inside the mapped north sidewalk. All standing and wheeled support roots use z=0.
- Ego is separate from the six listed actors: 4.5 m long, 1.9 m wide, y=0, starting at x=4 at -7 s with speed 4 m/s and stopping smoothly at x=12 by -3 s. The buffered corridor is y=-1.5 to 1.5.
- The school bus intentionally remains stopped for the entire rehearsal. Its front-side footprint intrudes into the ego corridor, so pedestrian clearance alone cannot authorize resumption. No bus departure or overtaking maneuver is invented.
- The bus door and lamps are integral rigged components; no additional pupils, bags, or freestanding stop-sign props are assumed. Background parked-vehicle footprints and exact occlusion require human review.
- Approval is pending. Later Image 2.5 must edit original Image #3, preserving source architecture and using this rehearsal only for actor position and posture.
Fresh GPT-6 motion plans use semantic descriptions from the pinned consolidated catalog and NAVSIM environments. No upstream nuPlan vectors, trajectories or images are used. The four source environments are reused; 82 scenario descriptions do not mean 82 independent locations.
Higgsfield revision 1. The portable GLB combines export clips without changing geometry or animation samples.
This review uses Higgsfield revision 1 and the exact exported scene snapshot.
Higgsfield workspace (latest revision) · Download animated GLB · GPT-6 scene plan · Visual review evidence · Motion checks · Approval status