MARSAD / CONSOLIDATED CATALOG / #024
Slow recycling cart with an obstructed forward view
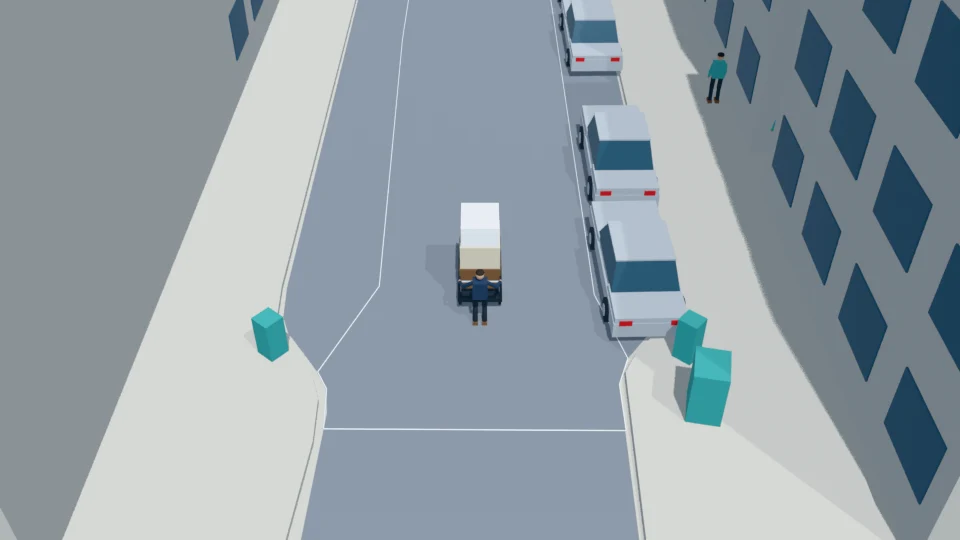
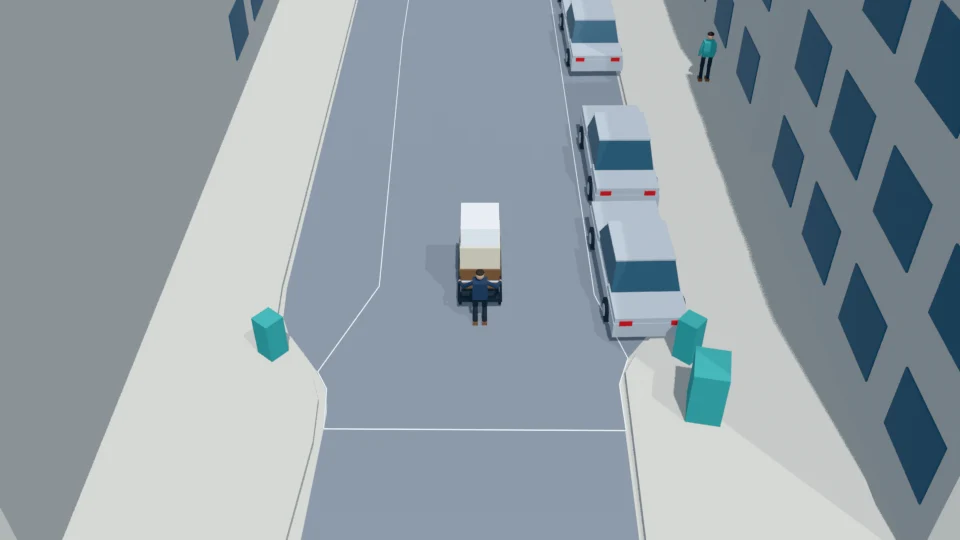
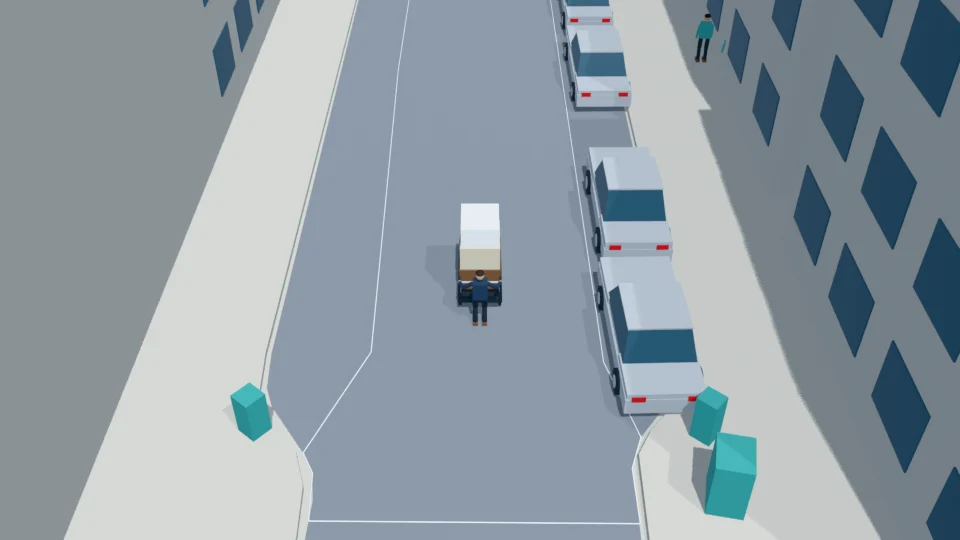
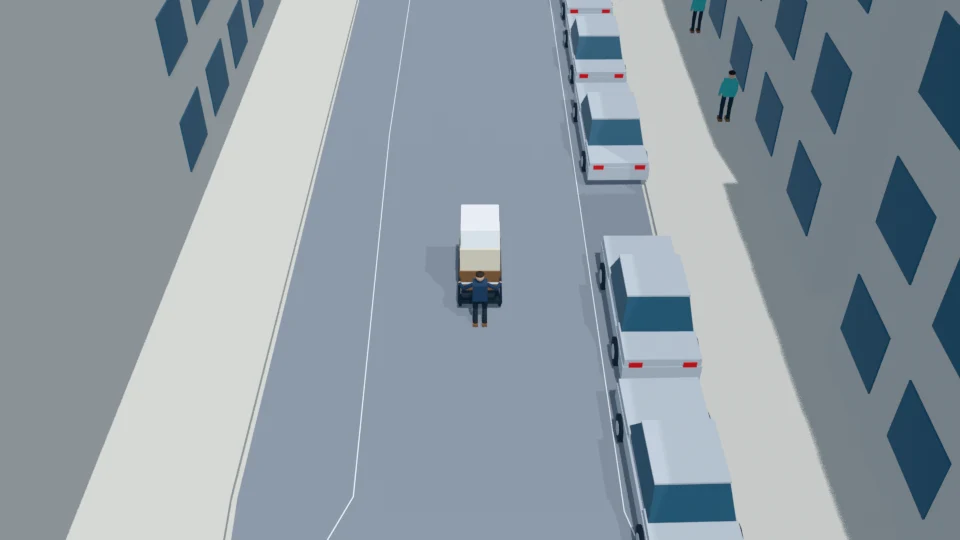
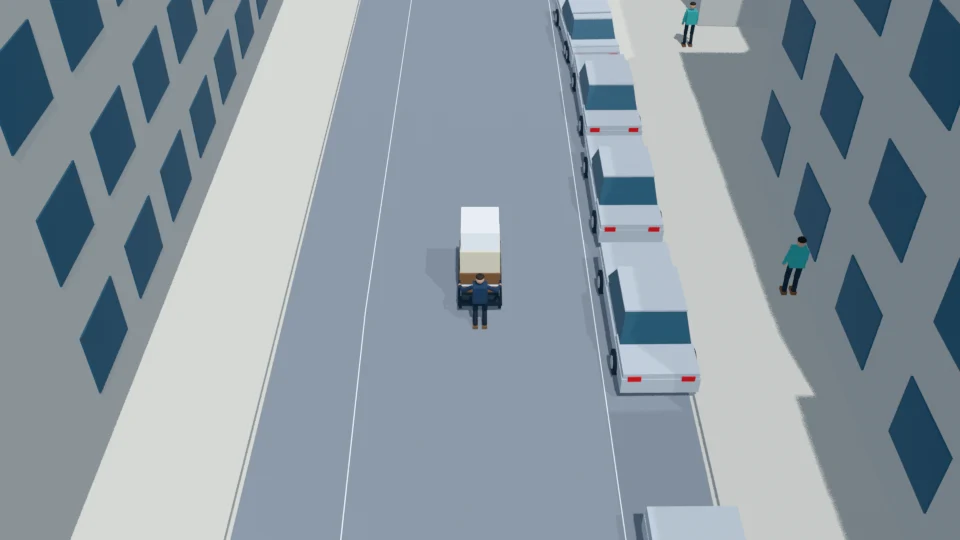
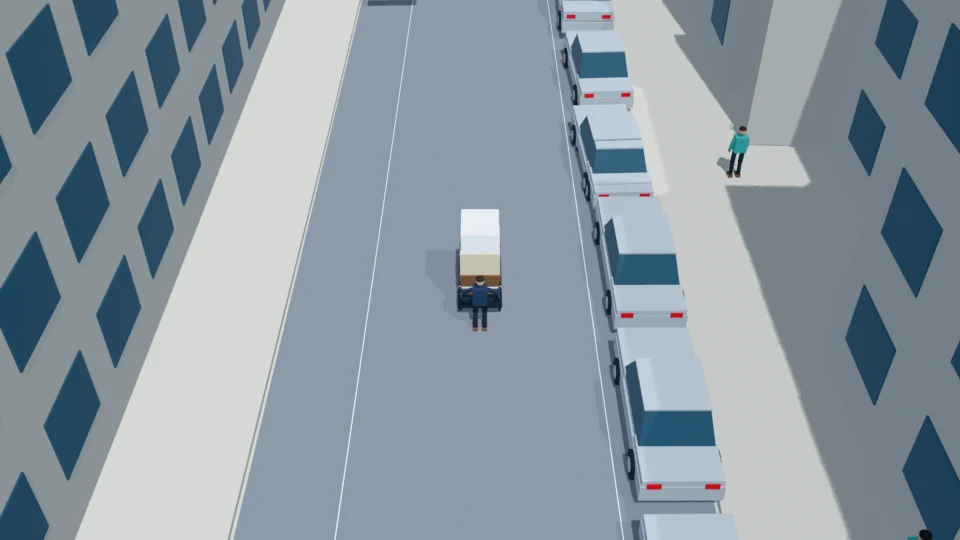
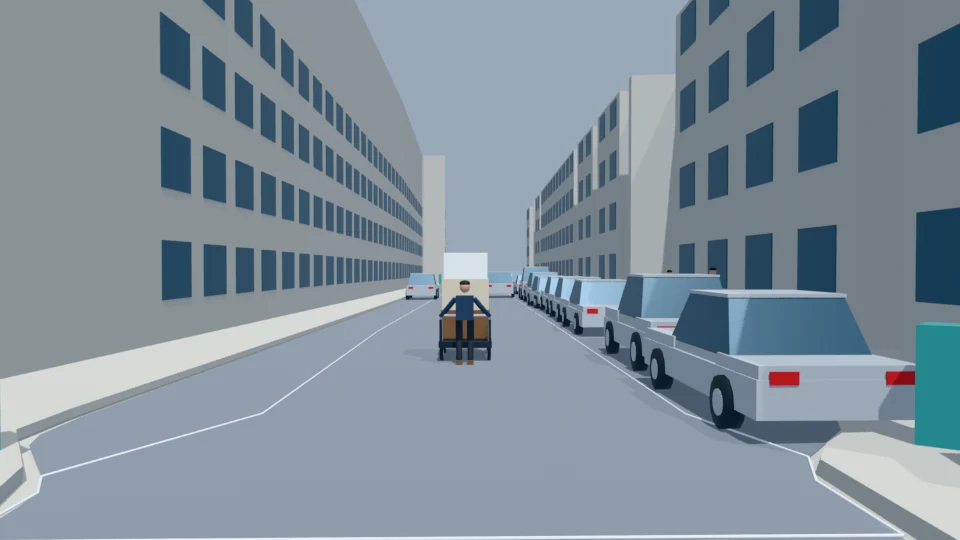
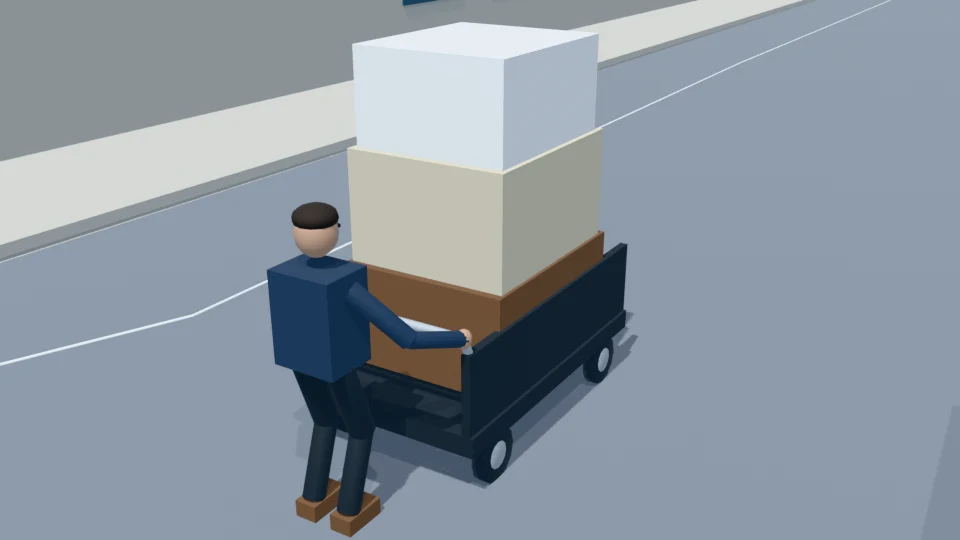
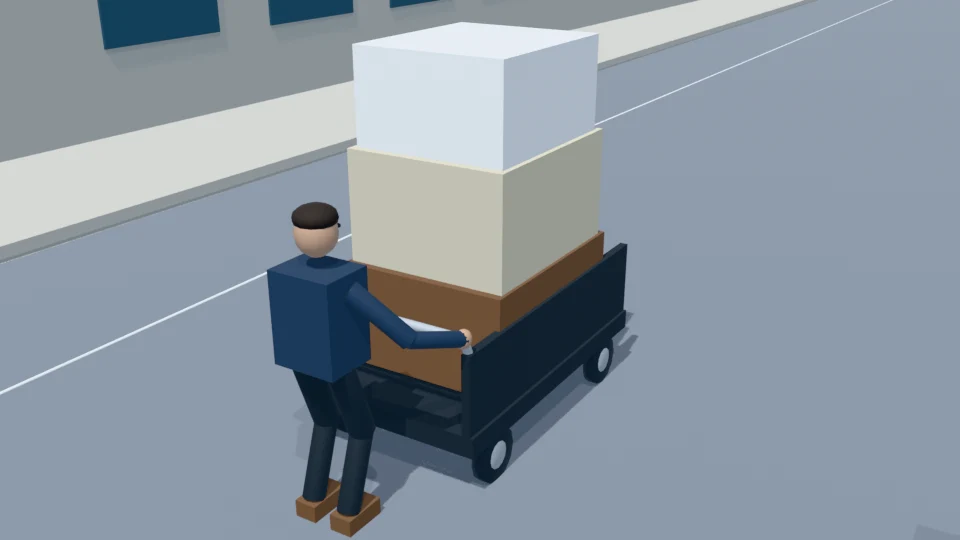
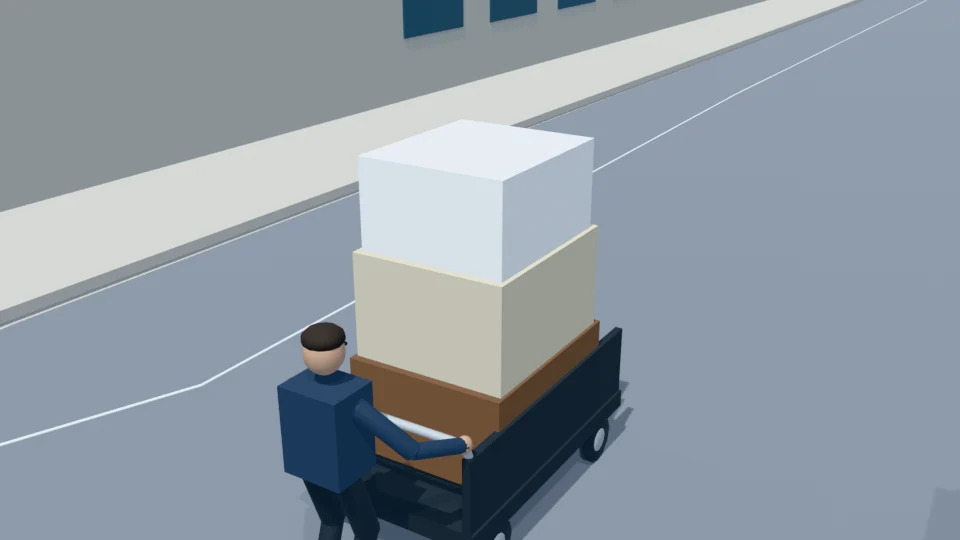
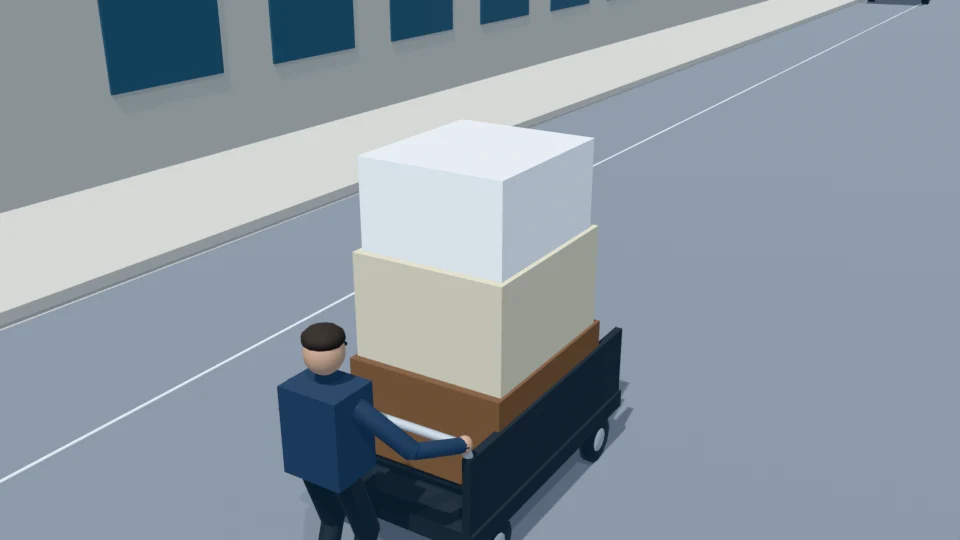
Awaiting your 3D scene approvalCounterfactual: A recycling collector slowly pushes a heavily loaded cart east through the ego corridor. The secured stack rises above the collector's eyes and obstructs the direct forward view. The collector eventually pauses without clearing the lane.
Original description: 前方有拾荒者推着满载回收物的小车,车上物品堆积过高,遮挡其视线,且行进缓慢。
Loading the full animated scene…
Critical moments
What to verify
- Exactly five critical actors persist: one collector, one operator-free cart, and three separately identified recycling bundles.
- Sample the complete interval from -7 through 40 seconds at 20 Hz, including both endpoints; all tracks remain finite and non-looping.
- Verify cart and collector footprints remain on the wheelchair road polygon, with wheel and standing-human support offsets equal to zero.
- Verify hand-to-handle contact throughout pushing and resting, with no torso penetration into the cart.
- Verify the three load layers touch their supports without overlap, remain attached, and obstruct the collector's direct forward eye-level view.
- Maintain slow walking motion near 0.6 m/s, with smooth acceleration and deceleration at the two rests.
- The cart footprint intersects the buffered ego corridor throughout; ego must remain at x=14 through time 40.
- Require human approval of the full rehearsal, especially time 7, before image generation. Later Image 2.5 must edit original Image #1, using this rehearsal only for placement and posture.
Review notes
Inspected the loaded cart sequence. The stacked load blocks the pushing adult’s forward view; hands align with the cart handle and the cart follows the slow crossing path.
Check action, relative position, facing, posture and visibility. Approximate offsets are acceptable. Sampled visual checks do not prove every contact or continuous collision clearance.
Rendered inspection views
Event, approach and final views rendered from the exact committed Higgsfield Blender source. These are procedural 3D previews, not generated training photographs.
Original NAVSIM camera context
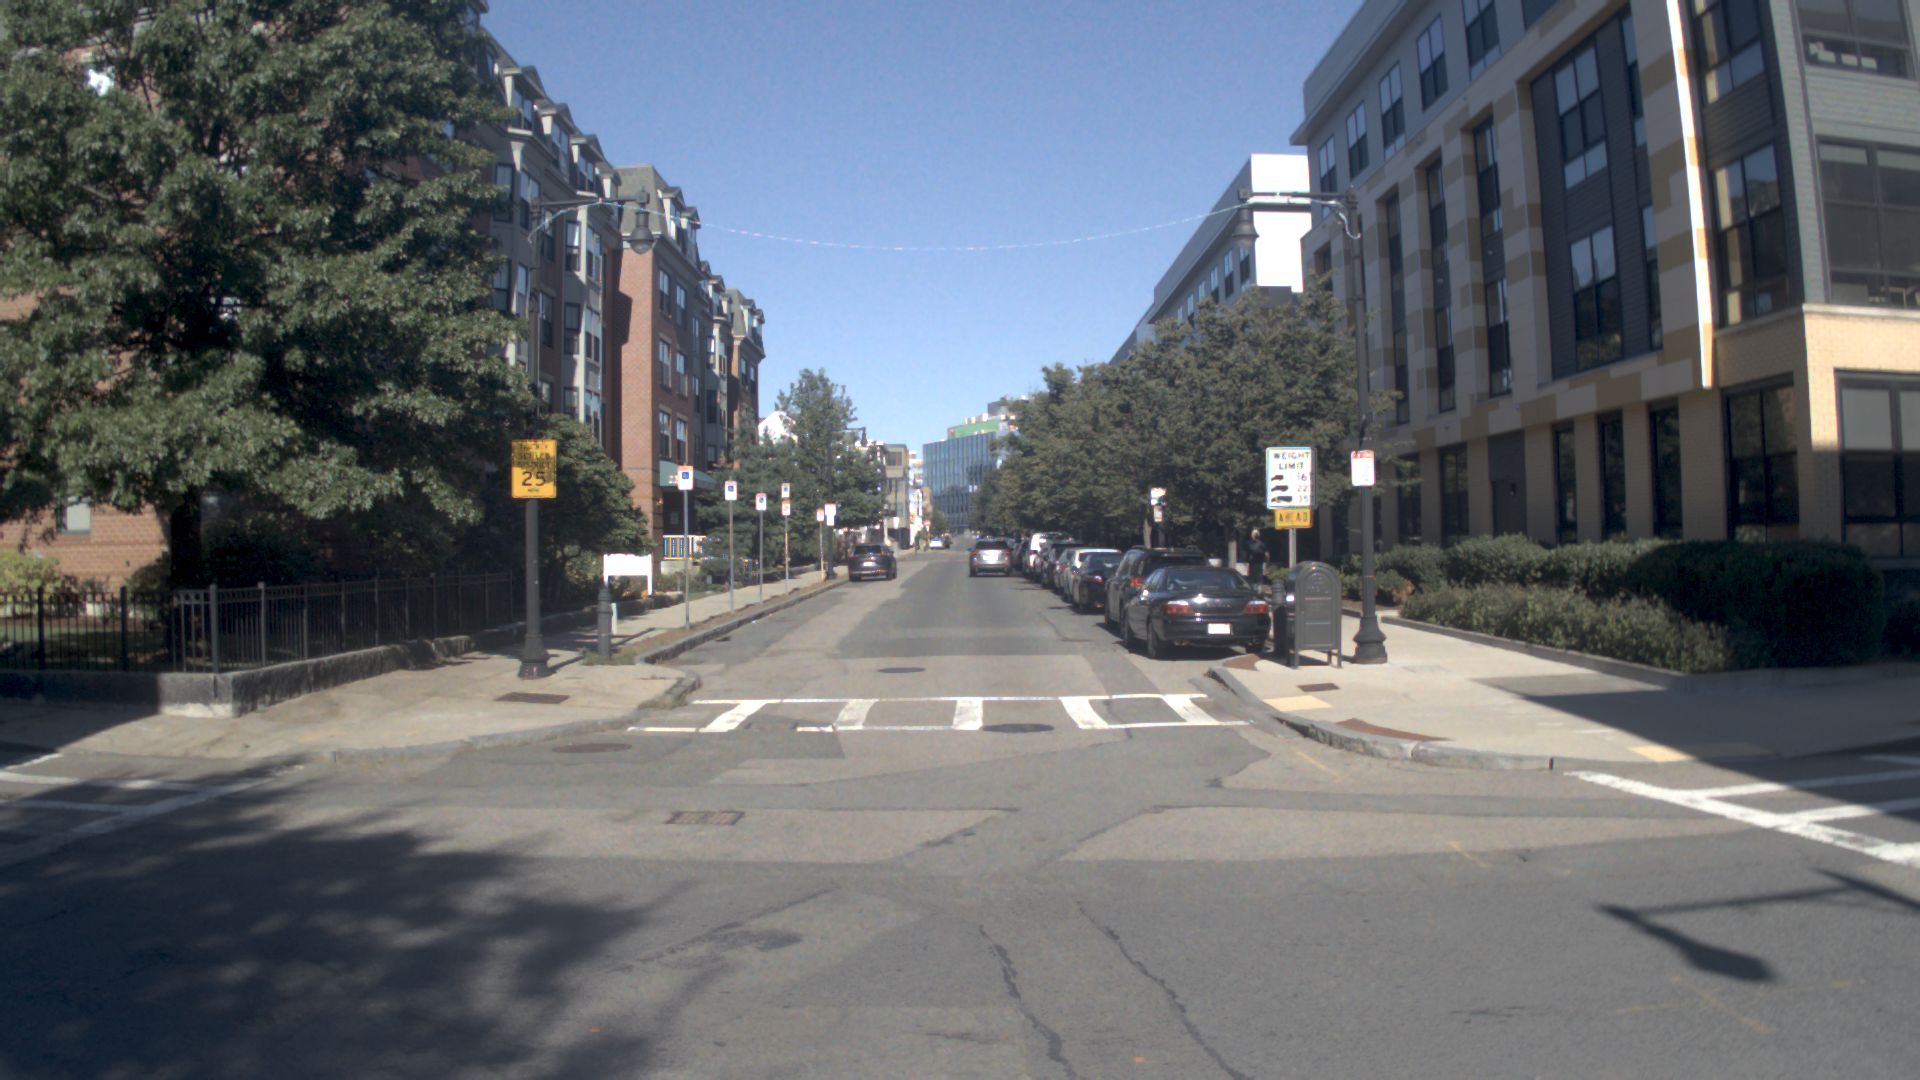
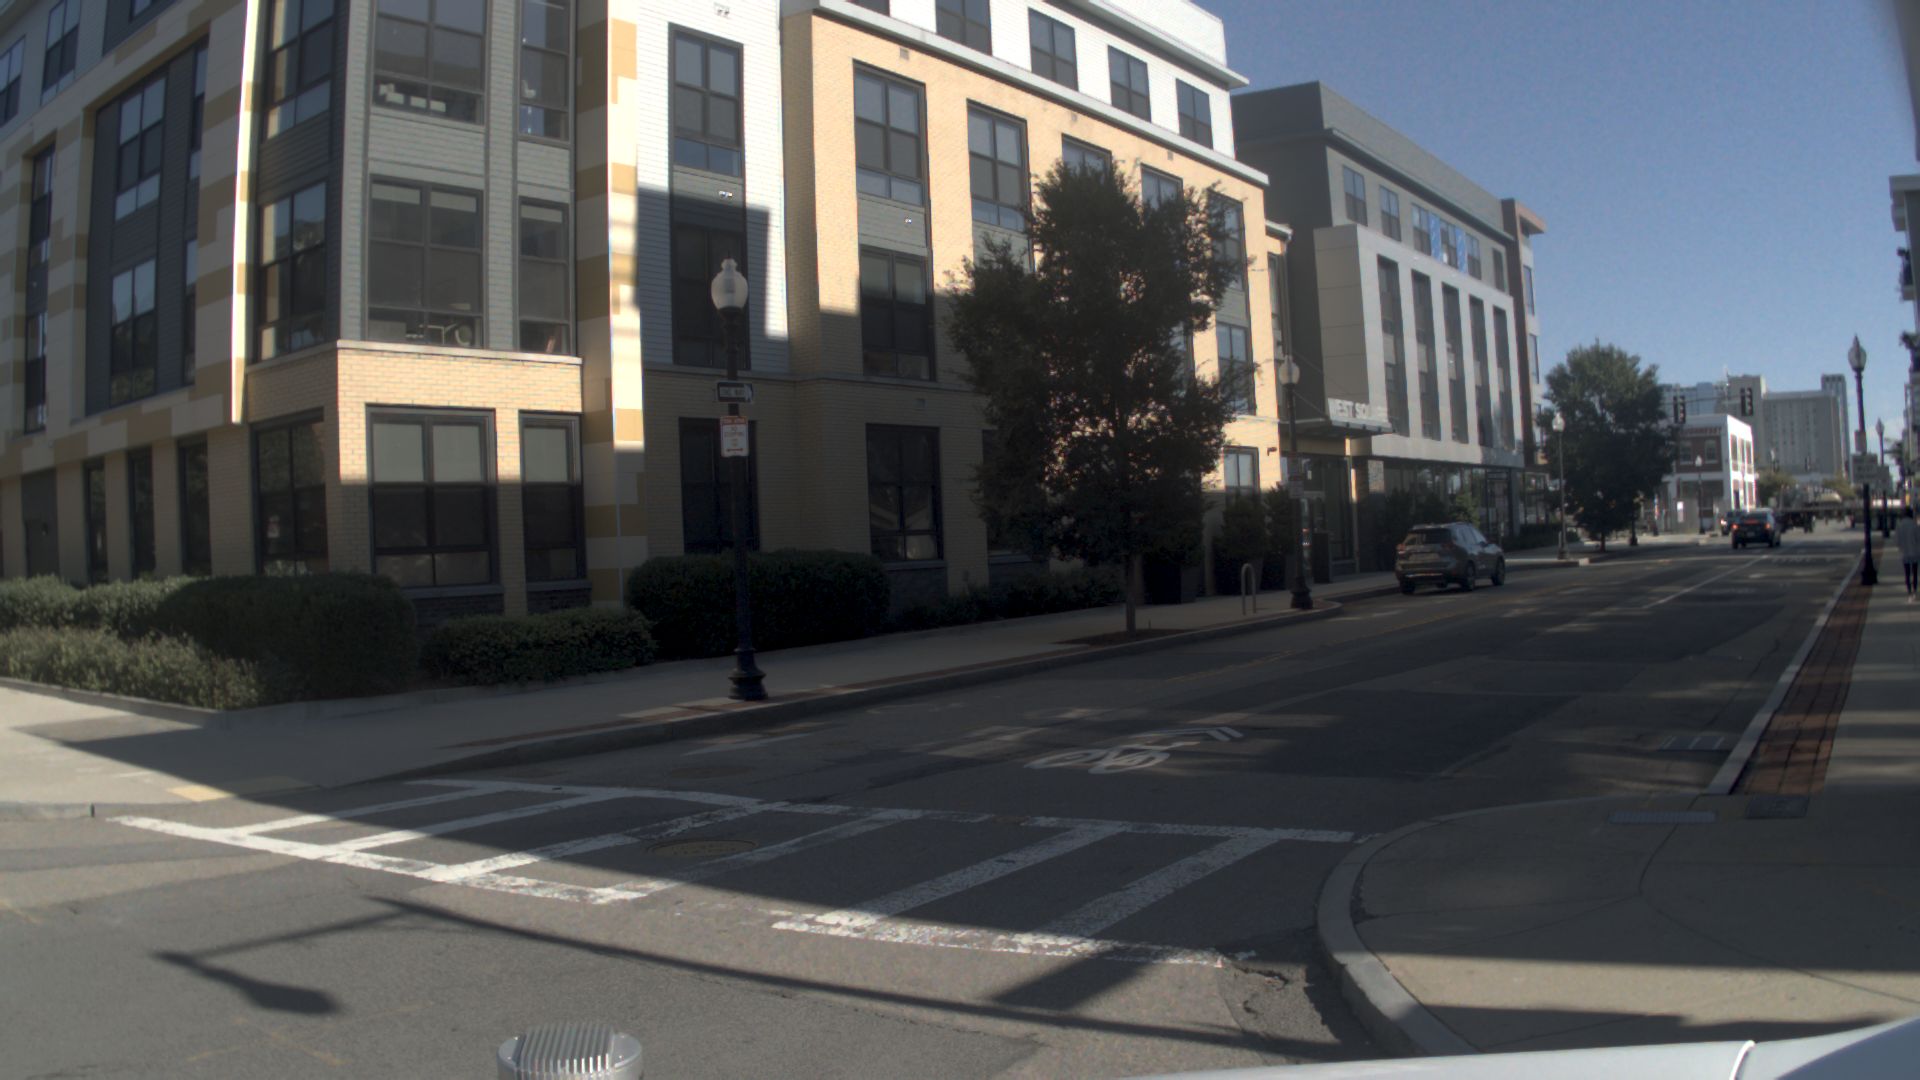
No additional background-vehicle holding corrections were needed. Original photos remain unchanged. Before later inpainting, any overlap with original-photo traffic must be resolved. Background positions in this 3D rehearsal are not an exact replay of the photographs.
After scene approval
The working pipeline will edit each original NAVSIM camera photograph with Image 2.5. Its same-time Higgsfield view will provide position and posture, annotated with facing direction and current speed. Temporal image requests will cover the full event with a 1 Hz base plus critical moments.
Assumptions and source provenance
- Observed evidence is limited to the supplied NAVSIM geometry and Image #1's roadway, curbs, sidewalks, trees, and frontage. The collector, cart, load, and all actions are counterfactual proposals.
- The selected work area uses the wheelchair road, approximately y=-4.5 to y=5.2 around x=25..50; adjacent mapped sidewalks are not used as an invented cart exit.
- The load consists of lightweight secured recycling bundles. The proposal concerns blocked visibility and slow progress, not a cargo spill.
- The built-in ego is not an additional cast actor. It starts at x=0, y=0 at time -7 with speed 5.6 m/s and brakes at 1.12 m/s squared to stop centered at x=14 at time -2. Its buffered corridor is |y|<=1.25.
- Use shape-preserving, speed-bounded interpolation at 0.05-second intervals. Brief start and stop ramps are exceptions to the moving walking-speed minimum. All z values are support offsets over the supplied ground plane.
- No image has been generated or human review completed; the review gate remains mandatory.
Fresh GPT-6 motion plans use semantic descriptions from the pinned consolidated catalog and NAVSIM environments. No upstream nuPlan vectors, trajectories or images are used. The four source environments are reused; 82 scenario descriptions do not mean 82 independent locations.
Higgsfield revision 1. The portable GLB combines export clips without changing geometry or animation samples.
This review uses Higgsfield revision 1 and the exact exported scene snapshot.
Higgsfield workspace (latest revision) · Download animated GLB · GPT-6 scene plan · Visual review evidence · Motion checks · Approval status