MARSAD / CONSOLIDATED CATALOG / #026
Tricycle courier parks and runs north with a parcel
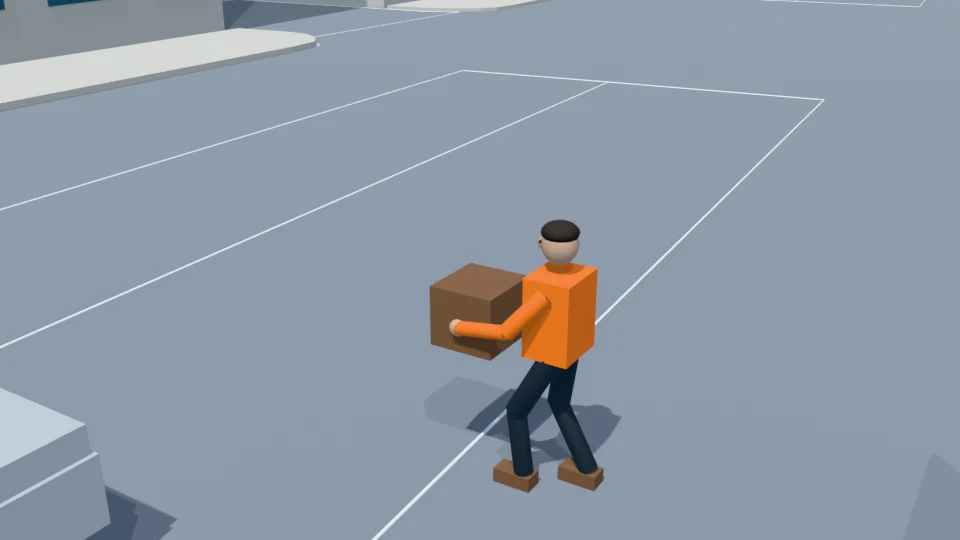
Awaiting your 3D scene approvalCounterfactual: A courier drives an electric cargo tricycle east along the road's right side, parks, steps off, and takes a parcel from its open cargo shelf. Holding the parcel ahead of the torso, the courier runs north across the road and finishes on the mapped north sidewalk. The tricycle remains parked.
Original description: 前方有快递员骑着电动三轮车沿着道路右侧向东行驶,然后停在路边,自己抱着电动三轮车上的包裹跑步向北横穿马路去派送快件。
Loading the full animated scene…
Critical moments
What to verify
- Exactly three critical actors persist: one operator-free tricycle, one separately identified courier, and one parcel. Do not add an implicit second rider.
- Verify the full -7..40-second rehearsal at 20 Hz, including driving, braking, dismounting, retrieval, turning, running, sidewalk arrival, and final hold.
- Verify the parked tricycle footprint, x=33.6..36.4 and y=-3.7..-2.4, stays inside the cargo road polygon and outside the buffered ego corridor.
- Verify the courier's dismount clears the chassis, the rearward approach avoids body penetration, and stationary turns are explicit rather than heading flips.
- At attachment boundaries -1 and 3, require position continuity within 0.01 m after applying the supplied ground plane. The parcel must not rotate or drift independently while resting on the shelf.
- Verify the parcel sweeps with the courier during the half-turn, stays in front of the torso during running, and does not intersect the tricycle or the courier's body.
- Maintain approximately 2.3 m/s northbound running, bounded by 2..4 m/s except acceleration and stopping transitions; ordinary walking stays within 0.6..1.7 m/s.
- Verify the courier and complete parcel footprint are on the north sidewalk before time 13. Permit ego release only then, with no remaining object in its corridor.
- Require human approval of the full rehearsal, the pickup at time 3, and the conflict at time 5.4 before image generation. Later Image 2.5 must edit original Image #3.
Review notes
Re-inspected the corrected cargo tricycle: one front wheel, two rear wheels, saddle, handlebars and rear cargo bed replace the earlier four-wheel cart. The courier dismounts, retrieves the parcel and crosses while carrying it; the parked tricycle persists.
Check action, relative position, facing, posture and visibility. Approximate offsets are acceptable. Sampled visual checks do not prove every contact or continuous collision clearance.
Rendered inspection views
Event, approach and final views rendered from the exact committed Higgsfield Blender source. These are procedural 3D previews, not generated training photographs.
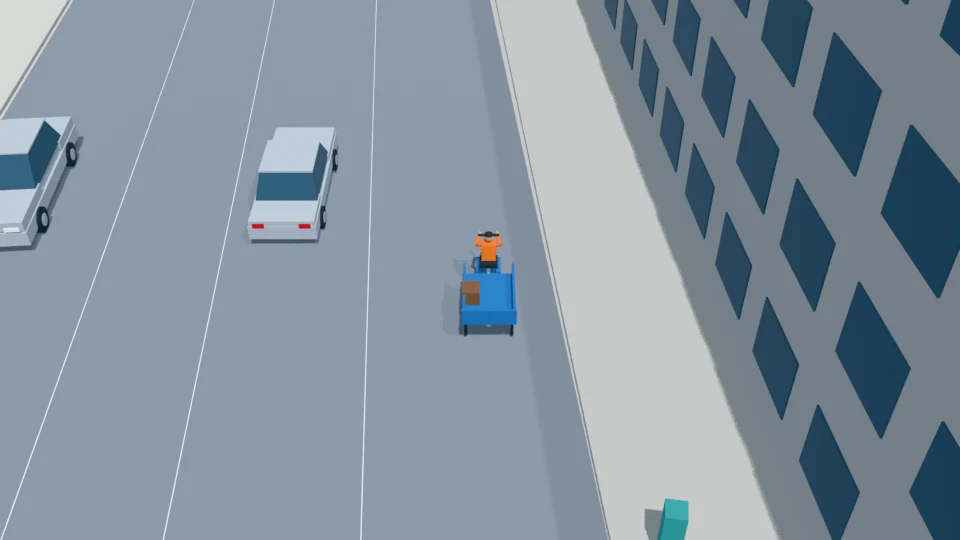
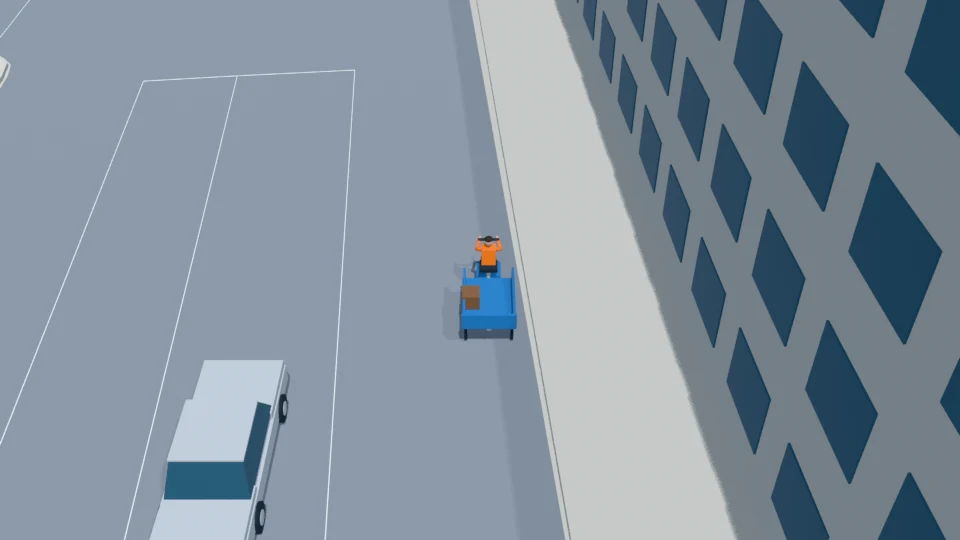
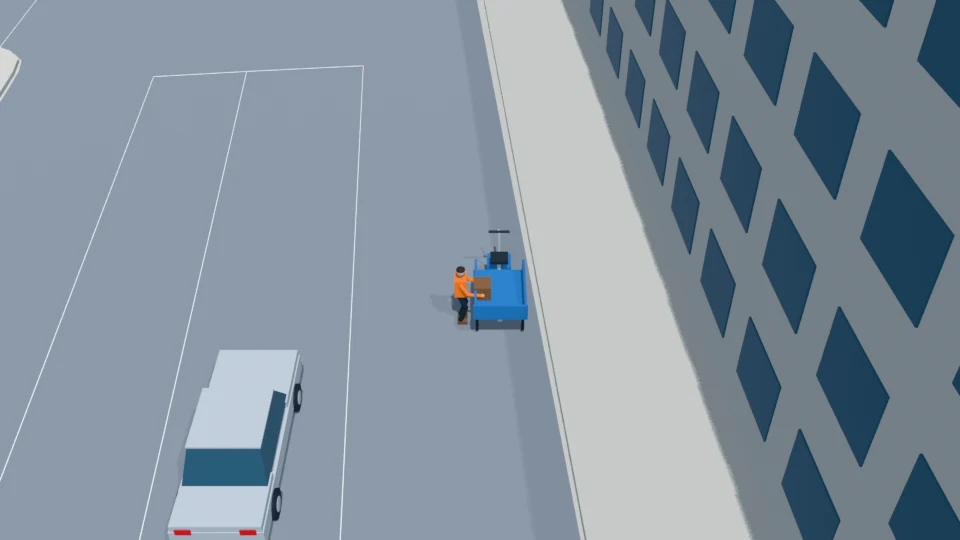
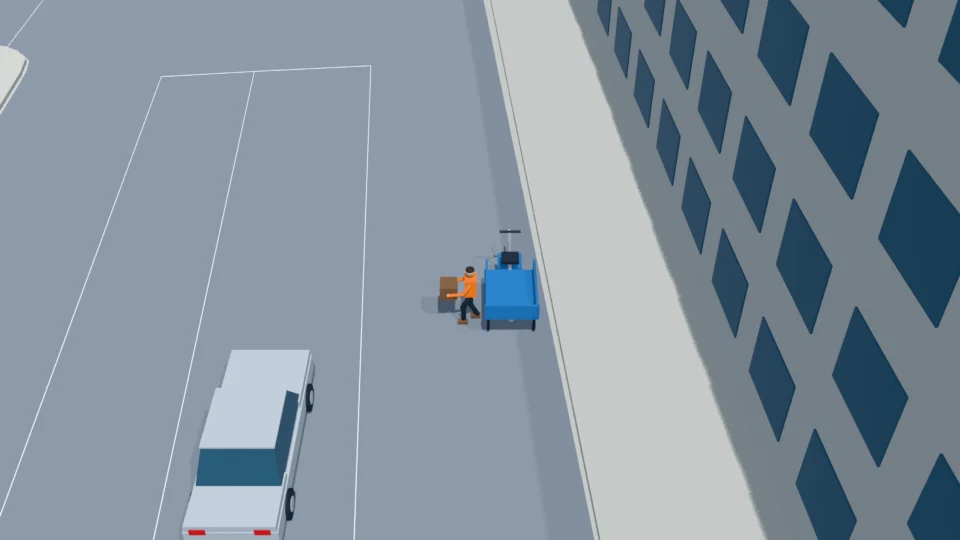
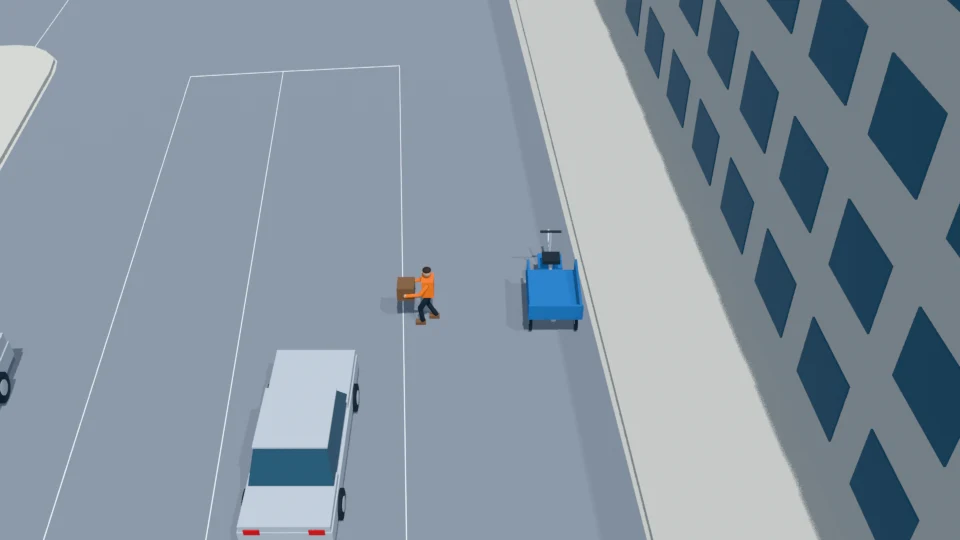
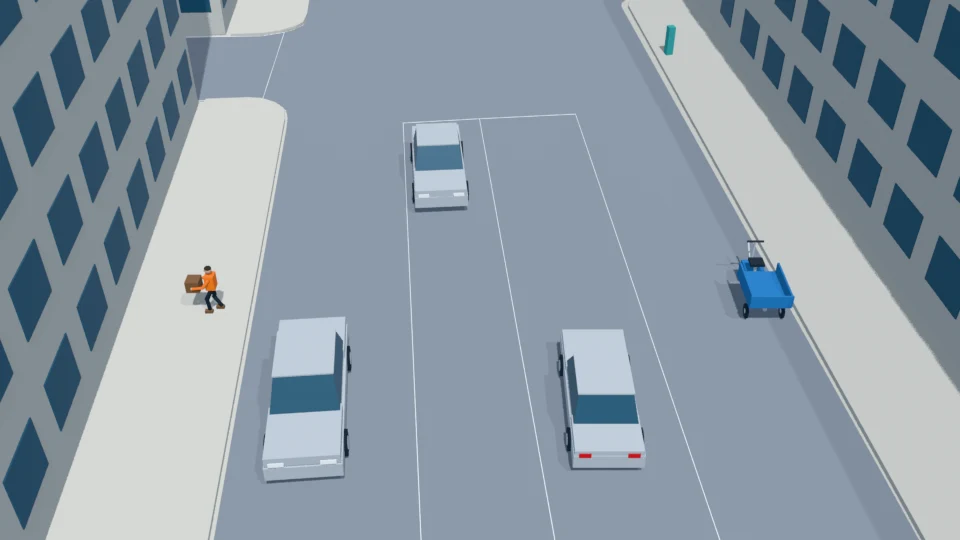
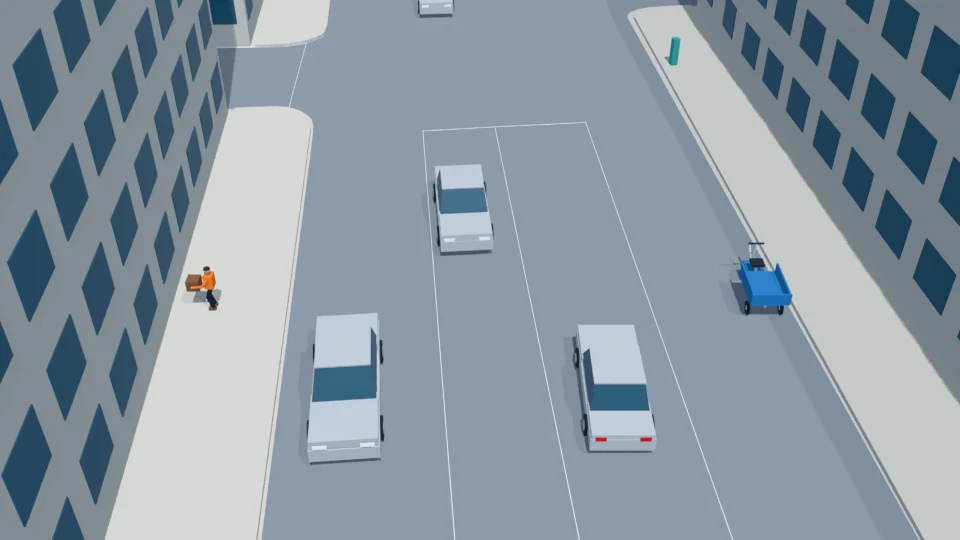
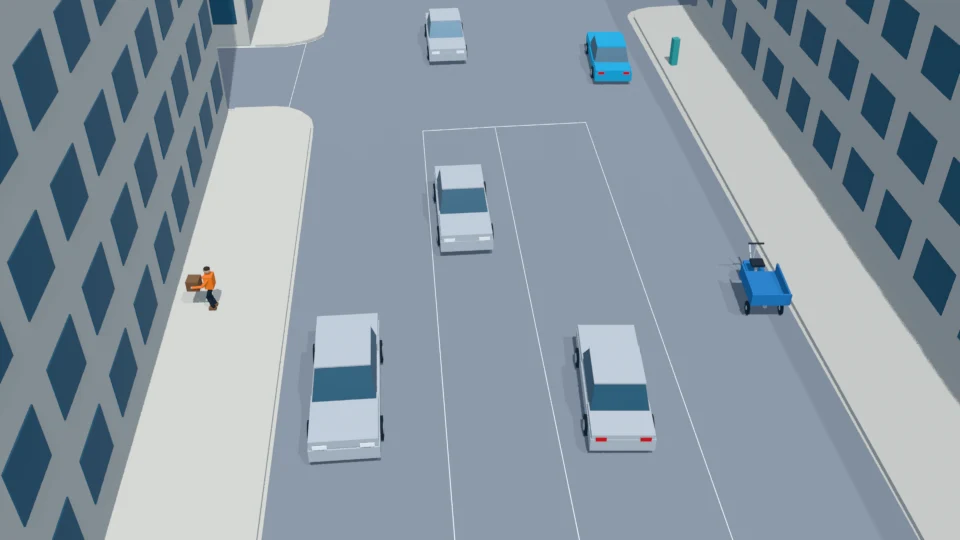
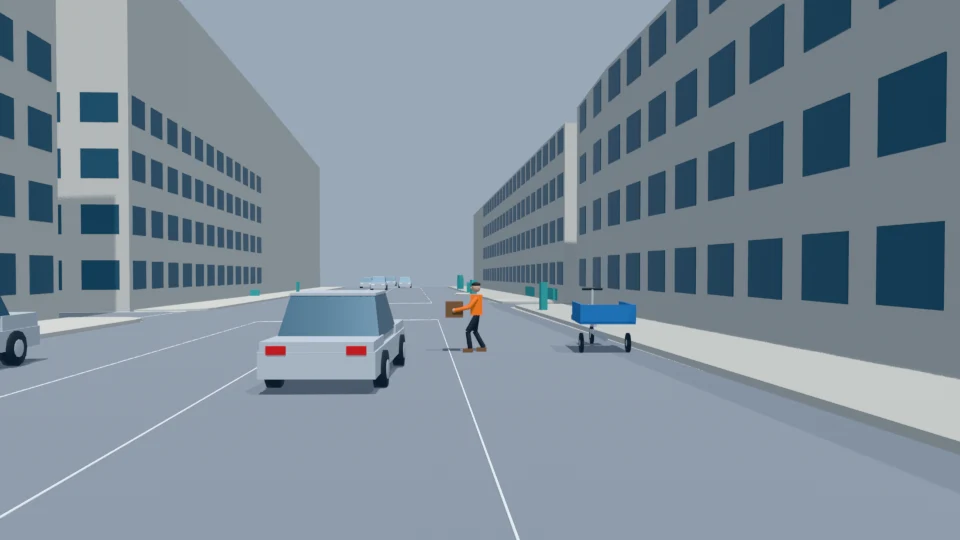
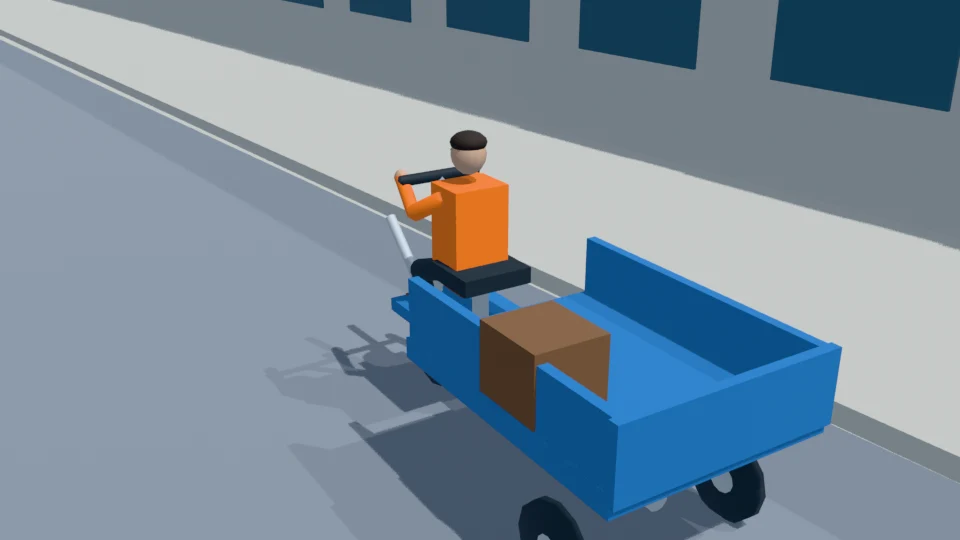
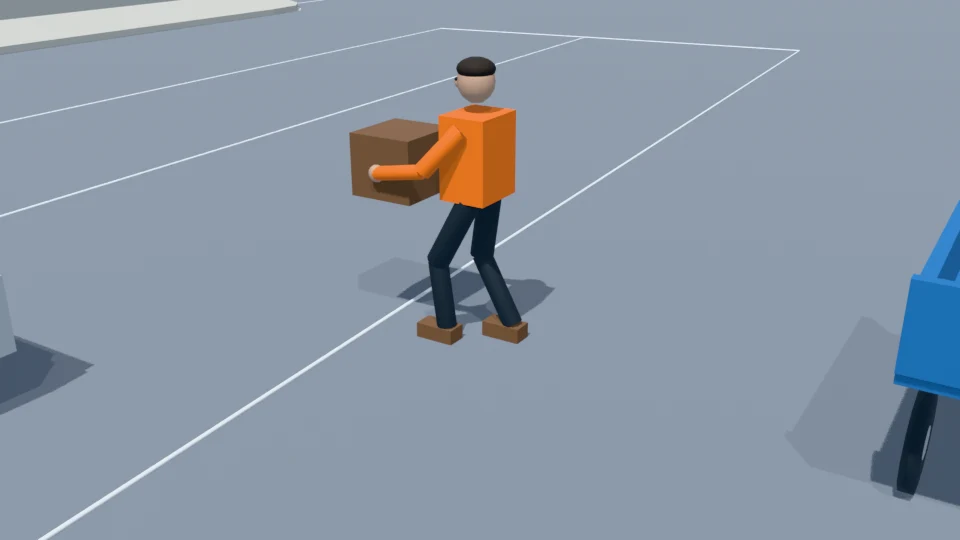
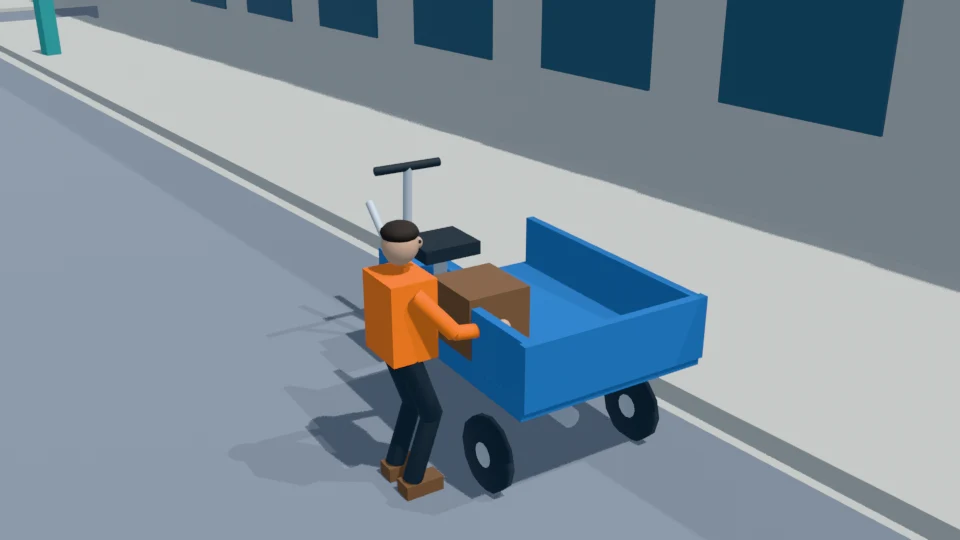
Original NAVSIM camera context
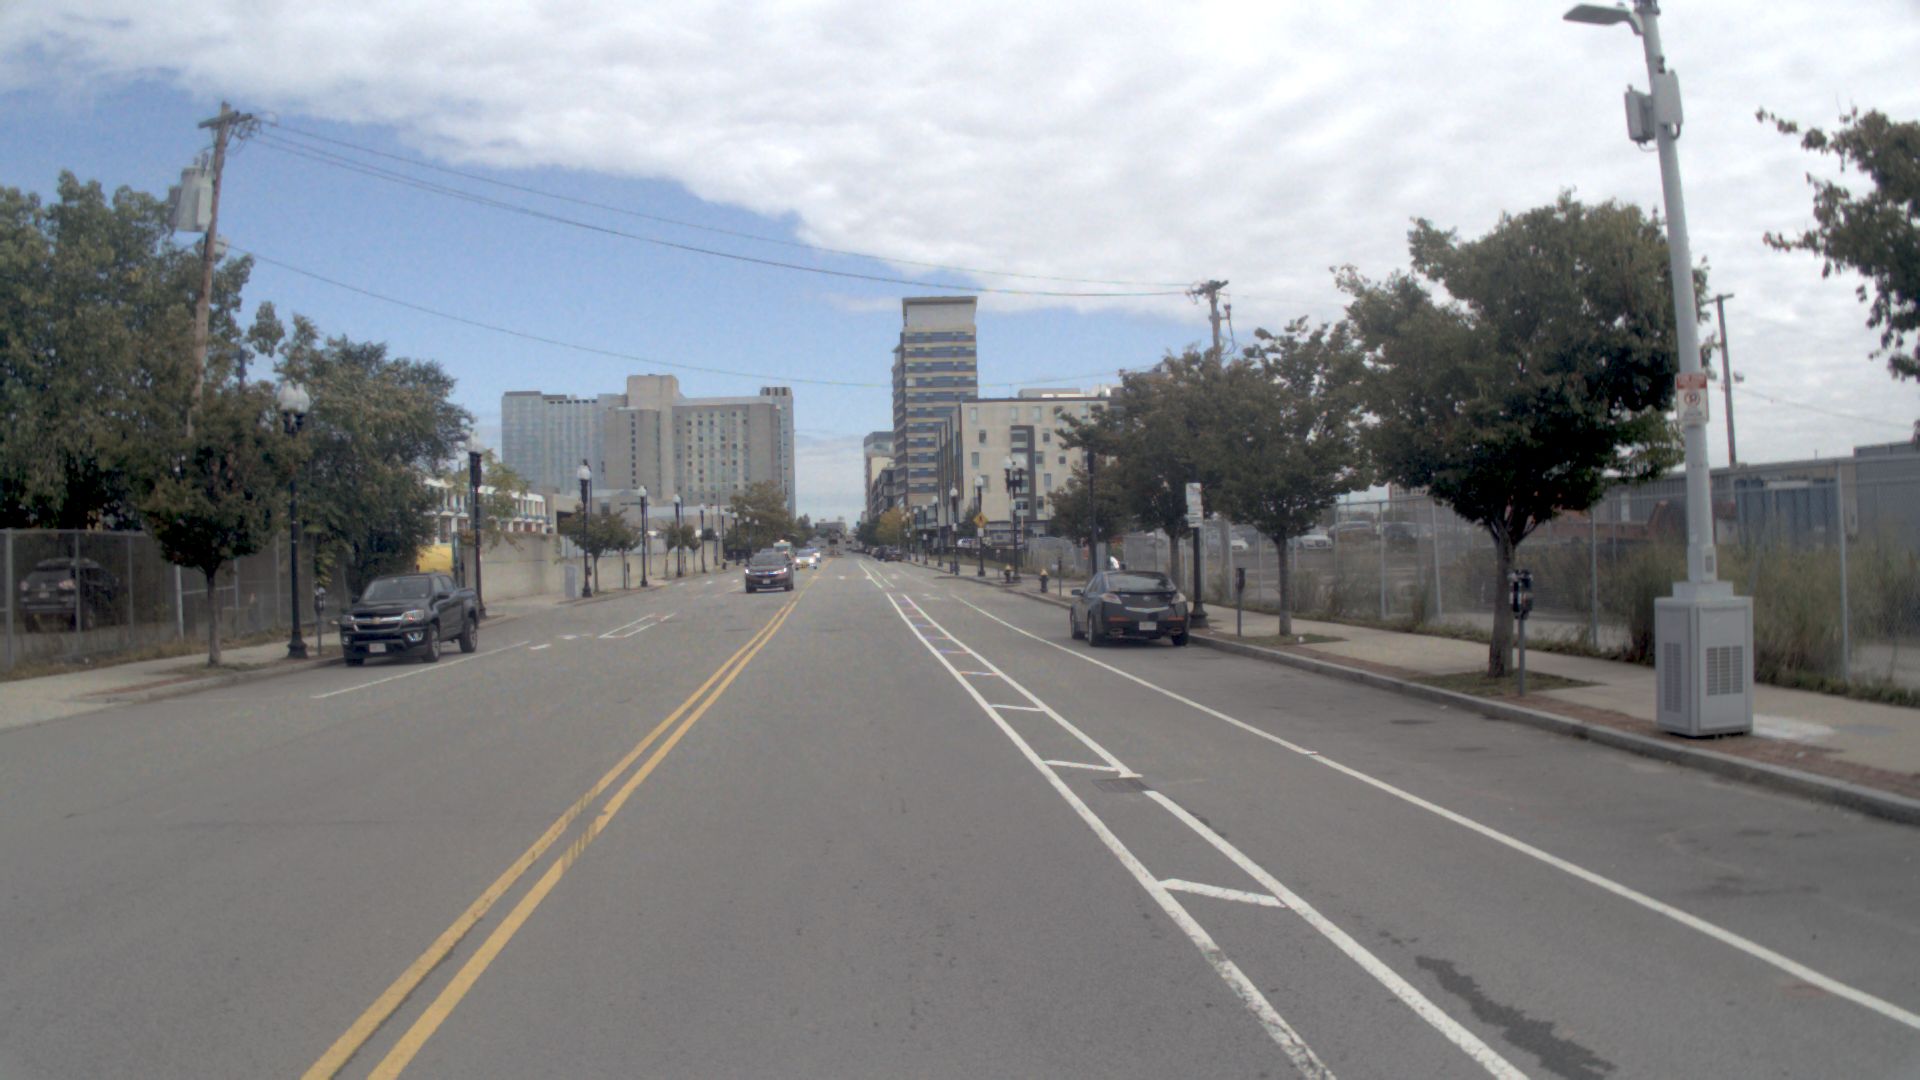
5 conflicting background vehicles were moved to clear holding positions for this counterfactual rehearsal. Original photos remain unchanged. Before later inpainting, any overlap with original-photo traffic must be resolved. Background positions in this 3D rehearsal are not an exact replay of the photographs.
After scene approval
The working pipeline will edit each original NAVSIM camera photograph with Image 2.5. Its same-time Higgsfield view will provide position and posture, annotated with facing direction and current speed. Temporal image requests will cover the full event with a 1 Hz base plus critical moments.
Assumptions and source provenance
- The cargo NAVSIM map and Image #3 provide the roadway, curb, sidewalk, and coarse frontage evidence. The tricycle, courier, parcel, destination, and timing are counterfactual proposals.
- At x approximately 34.4, the north roadway edge is near y=13.0 and the mapped sidewalk extends to approximately y=16.7. The final courier and parcel positions lie within that sidewalk, not an invented doorway.
- One modest parcel represents the unspecified shipment. The courier pauses with it on the destination-side sidewalk; a recipient and completed handover are not invented.
- Before pickup, the parcel follows synchronized shelf keys rather than a second attachment parent. From time 3 onward it is attached only to the courier.
- Attachment coordinates include small ground-plane corrections: seated-human z=0.5593 and parcel z near 0.85 are support offsets, not absolute elevations. Attachment transforms govern between rounded check keys.
- Use 0.05-second sampling, smooth bounded-speed interpolation, and path tangents consistent with unwrapped headings. The dismount is an explicit sideways step; the retrieval and half-turn occur while stationary.
- The built-in ego starts at x=0, y=0 at time -7 with speed 5.6 m/s and stops at x=14 at time -2. Its buffered corridor is |y|<=1.25. After release at time 13 it may accelerate gently to 1.5 m/s along y=0.
- No human review or image generation has yet occurred.
Fresh GPT-6 motion plans use semantic descriptions from the pinned consolidated catalog and NAVSIM environments. No upstream nuPlan vectors, trajectories or images are used. The four source environments are reused; 82 scenario descriptions do not mean 82 independent locations.
Higgsfield revision 2. The portable GLB combines export clips without changing geometry or animation samples.
This review uses Higgsfield revision 2 and the exact exported scene snapshot.
Higgsfield workspace (latest revision) · Download animated GLB · GPT-6 scene plan · Visual review evidence · Motion checks · Approval status