MARSAD / CONSOLIDATED CATALOG / #028
Half-crouched road-marking worker overlooking rear traffic
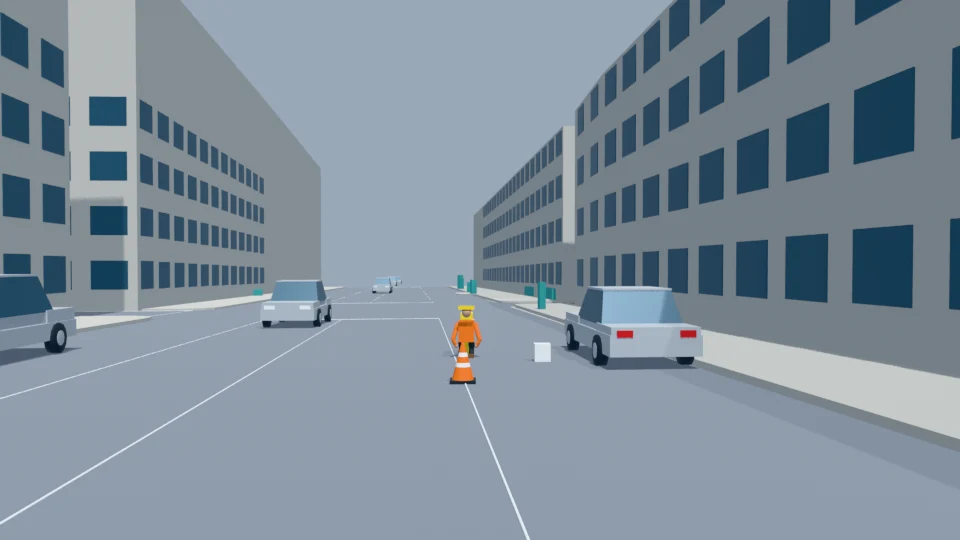
Awaiting your 3D scene approvalCounterfactual rehearsal: a worker refreshes a short road stripe, repeatedly half-crouching and concentrating on the applicator rather than approaching traffic behind. The worker and protected work area remain in the ego corridor through the final state.
Original description: 前方有施工人员在道路上进行划线作业,身体半蹲,专注于工作而忽略了后方来车。
Loading the full animated scene…
Critical moments
What to verify
- Sample the finite interval [-7,40] at 20 Hz, producing 941 inclusive states; retain all six critical IDs throughout.
- Check every support point and solid footprint against the supplied cargo road polygon, including interpolated states.
- Verify the two 3.2 m walking transfers occur over four seconds each, with smooth acceleration and no walking speed above 1.7 m/s.
- Verify half-crouched posture, hands ahead on the applicator grips, ground contact at the roller, and no torso-tool penetration.
- Keep the worker facing the work rather than acknowledging rear traffic; the scene must visibly depict road marking rather than a generic pedestrian crossing.
- Keep ego stopped at x=13 near y=0 from time 0 onward. Worker, cones, and equipment prevent release through time 40.
- Obtain human approval of the full timeline and the initial review state before Image 2.5 edits the original cargo photo; preserve the original architecture.
Review notes
Inspected every event view. The worker lowers into a crouch behind the marking tool and works within the cone corridor while a vehicle passes in the other lane. Rear traffic awareness remains absent as specified.
Check action, relative position, facing, posture and visibility. Approximate offsets are acceptable. Sampled visual checks do not prove every contact or continuous collision clearance.
Rendered inspection views
Event, approach and final views rendered from the exact committed Higgsfield Blender source. These are procedural 3D previews, not generated training photographs.
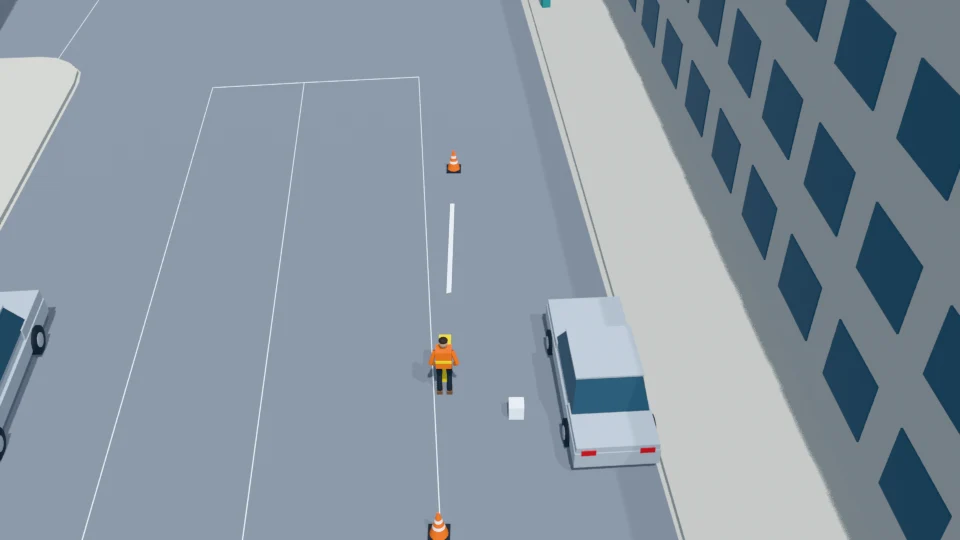
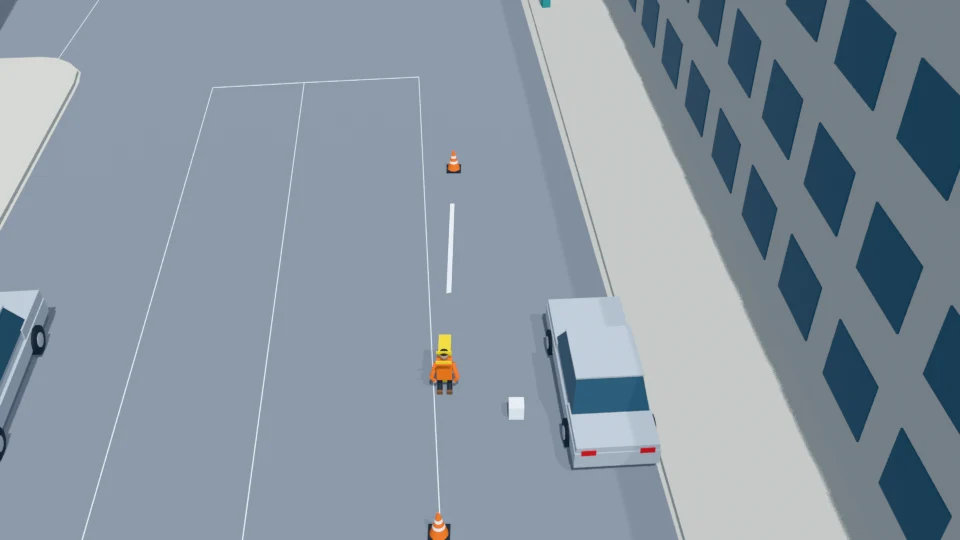
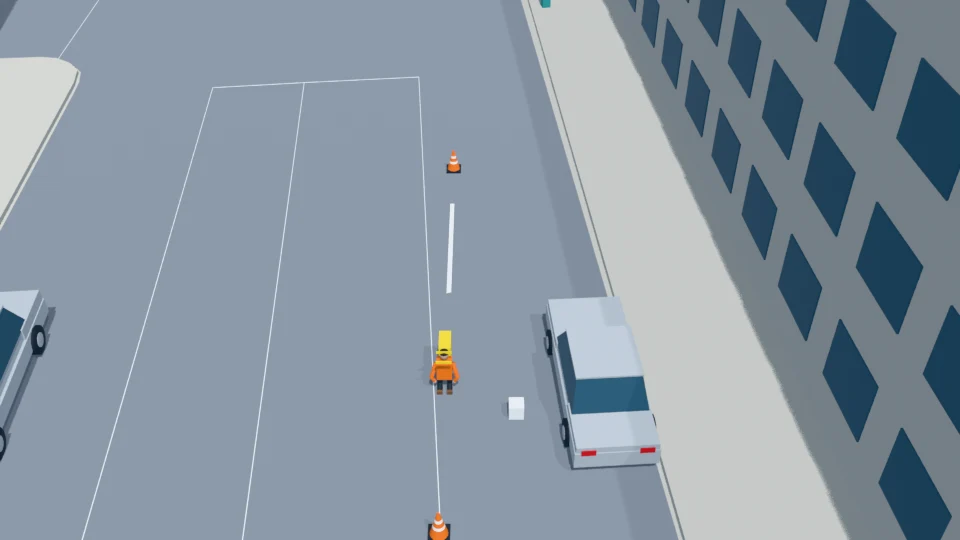
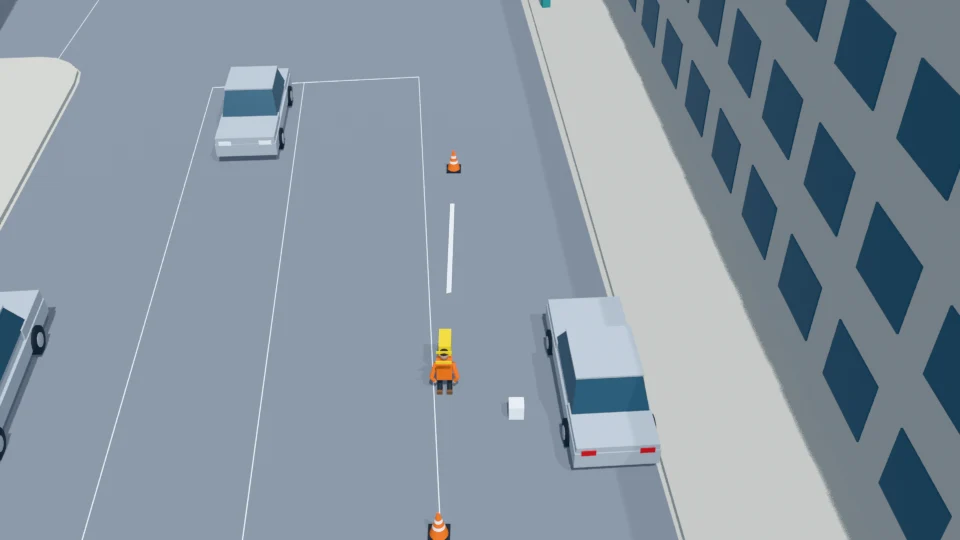
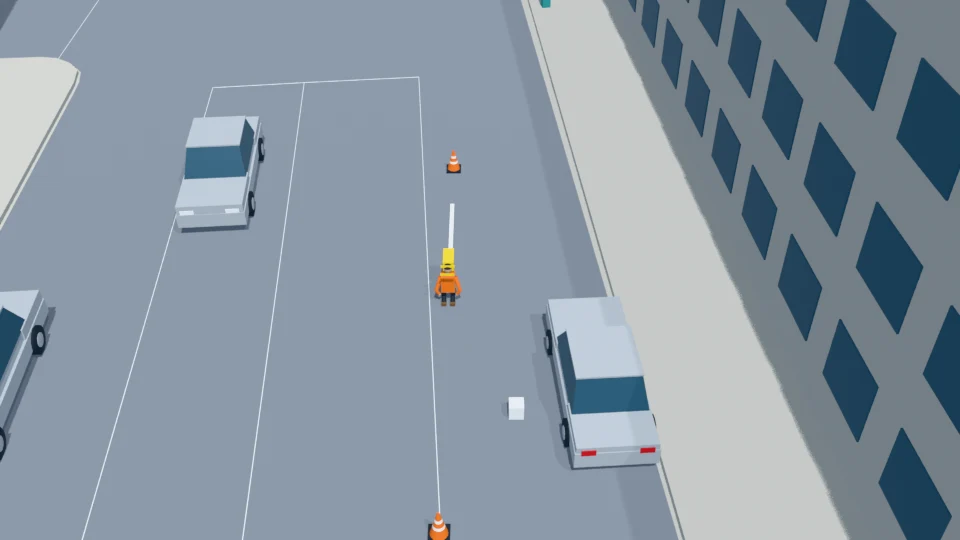
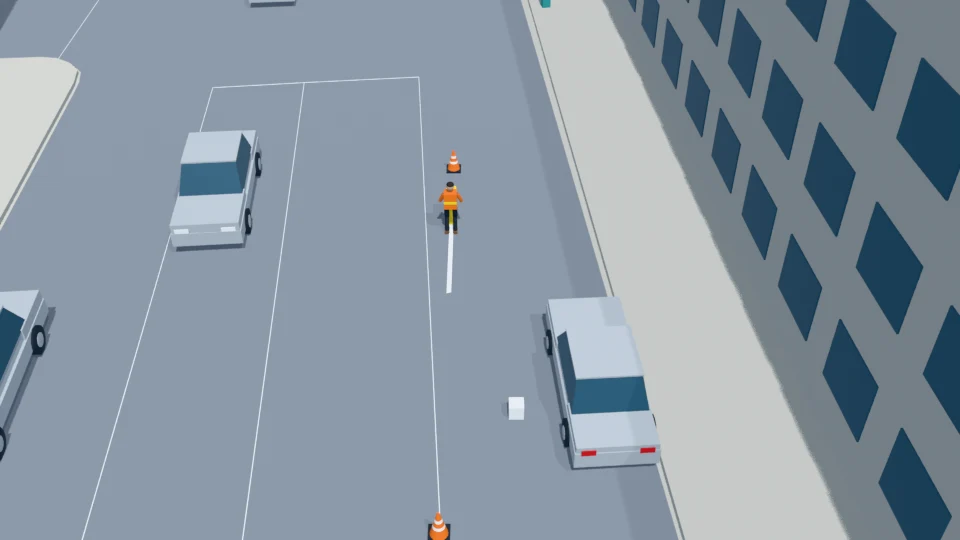
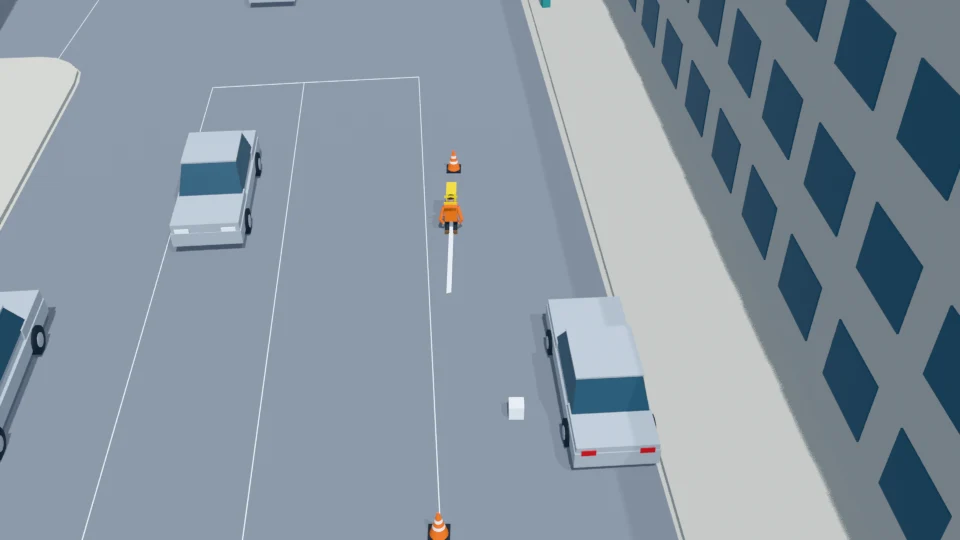
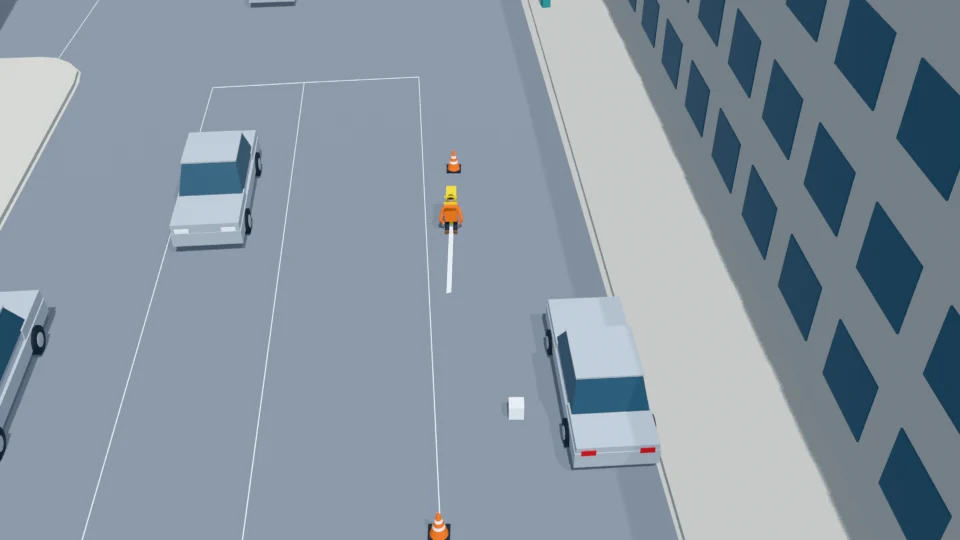
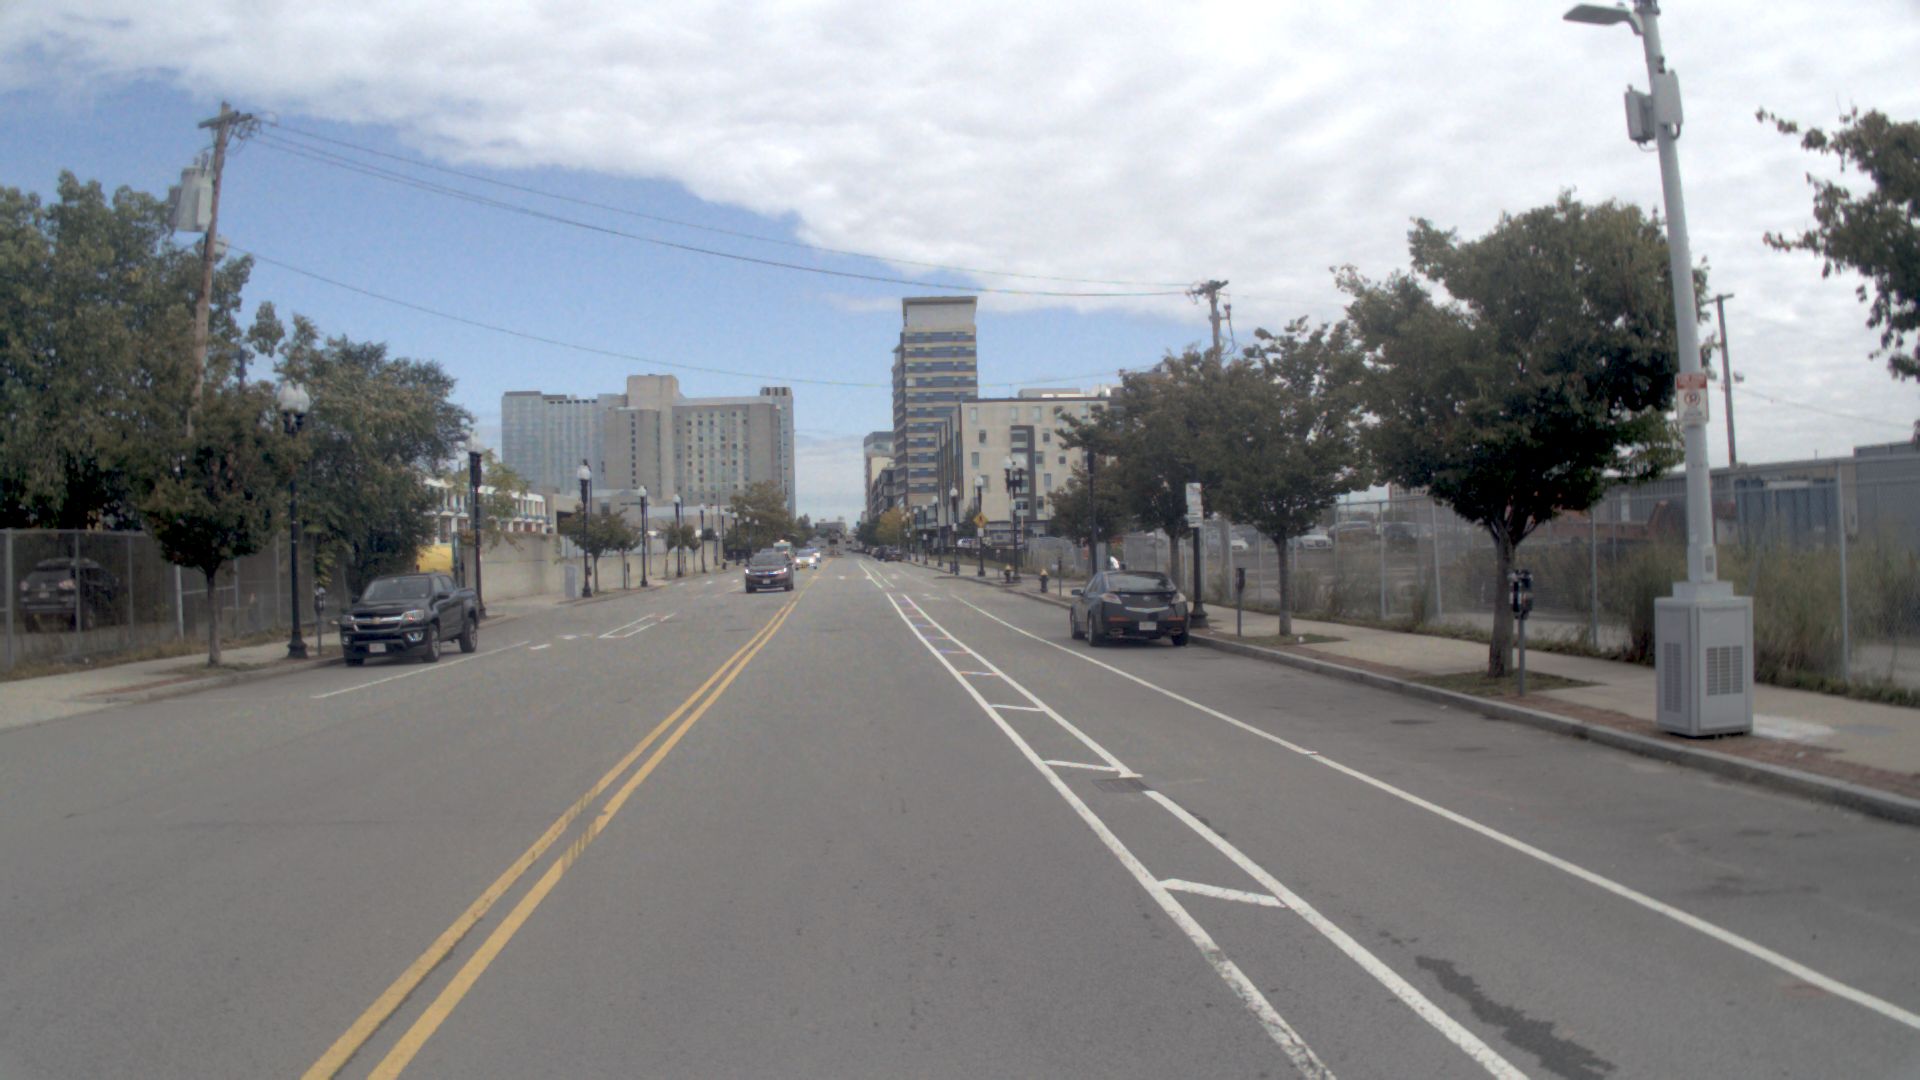
Original NAVSIM camera context
1 conflicting background vehicles were moved to clear holding positions for this counterfactual rehearsal. Original photos remain unchanged. Before later inpainting, any overlap with original-photo traffic must be resolved. Background positions in this 3D rehearsal are not an exact replay of the photographs.
After scene approval
The working pipeline will edit each original NAVSIM camera photograph with Image 2.5. Its same-time Higgsfield view will provide position and posture, annotated with facing direction and current speed. Temporal image requests will cover the full event with a 1 Hz base plus critical moments.
Assumptions and source provenance
- Observed evidence is limited to Image 3 and the supplied cargo map: a paved urban street, sidewalks, and road markings. The worker, equipment, cones, and guide stripe are counterfactual additions.
- All coordinates are newly authored on this map. The critical cast contains one adult and five individually identified props; ego is separately controlled.
- Playback is non-looping from -7 to 40 seconds at 20 Hz. Use continuous, bounded motion between keys and hold explicit rest states.
- All ground-supported roots use z=0 relative to the supplied mapped ground surface. The stripe is a surface decal, not a raised obstacle.
- The short stripe is a local repainting task, not an asserted change to the source map's lane topology.
- Background-object occupancy and fine curb geometry are not fully specified by the polygons and must be checked against the original photo during human review.
- This JSON is a proposed rehearsal, not a claim that simulation checks or image generation have been performed.
Fresh GPT-6 motion plans use semantic descriptions from the pinned consolidated catalog and NAVSIM environments. No upstream nuPlan vectors, trajectories or images are used. The four source environments are reused; 82 scenario descriptions do not mean 82 independent locations.
Higgsfield revision 1. The portable GLB combines export clips without changing geometry or animation samples.
This review uses Higgsfield revision 1 and the exact exported scene snapshot.
Higgsfield workspace (latest revision) · Download animated GLB · GPT-6 scene plan · Visual review evidence · Motion checks · Approval status