MARSAD / CONSOLIDATED CATALOG / #029
Traffic officers document an accident and direct following traffic
Awaiting your 3D scene approvalCounterfactual rehearsal: two compact cars make gentle bumper contact at time 0. One officer surveys and photographs multiple sides of the vehicles while another holds ego and directs one following car through a separate northern channel. The incident vehicles remain in the ego corridor.
Original description: 前方有交警在处理交通事故,围绕事故车辆进行勘查、拍照,并指挥疏导后方车辆。
Loading the full animated scene…
Critical moments
What to verify
- Retain exactly four critical vehicles, two officers, one camera, and one cone across all 941 inclusive 20 Hz states.
- At time 0, verify bumper tangency at x=34.8, low approach speed, and zero gross penetration. After time 3, verify the 0.20 m bumper gap remains.
- Check vehicle footprints against the police road polygon throughout, including c029_follow at its downstream positions.
- Verify the northern passing car remains clear of the investigator and retains at least 0.8 m lateral footprint clearance from the parked police car.
- Verify the investigator visibly surveys multiple sides and takes photographs, using explicit inward-facing sidesteps at walking speeds of 0.6-1.7 m/s outside start and stop transitions.
- Verify camera attachment continuity and hand contact at every interpolated orientation, including headings beyond 360 degrees.
- Keep ego stopped at x=13 despite the targeted guidance given to the northern passing car; incident cars and the cone still occupy its corridor at time 40.
- Require human approval before Image 2.5 edits the original police photo; do not replace its streetscape with a newly generated setting.
Review notes
Inspected traffic-direction gestures and the documentation-device close-ups. The two accident vehicles remain stopped, one officer examines them, and the other controls the following traffic.
Check action, relative position, facing, posture and visibility. Approximate offsets are acceptable. Sampled visual checks do not prove every contact or continuous collision clearance.
Rendered inspection views
Event, approach and final views rendered from the exact committed Higgsfield Blender source. These are procedural 3D previews, not generated training photographs.
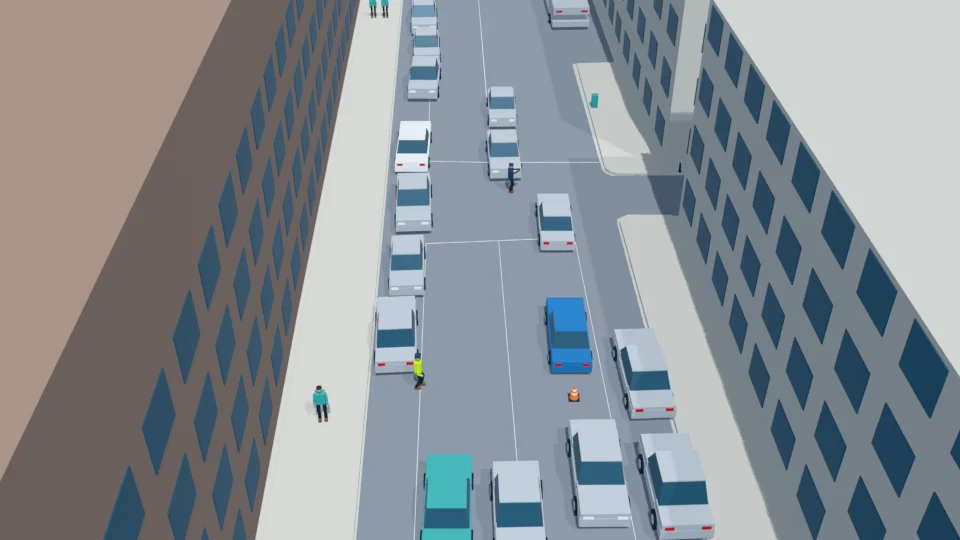
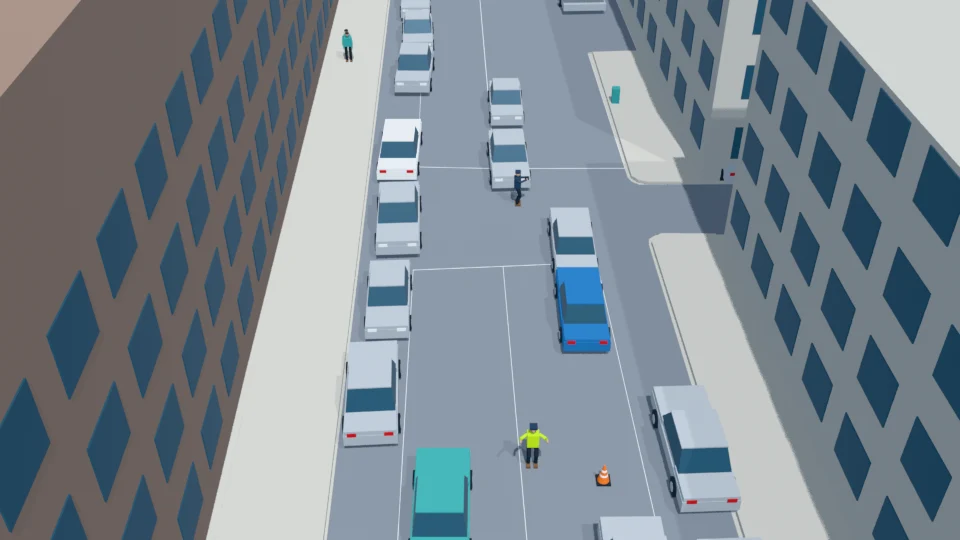
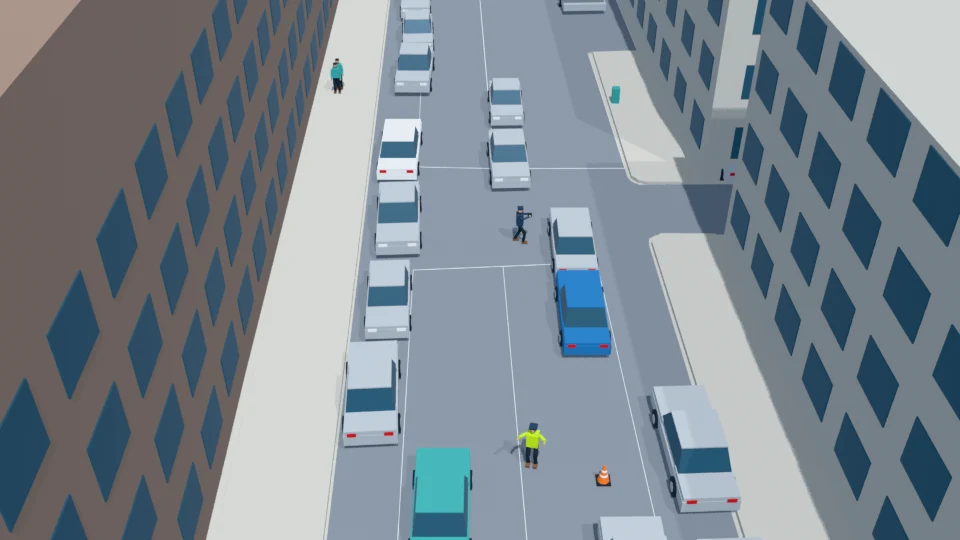
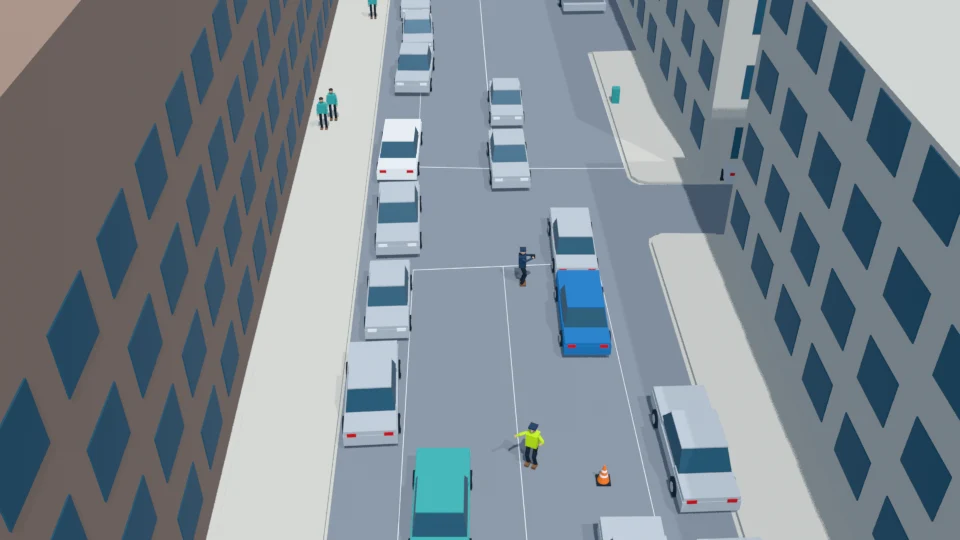
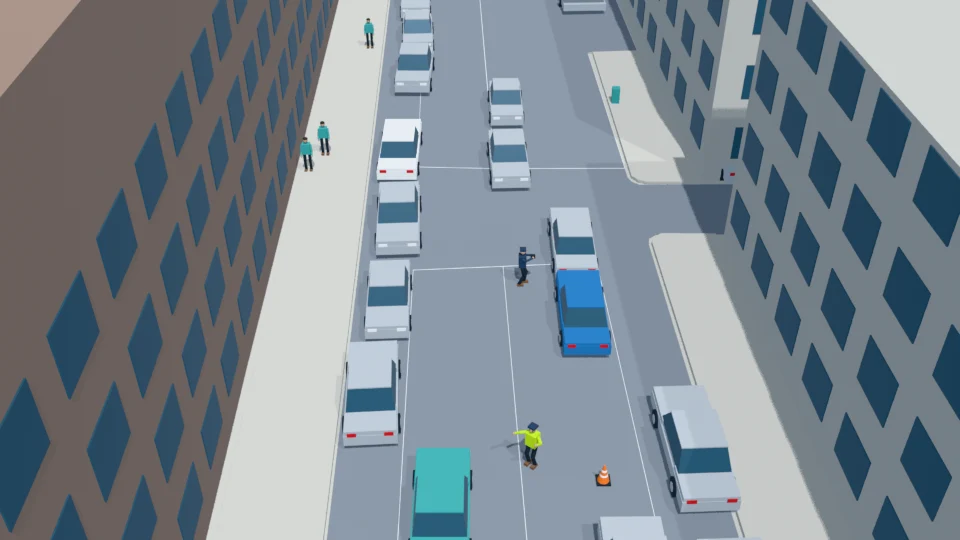
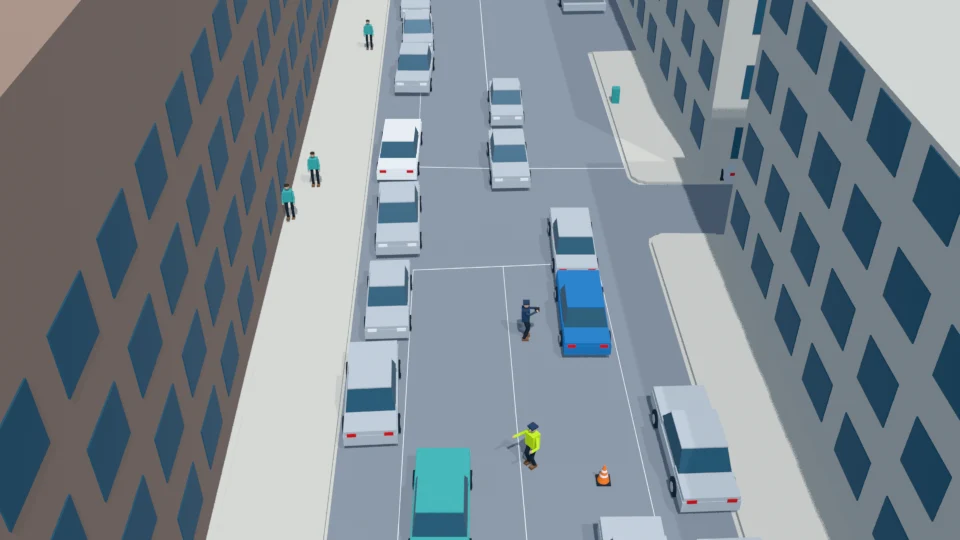
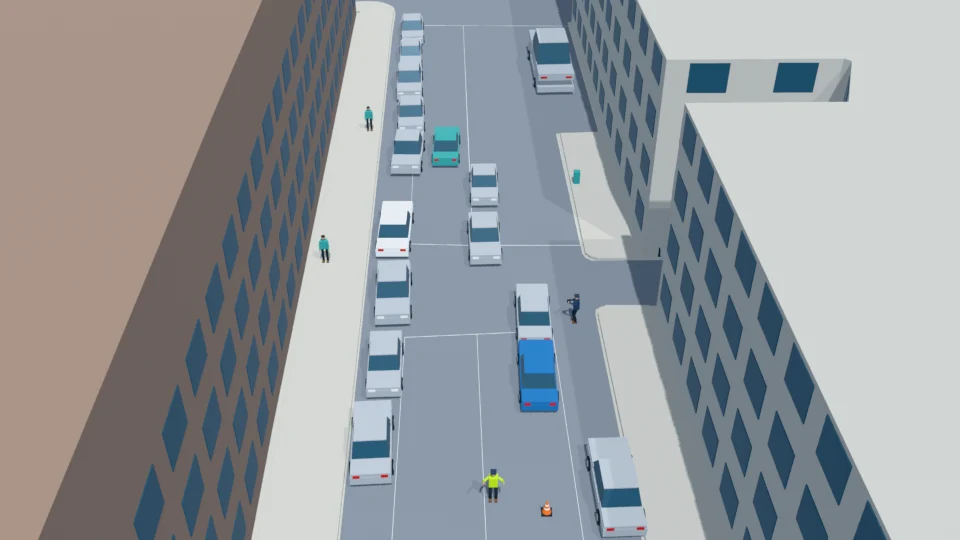
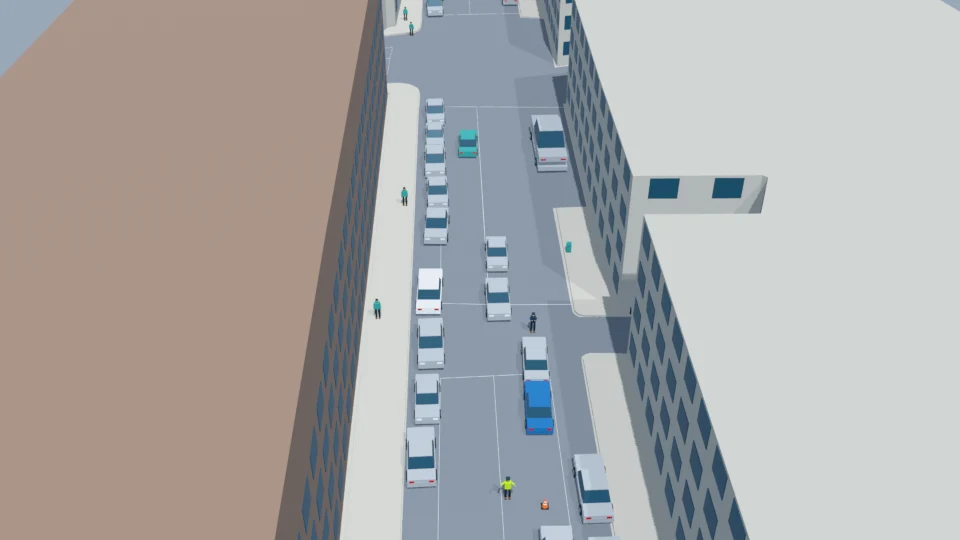
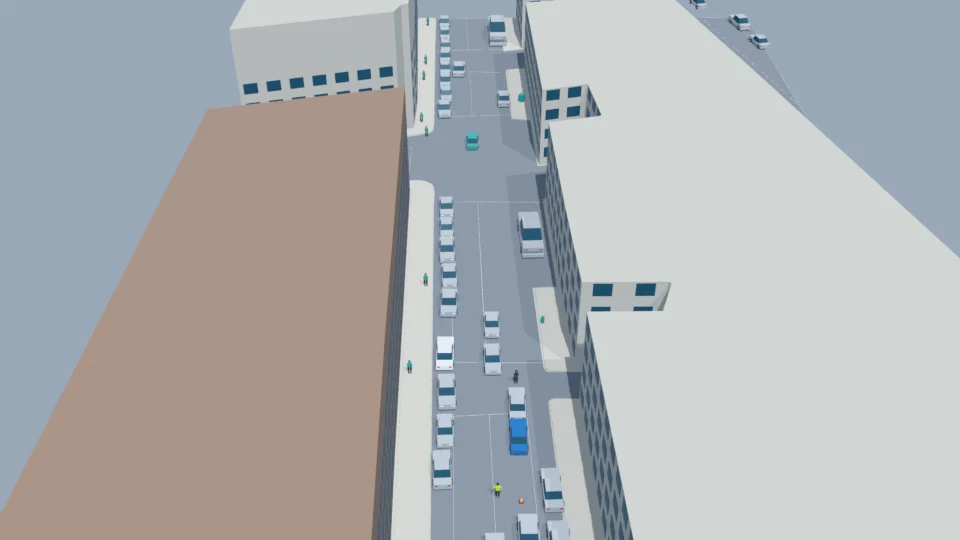
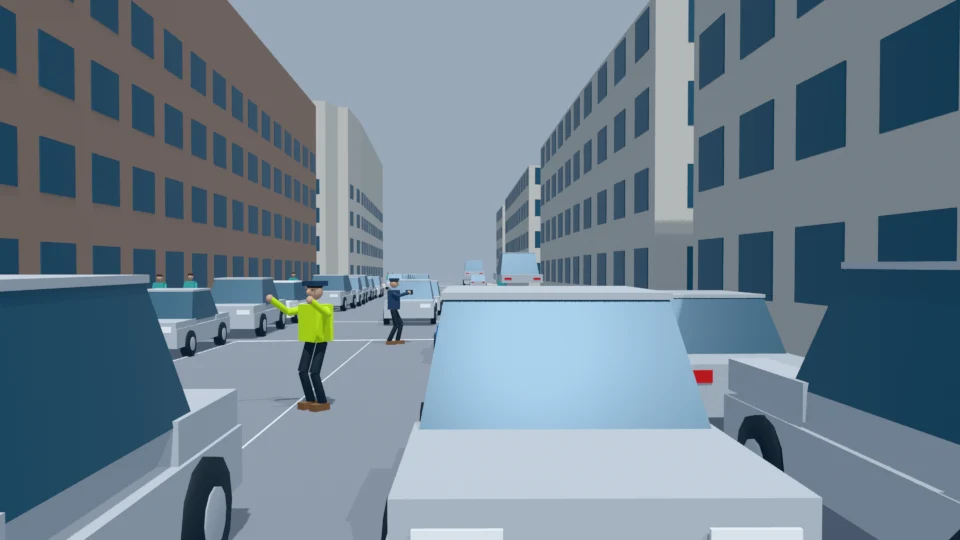
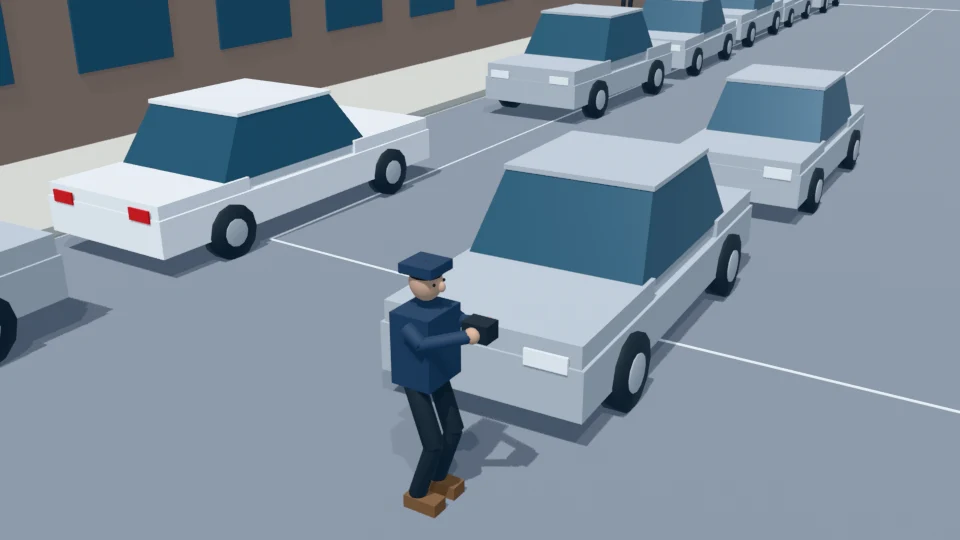
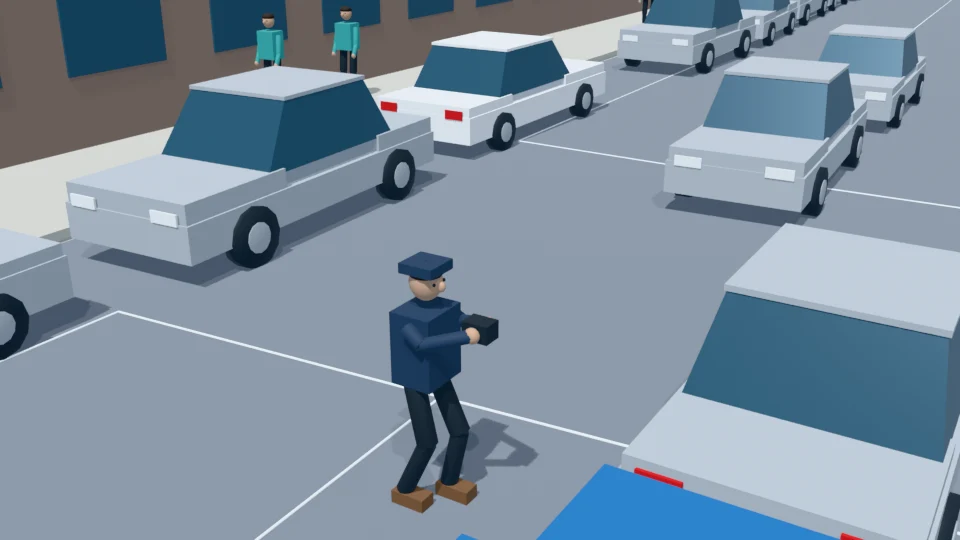
Original NAVSIM camera context
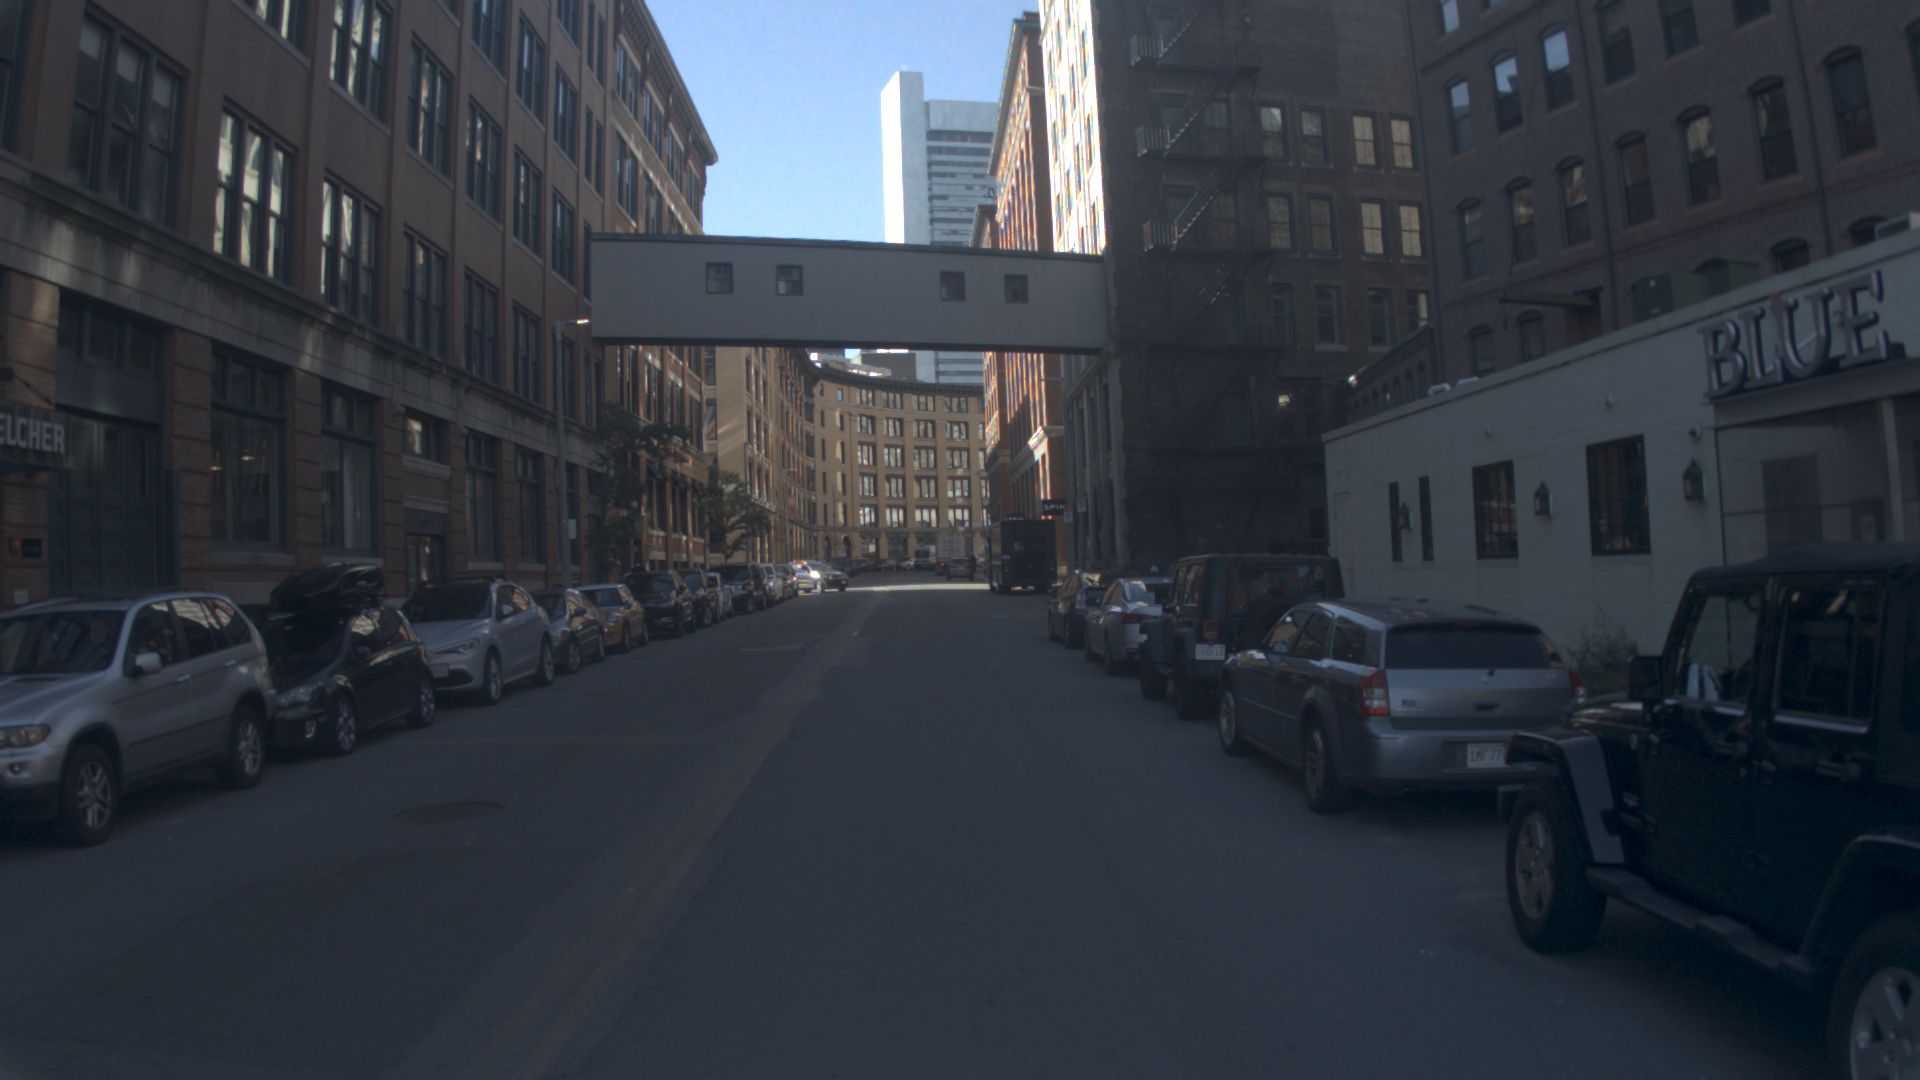
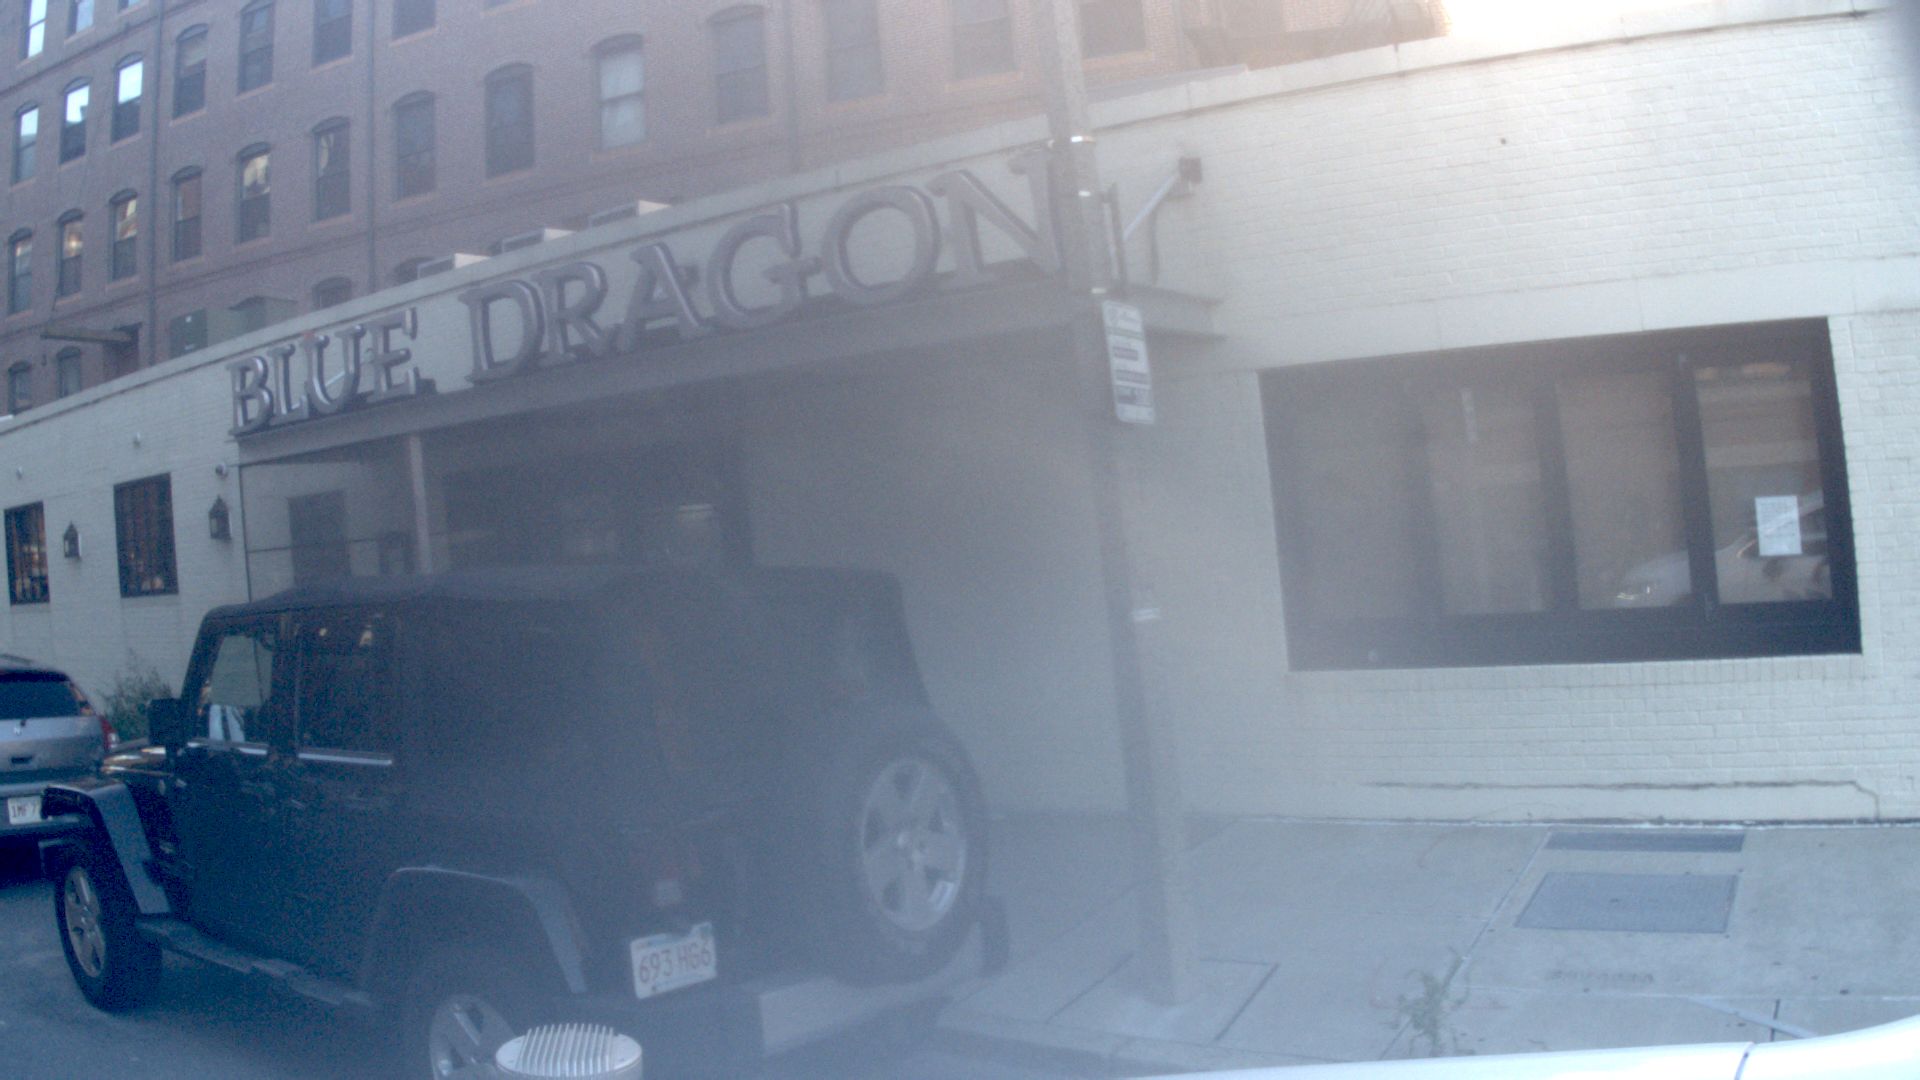
7 conflicting background vehicles were moved to clear holding positions for this counterfactual rehearsal. Original photos remain unchanged. Before later inpainting, any overlap with original-photo traffic must be resolved. Background positions in this 3D rehearsal are not an exact replay of the photographs.
After scene approval
The working pipeline will edit each original NAVSIM camera photograph with Image 2.5. Its same-time Higgsfield view will provide position and posture, annotated with facing direction and current speed. Temporal image requests will cover the full event with a 1 Hz base plus critical moments.
Assumptions and source provenance
- Observed reference evidence is Image 2 and the police map, including a built-up street, parked vehicles, and an overhead enclosed walkway. The accident, officers, and their actions are counterfactual proposals.
- The unspecified traffic arrangement is made explicit as four modest vehicles: two incident sedans, one parked police car, and one directed following sedan. Ego is additional and separately controlled.
- Officers and the warning cone are already nearby during slow-traffic management before the gentle contact; no instantaneous emergency response or actor spawning is implied.
- Vehicle occupants remain inside their vehicles and are not separately instantiated critical actors. No injury detail or vehicle evacuation is proposed.
- Playback is finite from -7 to 40 seconds at 20 Hz. Use smooth bounded interpolation, enforce stationary holds, and treat nonhuman stand poses as neutral rigid-object poses.
- For attachment consistency, interpret the supplied ground plane as g(x,y)=a*x+b*y+c. Camera key z values compensate for slope while preserving its fixed local vertical offset.
- Photographed background occupancy is not fully encoded by the road rings; human review must reject any placement conflicting with a real retained background object.
- This JSON records a proposal and requested checks, not completed simulation validation or generated imagery.
Fresh GPT-6 motion plans use semantic descriptions from the pinned consolidated catalog and NAVSIM environments. No upstream nuPlan vectors, trajectories or images are used. The four source environments are reused; 82 scenario descriptions do not mean 82 independent locations.
Higgsfield revision 1. The portable GLB combines export clips without changing geometry or animation samples.
This review uses Higgsfield revision 1 and the exact exported scene snapshot.
Higgsfield workspace (latest revision) · Download animated GLB · GPT-6 scene plan · Visual review evidence · Motion checks · Approval status