MARSAD / CONSOLIDATED CATALOG / #003
Full-width eastbound parade
Awaiting your 3D scene approvalCounterfactual proposal: four modest cars lead eleven adults eastward in a coordinated procession. The following crowd spans the usable road width, leaving no vehicle-width passage. The parade continues ahead throughout the finite rehearsal.
Original description: 前方有游行队伍占据整条道路,游行队伍有多辆车和多个人,人跟随着车辆向东移动
Loading the full animated scene…
Critical moments
What to verify
- Require human review and approval before generating or editing an image.
- Verify exactly four procession vehicles and eleven individually identified adult marchers.
- Play -7 through 40 seconds at 20 Hz, with 941 inclusive frames and no looping or disappearing actors.
- Verify all vehicle footprints remain non-overlapping and inside the cargo road polygon throughout the eastward progression.
- Verify pedestrian body clearance exceeds 0.6 m, and the following row remains more than 6 m behind the vehicle rear footprints.
- Verify that neither gaps between marchers nor gaps at the road edges admit the ego vehicle with clearance; full-width occupation must persist.
- Verify walking speed remains approximately 0.803 m/s and headings track the road-aligned eastward motion.
- Keep ego stopped through the endpoint; advancing the parade farther east is not equivalent to clearing the corridor.
Review notes
Reviewed full parade sequence and native front camera. Four lead vehicles and the following line of people advance east together while the ego holds. All members remain present. Reconciled background traffic is visibly separated from the procession.
Check action, relative position, facing, posture and visibility. Approximate offsets are acceptable. Sampled visual checks do not prove every contact or continuous collision clearance.
Rendered inspection views
Event, approach and final views rendered from the exact committed Higgsfield Blender source. These are procedural 3D previews, not generated training photographs.
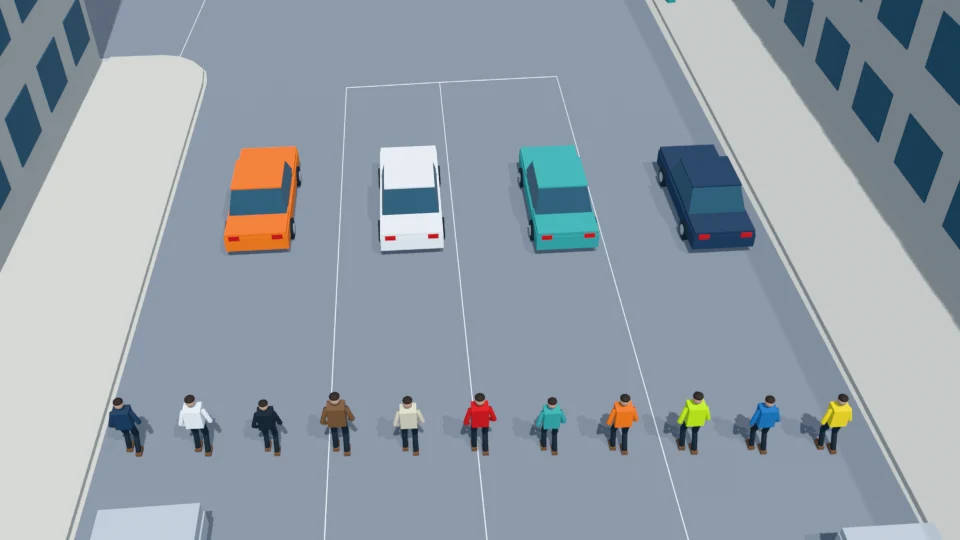
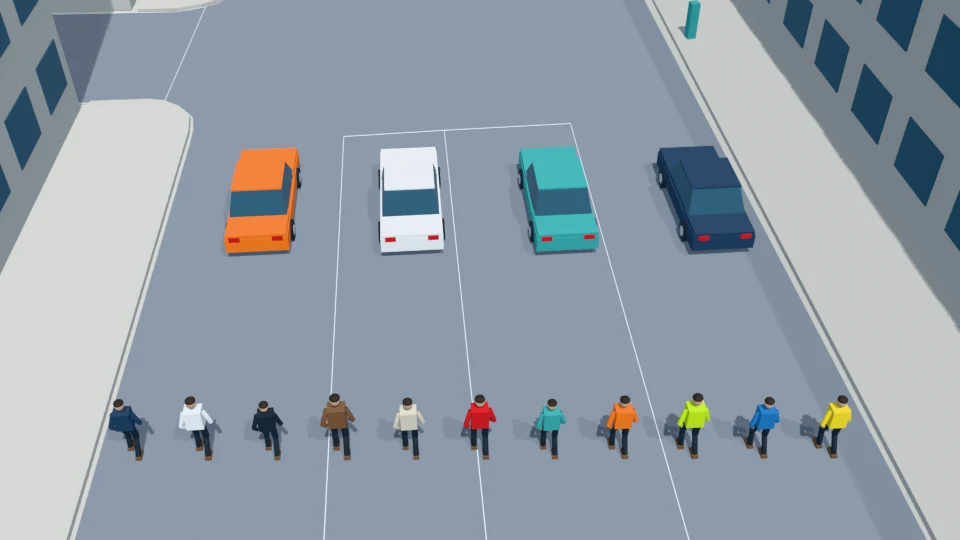
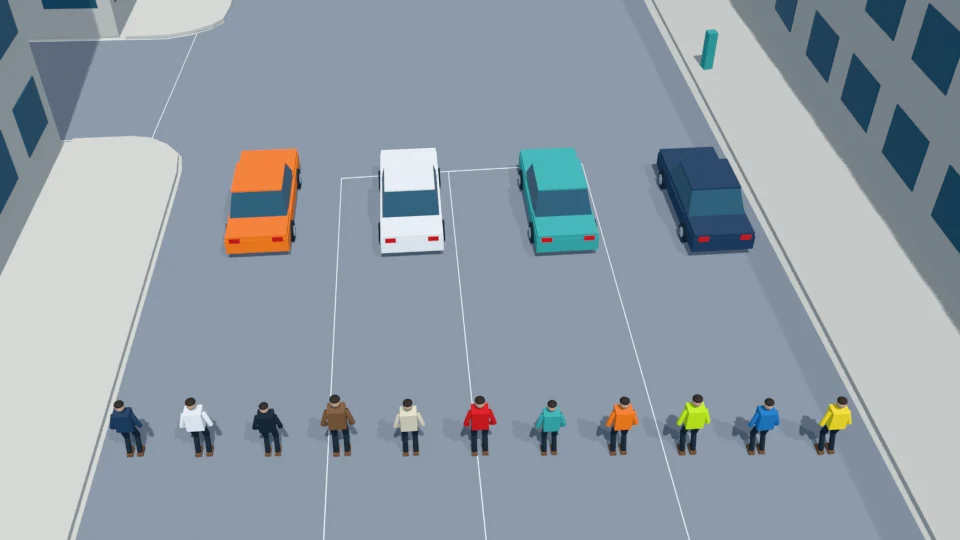
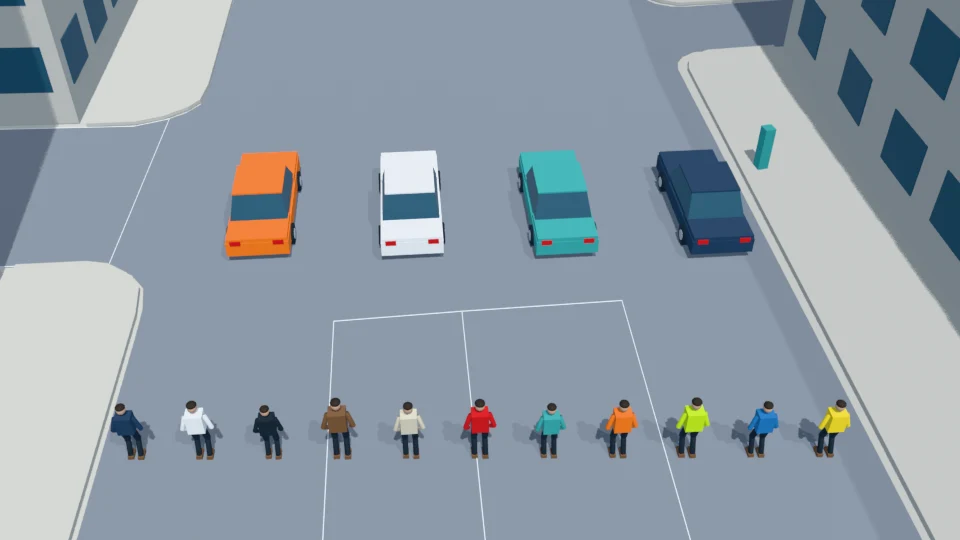
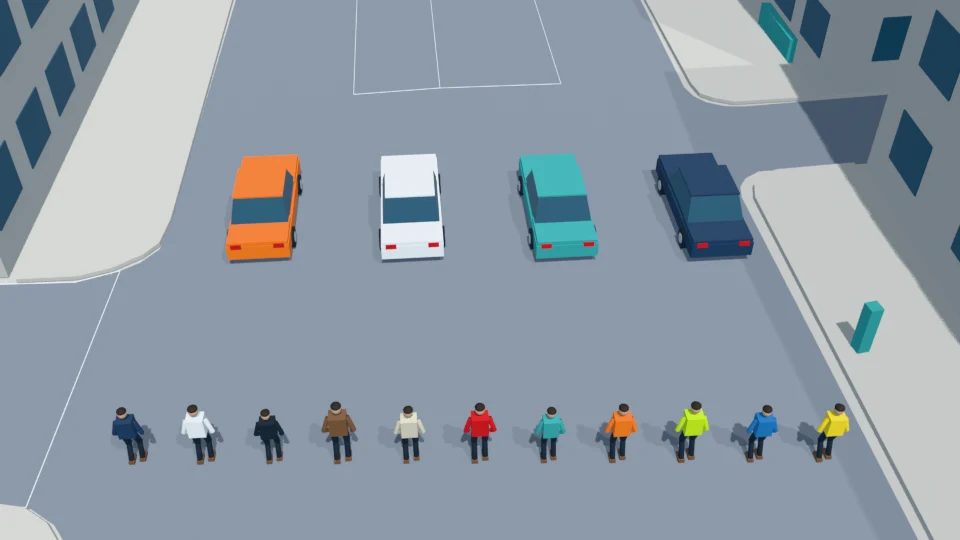
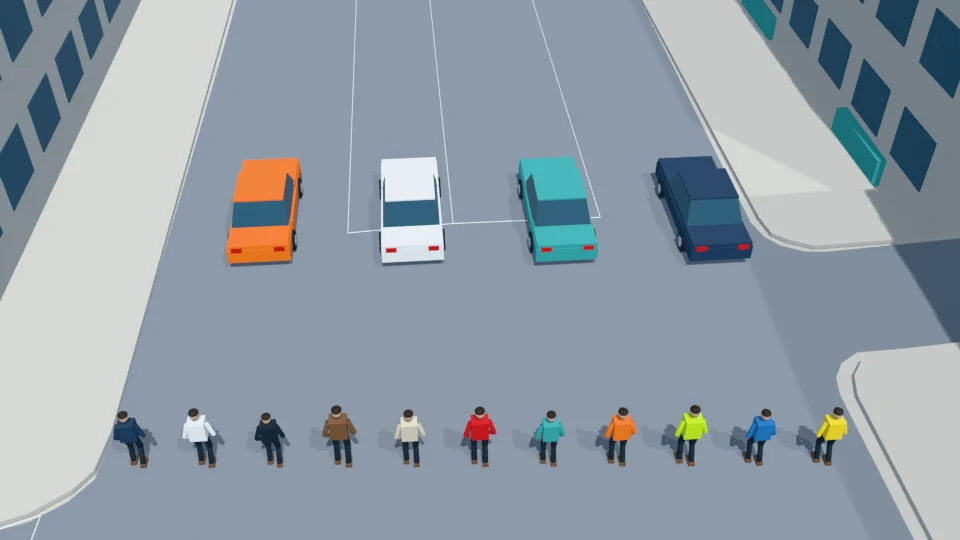
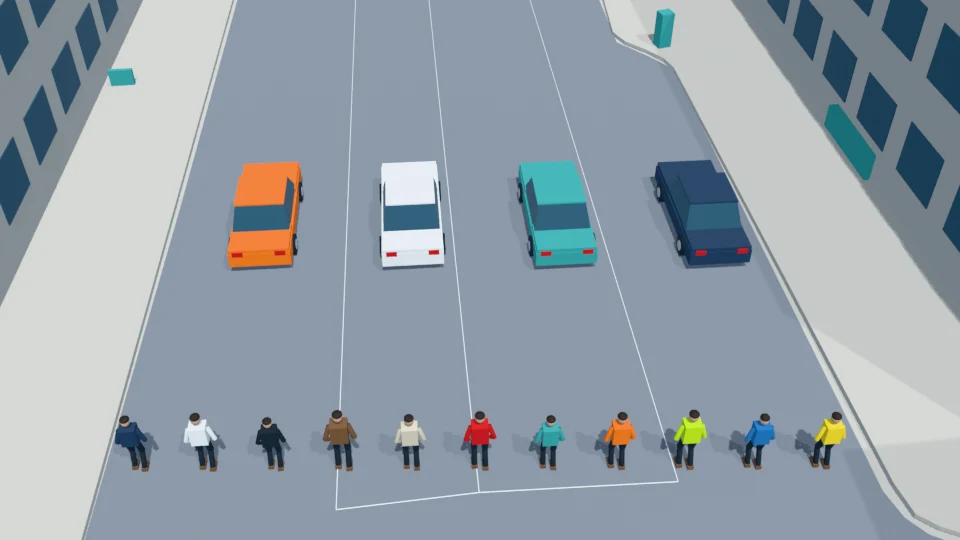
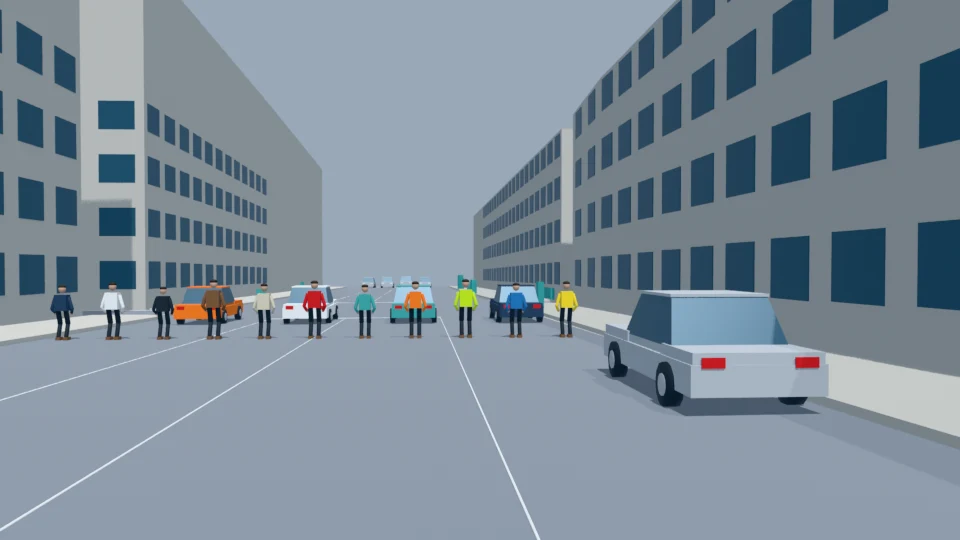
Original NAVSIM camera context
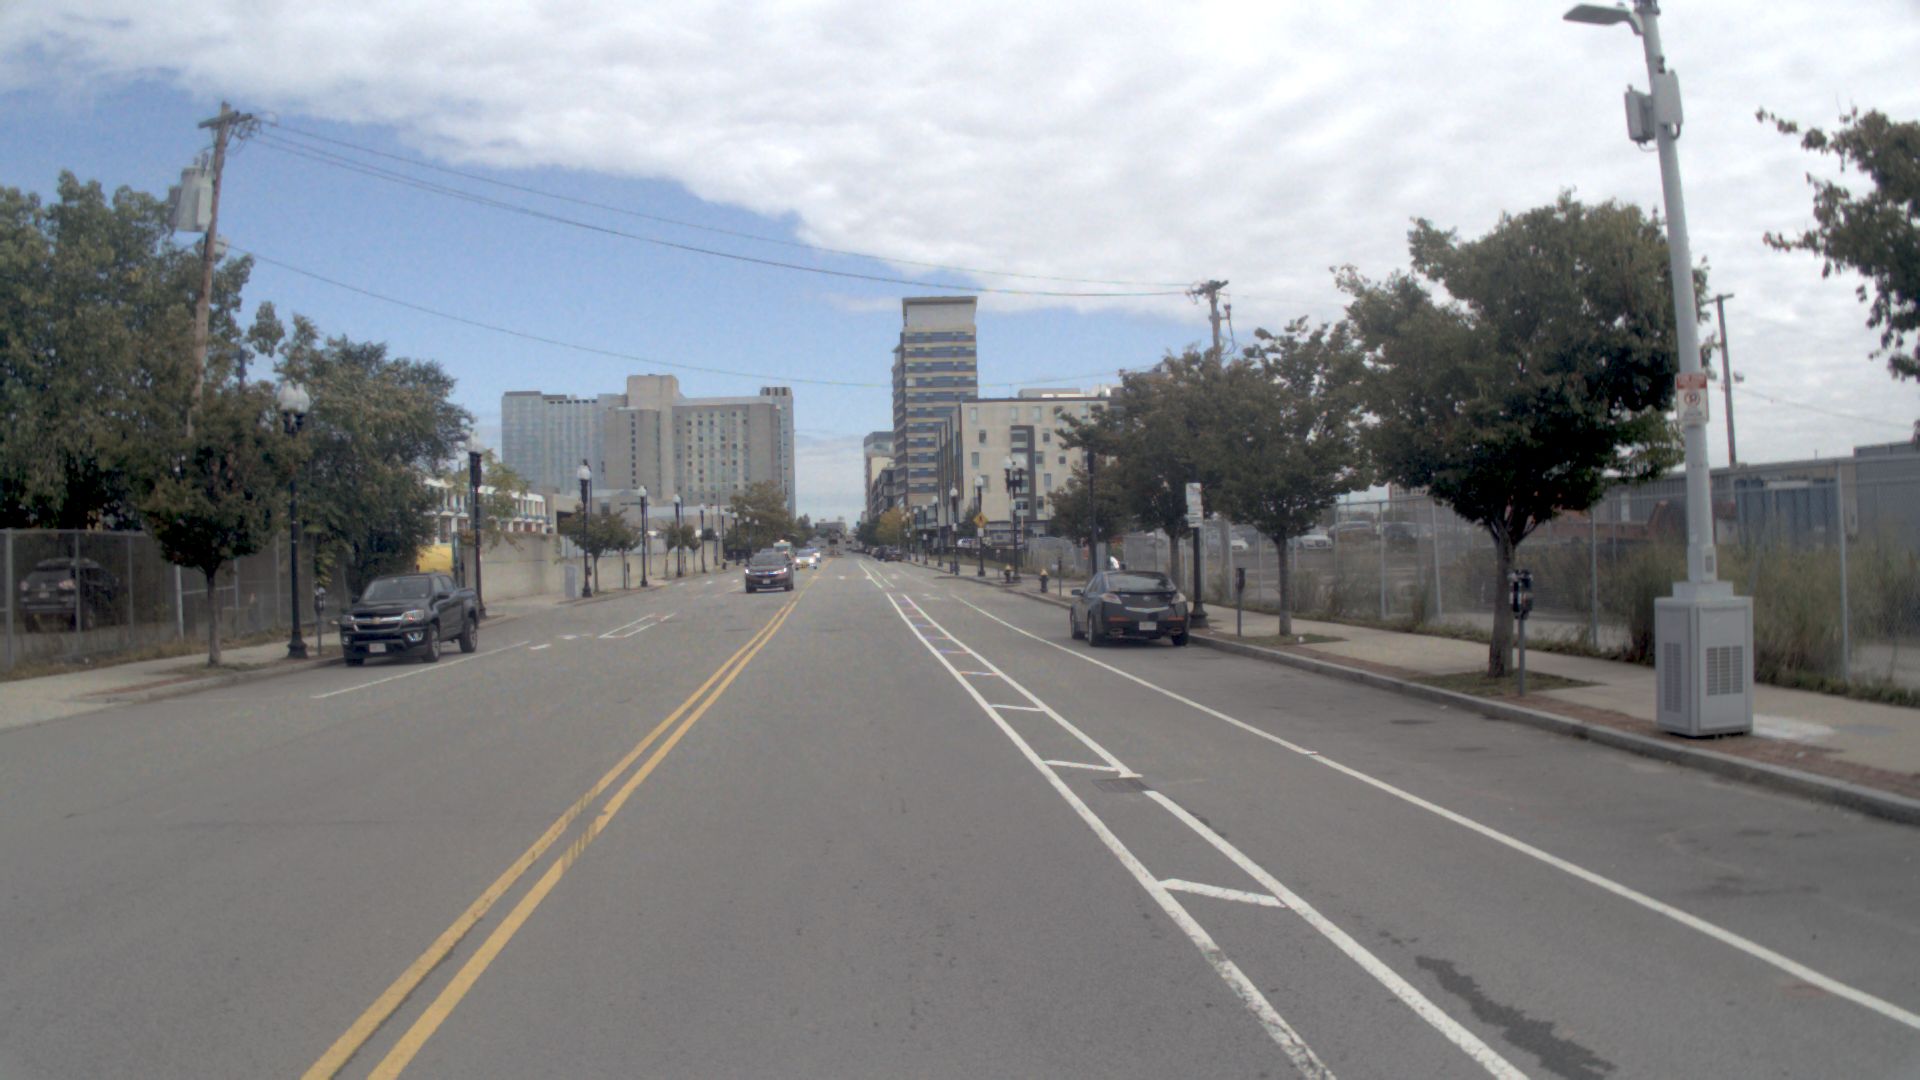
7 conflicting background vehicles were moved to clear holding positions for this counterfactual rehearsal. Original photos remain unchanged. Before later inpainting, any overlap with original-photo traffic must be resolved. Background positions in this 3D rehearsal are not an exact replay of the photographs.
After scene approval
The working pipeline will edit each original NAVSIM camera photograph with Image 2.5. Its same-time Higgsfield view will provide position and posture, annotated with facing direction and current speed. Temporal image requests will cover the full event with a 1 Hz base plus critical moments.
Assumptions and source provenance
- Image 3 establishes a broad marked roadway, sidewalks, fencing and distant buildings. The parade is proposed, not observed.
- The underspecified multiple-vehicle interaction is instantiated as exactly four modest passenger cars moving in parallel, followed by eleven adults. Vehicle occupants are enclosed, non-critical occupants rather than additional marching actors.
- Eastward motion includes a northward component of 0.08 m per metre of eastward travel to follow the supplied road geometry. The initial interaction is within x=31..46; continued motion extends beyond the usual work area while remaining on the map.
- Full-road occupation means no vehicle-width passage through or around the following crowd, not overlapping people or physically covering every centimetre of pavement.
- Ego is implicit: x=0, y=0 and speed 6 m/s at -7 seconds, smooth deceleration at 1.5 m/s squared to x=12 at -3 seconds, then a stationary hold.
- All support roots use z=0 above their mapped surfaces. The finite timeline ends with the procession still moving; no turnaround, removal or repeated cycle is proposed.
- Any later Image 2.5 edit must use original Image 3 only after human approval, taking position and posture guidance from this rehearsal. Background parked-vehicle positions are not supplied in 3D and require overlap review.
Fresh GPT-6 motion plans use semantic descriptions from the pinned consolidated catalog and NAVSIM environments. No upstream nuPlan vectors, trajectories or images are used. The four source environments are reused; 82 scenario descriptions do not mean 82 independent locations.
Higgsfield revision 2. The portable GLB combines export clips without changing geometry or animation samples.
This review uses Higgsfield revision 2 and the exact exported scene snapshot.
Higgsfield workspace (latest revision) · Download animated GLB · GPT-6 scene plan · Visual review evidence · Motion checks · Approval status