MARSAD / CONSOLIDATED CATALOG / #012
Two scooters and a backward pickup
Awaiting your 3D scene approvalTwo children cross on kick scooters. One continues while the other stops, looks back and retrieves a dropped toy box.
Original description: 前方两名儿童滑着滑板车横穿马路,其中一人停下回头捡物,另一人继续前行
Loading the full animated scene…
Critical moments
What to verify
- Verify exactly two children, two kick scooters and one toy box: the children are included in the two scooter actors, never duplicated as separate actors.
- Evaluate 941 samples at 20 Hz over -7..40 s; maintain the 2.9 m lateral separation of scooter roots and check articulated scooter, child and hand envelopes during both manual pivots.
- Show Child A braking, looking back, returning south, crouching and lifting the object while Child B continues north.
- Verify ground contact through curb transitions without inventing a ramp; the child may articulate and hand-lift the lightweight scooter while the composite support root remains grounded.
- Verify continuous pickup at 5.3..6 s and attachment without a position jump; retain the same toy ID in the hand through the final frame.
- Keep ego stopped at x=12 until at least 16 s, after both complete footprints and the carried box are on the north sidewalk.
- Require full-timeline human review before Image 2.5 edits original Image 1; unresolved source-vehicle or curb conflicts block image generation.
Review notes
Reviewed both child scooter riders, the stop and turn, toy pickup and departure. Riders stay attached to their scooters and the toy transfers continuously to the hand. Close-up contact is approximate but the retrieval sequence is readable.
Check action, relative position, facing, posture and visibility. Approximate offsets are acceptable. Sampled visual checks do not prove every contact or continuous collision clearance.
Rendered inspection views
Event, approach and final views rendered from the exact committed Higgsfield Blender source. These are procedural 3D previews, not generated training photographs.
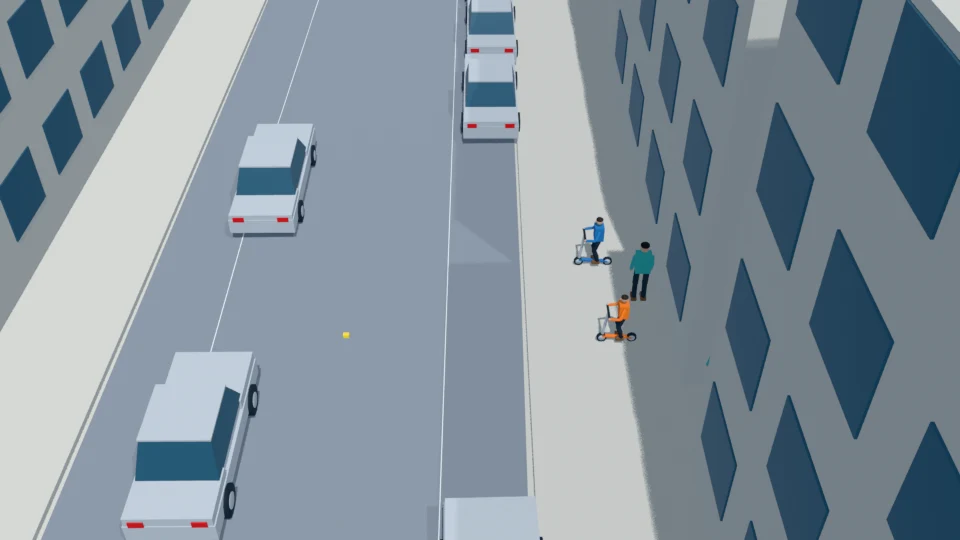
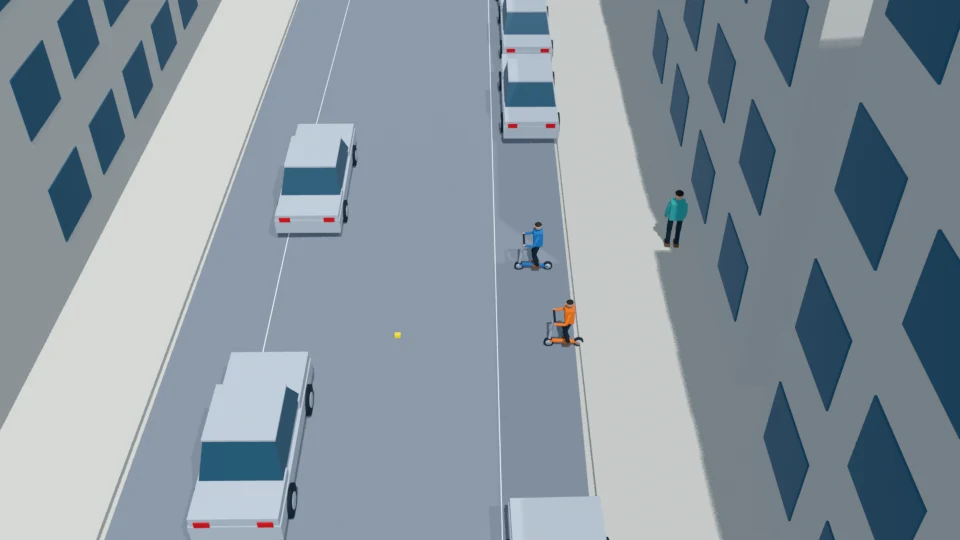
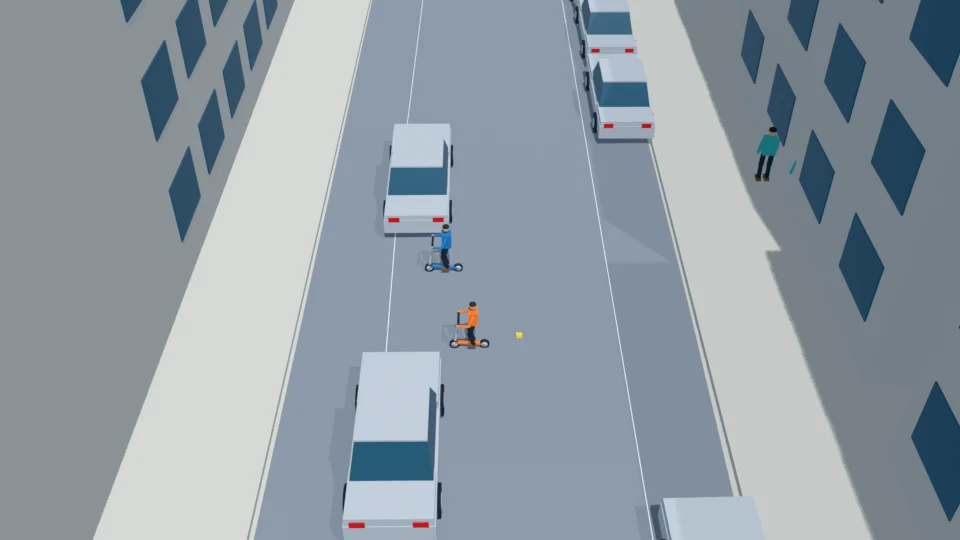
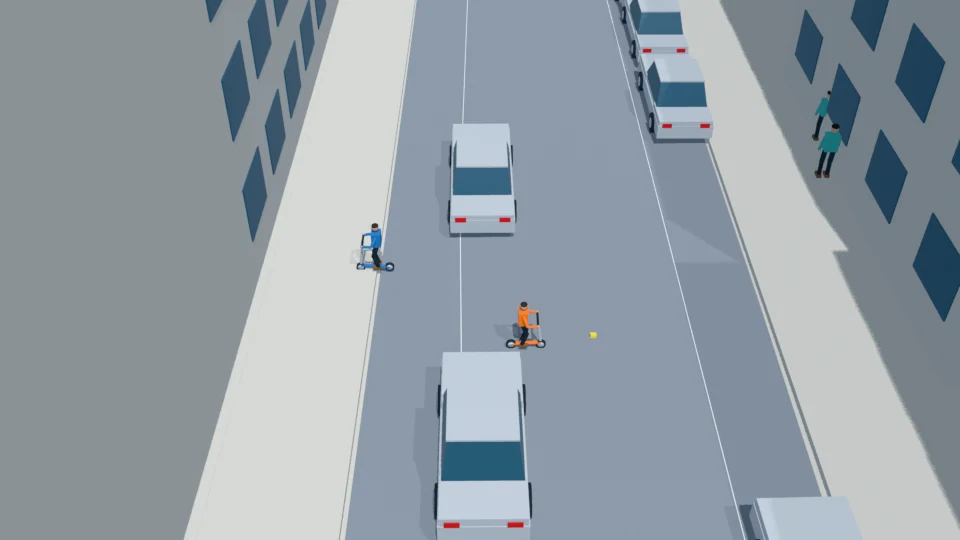
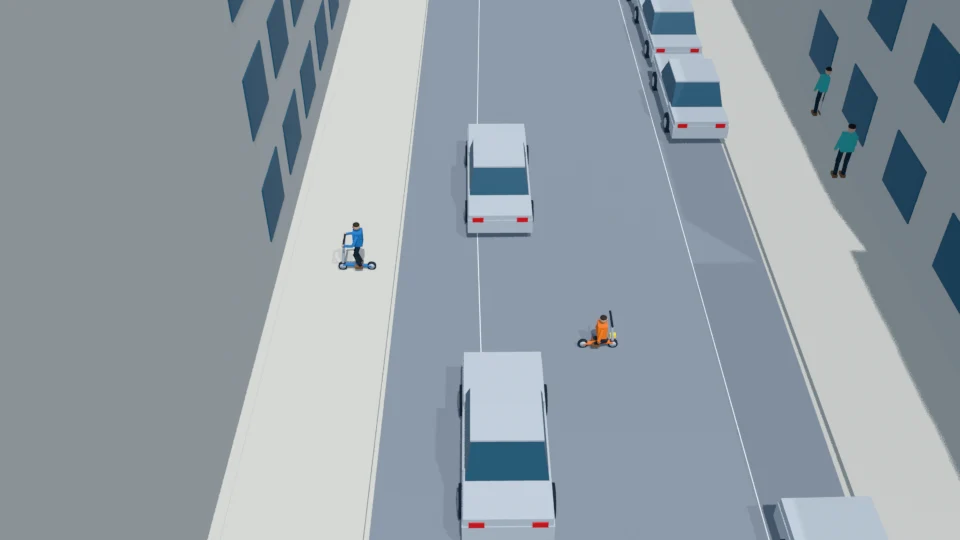
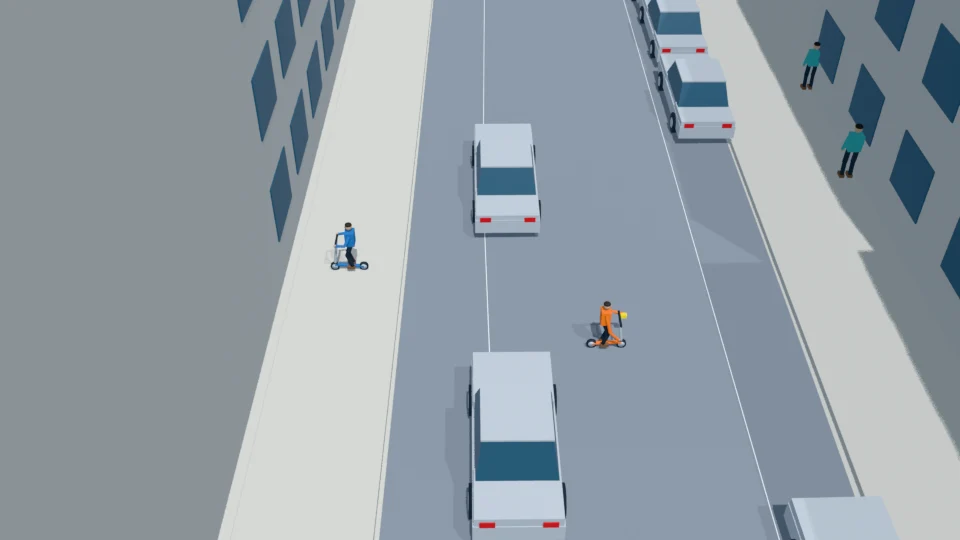
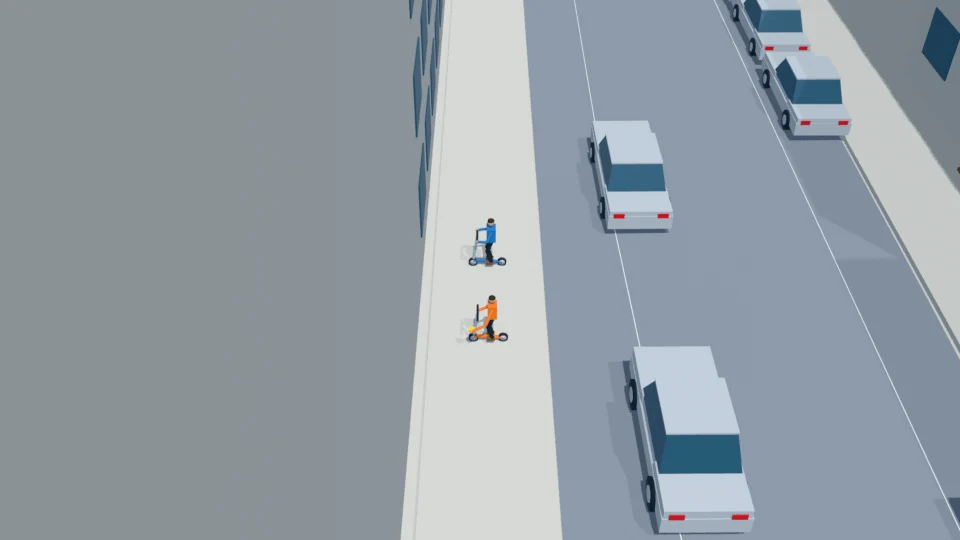
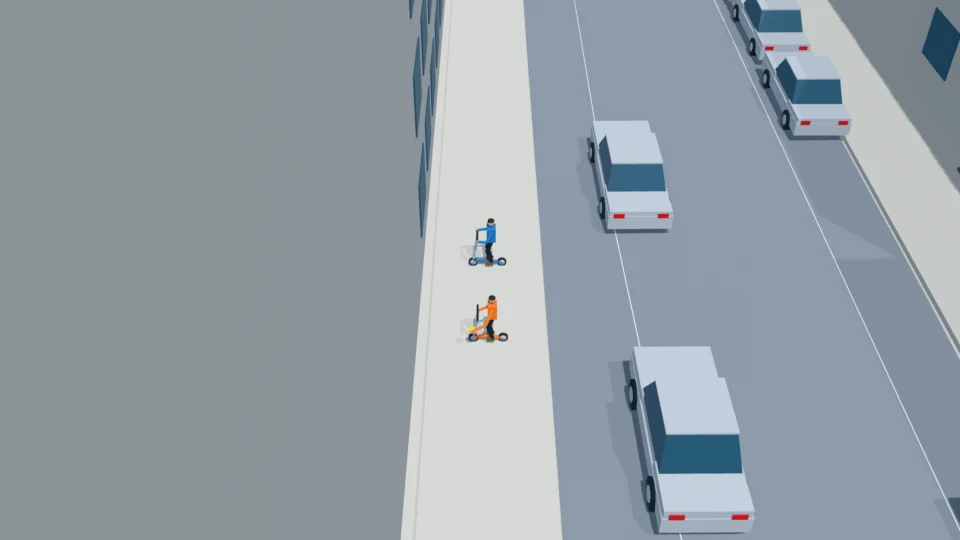
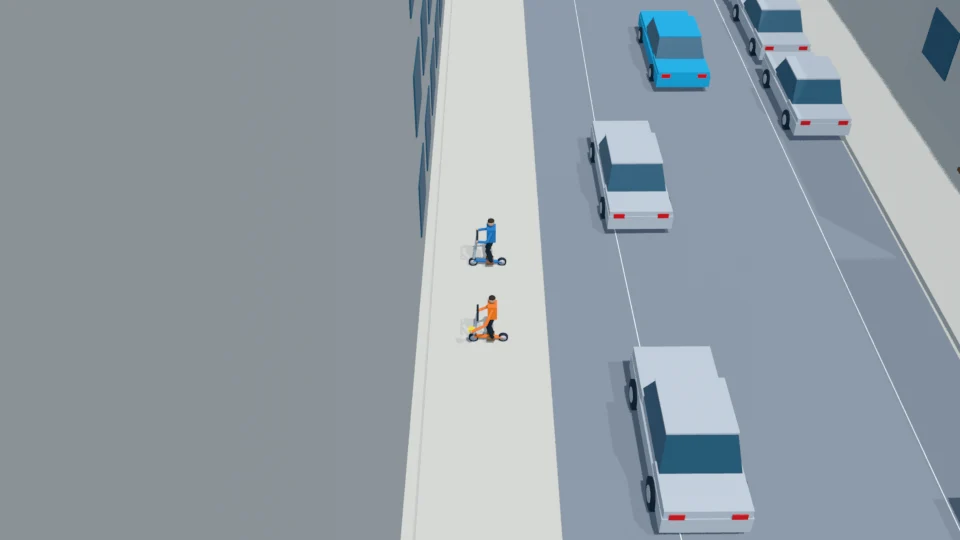
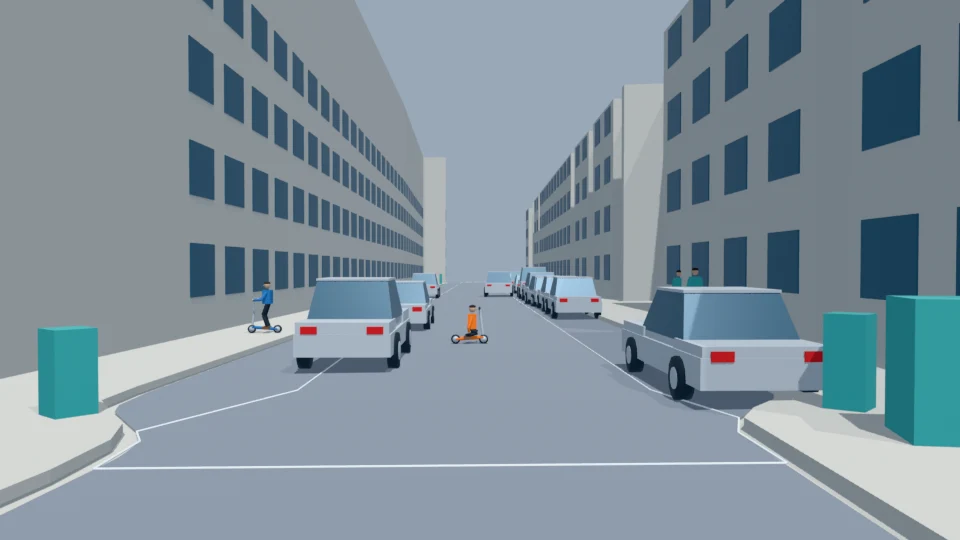
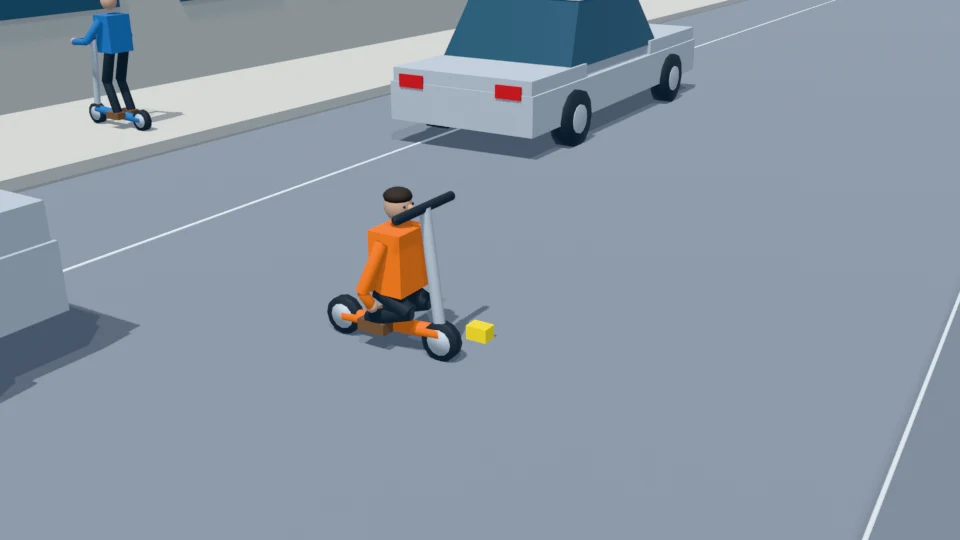
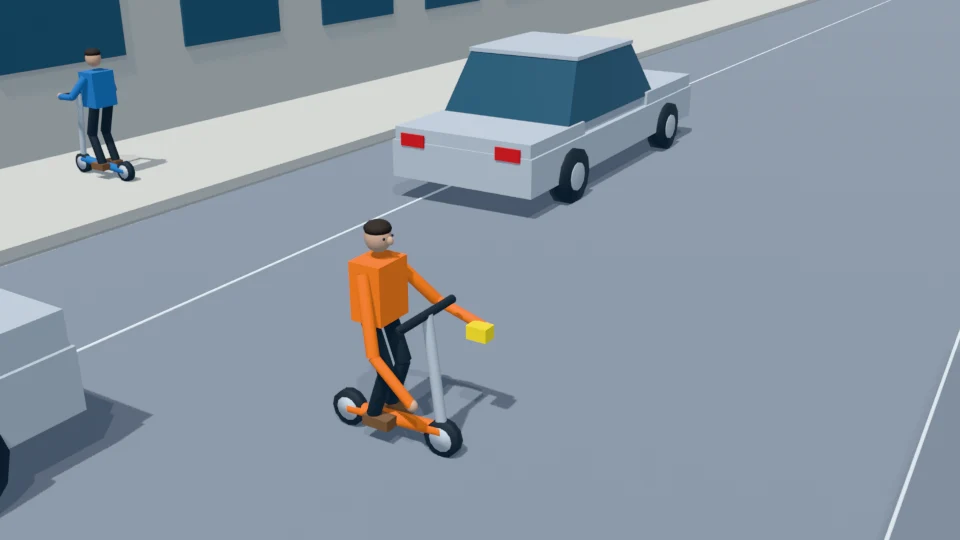
Original NAVSIM camera context
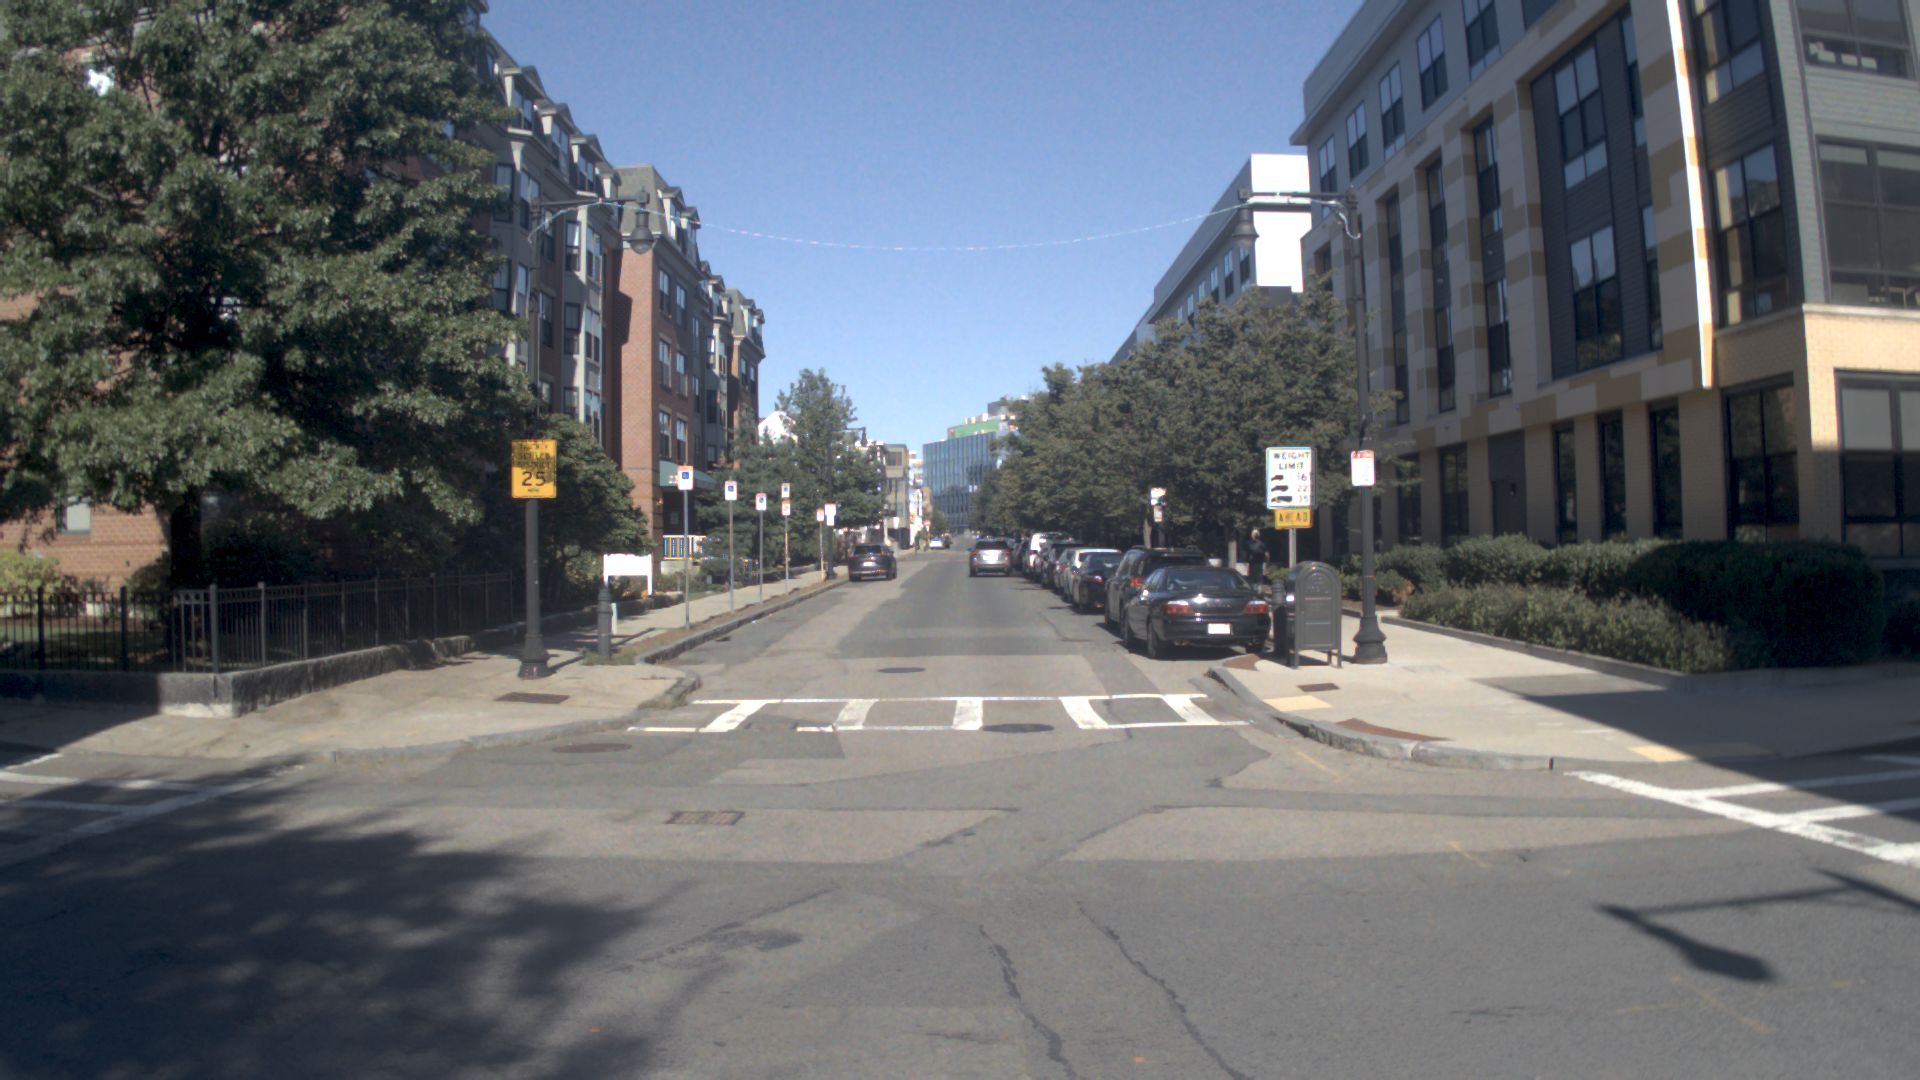
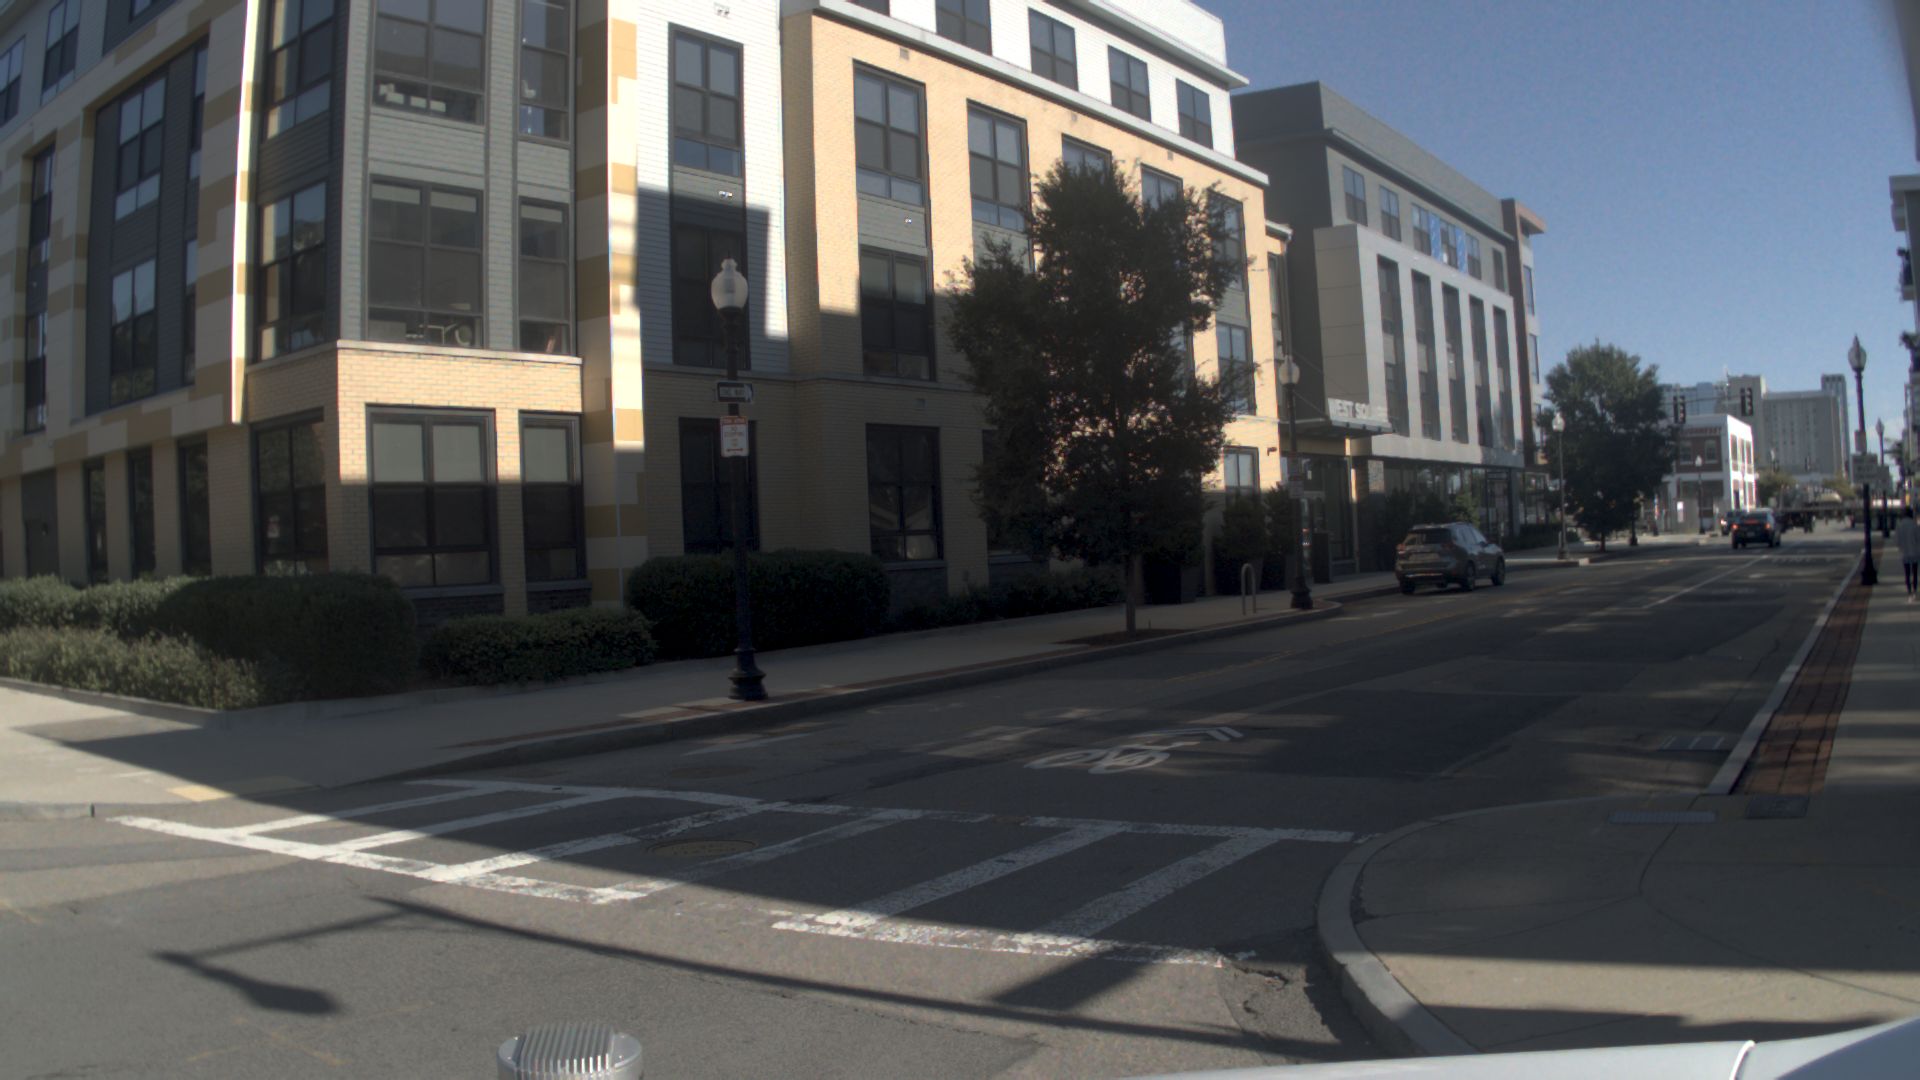
2 conflicting background vehicles were moved to clear holding positions for this counterfactual rehearsal. Original photos remain unchanged. Before later inpainting, any overlap with original-photo traffic must be resolved. Background positions in this 3D rehearsal are not an exact replay of the photographs.
After scene approval
The working pipeline will edit each original NAVSIM camera photograph with Image 2.5. Its same-time Higgsfield view will provide position and posture, annotated with facing direction and current speed. Temporal image requests will cover the full event with a 1 Hz base plus critical moments.
Assumptions and source provenance
- All children, scooters, the toy and their coordinates are counterfactual additions. Original Image 1 supplies the residential streetscape; the wheelchair map supplies the road and sidewalk polygons.
- The unspecified retrieved object is authored as one small toy box already lying in the road at -7 s. No unseen fall or prior attachment is asserted.
- The crossing is transverse and unmarked at x=33.4 and x=36.3. No new crosswalk or curb ramp is assumed; the composite riders hand-walk or hand-lift their scooters at existing curb transitions.
- Playback is finite and non-looping at 20 Hz from -7 through 40 s. Use bounded C1 motion, rolling speeds up to approximately 2.1 m/s, ordinary walking during the return, and zero translational velocity during planted manual turns.
- Ground uses the supplied plane. Human and wheel support roots have z=0; toy key heights at attachment compensate the plane gradient so the local hand offset meets the world path.
- Ego is the simulator vehicle, approximately 4.6 by 1.85 m, stopped with its center at x=12, y=0 by -3 s. Release at 16 s is conditional on an actually clear buffered corridor.
- Exact curb profiles and photographed parked-vehicle depths are uncertain. The 4.4 s review seek point does not replace approval of the complete rehearsal; no image generation has been performed.
Fresh GPT-6 motion plans use semantic descriptions from the pinned consolidated catalog and NAVSIM environments. No upstream nuPlan vectors, trajectories or images are used. The four source environments are reused; 82 scenario descriptions do not mean 82 independent locations.
Higgsfield revision 1. The portable GLB combines export clips without changing geometry or animation samples.
This review uses Higgsfield revision 1 and the exact exported scene snapshot.
Higgsfield workspace (latest revision) · Download animated GLB · GPT-6 scene plan · Visual review evidence · Motion checks · Approval status