MARSAD / CONSOLIDATED CATALOG / #021
Child retrieves a rolling ball from the road center
Awaiting your 3D scene approvalA ball rolls from the southern roadway edge toward the geometric road center. A child leaves the south sidewalk, walks across ego's held corridor, crouches to collect the ball, then carries it back to the sidewalk before ego resumes.
Original description: 前方有儿童在捡拾滚到马路中央的皮球或玩具。
Loading the full animated scene…
Critical moments
What to verify
- Require exactly one child and one ball, both present throughout all 941 playback samples.
- Check that the rolling ball remains inside the road polygon and stops near y=4.6, the approximate road midpoint at x=36, rather than teleporting to the pickup position.
- Require walking cruise speeds of 0.6 to 1.7 m/s, bounded acceleration, and complete stops for pickup and both stationary turns.
- Check forward hand contact during the crouched pickup, continuous lift from 5 to 7 seconds, and matching attachment position at 7 seconds within 1 mm.
- At 16 seconds, require the child and entire held ball to be inside the south sidewalk polygon; keep them there through 40 seconds.
- Keep ego at x=14 through the child's outward and return passages across y=0. Release at 19 seconds only after the complete ego swept corridor is clear.
- Human review must approve road-center placement, retained-photo obstacle clearance, ball contact, and the full timeline before image generation; these are unexecuted acceptance requirements.
Review notes
Reviewed ball roll, child's approach, crouched pickup, carried-ball return and final clearance. The ball remains present and hand attachment is continuous. Front view and contact views show the key retrieval event.
Check action, relative position, facing, posture and visibility. Approximate offsets are acceptable. Sampled visual checks do not prove every contact or continuous collision clearance.
Rendered inspection views
Event, approach and final views rendered from the exact committed Higgsfield Blender source. These are procedural 3D previews, not generated training photographs.
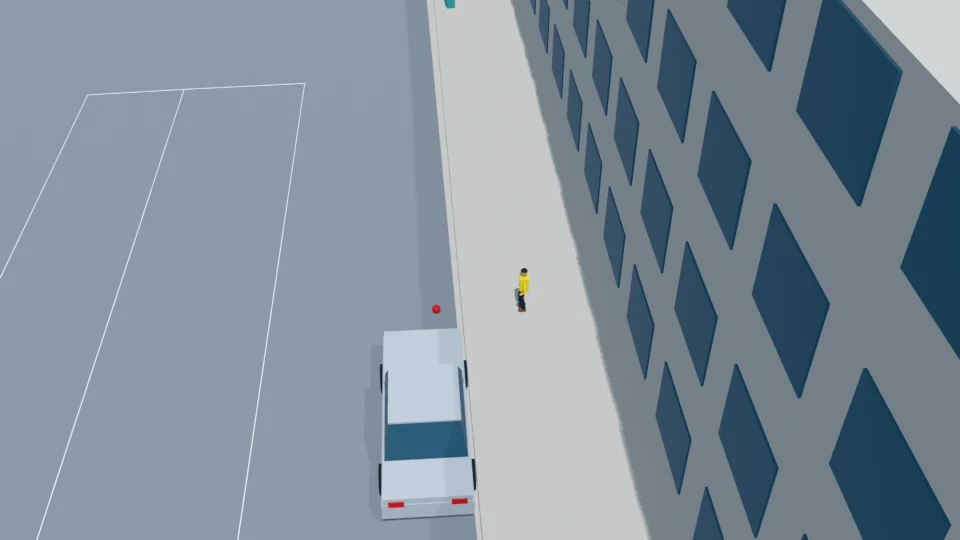
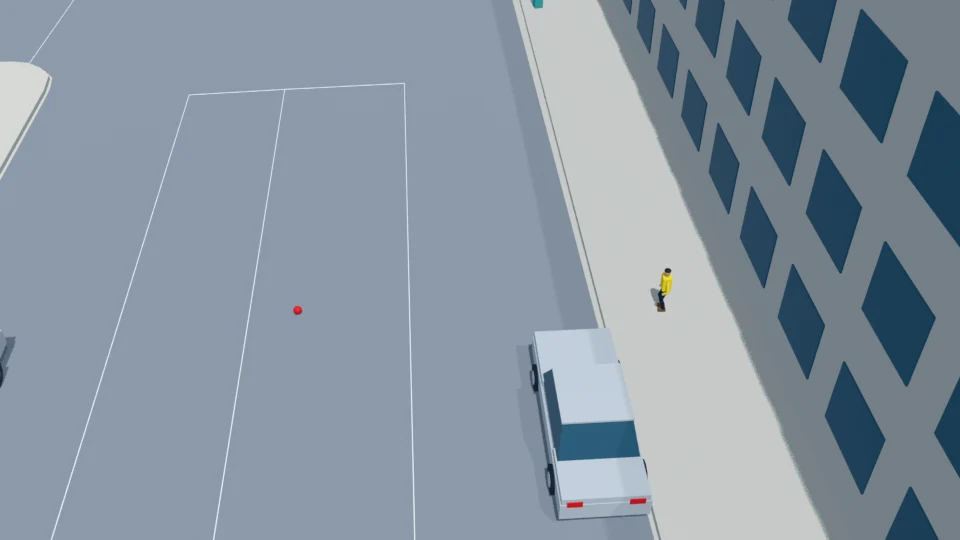
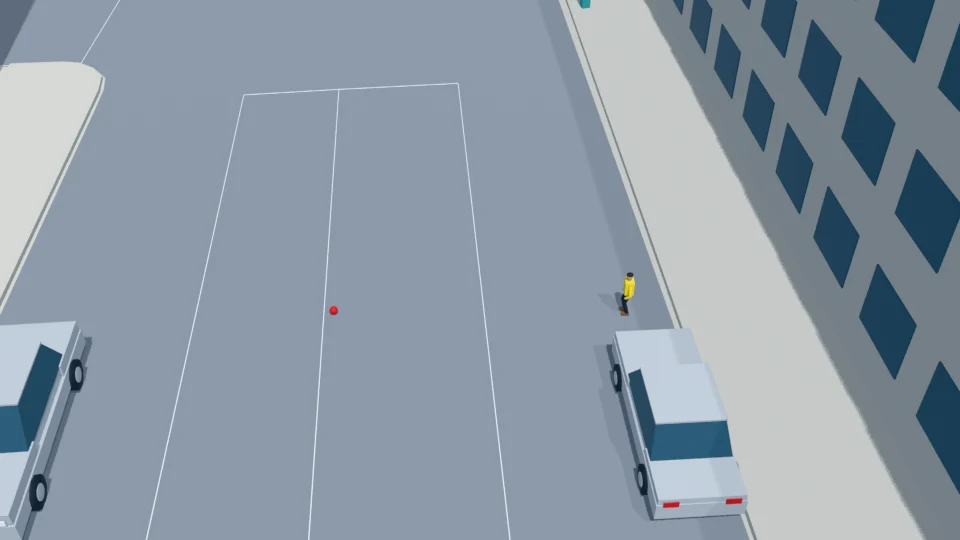
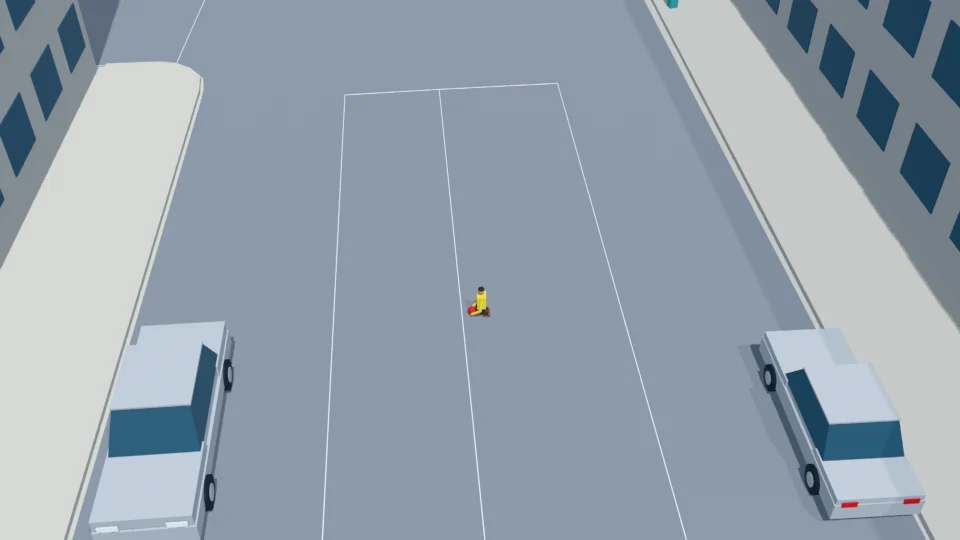
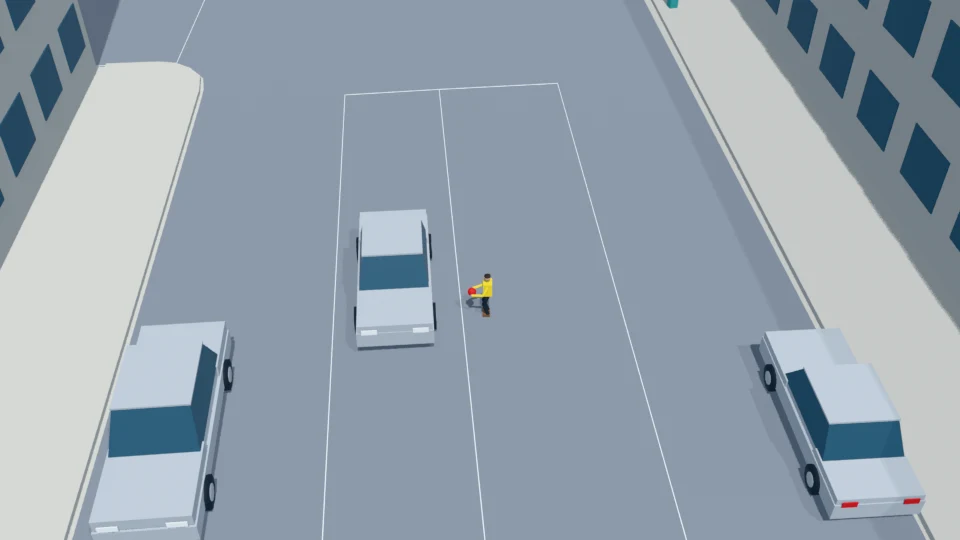
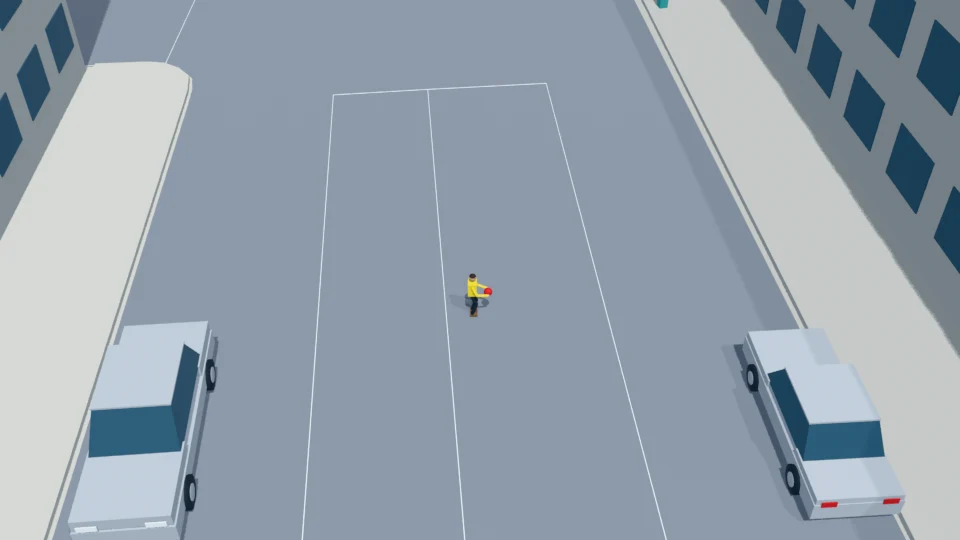
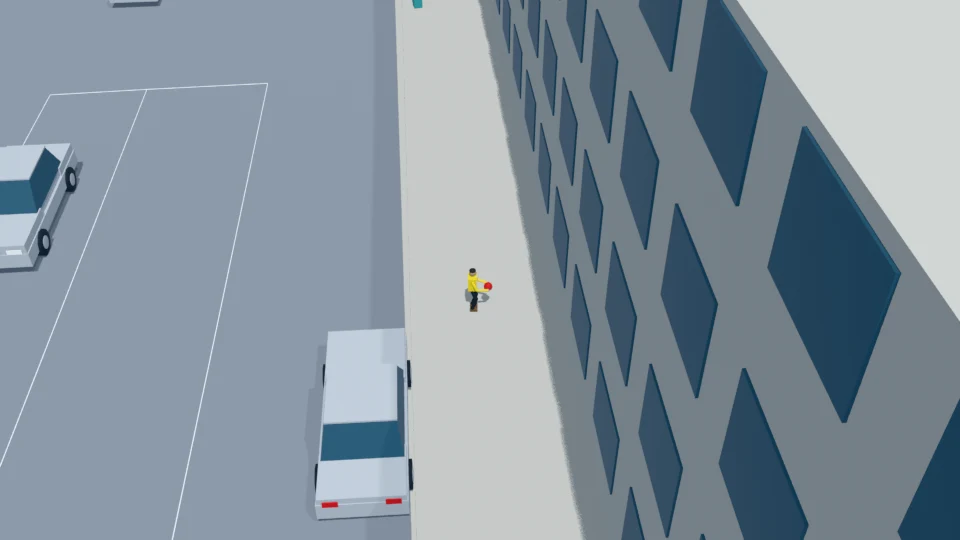
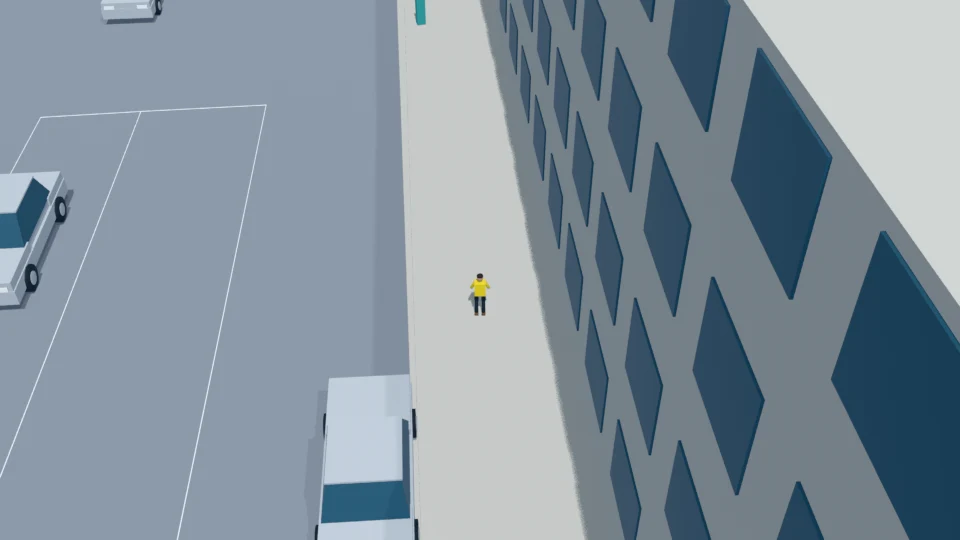
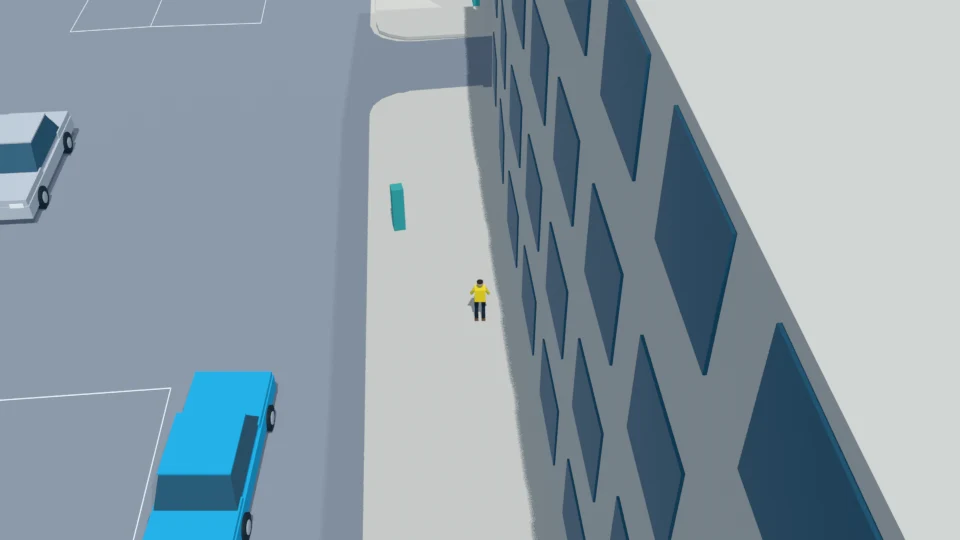
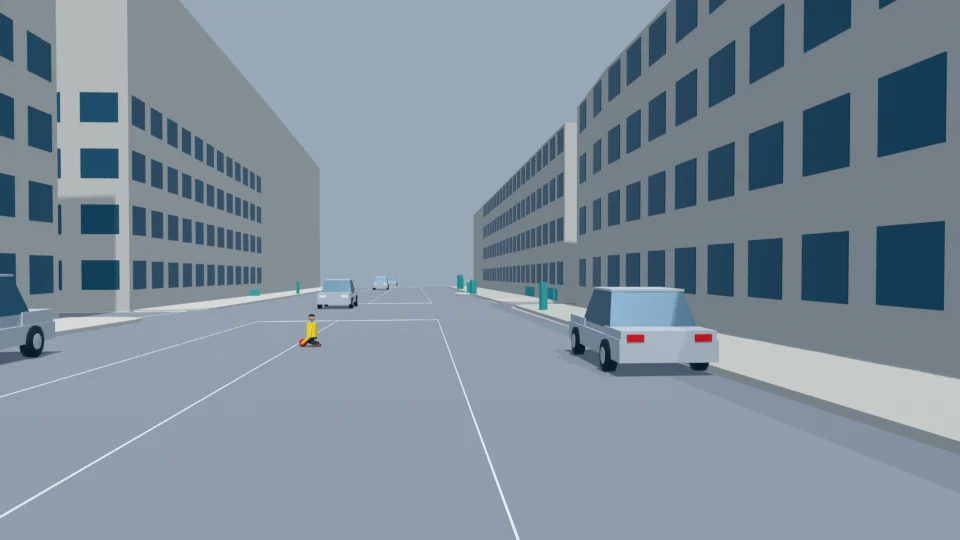
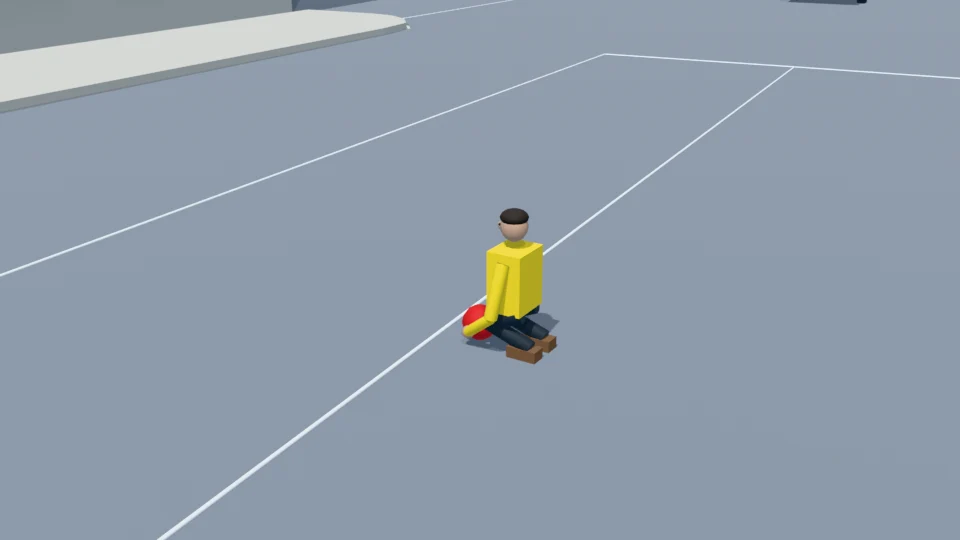
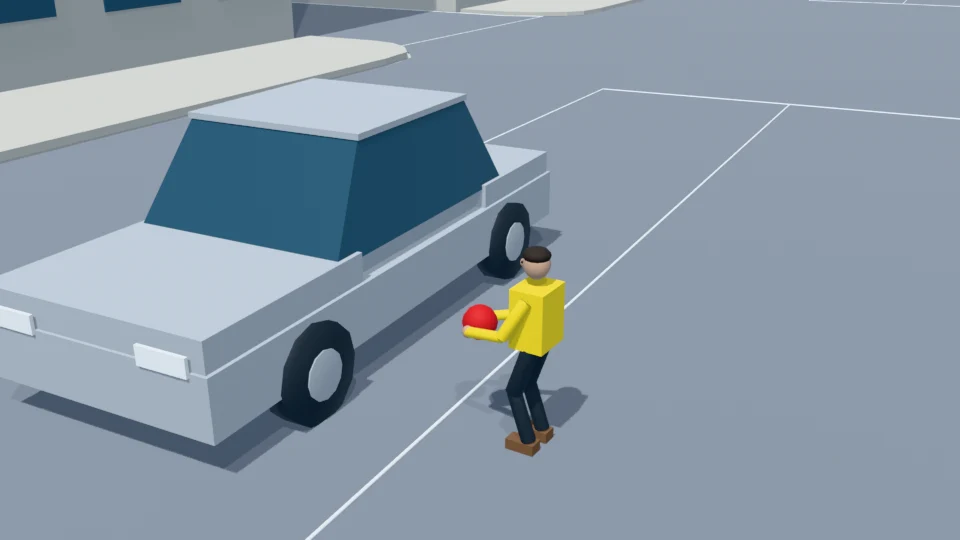
Original NAVSIM camera context
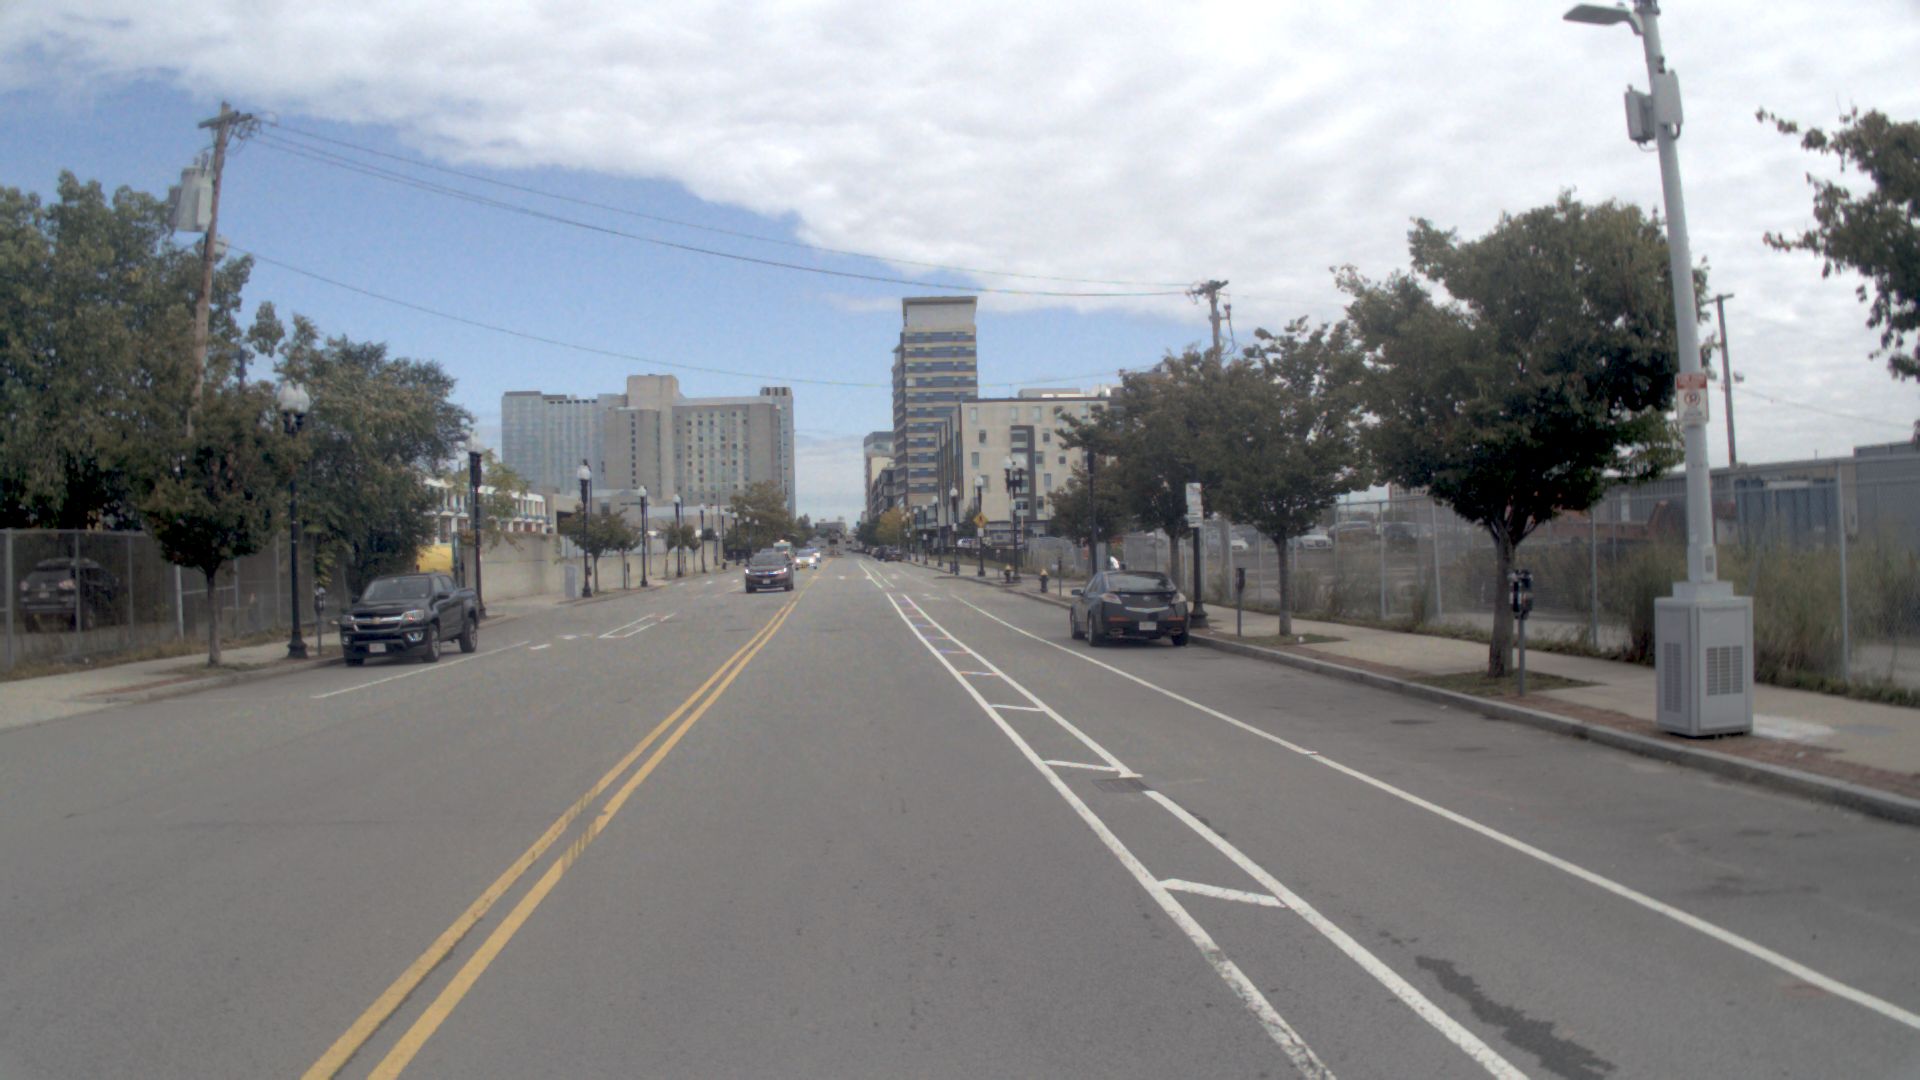
1 conflicting background vehicles were moved to clear holding positions for this counterfactual rehearsal. Original photos remain unchanged. Before later inpainting, any overlap with original-photo traffic must be resolved. Background positions in this 3D rehearsal are not an exact replay of the photographs.
After scene approval
The working pipeline will edit each original NAVSIM camera photograph with Image 2.5. Its same-time Higgsfield view will provide position and posture, annotated with facing direction and current speed. Temporal image requests will cover the full event with a 1 Hz base plus critical moments.
Assumptions and source provenance
- Image 3 and the cargo map establish broad roadway and sidewalk context. The child, ball, initial rolling momentum, coordinates, and timing are newly authored counterfactuals.
- At x=36, the supplied road extends approximately from y=-3.9 to y=13.1; y=4.6 therefore represents its geometric middle. The return destination y=-5.6 is on the mapped south sidewalk.
- The ball has already crossed the curb before -7 seconds. Its initial northward speed is approximately 2.29 m/s and decreases to zero over seven seconds, avoiding an invented curb-drop animation or kick.
- Playback is finite and non-looping from -7 through 40 seconds at 20 Hz, including both endpoints. Use bounded-speed trajectories, explicit stationary turns, and no interpolation overshoot.
- Human and rolling-ball support roots use z=0 on mapped ground. Held-ball support offsets include the supplied ground-plane slope; its attachment transform overrides its own keys from 7 through 40 seconds.
- Ego is implicit. It approaches along y=0 from x=13 at -7 seconds, brakes from 2 m/s to rest at x=14 by -6 seconds, and after release accelerates at no more than 0.75 m/s squared to at most 1.5 m/s.
- Static parked-vehicle footprints and curb details are not fully supplied and must be reviewed. Any later Image 2.5 generation must edit original Image 3 using this rehearsal only for actor positions and postures, after human approval.
Fresh GPT-6 motion plans use semantic descriptions from the pinned consolidated catalog and NAVSIM environments. No upstream nuPlan vectors, trajectories or images are used. The four source environments are reused; 82 scenario descriptions do not mean 82 independent locations.
Higgsfield revision 1. The portable GLB combines export clips without changing geometry or animation samples.
This review uses Higgsfield revision 1 and the exact exported scene snapshot.
Higgsfield workspace (latest revision) · Download animated GLB · GPT-6 scene plan · Visual review evidence · Motion checks · Approval status