MARSAD / CONSOLIDATED CATALOG / #022
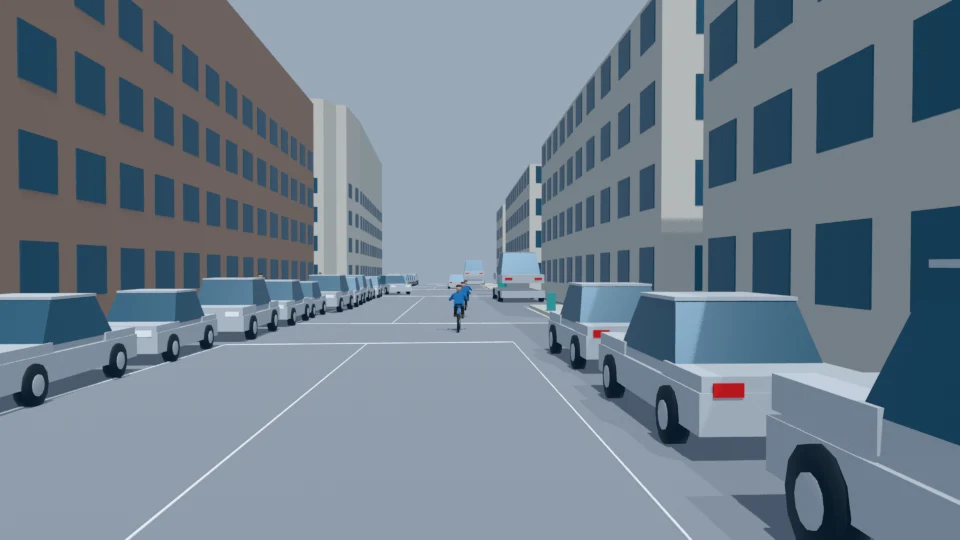
Three teenage shared-bike riders in eastbound pursuit
Awaiting your 3D scene approvalExactly three teenagers ride shared bicycles east. The leader maintains a straight line and steady pace while both following riders repeatedly increase cadence to close their gaps. They remain in safe single-file pursuit within ego's corridor through 40 seconds, so ego does not resume.
Original description: 前方三名青少年骑着共享单车,一名青少年径直往东骑行,另外两名青少年不断追赶
Loading the full animated scene…
Critical moments
What to verify
- Require exactly three cyclist actors, each including one teenager and one shared bicycle; do not create separate duplicate bicycle or rider actors.
- Keep the leader's y coordinate fixed at 0.6 and heading fixed at 0 degrees throughout the complete eastbound route.
- Require both following riders to demonstrate sustained pursuit with repeated catch-up efforts, rather than substituting a crossing or unrelated cycling event.
- At every playback sample, keep bicycle footprints inside the police road polygon and preserve at least 4 m center-to-center longitudinal separation, approximately 2.15 m clear bicycle gap.
- Use smooth forward-only bicycle motion, approximately 1.75 to 2.25 m/s, with no abrupt acceleration, overtaking, contact, or heading reversal.
- Keep all three riders present through 40 seconds and ego stopped at x=14; ego_release_s=-1 must remain in force because the riders continue occupying its corridor.
- Human review must approve the complete route, source-photo placement, counts, and continuous spacing before image generation; no validation result is asserted here.
Review notes
Inspected the sequence after widening the review camera. Three bicycle riders stay attached to their bicycles and the following gaps close during the maneuver. The leading and trailing cyclists remain distinct through the long scene.
Check action, relative position, facing, posture and visibility. Approximate offsets are acceptable. Sampled visual checks do not prove every contact or continuous collision clearance.
Rendered inspection views
Event, approach and final views rendered from the exact committed Higgsfield Blender source. These are procedural 3D previews, not generated training photographs.
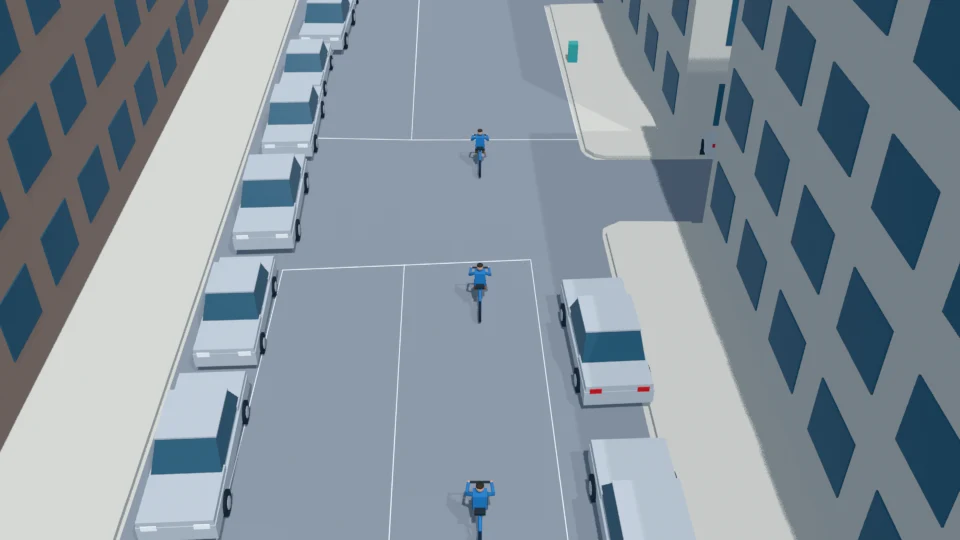
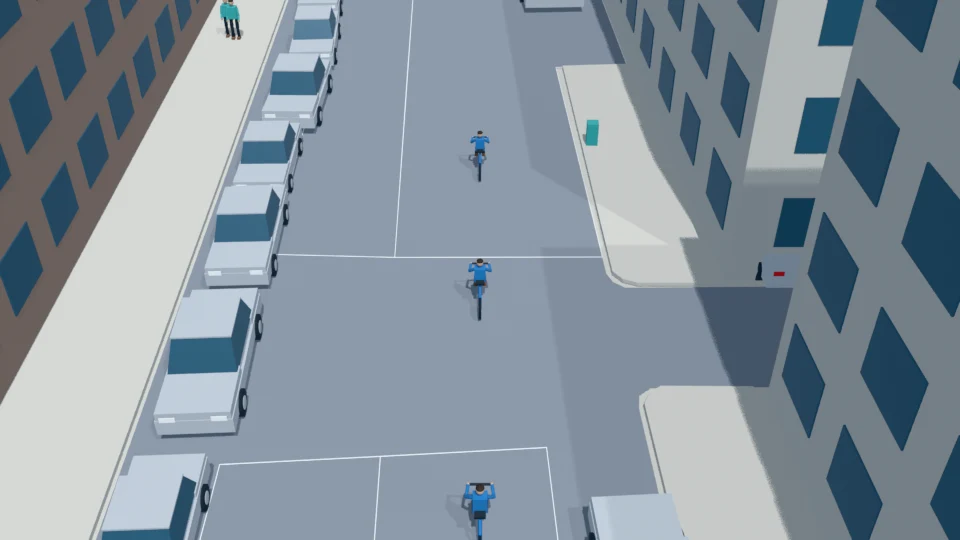
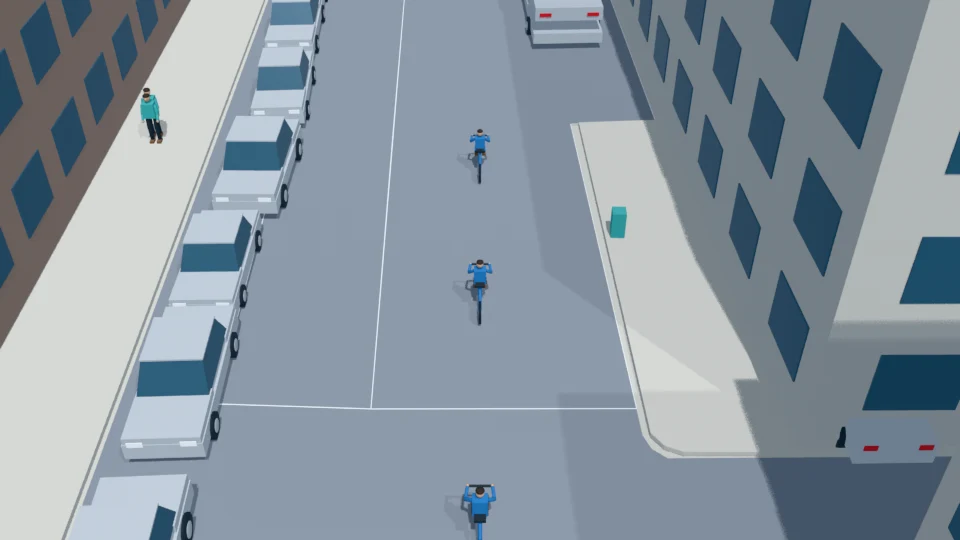
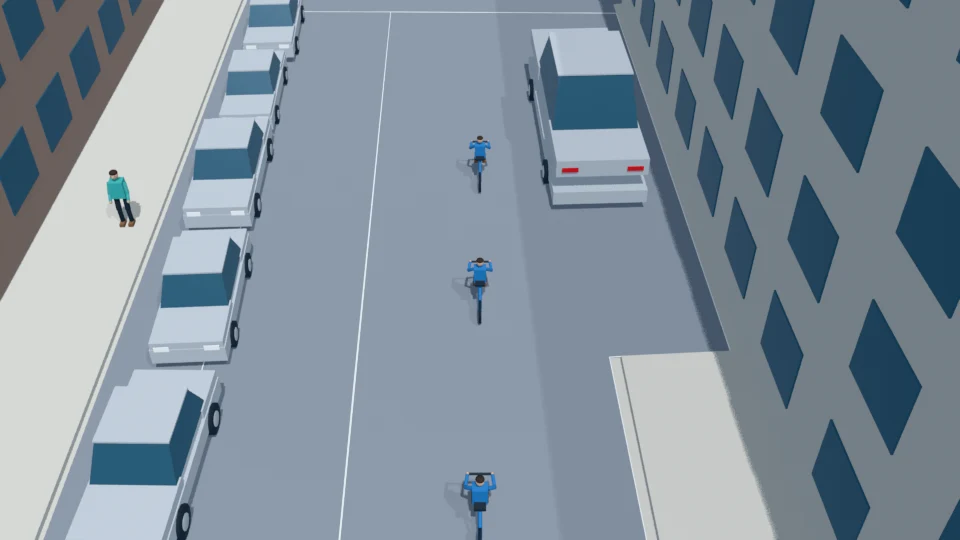
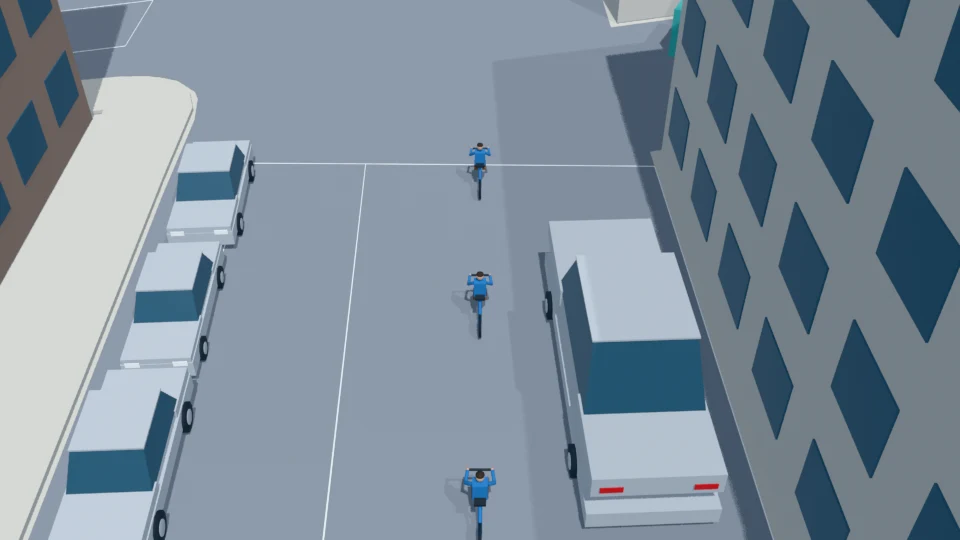
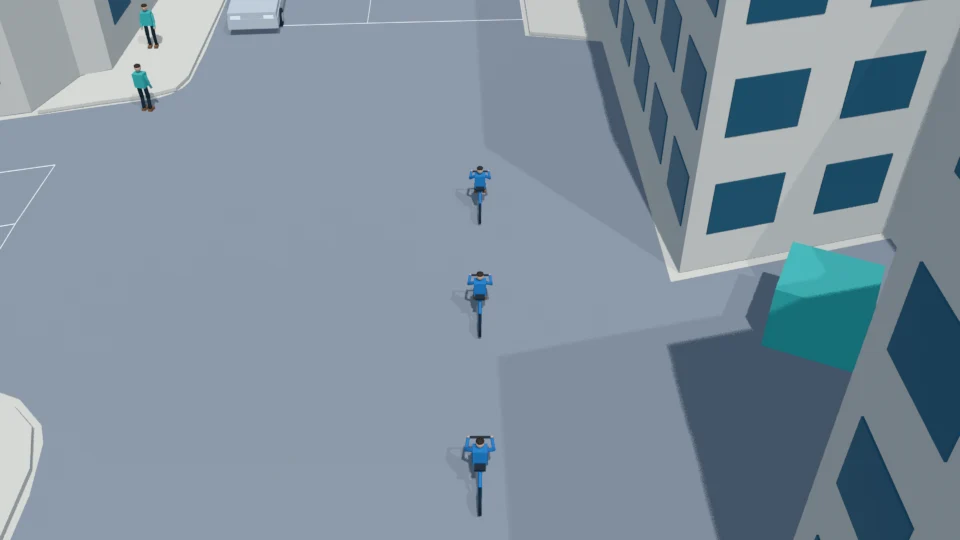
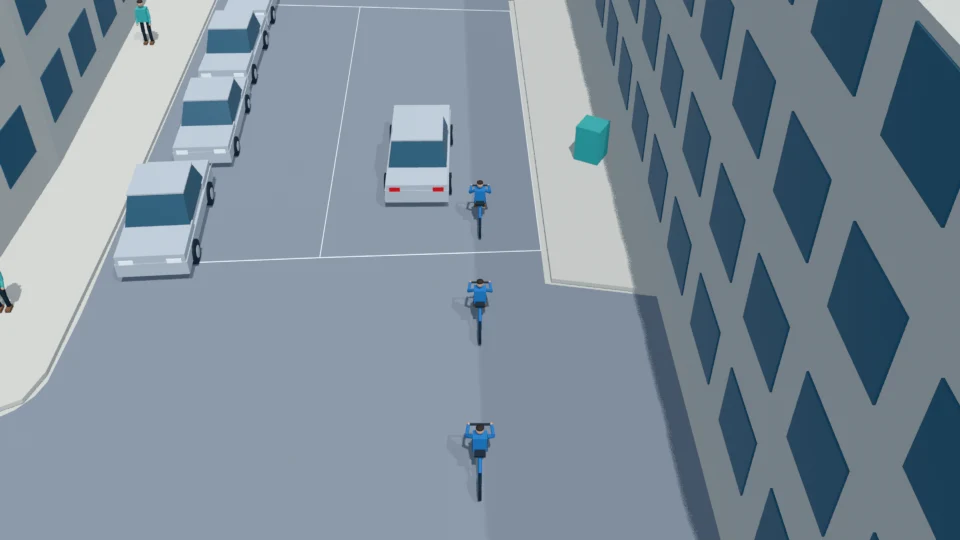
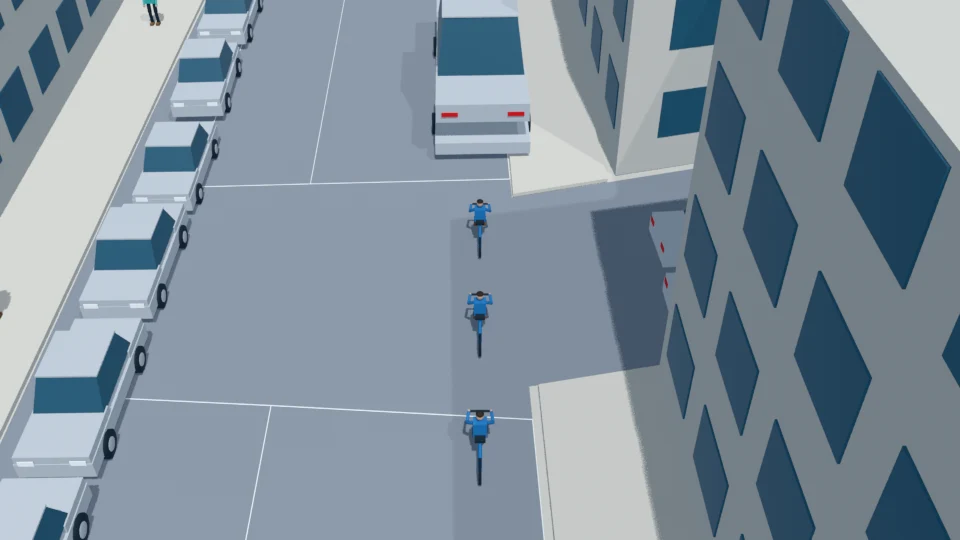
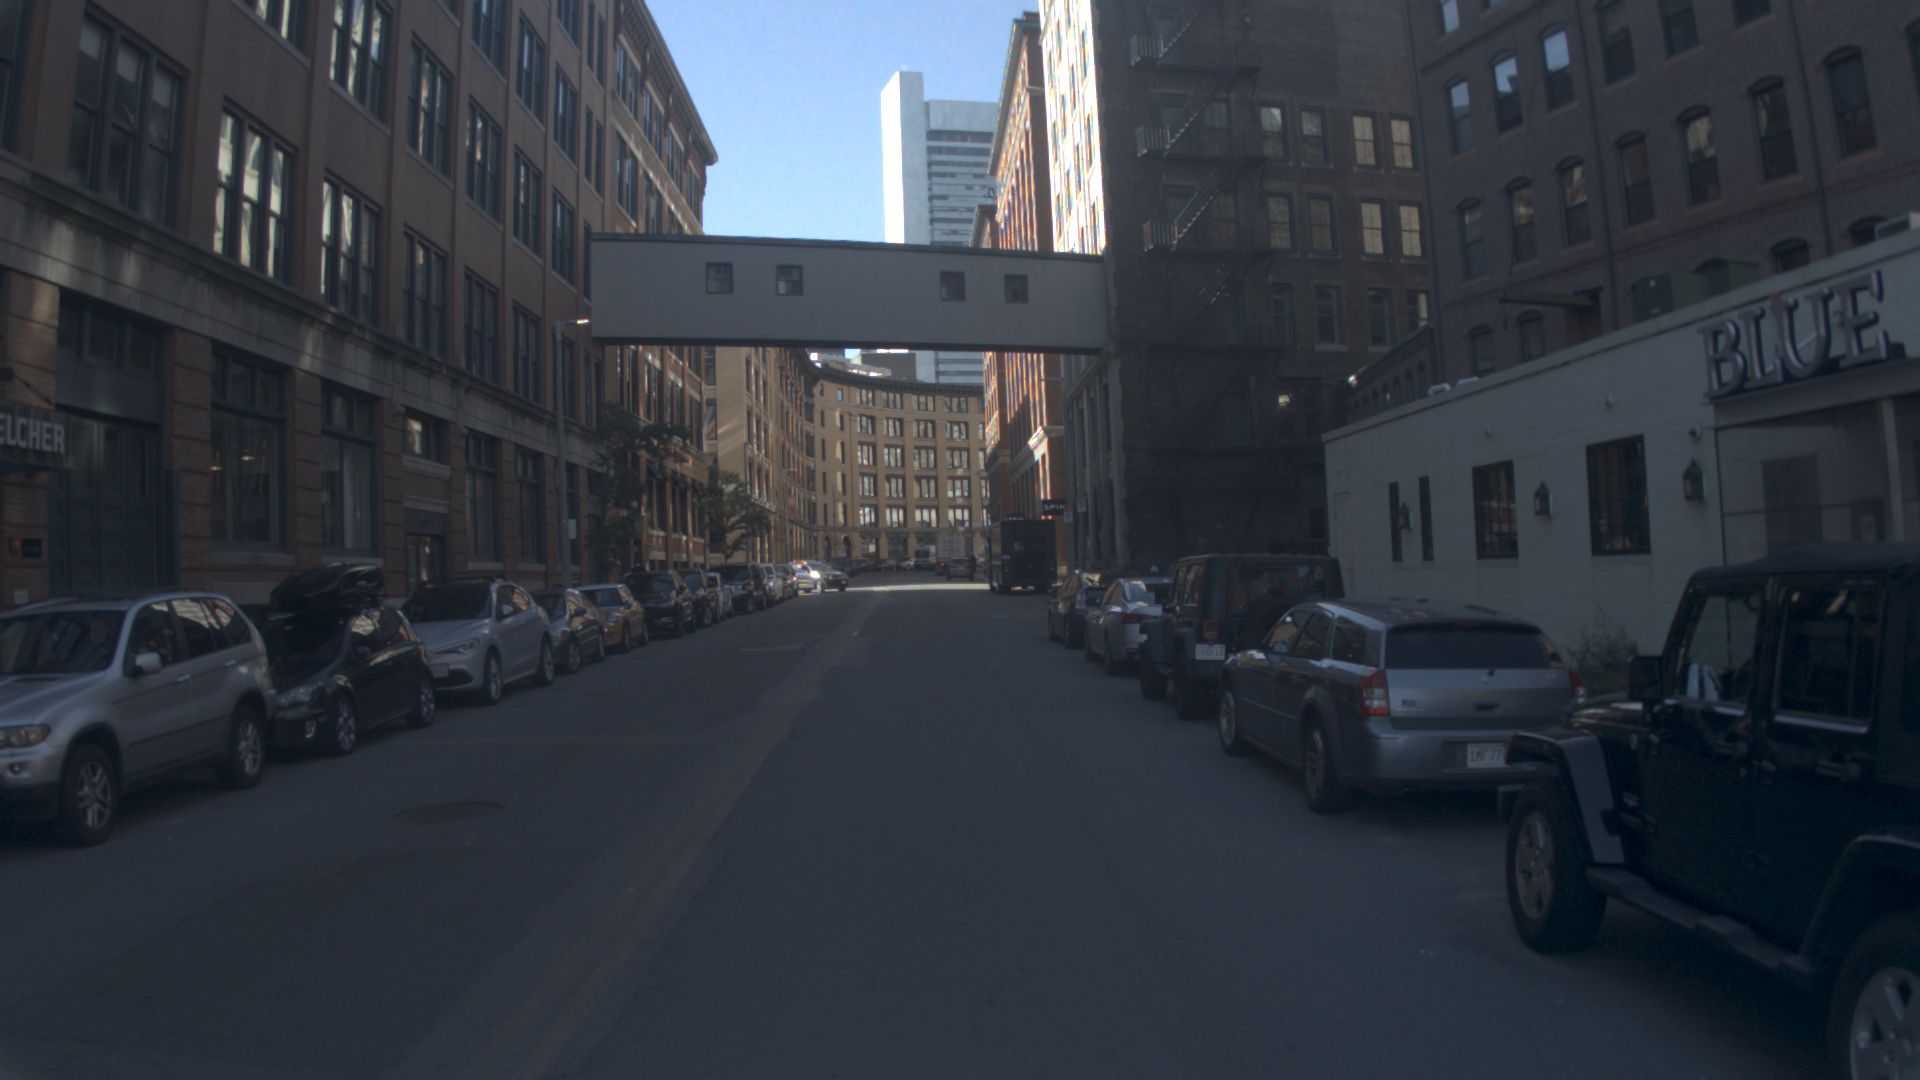
Original NAVSIM camera context
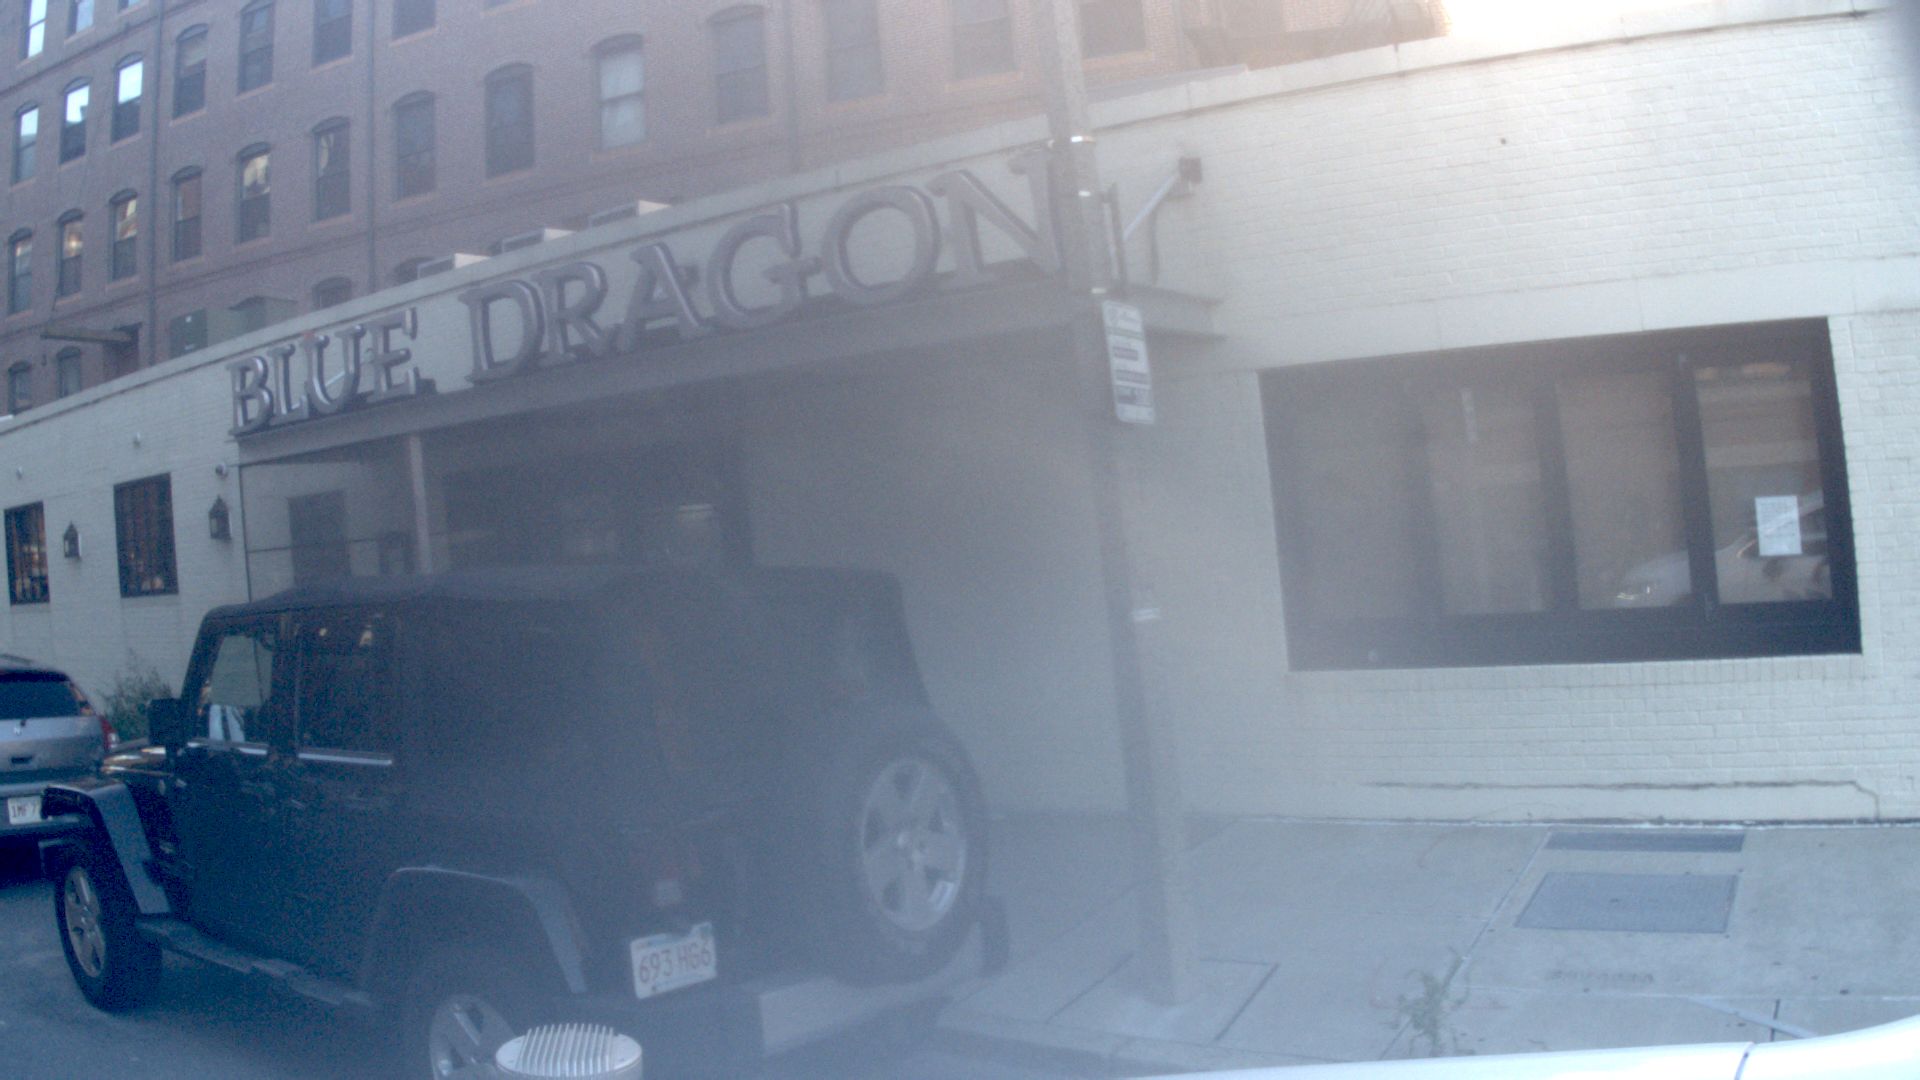
1 conflicting background vehicles were moved to clear holding positions for this counterfactual rehearsal. Original photos remain unchanged. Before later inpainting, any overlap with original-photo traffic must be resolved. Background positions in this 3D rehearsal are not an exact replay of the photographs.
After scene approval
The working pipeline will edit each original NAVSIM camera photograph with Image 2.5. Its same-time Higgsfield view will provide position and posture, annotated with facing direction and current speed. Temporal image requests will cover the full event with a 1 Hz base plus critical moments.
Assumptions and source provenance
- Image 2 supplies broad street and building context only. The police template is a map choice, not an instruction to add police; all three riders and their behavior are counterfactual.
- The teenagers are represented as small young-teen silhouettes with approximately 1.5 m stature. Each 1.85 m long low-step shared bicycle and its mounted rider are represented by one combined cyclist actor.
- All three bicycles use the same modest blue shared-bike design. Persistent rendered role labels distinguish the leader and two pursuers without inventing additional props.
- The 47-second route necessarily extends east beyond the initial x=25..50 interaction area, but remains within the supplied road polygon and map extent.
- Playback is finite and non-looping from -7 through 40 seconds at 20 Hz, including 941 samples. Use monotone, acceleration-bounded interpolation that preserves the specified ordering and minimum gaps; z=0 follows mapped ground.
- Ego approaches along y=0 from x=13 at -7 seconds, brakes from 2 m/s to rest at x=14 by -6 seconds, and remains there through 40 seconds. No artificial clearing maneuver or out-of-frame deletion is proposed.
- Exact retained-vehicle footprints require human inspection. A later Image 2.5 edit must use original Image 2 and this rehearsal only for position and posture, after human approval.
Fresh GPT-6 motion plans use semantic descriptions from the pinned consolidated catalog and NAVSIM environments. No upstream nuPlan vectors, trajectories or images are used. The four source environments are reused; 82 scenario descriptions do not mean 82 independent locations.
Higgsfield revision 1. The portable GLB combines export clips without changing geometry or animation samples.
This review uses Higgsfield revision 1 and the exact exported scene snapshot.
Higgsfield workspace (latest revision) · Download animated GLB · GPT-6 scene plan · Visual review evidence · Motion checks · Approval status