MARSAD / CONSOLIDATED CATALOG / #023
Unsteady adult wavering between sidewalk and roadway
Awaiting your 3D scene approvalAn adult, counterfactually specified as intoxicated, hesitates on the south sidewalk, staggers into the roadway, retreats, and enters again. The adult then remains unsteady in ego's corridor through 40 seconds while a separate sidewalk pedestrian stays back. Ego never resumes.
Original description: 前方有醉酒者步履蹒跚,在机动车道与人行道之间摇摆不定。
Loading the full animated scene…
Critical moments
What to verify
- Require exactly two persistent adults: one unsteady roadway pedestrian and one stationary sidewalk witness.
- Check that initial and intermediate sidewalk positions lie within the supplied south sidewalk polygon, and both incursions enter the road polygon without teleportation.
- Keep active walking cruise speeds within 0.6 to 1.7 m/s, allowing slower acceleration and stopping transients. Both reversals must occur while the root remains stationary.
- Preserve unwrapped headings through 407.46 degrees and beyond; do not interpolate a sudden full-body heading flip during translation.
- Maintain at least 0.6 m body clearance from the witness throughout, with no contact, injury depiction, or invented intervention.
- From 18 through 40 seconds, retain the adult's footprint in ego's corridor. Ego must remain stopped at x=14 with ego_release_s=-1.
- Human review must approve the full motion, postural portrayal, map support, and retained-photo obstacle clearance before image generation; these are requirements rather than completed tests.
Review notes
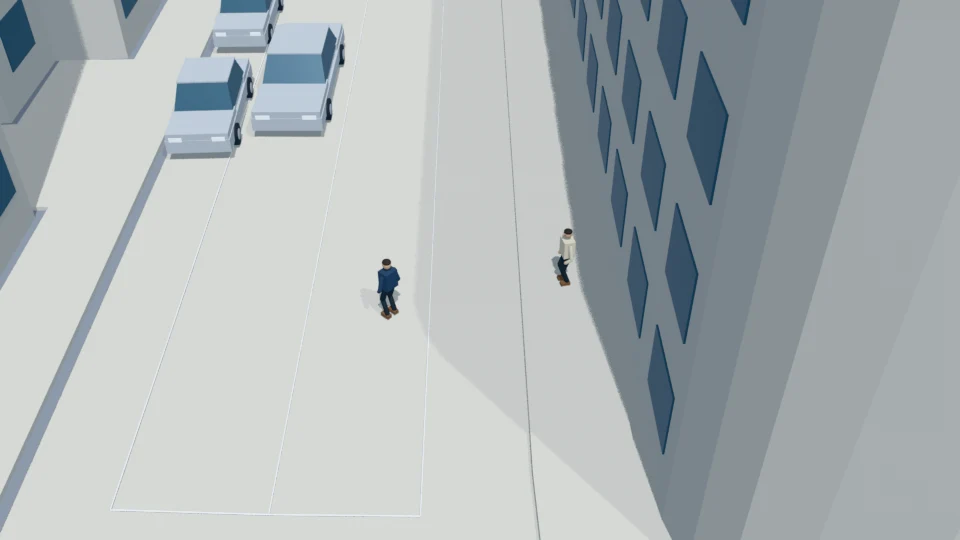
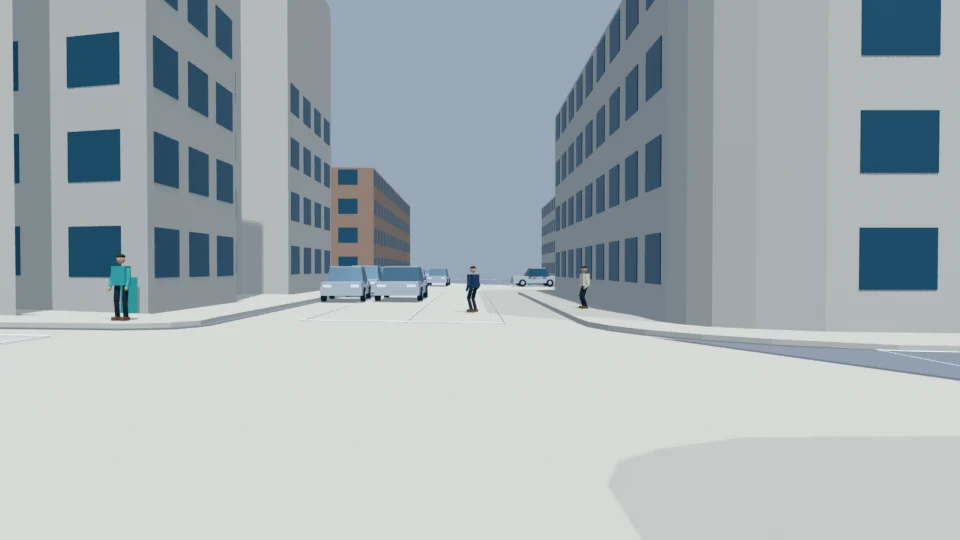
Inspected the whole event sheet. The unsteady adult follows a wavering path into and out of the road while the second pedestrian remains clear. Body gait is a coarse rehearsal proxy, with the path and relationship legible.
Check action, relative position, facing, posture and visibility. Approximate offsets are acceptable. Sampled visual checks do not prove every contact or continuous collision clearance.
Rendered inspection views
Event, approach and final views rendered from the exact committed Higgsfield Blender source. These are procedural 3D previews, not generated training photographs.
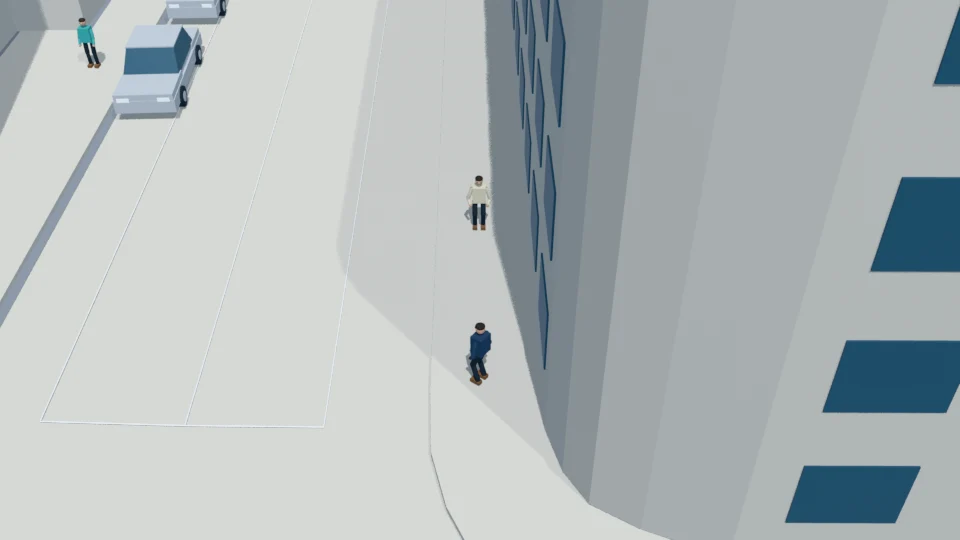
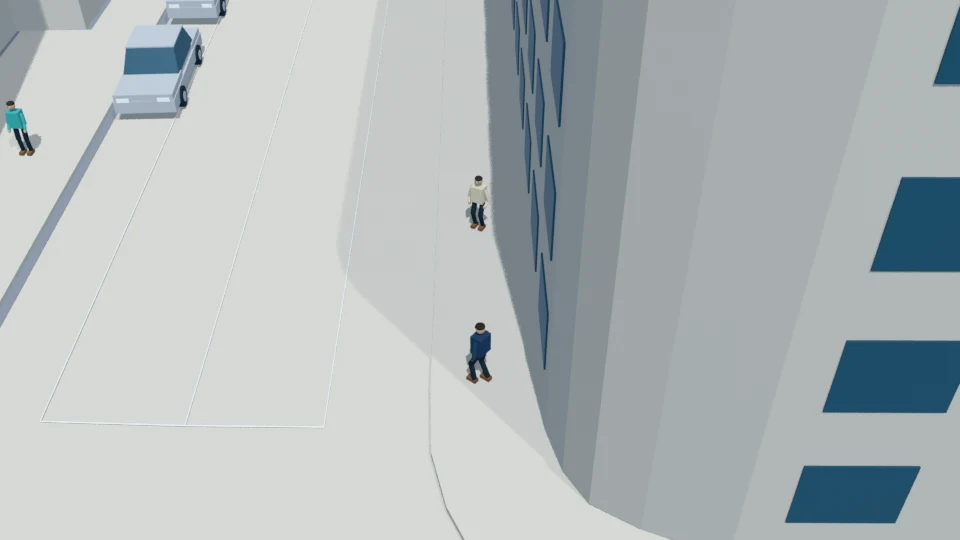
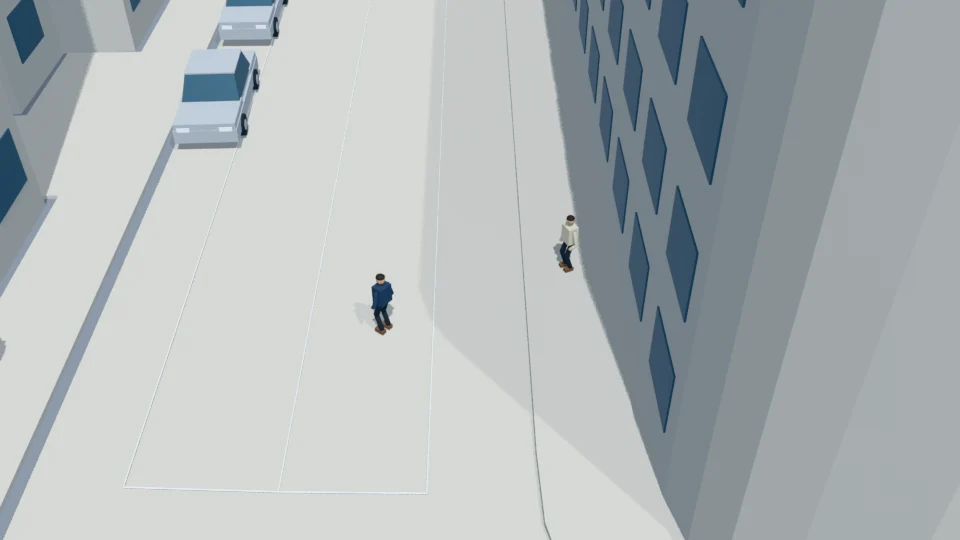
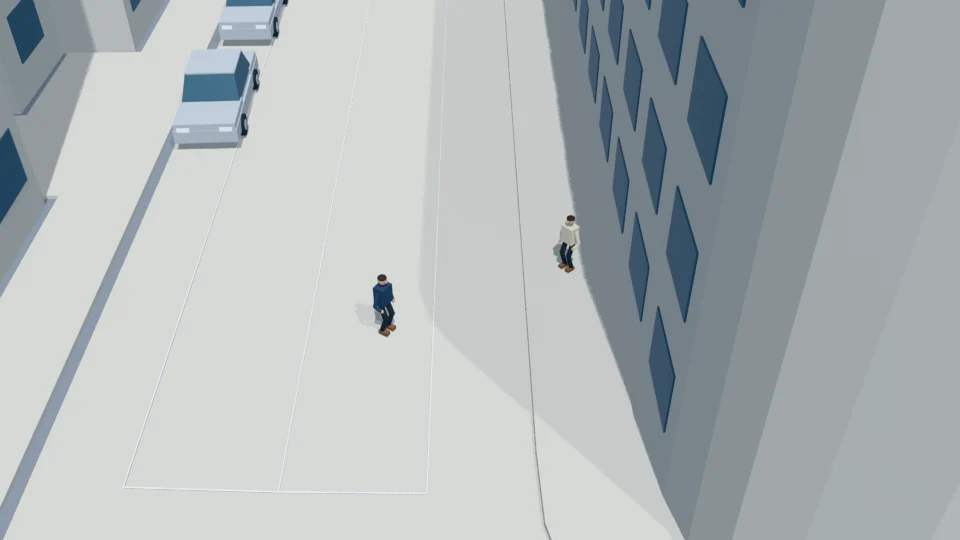
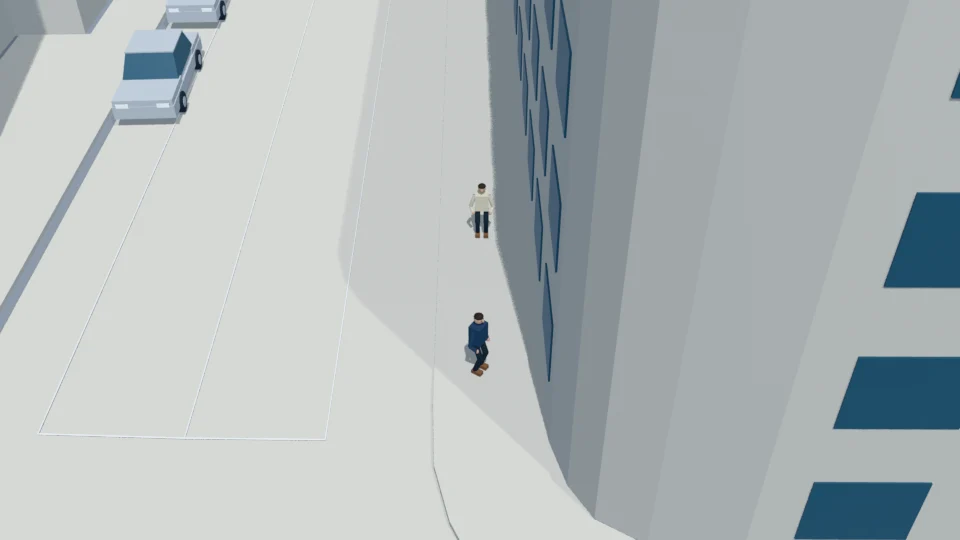
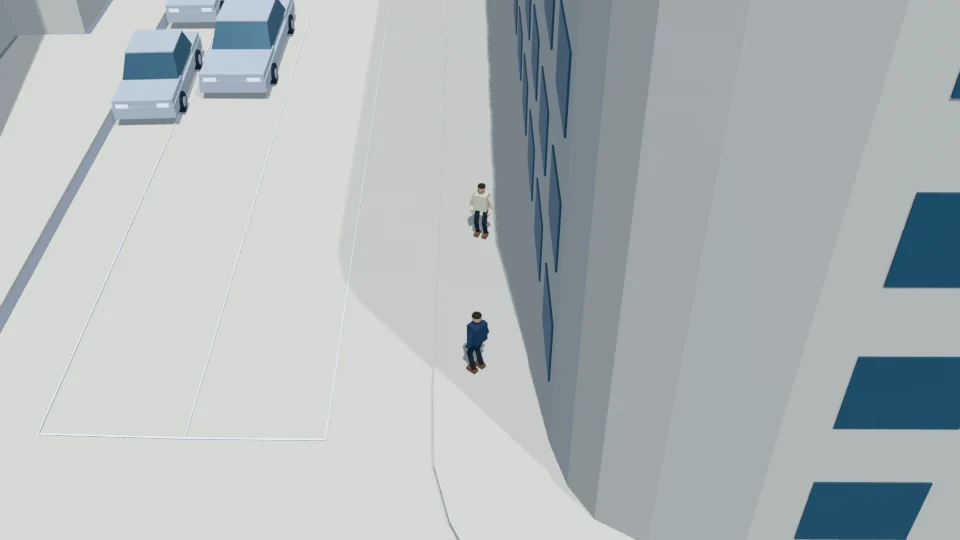
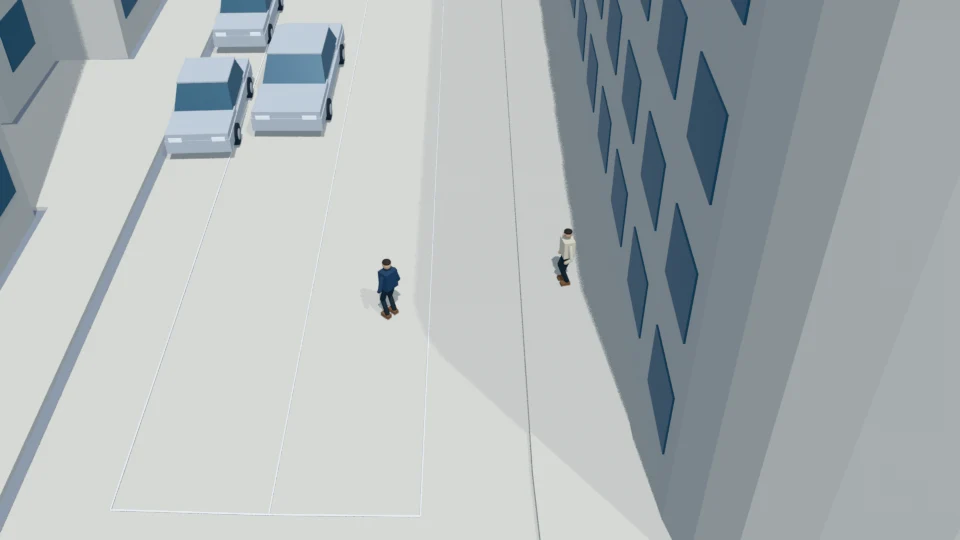
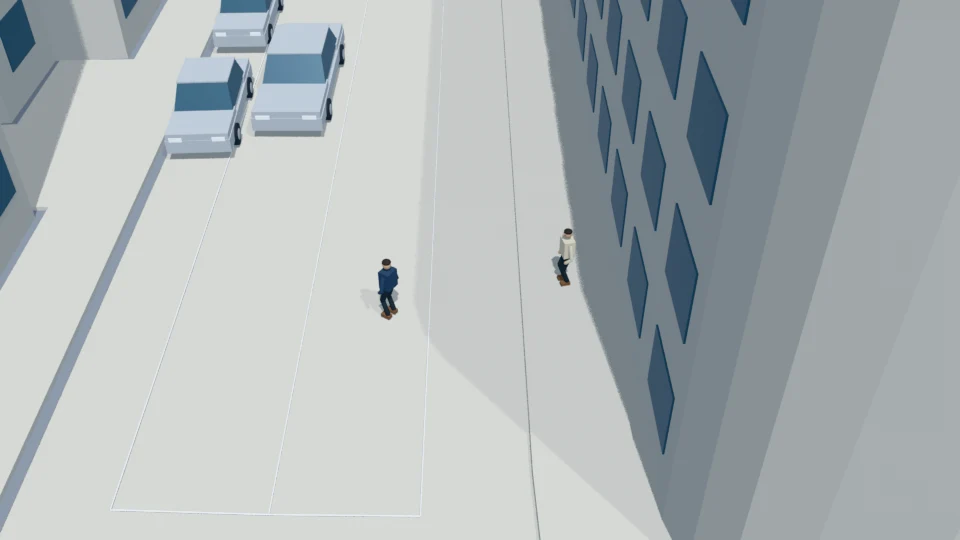
Original NAVSIM camera context
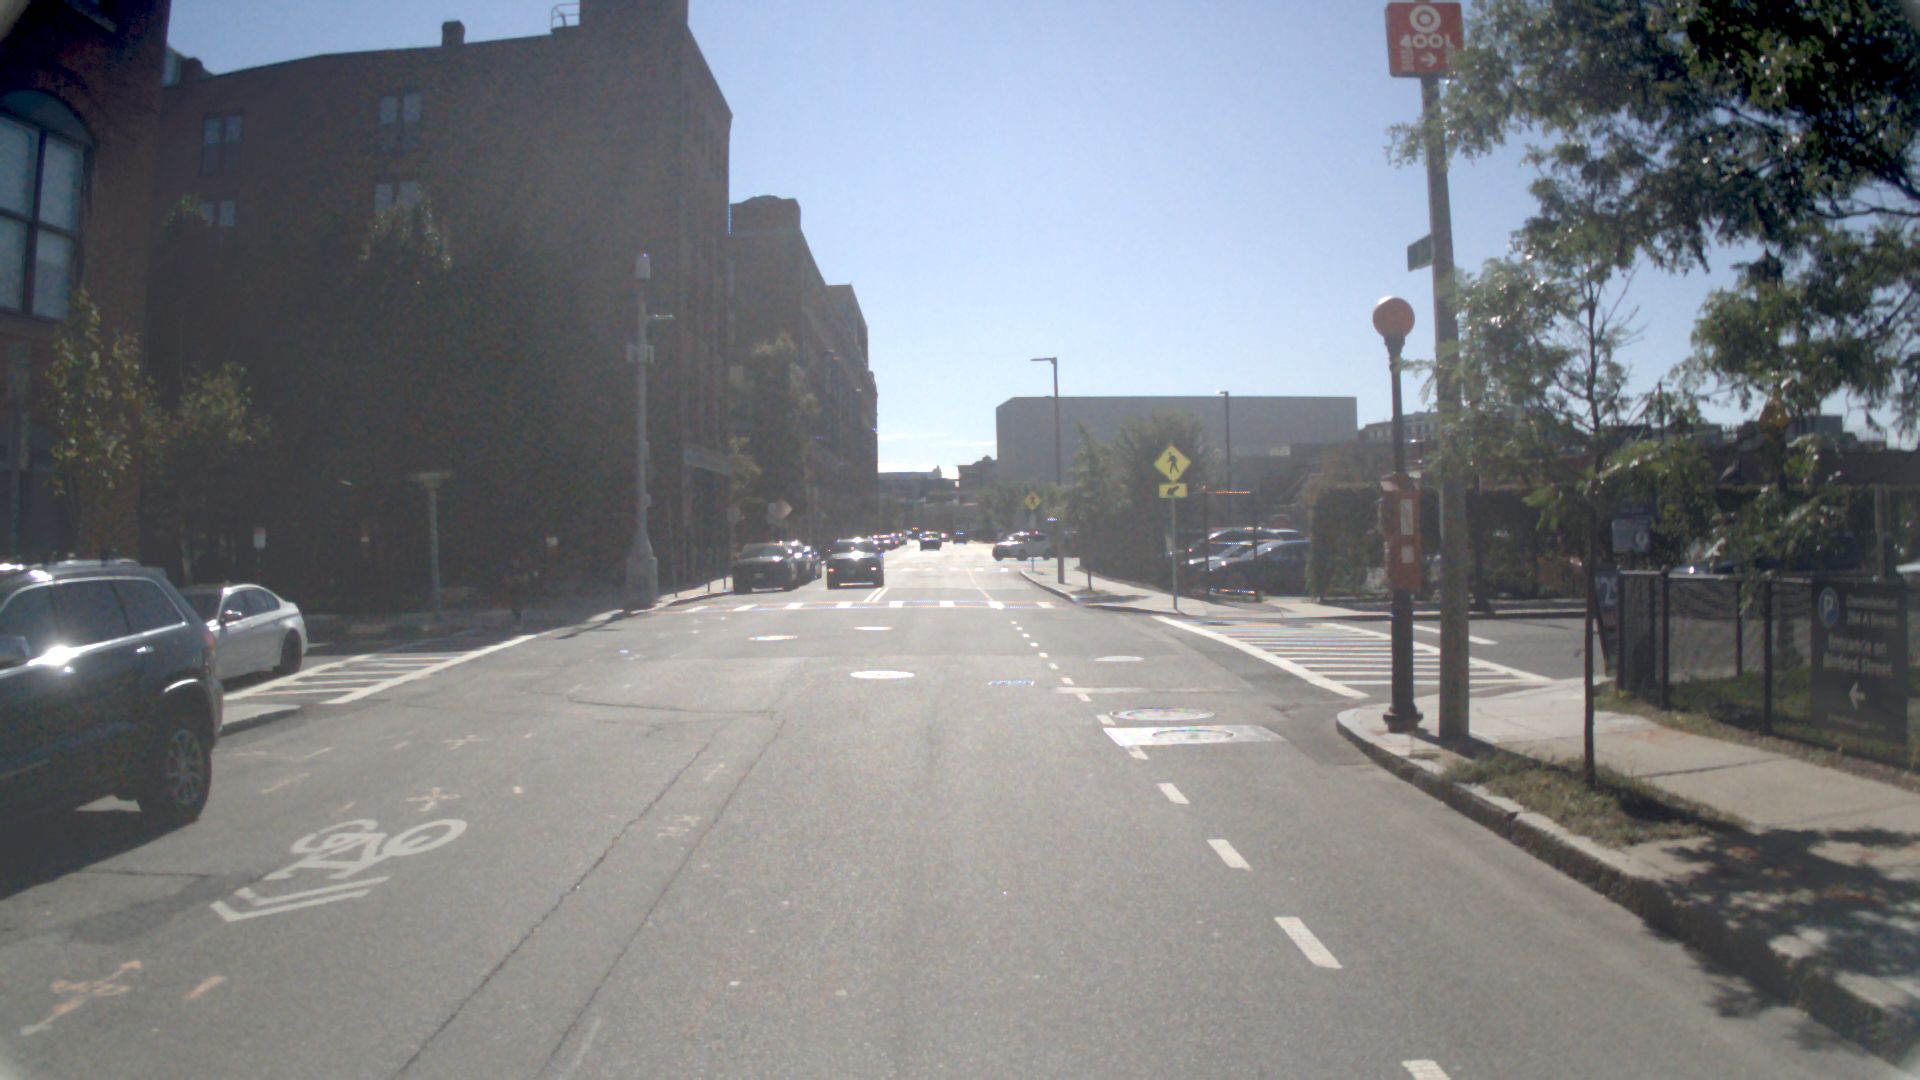
2 conflicting background vehicles were moved to clear holding positions for this counterfactual rehearsal. Original photos remain unchanged. Before later inpainting, any overlap with original-photo traffic must be resolved. Background positions in this 3D rehearsal are not an exact replay of the photographs.
After scene approval
The working pipeline will edit each original NAVSIM camera photograph with Image 2.5. Its same-time Higgsfield view will provide position and posture, annotated with facing direction and current speed. Temporal image requests will cover the full event with a 1 Hz base plus critical moments.
Assumptions and source provenance
- Image 4 supports broad street, sidewalk, and building context only. Intoxication is the requested counterfactual characterization, not a diagnosis or an observation about anyone in the source photograph.
- The passive sidewalk witness is an ancillary second actor, added without a new incident or resolution. No handler, medical response, pursuit, or forced clearance is introduced.
- The selected south sidewalk near x=40..46 lies approximately between y=-5.3 and y=-3.1. The final position at y=0.15 is deliberately inside the motor-vehicle corridor.
- Playback is finite and non-looping from -7 through 40 seconds at 20 Hz, including 941 samples. The two incursions are separately authored rather than a repeated animation loop.
- All roots remain at z=0 relative to mapped ground. Use bounded-speed translation, stationary turns, and restrained skeletal sway without adding an unkeyed root excursion or fall.
- Ego approaches along y=0 from x=13 at -7 seconds, brakes from 2 m/s to rest at x=14 by -6 seconds, and stays stopped through the final frame because the obstruction persists.
- Exact static-obstacle footprints remain uncertain and require human inspection. Any later Image 2.5 edit must use original Image 4, with this rehearsal controlling only positions and postures after human approval.
Fresh GPT-6 motion plans use semantic descriptions from the pinned consolidated catalog and NAVSIM environments. No upstream nuPlan vectors, trajectories or images are used. The four source environments are reused; 82 scenario descriptions do not mean 82 independent locations.
Higgsfield revision 1. The portable GLB combines export clips without changing geometry or animation samples.
This review uses Higgsfield revision 1 and the exact exported scene snapshot.
Higgsfield workspace (latest revision) · Download animated GLB · GPT-6 scene plan · Visual review evidence · Motion checks · Approval status